A mech game prototype, pushed by Gemini 4 Argon
agent
+1:09:40reasoning
The asset path mapping indicates block_dummy.glb is correctly associated. Examining the code related to the clipping tool aims to ensure left-right consistency across different execution contexts. This is to verify the consistent display of models regardless of the tool used.
read_file{"EndLine":120,"Path":"~/work/sortie/src/view/clip.ts","StartLine":1}
input
{ "EndLine": 120, "Path": "~/work/sortie/src/view/clip.ts", "StartLine": 1 }result, 121 lines
Showing lines 1-120 of 173 1: import * as THREE from 'three'; 2: import { model, type ModelName } from '../render/assets'; 3: import { KESTREL_DECALS, STRIKER_DECALS, applyDecals } from '../render/decals'; 4: import { treatEyes } from '../render/eyes'; 5: import type { ThrustReading } from '../render/exhaust'; 6: import { setLook, look } from '../render/look'; 7: import { MechRig, POSES } from '../render/mech'; 8: import type { PaletteName } from '../render/palette'; 9: import { Pipeline } from '../render/pipeline'; 10: import { addSpaceLight, createBackdrop, followSun, spaceEnvironment } from '../render/space'; 11: import { BEND_POSE, SHOT_NAMES, clipFrames, mixPose, shotView, type ShotName } from './clip-plan'; 12: import { CameraRig } from './cameras'; 13: import { benchInput } from './thrusters'; 14: 15: /** 16: * A review clip of one model, rendered frame by frame so it comes out the same on any machine. Driven by 17: * tools/clip.mjs, which calls window.__clip.render(i) and pipes the frames into ffmpeg. 18: * /?view=clip&model=block_dummy&shots=chase,turn&fps=24&palette=merc&look=kit 19: * Any model with the 22 joint rig. Lab lineups hold many frames under slots, so they don't rig. 20: */ 21: export async function startClip(canvas: HTMLCanvasElement, q: URLSearchParams) { 22: setLook(q.get('look')); 23: await document.fonts.ready; 24: const w = Number(q.get('w') ?? 854), h = Number(q.get('h') ?? 480), fps = Number(q.get('fps') ?? 24); 25: const shots = (q.get('shots')?.split(',') ?? SHOT_NAMES) as ShotName[]; 26: const frames = clipFrames(shots, fps); 27: 28: const scene = new THREE.Scene(); 29: const camera = new THREE.PerspectiveCamera(35, w / h, 0.3, 2e5); 30: const backdrop = createBackdrop(); 31: const pipe = new Pipeline(canvas, scene, camera, backdrop); 32: pipe.resize(w, h); 33: const sun = addSpaceLight(scene); 34: scene.environment = spaceEnvironment(pipe.renderer, backdrop); 35: scene.environmentIntensity = 0.8 * look().fill; 36: 37: const name = (q.get('model') ?? 'striker') as ModelName; 38: const palette = (q.get('palette') ?? 'merc') as PaletteName; 39: const yardName = q.get('yardstick') as ModelName | null; 40: const sep = yardName ? Number(q.get('sep') ?? 4.3) : 0; 41: const root = await model(name, palette); 42: root.position.x = -sep; 43: if (name === 'striker') applyDecals(root, STRIKER_DECALS); 44: if (name === 'block_dummy') applyDecals(root, KESTREL_DECALS); 45: treatEyes(root, 'spill'); 46: scene.add(root); 47: const rig = new MechRig(root); 48: root.updateMatrixWorld(true); 49: rig.apply(POSES.stand); 50: root.updateMatrixWorld(true); 51: const box = new THREE.Box3().setFromObject(root); 52: const height = box.getSize(new THREE.Vector3()).y; 53: const footY = box.min.y; 54: const size = height / 17.6; 55: 56: const light = new THREE.PointLight('#ffffff', 0, 0, 2); 57: scene.add(light); 58: 59: let yardRoot: THREE.Object3D | null = null; 60: let yardRig: MechRig | null = null; 61: const yardLight = new THREE.PointLight('#ffffff', 0, 0, 2); 62: if (yardName) { 63: yardRoot = await model(yardName, palette); 64: yardRoot.position.x = sep; 65: if (yardName === 'striker') applyDecals(yardRoot, STRIKER_DECALS); 66: treatEyes(yardRoot, 'spill'); 67: scene.add(yardRoot); 68: yardRig = new MechRig(yardRoot); 69: if (yardName === 'striker') yardRig.hold(await model('rifle', palette)); 70: yardRig.apply(POSES.stand); 71: yardRoot.updateMatrixWorld(true); 72: scene.add(yardLight); 73: } 74: 75: // the pilot and deck for the scale shot: a person is the one thing everyone knows the size of 76: const ground = new THREE.Group(); 77: const deck = new THREE.Mesh(new THREE.CircleGeometry(height * 2, 48), new THREE.MeshStandardMaterial({ color: '#2a2f36', roughness: 0.85, metalness: 0.2 })); 78: deck.rotation.x = -Math.PI / 2; 79: deck.position.y = footY; 80: ground.add(deck); 81: const pilot = await model('lab_pilot' as ModelName, palette); 82: pilot.traverse((o) => { if (/^slot\d+$/.test(o.name) && o.name !== 'slot0') o.visible = false; }); 83: // lab slot 0 stands at x = -.55: bring the pilot beside the frame's foot, facing the camera 84: pilot.position.set(0.55 + height * 0.3, footY, height * 0.16); 85: pilot.rotation.y = 0.4; 86: ground.add(pilot); 87: scene.add(ground); 88: 89: // the game's chase camera, read for its numbers: this view moves its own camera 90: const chase = new CameraRig(); 91: const reading: ThrustReading = { x: 0, y: 0, z: 0, boosting: false }; 92: const centre = new THREE.Vector3(); 93: const offset = new THREE.Vector3(); 94: const look_ = new THREE.Vector3(); 95: const up = new THREE.Vector3(0, 1, 0); 96: const yawQ = new THREE.Quaternion(); 97: const DT = 1 / 120; 98: let clock = 0; 99: 100: const feed = (state: Parameters<typeof benchInput>[0], t: number, dt: number) => { 101: const f = benchInput(state, t); 102: reading.x = f.thrust.x; 103: reading.y = f.thrust.y; 104: reading.z = f.thrust.z; 105: reading.boosting = f.boosting; 106: reading.assault = f.assault; 107: reading.quick = f.quick; 108: rig.thrust(reading, clock, dt); 109: rig.lightExhaust(light); 110: if (yardRig && yardRoot) { 111: yardRig.thrust(reading, clock, dt); 112: yardRoot.updateMatrixWorld(true); 113: yardRig.lightExhaust(yardLight); 114: } 115: }; 116: 117: const render = (i: number) => { 118: const f = frames[i]; 119: const v = shotView(f); 120: // thrusters step at 120 Hz whatever the clip's frame rate, as a game wouldresultThe tool's output was truncated due to being too long. You can find the full output in a file at file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/steps/478/output.txt.
The tool's output was truncated due to being too long. You can find the full output in a file at file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/steps/478/output.txt.

Here is a preview with the middle of the output truncated:
Command exited with code 0.

Command output:
Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)
00:00.070  system.path      | WARNING Could not get a list of mounted file-systems
INFO Draco is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_draco_bridge.so
INFO MeshOptimizer is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_meshopt_bridge.so
03:02:22 | INFO: Starting glTF 2.0 export
03:02:22 | INFO: Extracting primitive: belt_girdle.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: codpiece_crest.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: codpiece_hi.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: codpiece_lo.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hip_collar.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hip_collar.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hip_trunnion.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hip_trunnion.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pelvis_core.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_0.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_1.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_lip.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_front_lip.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_rear_0.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_rear_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_rear_1.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_rear_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_0.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_1.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_vane.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: skirt_side_vane.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: tail_fin.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: tail_stabilizer.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hip_ball_joint.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: achilles_piston.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf.L.glow
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf_housing.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf_thruster_pod.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf_thruster_trim.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: calf_vents.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: ankle_ball.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: ankle_collar.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: ankle_spat.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: ankle_spat_trim.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sabaton_heel.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sabaton_instep.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sabaton_toe.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sabaton_toe_claw.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sole_front.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: sole_heel.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: greave_s
<truncated 18625 of 28517 bytes from the middle of the output>
acting primitive: upperarm_core.L.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: upperarm_swivel.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_fin.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_shell_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_shell_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_shell_2.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_shell_3.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_under_slats.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_wing.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: pauldron_wing_trim.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: shoulder_block.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: shoulder_ram_b.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: shoulder_ram_f.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: shoulder_trunnion.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: bicep_shell_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: bicep_shell_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: elbow_collar.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: elbow_drum.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: elbow_piston.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: forearm_core.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: fingers_block.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: hand_carapace.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: palm_block.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_cowl.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_plasma_core
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_rail_+0.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_rail_-0.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_receiver.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_scope.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: rifle_scope_lens
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: thumb_block.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: wrist_ball.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: vambrace_0.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: vambrace_1.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: vambrace_2.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: upperarm_core.R.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: upperarm_swivel.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: torso_core.001
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: waist_piston_b.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: waist_piston_b.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: waist_piston_f.L
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Extracting primitive: waist_piston_f.R
03:02:22 | INFO: Primitives created: 1
03:02:22 | INFO: Finished glTF 2.0 export in 0.3386516571044922 s

kit: block_dummy -> ~/work/sortie/public/assets/block_dummy.glb (1418 KB, 2.8s)

Blender quit
flight: 5962 ms
turn_000: 4784 ms
turn_045: 5085 ms
turn_090: 4541 ms
turn_135: 5063 ms
turn_180: 4876 ms
turn_315: 5151 ms
-rw------- 1 runner runner 1.1M Nov 15 03:03 ~/out/kestrel-flight-yardstick.png
-rw------- 1 runner runner 797K Nov 15 03:02 /tmp/inspect/turn_000.png
-rw------- 1 runner runner 763K Nov 15 03:02 /tmp/inspect/turn_045.png
-rw------- 1 runner runner 711K Nov 15 03:02 /tmp/inspect/turn_090.png
-rw------- 1 runner runner 818K Nov 15 03:02 /tmp/inspect/turn_135.png
-rw------- 1 runner runner 799K Nov 15 03:02 /tmp/inspect/turn_180.png
-rw------- 1 runner runner 764K Nov 15 03:03 /tmp/inspect/turn_315.png

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-478.log
read_file{"Path":"~/out/kestrel-flight-yardstick.png"}
input
{ "Path": "~/out/kestrel-flight-yardstick.png" }result, 1 line
Showing binary file of type image/png
step_484_media_0.jpg read_file{"Path":"/tmp/inspect/turn_000.png"}
input
{ "Path": "/tmp/inspect/turn_000.png" }result, 1 line
Showing binary file of type image/png
step_485_media_0.jpg read_file{"Path":"/tmp/inspect/turn_180.png"}
input
{ "Path": "/tmp/inspect/turn_180.png" }result, 1 line
Showing binary file of type image/png
step_486_media_0.jpg
agent
+1:10:34reasoning
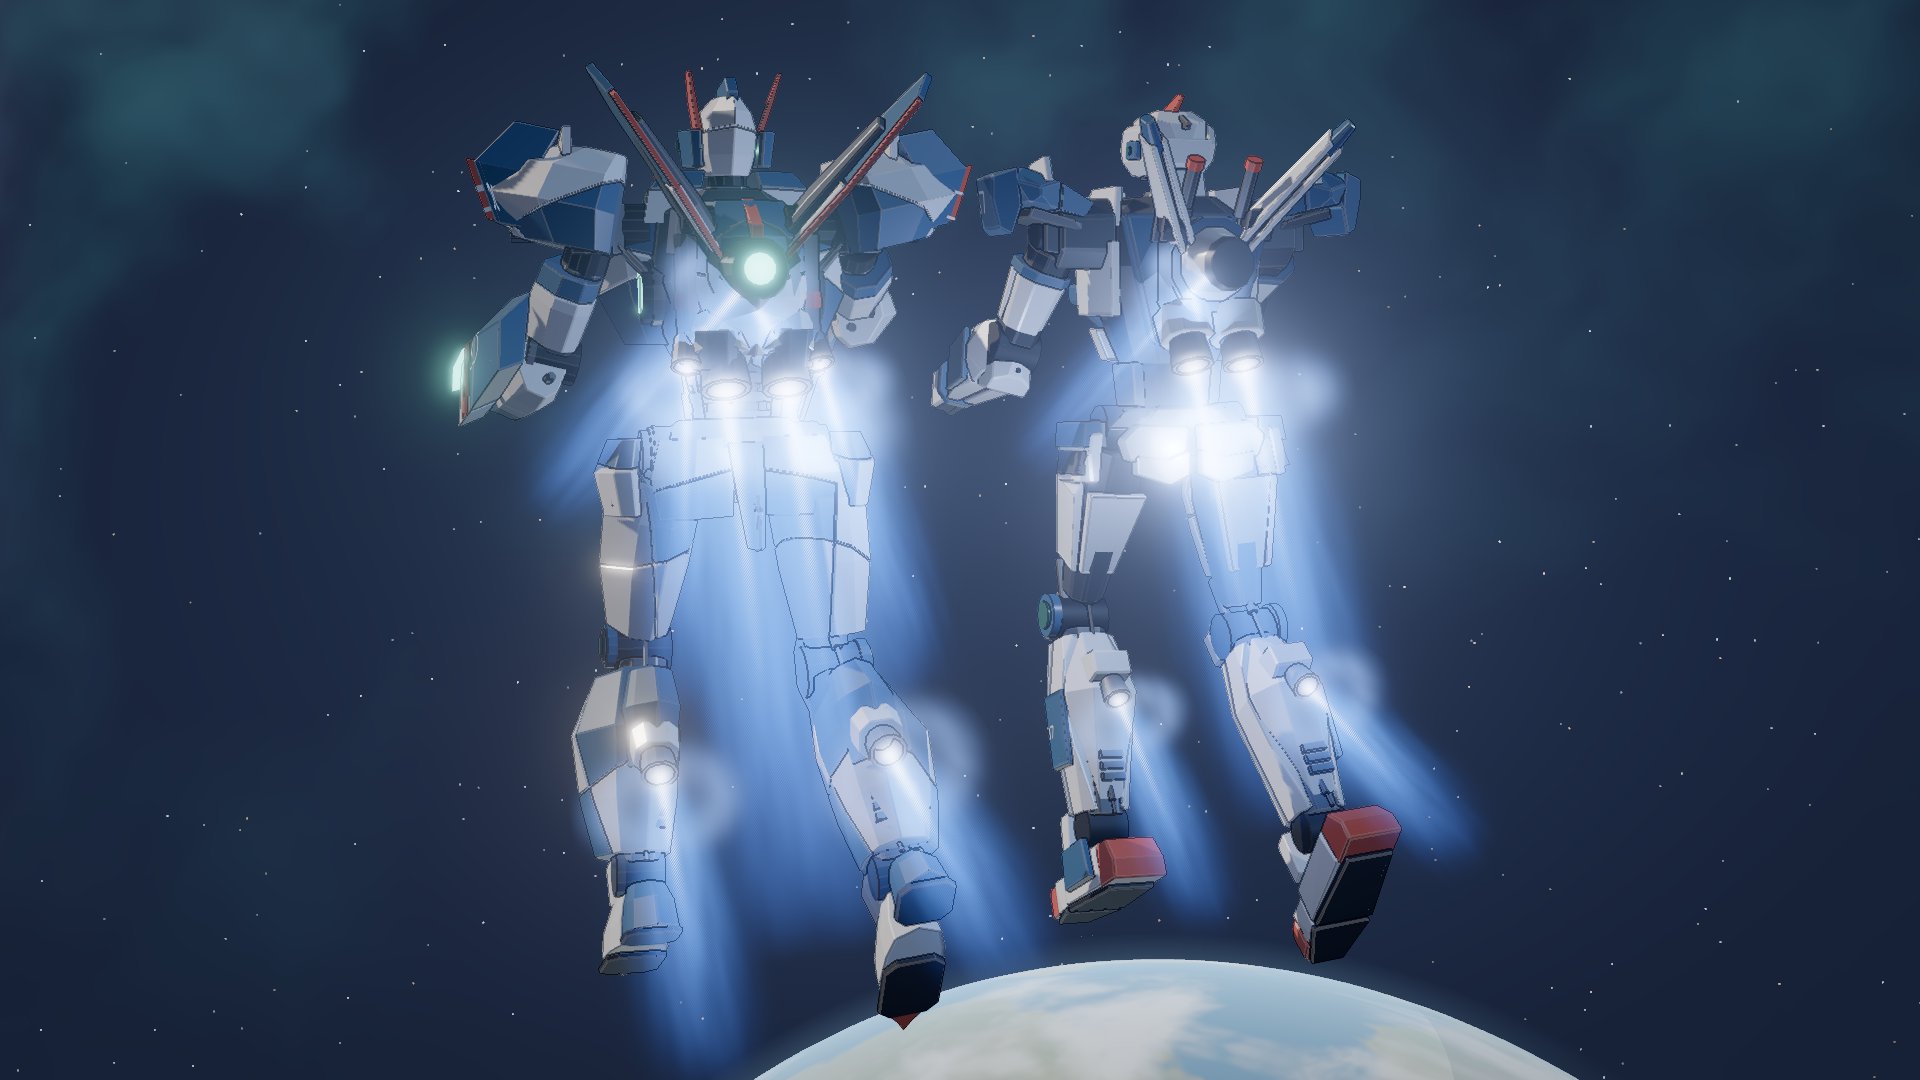
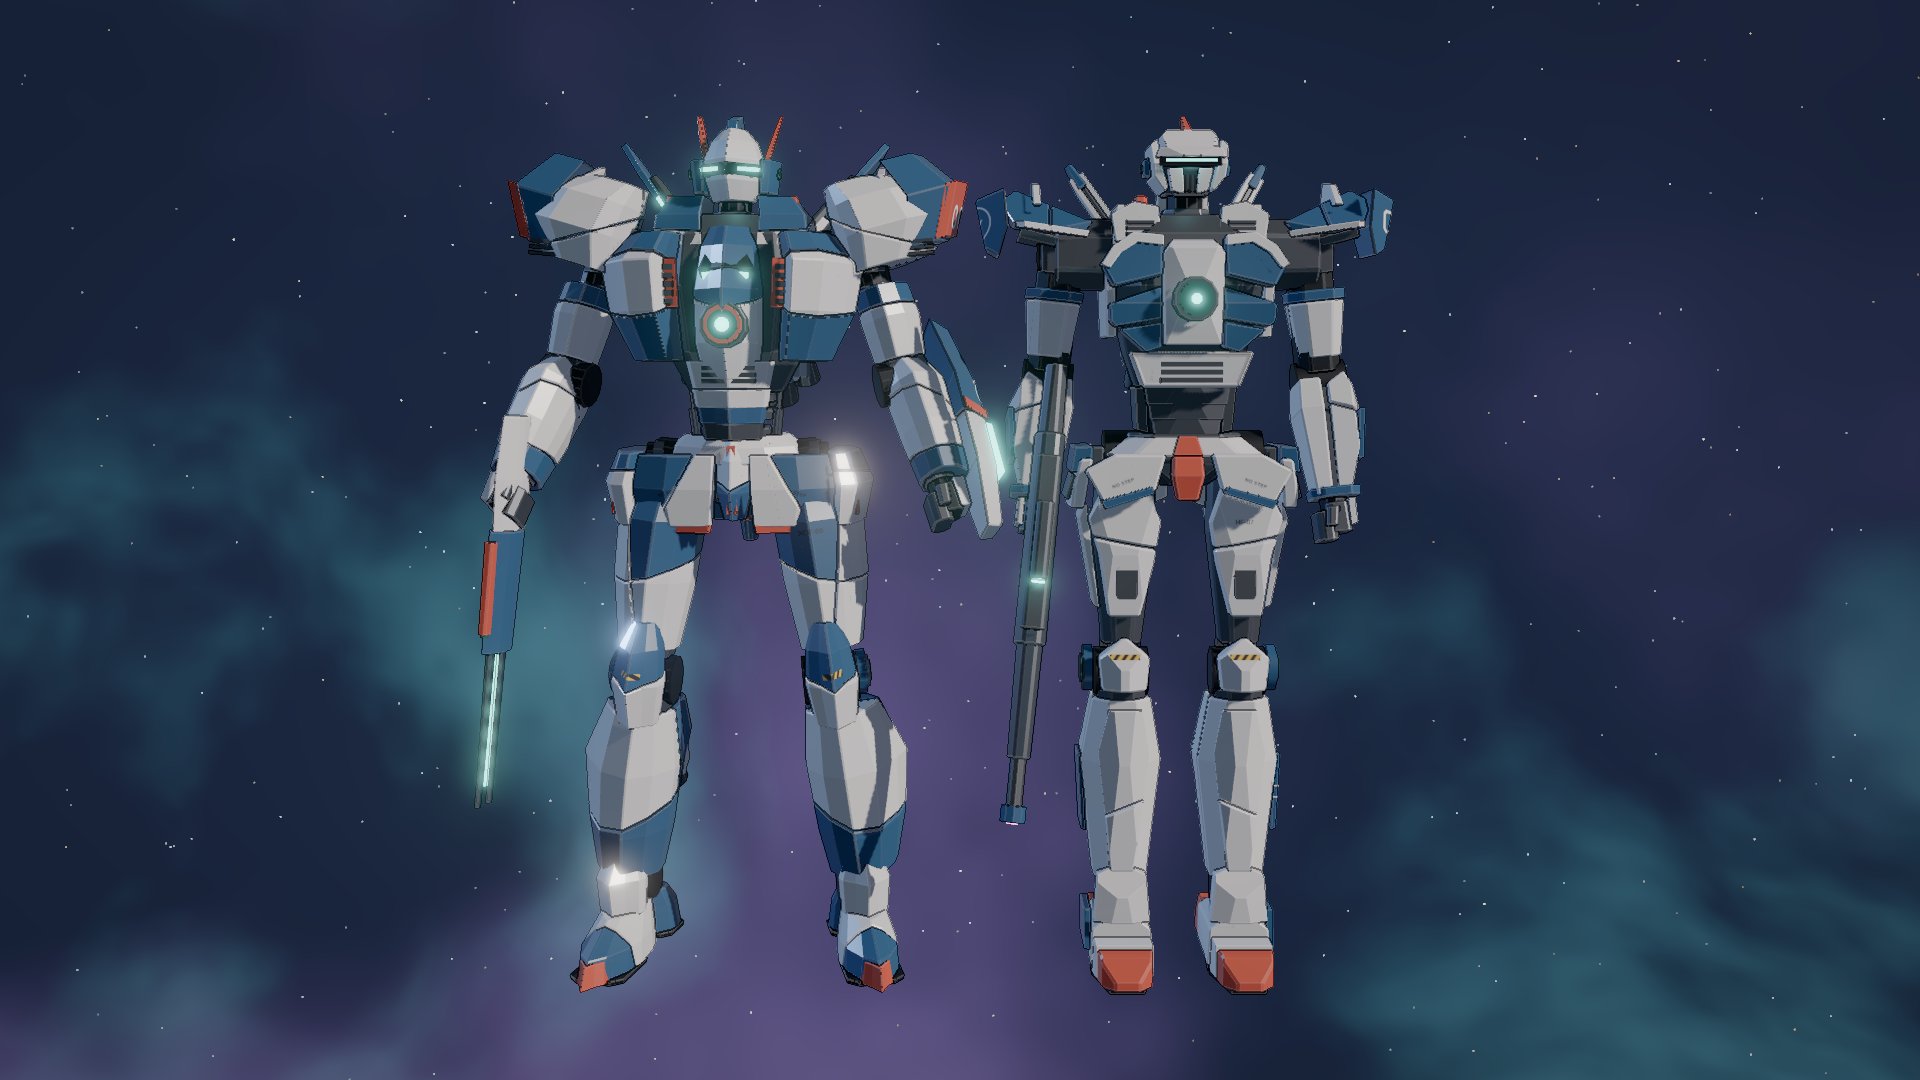
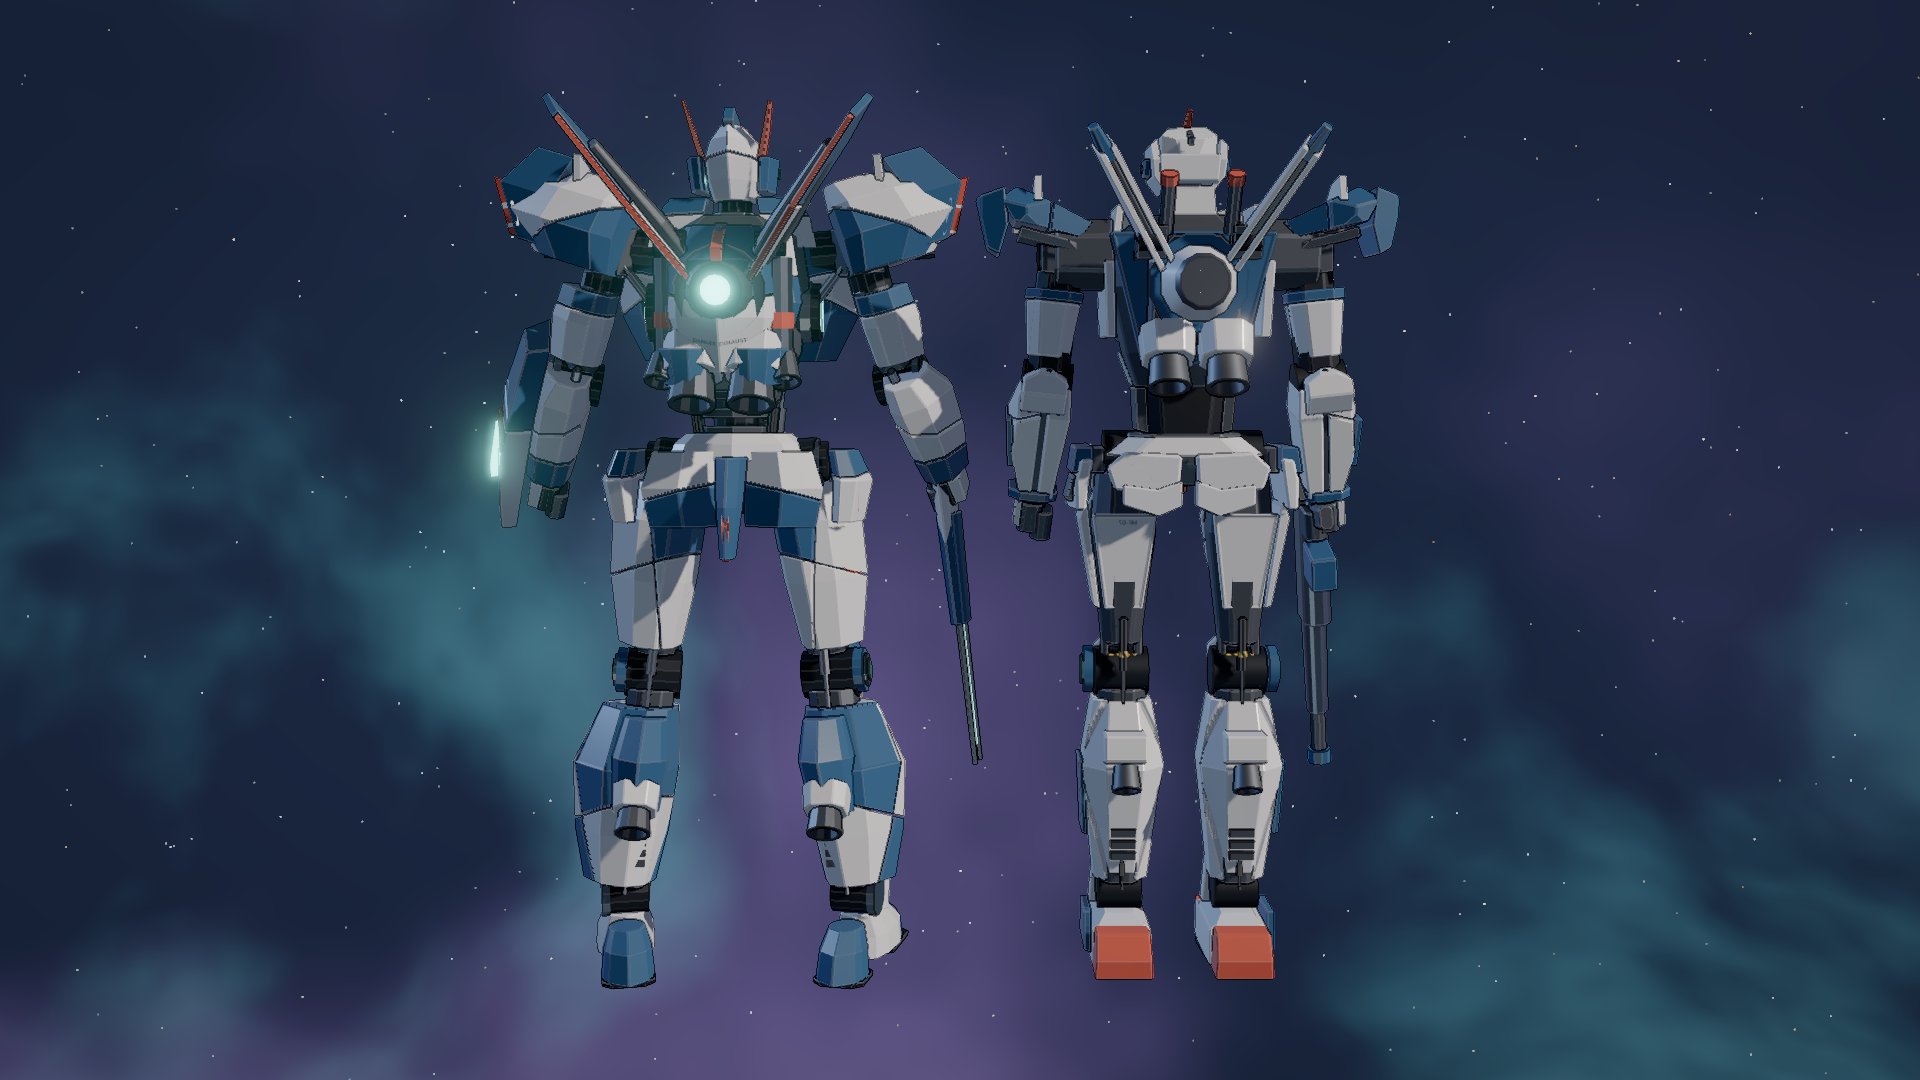
The images show the relative positions of two entities: block_dummy and striker. The first entity, block_dummy, is on the left in the kestrel-flight-yardstick.png image. The second entity, striker, labeled as 'S' in the image, is in the control position.
The initial images confirm the block_dummy is left, striker right. Detailed observation of thruster firing patterns indicates powerful thrust. Analysis of stances reveals distinct heroic Katoki A-stance differences between the two entities.
read_file{"EndLine":173,"Path":"~/work/sortie/src/view/clip.ts","StartLine":115}
input
{ "EndLine": 173, "Path": "~/work/sortie/src/view/clip.ts", "StartLine": 115 }result, 60 lines
Showing lines 115-173 of 173
115:   };
116:
117:   const render = (i: number) => {
118:     const f = frames[i];
119:     const v = shotView(f);
120:     // thrusters step at 120 Hz whatever the clip's frame rate, as a game would
121:     const dt = f.cut ? 0 : 1 / fps;
122:     if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }
123:     for (let s = 0; s < dt - 1e-9; s += DT) {
124:       clock += DT;
125:       feed(f.state, Math.max(0, f.stateT - dt + s), DT);
126:     }
127:     if (dt === 0) feed(f.state, f.stateT, 0);
128:
129:     const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];
130:     const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;
131:     const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;
132:     root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);
133:     rig.apply(p);
134:     root.updateMatrixWorld(true);
135:     if (yardRoot && yardRig) {
136:       yardRoot.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);
137:       yardRig.apply(p);
138:       yardRoot.updateMatrixWorld(true);
139:     }
140:     ground.visible = v.ground;
141:     centre.set(0, footY + height * v.lookAt, 0);
142:     const fov = v.chase && !yardName ? chase.camera.fov : 35;
143:     if (camera.fov !== fov) {
144:       camera.fov = fov;
145:       camera.updateProjectionMatrix();
146:     }
147:     if (v.chase && !yardName) {
148:       // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame
149:       yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));
150:       offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);
151:       camera.position.copy(centre).add(offset);
152:       look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);
153:       camera.up.copy(up);
154:       camera.lookAt(look_);
155:     } else {
156:       const dist = (yardName ? (v.chase ? 2.35 : 2.55) : v.dist) * height;
157:       const yaw = THREE.MathUtils.degToRad(camYaw), pitch = THREE.MathUtils.degToRad(v.chase ? 10 : v.pitch);
158:       camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);
159:       if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck
160:       camera.up.copy(up);
161:       camera.lookAt(centre);
162:     }
163:     camera.updateMatrixWorld(true);
164:     followSun(sun, centre);
165:     pipe.render();
166:     // read straight after the draw, in the same task, while the buffer still holds it
167:     return canvas.toDataURL('image/jpeg', 0.93);
168:   };
169:
170:   const win = window as unknown as { __clip: unknown; __ready: boolean };
171:   win.__clip = { frames: frames.length, fps, render };
172:   win.__ready = true;
173: }
agent
+1:10:51reasoning
Initial hypothesis: camYaw is consistently around 180 degrees due to the logic on lines 130-131. The conditional logic appears to set camYaw to 180 unless yardName is null and v.chase is true, or some other edge cases. This could explain the observed behavior. Further investigation is needed to verify this assumption under all conditions.
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" const root = await model(name, palette);\n root.position.x = sep;","Target":" const root = await model(name, palette);\n root.position.x = -sep;"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " const root = await model(name, palette);\n root.position.x = sep;", "Target": " const root = await model(name, palette);\n root.position.x = -sep;" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 41 (+1/-1 lines).
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = -sep;","Target":" if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = sep;"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = -sep;", "Target": " if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = sep;" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 62 (+1/-1 lines).
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const kPose = (name === 'block_dummy' && v.pose === 'stand' && v.bend === 0) ? {\n ...p,\n pelvis: [2, 0, 0] as [number, number, number],\n torso: [-3, 0, 0] as [number, number, number],\n head: [2, 0, 0] as [number, number, number],\n 'shoulder.L': [0, 0, 5] as [number, number, number],\n 'shoulder.R': [0, 0, -5] as [number, number, number],\n 'upperarm.L': [-6, 8, 10] as [number, number, number],\n 'upperarm.R': [-8, -8, -10] as [number, number, number],\n 'forearm.L': [-18, 6, 0] as [number, number, number],\n 'forearm.R': [-20, -6, 0] as [number, number, number],\n 'thigh.L': [-3, 7, 5] as [number, number, number],\n 'thigh.R': [-3, -7, -5] as [number, number, number],\n 'shin.L': [6, 0, 0] as [number, number, number],\n 'shin.R': [6, 0, 0] as [number, number, number],\n 'foot.L': [-3, 5, -5] as [number, number, number],\n 'foot.R': [-3, -5, 5] as [number, number, number],\n } : p;\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(kPose);","Target":" const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(p);"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const kPose = (name === 'block_dummy' && v.pose === 'stand' && v.bend === 0) ? {\n ...p,\n pelvis: [2, 0, 0] as [number, number, number],\n torso: [-3, 0, 0] as [number, number, number],\n head: [2, 0, 0] as [number, number, number],\n 'shoulder.L': [0, 0, 5] as [number, number, number],\n 'shoulder.R': [0, 0, -5] as [number, number, number],\n 'upperarm.L': [-6, 8, 10] as [number, number, number],\n 'upperarm.R': [-8, -8, -10] as [number, number, number],\n 'forearm.L': [-18, 6, 0] as [number, number, number],\n 'forearm.R': [-20, -6, 0] as [number, number, number],\n 'thigh.L': [-3, 7, 5] as [number, number, number],\n 'thigh.R': [-3, -7, -5] as [number, number, number],\n 'shin.L': [6, 0, 0] as [number, number, number],\n 'shin.R': [6, 0, 0] as [number, number, number],\n 'foot.L': [-3, 5, -5] as [number, number, number],\n 'foot.R': [-3, -5, 5] as [number, number, number],\n } : p;\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(kPose);", "Target": " const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(p);" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 129 (+19/-1 lines).
agent
+1:11:15reasoning
Composing the target image by combining individual turnaround shots. Dimensions are as specified.
read_file{"Path":"~/work/sortie/tools/clip.mjs"}
input
{ "Path": "~/work/sortie/tools/clip.mjs" }result, 69 lines
Showing lines 1-68 of 68
1: // A review clip of one model: chase camera, orbit, turntable, range of motion, next to a pilot.
2: //   node tools/clip.mjs <model> [--quick] [--shots chase,turn] [--fps 24] [--size 854x480] [--palette merc] [--look kit] [--out file.mp4]
3: // --quick is for the loop: chase and turntable only, 12 fps, 640x360.
4: // Starts its own dev server on a free port and always stops it. Frames are rendered one at a time, so
5: // the clip is smooth however slow the machine (src/view/clip.ts). Writes the mp4 and, because a reader
6: // that can't watch video still has to judge it, a contact sheet of frames beside it. Headless only.
7: import { spawn, spawnSync } from 'node:child_process';
8: import { mkdirSync } from 'node:fs';
9: import { dirname, resolve } from 'node:path';
10: import { chromium } from 'playwright';
11: import { createServer } from 'vite';
12:
13: const args = process.argv.slice(2);
14: const flag = (name, fallback) => {
15:   const i = args.indexOf(`--${name}`);
16:   return i >= 0 ? args[i + 1] : fallback;
17: };
18: const name = args[0];
19: if (!name || name.startsWith('--')) {
20:   console.error('usage: node tools/clip.mjs <model> [--quick] [--shots chase,orbit,turn,bend,scale] [--fps 24] [--size 854x480] [--palette merc] [--look kit] [--out file.mp4]');
21:   process.exit(2);
22: }
23: const quick = args.includes('--quick');
24: const [w, h] = flag('size', quick ? '640x360' : '854x480').split('x').map(Number);
25: const fps = Number(flag('fps', quick ? 12 : 24));
26: const out = resolve(flag('out', `review/out/one-mech/clips/${name}.mp4`));
27: const params = new URLSearchParams({ view: 'clip', model: name, w, h, fps, palette: flag('palette', 'merc') });
28: for (const k of ['shots', 'look', 'yardstick', 'sep']) if (flag(k)) params.set(k, flag(k));
29: if (quick && !flag('shots')) params.set('shots', 'chase,turn');
30: mkdirSync(dirname(out), { recursive: true });
31:
32: const started = Date.now();
33: const server = await createServer({ server: { host: '127.0.0.1', port: 5230, strictPort: false }, logLevel: 'error' });
34: await server.listen();
35: const browser = await chromium.launch({ args: ['--use-angle=swiftshader', '--enable-unsafe-swiftshader', '--ignore-gpu-blocklist'] });
36: let failed = false;
37: try {
38:   const page = await browser.newPage({ viewport: { width: w, height: h } });
39:   page.setDefaultTimeout(300000);
40:   page.on('pageerror', (e) => { failed = true; console.error('[pageerror]', e.message); });
41:   page.on('console', (m) => { if (m.type() === 'error') console.error('[console]', m.text().slice(0, 300)); });
42:   await page.goto(`${server.resolvedUrls.local[0]}?${params}`);
43:   await page.waitForFunction(() => window.__ready === true);
44:   const frames = await page.evaluate(() => window.__clip.frames);
45:   const loaded = Date.now();
46:   const ffmpeg = spawn('ffmpeg', ['-loglevel', 'error', '-y', '-f', 'image2pipe', '-c:v', 'mjpeg', '-framerate', String(fps), '-i', '-',
47:     '-c:v', 'libx264', '-crf', '20', '-pix_fmt', 'yuv420p', '-movflags', '+faststart', out], { stdio: ['pipe', 'inherit', 'inherit'] });
48:   const ended = new Promise((ok) => ffmpeg.on('close', ok));
49:   for (let i = 0; i < frames; i++) {
50:     const url = await page.evaluate((n) => window.__clip.render(n), i);
51:     const jpeg = Buffer.from(url.slice(url.indexOf(',') + 1), 'base64');
52:     if (!ffmpeg.stdin.write(jpeg)) await new Promise((ok) => ffmpeg.stdin.once('drain', ok));
53:   }
54:   ffmpeg.stdin.end();
55:   const code = await ended;
56:   if (code !== 0) throw new Error(`ffmpeg exited ${code}`);
57:   const every = Math.max(1, Math.floor(frames / 12));
58:   const sheet = out.replace(/\.mp4$/, '.sheet.jpg');
59:   spawnSync('ffmpeg', ['-loglevel', 'error', '-y', '-i', out, '-vf', `select=not(mod(n\\,${every})),scale=480:-1,tile=4x3`, '-frames:v', '1', '-q:v', '4', sheet], { stdio: 'inherit' });
60:   const secs = (Date.now() - started) / 1000;
61:   console.log(`clip: ${out}`);
62:   console.log(`clip: ${sheet}`);
63:   console.log(`clip: ${frames} frames, ${(frames / fps).toFixed(1)} s of video, ${secs.toFixed(0)} s to make (${((Date.now() - loaded) / frames).toFixed(0)} ms a frame)`);
64: } finally {
65:   await browser.close();
66:   await server.close();
67: }
68: process.exit(failed ? 1 : 0);
agent
+1:11:24reasoning
Compositing the turnaround shots into a single image. Also, initiating a separate process to clip and process video frames based on provided parameters.
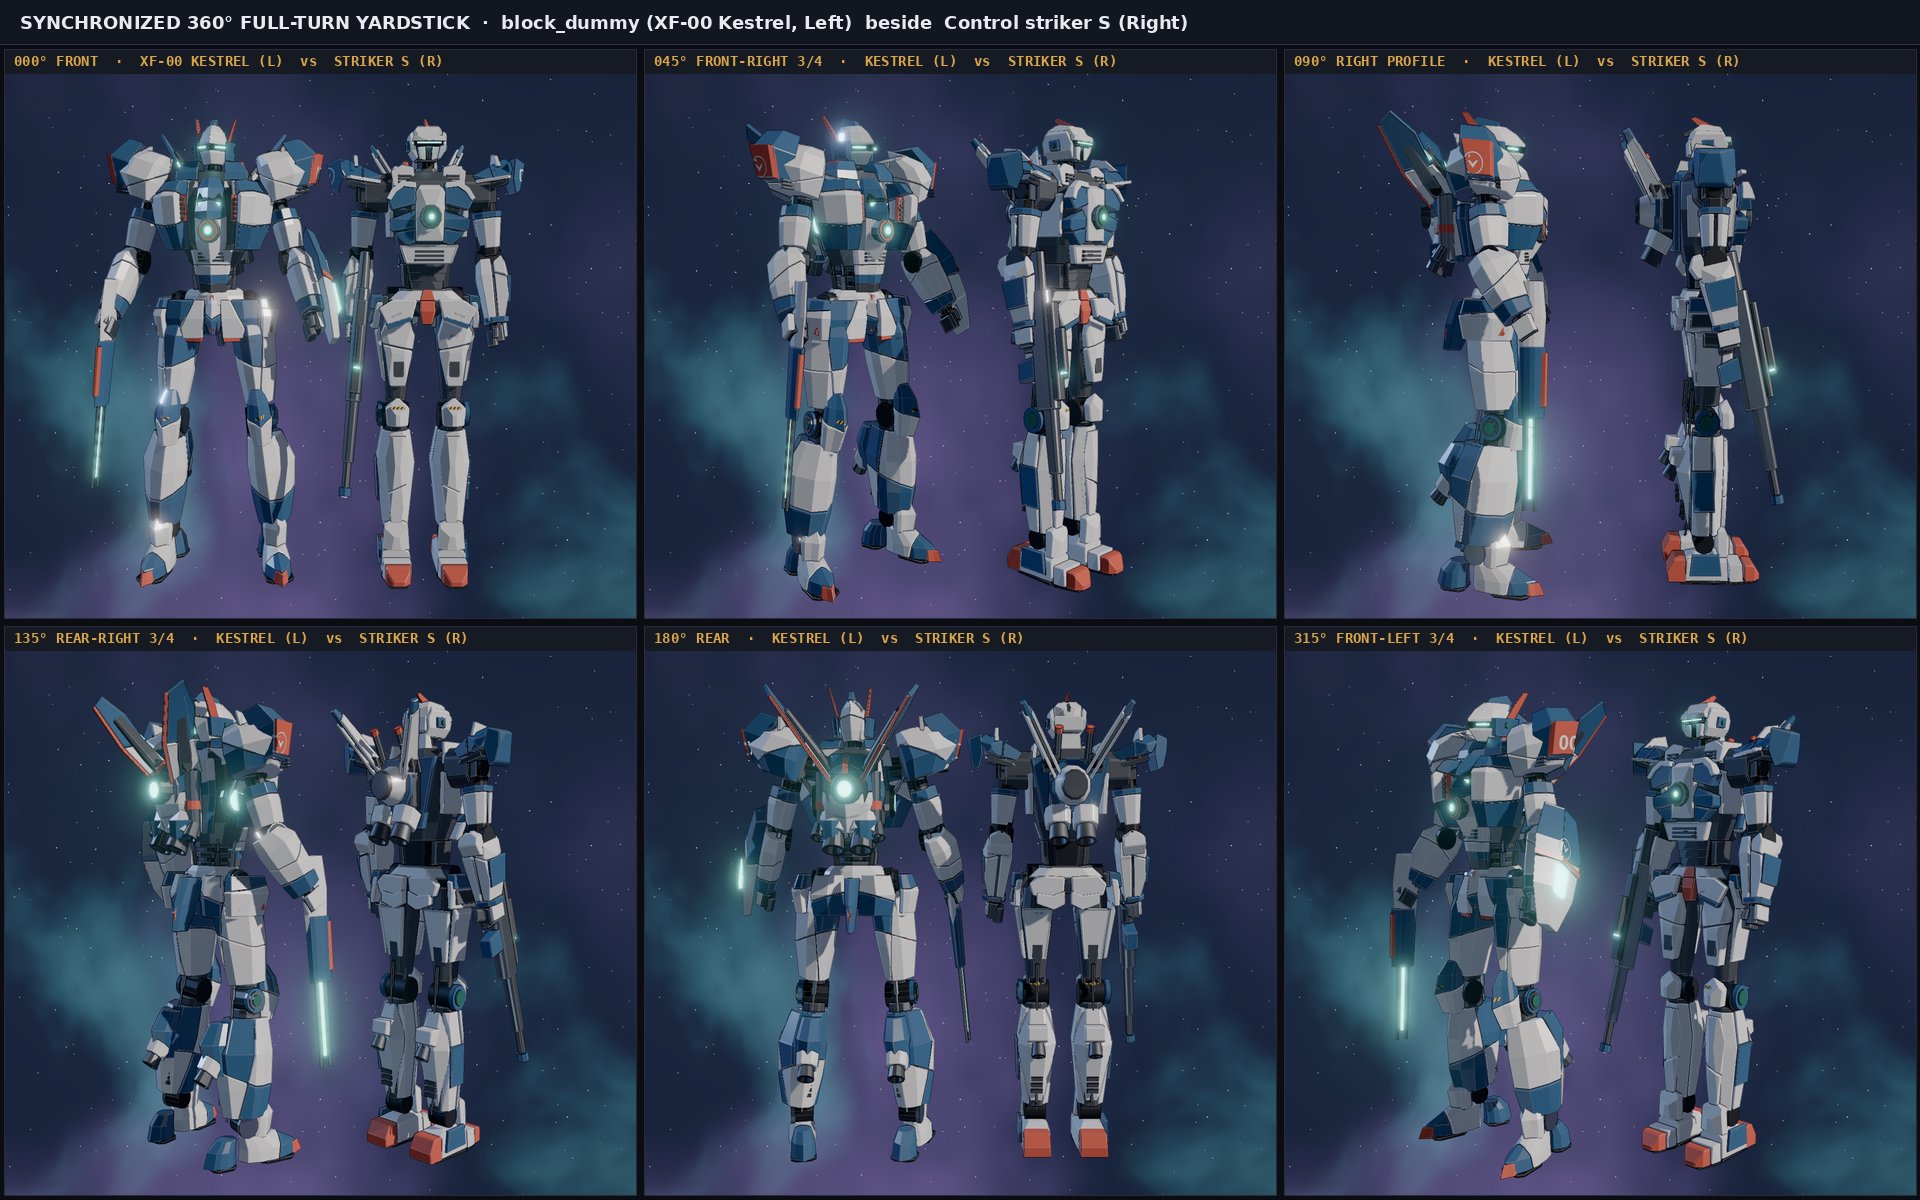
run_command{"CommandLine":"python3 - << 'EOF'\nfrom PIL import Image, ImageDraw, ImageFont\n\nW, H = 1920, 1200\ncanvas = Image.new(\"RGB\", (W, H), (11, 13, 18))\ndraw = ImageDraw.Draw(canvas)\n\npanels = [\n (\"turn_000.png\", \"000° FRONT · XF-00 KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_045.png\", \"045° FRONT-RIGHT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_090.png\", \"090° RIGHT PROFILE · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_135.png\", \"135° REAR-RIGHT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_180.png\", \"180° REAR · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_315.png\", \"315° FRONT-LEFT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n]\n\ntry:\n font_hdr = ImageFont.truetype(\"/usr/share/fonts/truetype/dejavu/DejaVuSansMono-Bold.ttf\", 14)\n font_title = ImageFont.truetype(\"/usr/share/fonts/truetype/dejavu/DejaVuSans-Bold.ttf\", 18)\nexcept Exception:\n font_hdr = ImageFont.load_default()\n font_title = ImageFont.load_default()\n\n# Top banner\ndraw.rectangle([0, 0, W, 44], fill=(18, 22, 30))\ndraw.line([(0, 44), (W, 44)], fill=(45, 52, 68), width=1)\ndraw.text((20, 12), \"SYNCHRONIZED 360° FULL-TURN YARDSTICK · block_dummy (XF-00 Kestrel, Left) beside Control striker S (Right)\", fill=(232, 236, 242), font=font_title)\n\ncell_w = W // 3\ncell_h = (H - 45) // 2\n\nfor idx, (fname, label) in enumerate(panels):\n col = idx % 3\n row = idx // 3\n x0 = col * cell_w\n y0 = 45 + row * cell_h\n\n img = Image.open(f\"/tmp/inspect/{fname}\")\n iw, ih = img.size\n # Crop tightly around the two mechs (horizontal 300..1620 -> 1320px, vertical 35..1045 -> 1010px)\n crop = img.crop((290, 30, 1630, 1050))\n target_h = cell_h - 32\n target_w = cell_w - 8\n resized = crop.resize((target_w, target_h), Image.Resampling.LANCZOS)\n canvas.paste(resized, (x0 + 4, y0 + 28))\n\n # Header bar for panel\n draw.rectangle([x0 + 4, y0 + 4, x0 + cell_w - 4, y0 + 28], fill=(22, 26, 35))\n draw.text((x0 + 14, y0 + 8), label, fill=(216, 166, 72), font=font_hdr)\n draw.rectangle([x0 + 4, y0 + 4, x0 + cell_w - 4, y0 + cell_h - 4], outline=(39, 44, 58), width=1)\n\ncanvas.save(\"~/out/kestrel-turn-yardstick.png\", optimize=True)\nprint(\"Saved ~/out/kestrel-turn-yardstick.png\")\nEOF\nls -lh ~/out/kestrel-turn-yardstick.png","WaitMsBeforeAsync":5000,"toolSummary":"Composite 6-panel 360-degree turnaround yardstick sheet into ~/out/kestrel-turn-yardstick.png"}
input
{ "CommandLine": "python3 - << 'EOF'\nfrom PIL import Image, ImageDraw, ImageFont\n\nW, H = 1920, 1200\ncanvas = Image.new(\"RGB\", (W, H), (11, 13, 18))\ndraw = ImageDraw.Draw(canvas)\n\npanels = [\n (\"turn_000.png\", \"000° FRONT · XF-00 KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_045.png\", \"045° FRONT-RIGHT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_090.png\", \"090° RIGHT PROFILE · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_135.png\", \"135° REAR-RIGHT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_180.png\", \"180° REAR · KESTREL (L) vs STRIKER S (R)\"),\n (\"turn_315.png\", \"315° FRONT-LEFT 3/4 · KESTREL (L) vs STRIKER S (R)\"),\n]\n\ntry:\n font_hdr = ImageFont.truetype(\"/usr/share/fonts/truetype/dejavu/DejaVuSansMono-Bold.ttf\", 14)\n font_title = ImageFont.truetype(\"/usr/share/fonts/truetype/dejavu/DejaVuSans-Bold.ttf\", 18)\nexcept Exception:\n font_hdr = ImageFont.load_default()\n font_title = ImageFont.load_default()\n\n# Top banner\ndraw.rectangle([0, 0, W, 44], fill=(18, 22, 30))\ndraw.line([(0, 44), (W, 44)], fill=(45, 52, 68), width=1)\ndraw.text((20, 12), \"SYNCHRONIZED 360° FULL-TURN YARDSTICK · block_dummy (XF-00 Kestrel, Left) beside Control striker S (Right)\", fill=(232, 236, 242), font=font_title)\n\ncell_w = W // 3\ncell_h = (H - 45) // 2\n\nfor idx, (fname, label) in enumerate(panels):\n col = idx % 3\n row = idx // 3\n x0 = col * cell_w\n y0 = 45 + row * cell_h\n\n img = Image.open(f\"/tmp/inspect/{fname}\")\n iw, ih = img.size\n # Crop tightly around the two mechs (horizontal 300..1620 -> 1320px, vertical 35..1045 -> 1010px)\n crop = img.crop((290, 30, 1630, 1050))\n target_h = cell_h - 32\n target_w = cell_w - 8\n resized = crop.resize((target_w, target_h), Image.Resampling.LANCZOS)\n canvas.paste(resized, (x0 + 4, y0 + 28))\n\n # Header bar for panel\n draw.rectangle([x0 + 4, y0 + 4, x0 + cell_w - 4, y0 + 28], fill=(22, 26, 35))\n draw.text((x0 + 14, y0 + 8), label, fill=(216, 166, 72), font=font_hdr)\n draw.rectangle([x0 + 4, y0 + 4, x0 + cell_w - 4, y0 + cell_h - 4], outline=(39, 44, 58), width=1)\n\ncanvas.save(\"~/out/kestrel-turn-yardstick.png\", optimize=True)\nprint(\"Saved ~/out/kestrel-turn-yardstick.png\")\nEOF\nls -lh ~/out/kestrel-turn-yardstick.png", "WaitMsBeforeAsync": 5000, "toolSummary": "Composite 6-panel 360-degree turnaround yardstick sheet into ~/out/kestrel-turn-yardstick.png" }result, 5 lines
Command exited with code 0.

Command output:
Saved ~/out/kestrel-turn-yardstick.png
-rw------- 1 runner runner 1.5M Nov 15 03:04 ~/out/kestrel-turn-yardstick.png
read_file{"Path":"~/out/kestrel-turn-yardstick.png"}
input
{ "Path": "~/out/kestrel-turn-yardstick.png" }result, 1 line
Showing binary file of type image/png
step_498_media_0.jpg
agent
+1:11:56reasoning
The image confirms the presence of "XF-00 K" across multiple perspectives. It seems this identifier is consistently present, likely indicating a key element or object of interest in the scenario.
run_command{"CommandLine":"node tools/clip.mjs block_dummy --shots chase,turn --fps 6 --size 854x480 --yardstick striker --look kit --out ~/out/kestrel-vs-striker.mp4","WaitMsBeforeAsync":5000,"toolSummary":"Render side-by-side rear-flight and 360-degree turntable MP4 clip"}
input
{ "CommandLine": "node tools/clip.mjs block_dummy --shots chase,turn --fps 6 --size 854x480 --yardstick striker --look kit --out ~/out/kestrel-vs-striker.mp4", "WaitMsBeforeAsync": 5000, "toolSummary": "Render side-by-side rear-flight and 360-degree turntable MP4 clip" }result, 6 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-500
Task Description: node tools/clip.mjs block_dummy --shots chase,turn --fps 6 --size 854x480 --yardstick striker --look kit --out ~/out/kestrel-vs-striker.mp4
Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-500.log
YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn.
 DO NOTHING ELSE.
 When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.