A mech game prototype, pushed by Gemini 4 Argon
agent
+4:15reasoning
The script clip.mjs successfully generated the video and sheet images, completing the rendering process. The execution time and frame rate were calculated based on the output. The presence of the --quick flag suggests it overrides the --seconds parameter, which explains the frame count.
read_file{"Path":"/tmp/test.sheet.jpg"}
input
{ "Path": "/tmp/test.sheet.jpg" }result, 1 line
Showing binary file of type image/jpeg
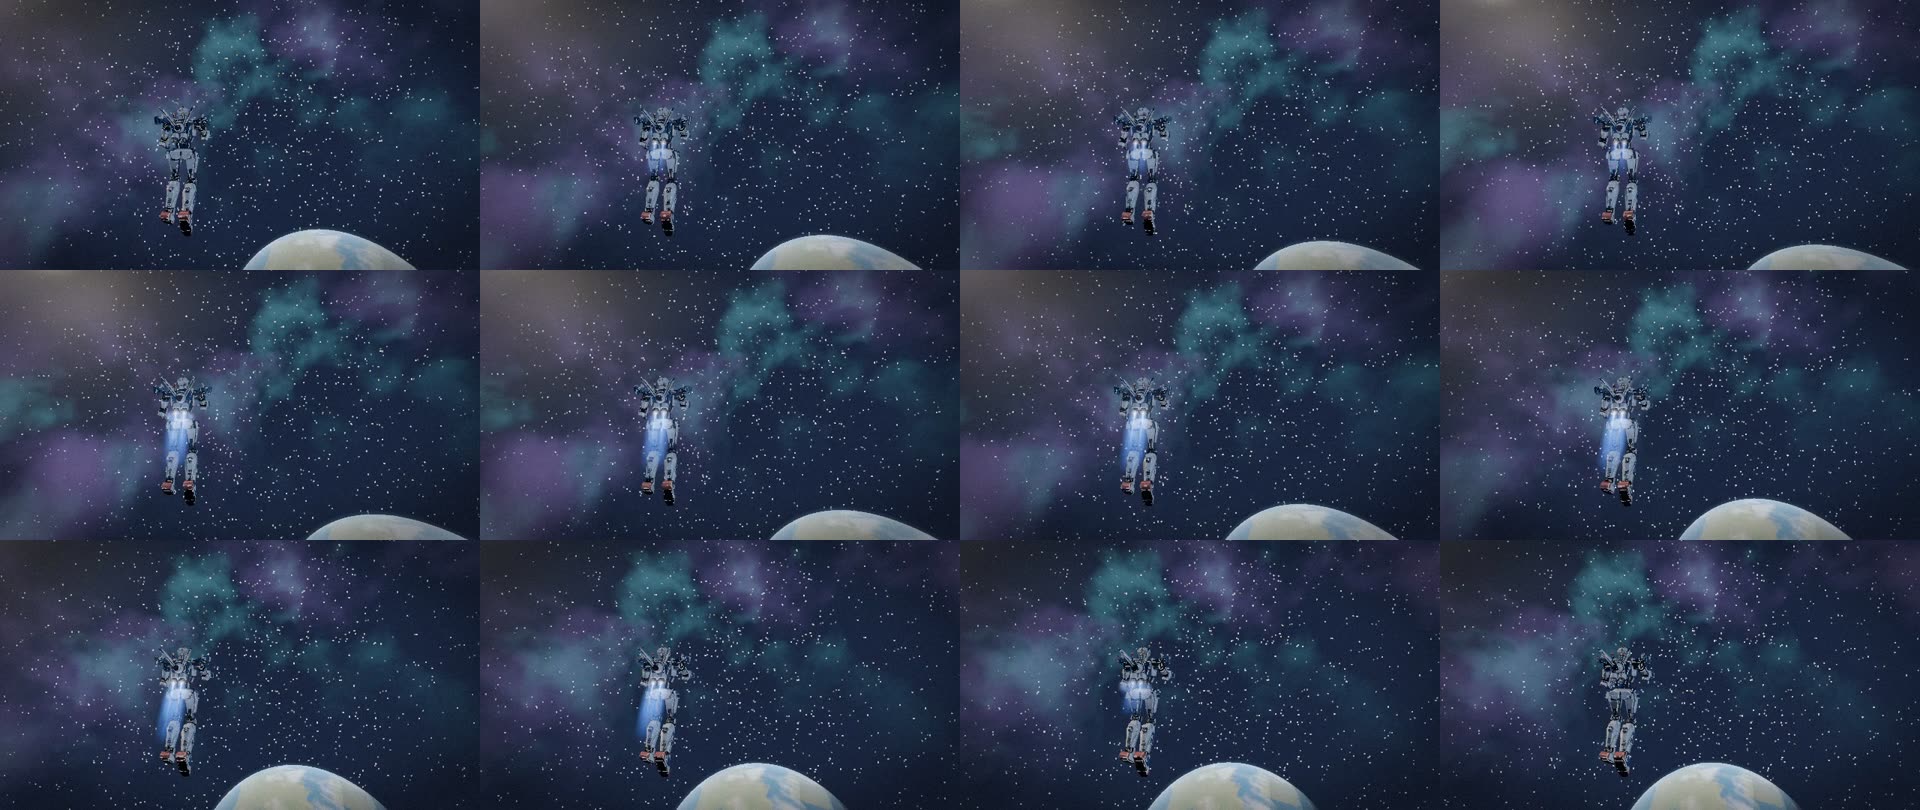
step_93_media_0.jpg
agent
+4:20reasoning
The image /tmp/test.sheet.jpg provides critical insight. Observing the chase shot reveals a key detail about the workflow's issues and the purpose of the 'quick' flag. The image now unlocks the reasoning.
run_command{"CommandLine":"rm -f /tmp/test.mp4 /tmp/test.sheet.jpg && node -e '\nimport { createServer } from \"vite\";\nimport { spawnSync } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: \"error\" });\nawait srv.listen();\nconst port = srv.config.server.port;\nconst env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: \"1280\", H: \"720\" };\nspawnSync(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=30&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=30&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait srv.close();\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render test views of existing models into /tmp/inspect"}
input
{ "CommandLine": "rm -f /tmp/test.mp4 /tmp/test.sheet.jpg && node -e '\nimport { createServer } from \"vite\";\nimport { spawnSync } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: \"error\" });\nawait srv.listen();\nconst port = srv.config.server.port;\nconst env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: \"1280\", H: \"720\" };\nspawnSync(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=30&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=30&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait srv.close();\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render test views of existing models into /tmp/inspect" }result, 23 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-95 Task Description: rm -f /tmp/test.mp4 /tmp/test.sheet.jpg && node -e ' import { createServer } from "vite"; import { spawnSync } from "node:child_process"; const srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: "error" }); await srv.listen(); const port = srv.config.server.port; const env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: "1280", H: "720" }; spawnSync("node", [ "tools/shoot.mjs", "/tmp/inspect", "atelier_b=/?view=lab_atelier_b&yaw=30&pitch=10", "atelier_a=/?view=lab_atelier_a&yaw=30&pitch=10", "pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard", "striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field", "striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit", "lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit" ], { stdio: "inherit", env }); await srv.close(); ' --input-type=module Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-95.log YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn. DO NOTHING ELSE. When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.read_file{"EndLine":100,"Path":"~/work/sortie/kit/lab/board_tourney.py","StartLine":1}
input
{ "EndLine": 100, "Path": "~/work/sortie/kit/lab/board_tourney.py", "StartLine": 1 }result, 101 lines
Showing lines 1-100 of 356 1: """Tilt (line D), tourney harness: the jousting armour of the references (docs/study-atelier.md), built 2: lopsided on purpose. 3: 4: The left side, the side that meets the lance, carries the weight: a grandguard over the left breast 5: and pauldron, an upstanding volant guard beside the helm, a broad pasguard over the left elbow. The 6: right side is the sword arm: a small pauldron with a round besagew at the armpit, a lance rest 7: hooked on the right breast. A frog mouth helm, its crown jutting over the sight. Smooth plates, roped 8: gold on the big pieces only. Asymmetry gives the strongest silhouette of the four and the clearest 9: sense of a job, at the cost of the mirror rule every other maker keeps. 10: 11: Grades by plate count (plates(J, P, g)): the light a grandguard over the breast alone, both pauldrons 12: without lames, no volant or pasguard, a plain helm, the core block. The medium the board's line knight. 13: The heavy three lames under the great pauldron and two under the small one, a taller volant, a manifer 14: over the left forearm, tassets of three, add-ons over the cuisses and greaves, wings on both knees. 15: The lance on every grade. 16: """ 17: import math 18: 19: import frame_std 20: from knightkit import Sheet, addon, band, bead, by, cap, curve, horn, joint_covers, lames, lin, put, put2, rim, rivets, smooth, spline, tent 21: from lib import clip, copy, mirror_x 22: from makers import atelier 23: from makers.atelier import bearing_at, lr 24: from makers.shell import subtract 25: 26: breast_r = curve([.98, 1.3, 1.5, 1.52, 1.45, 1.3, 1.12]) 27: 28: 29: def cuirass(u, z, grow=0.0, z0=12.15, z1=15.05): 30: r = breast_r(min(max((z - z0) / (z1 - z0), 0), 1)) + grow 31: a = math.radians(u) 32: return (r * 1.08 * math.cos(a), -.15 + r * math.sin(a), z) 33: 34: 35: def right(P, name, bm, role, joint, bevel=.012): 36: """A right side only part, authored on the left and mirrored.""" 37: P.solid(name, mirror_x(bm), role, joint, bevel=bevel) 38: bm.free() 39: 40: 41: def chest(P, J, g): 42: T, C = J["torso"], J["cockpit"] 43: if g == "light": 44: C = T # the light's cockpit is the core block: its breast does not open 45: z0 = 12.15 46: top = lambda u: 15.05 - .32 * tent(u, -90, 48) - .5 * smooth(abs(u + 90), 58, 80) 47: s = Sheet(lambda u, v: cuirass(u, z0 + (top(u) - z0) * v), lin(-172, -8, 30), lin(0, 1, 14), .14, 48: disp=lambda u, v: .06 * tent(u, -90, 10), inside=(0, 0, 13.6)) 49: bm = s.bm() 50: # the hatch: the breast's middle between two seams, clear of the grandguard 51: hatch = clip(copy(bm), x=(-.72, .64), y=(-60, -.9), z=(12.86, 16)) 52: bm = subtract(bm, frame_std.box(-.75, .67, -3, -.9, 12.82, 16)) 53: P.solid("breast", bm, "main", T, bevel=.012) 54: P.solid("hatch", hatch, "main", C, bevel=.01) 55: neck = s.edge("v1", out=.02) 56: rim(P, "breast_rim", [p for p in neck if p.x < -.78], .06, T) 57: rim(P, "hatch_rim", [p for p in neck if -.7 < p.x < .62], .06, C) 58: # the grandguard: bolted over the left breast and up over the left shoulder, ivory, roped gold 59: big = g == "heavy" # the castellan's grandguard is the one hero piece: bigger, standing further off, bolted 60: gtop = lambda u: 15.1 + (.85 if big else .55) * smooth(u, -70, -10) 61: gbot = lambda u: (12.7 if big else 13.15) - .5 * smooth(u, -60, -10) 62: gg = Sheet(lambda u, v: cuirass(u, gbot(u) + (gtop(u) - gbot(u)) * v, .42 if big else .3), lin(-70 if big else -66, 14 if big else 8, 18), 63: lin(0, 1, 10), .16 if big else .14, disp=lambda u, v: .07 * tent(u, -40, 9), inside=(0, 0, 13.8)) 64: P.solid("grandguard", gg.bm(), "accent", T, bevel=.012) 65: edge = gg.edge("u0", out=.02)[::-1] + gg.edge("v0", out=.02) + gg.edge("u1", out=.02) 66: rim(P, "grandguard_rim", edge, .08, T, rope=1.0) 67: bolts = ((-55, 14.6), (-20, 14.0), (-50, 13.4)) + (((-62, 13.0), (-10, 15.2), (-30, 13.2)) if big else ()) 68: P.solid("grandguard_bolts", _bolts([cuirass(u, z, .58 if big else .46) for u, z in bolts]), "metal", T, bevel=0) 69: # the volant: a guard standing up beside the helm on the left, taller on the castellan 70: if g != "light": 71: vh = by(g, 0, 16.35, 16.85) 72: v = band((0, .1), 14.9, lambda u: vh - .55 * smooth(abs(u + 10), 12, 46), [1.18, 1.2, 1.3], lin(-56, 40, 16), nv=8, kx=1.0, t=.14) 73: put(P, "volant", v, "accent", T) 74: rim(P, "volant_rim", v.edge("v1", out=.02), .07, T, rope=1.0) 75: # the lance rest on the right breast: a bracket and a hook 76: lr_ = merge_parts(frame_std.box(.82, 1.18, -1.86, -1.56, 13.1, 13.4), 77: horn([(1.0, -1.82, 13.25), (1.0, -2.25, 13.32), (1.0, -2.5, 13.6), (1.0, -2.46, 13.9)], .14, n=8, power=.6)) 78: right(P, "lance_rest", lr_, "metal", T) 79: bearing_at("chest", (-.9, -1.6, 14.3), (0, -1, 0), T, .7) 80: back = band((0, .15), 12.2, lambda u: 15.0 - .35 * smooth(u, 55, 80), [1.0, 1.4, 1.55, 1.5, 1.3], lin(14, 82, 10), nv=10, kx=1.04, ky=.92, t=.14) 81: put(P, "backplate", back, "main", T, T) 82: for i in range(by(g, 1, 1, 2)): 83: gor = band((0, .05), 14.82 + .3 * i, 15.3 + .3 * i, [1.12 - .1 * i, 1.04 - .1 * i, .94 - .1 * i], lin(-170, -10, 24), nv=4, kx=1.05, t=.1) 84: put(P, f"gorget{i}", gor, "main", T) 85: 86: 87: def merge_parts(*bms): 88: from lib import merge 89: return merge(*bms) 90: 91: 92: def _bolts(pts): 93: from knightkit import rivets 94: return rivets([(p, (p[0], p[1] + .15, 0)) for p in pts], r=.1) 95: 96: 97: def waist(P, J, g): 98: W = J["waist"] 99: if g == "light": 100: returnread_file{"EndLine":100,"Path":"~/work/sortie/kit/lab/board_heraldic.py","StartLine":1}
input
{ "EndLine": 100, "Path": "~/work/sortie/kit/lab/board_heraldic.py", "StartLine": 1 }result, 101 lines
Showing lines 1-100 of 375 1: """Direction C, bold heraldic: big simple shapes, painted like a shield (docs/study-atelier.md). 2: 3: The hero is the top: round pauldrons as big as the chest, a high collar standing round the helm and a 4: tall fan crest. Below them few, large plates: a heater shield breastplate with a raised gold chevron, a 5: heater tasset over each thigh, round knee cops, plain bell greaves. Painted per pale: the body's left 6: half ivory and its right half wine, the pauldrons and the legs counterchanged, so the machine reads 7: as two colours at any range. Broad gold rims, no small detail. 8: 9: Grades by role and by plate count (plates(J, P, g), docs/study-atelier.md, Grades by plate count), the 10: heater and the crest family on all three: 11: light the duellist: about a plate per segment, the frame bare between. Small shoulder caps over a bare 12: upper arm, a narrow ivory heater breast, no collar, the tallest raked crest, short split tassets, 13: slim greaves with the thigh showing, the core block cockpit 14: medium the line knight: a lame or a wing on every main plate (`layers`) 15: heavy the castellan: stacked lames where the medium has one, heater add-ons bolted over the cuisse, 16: greave, breast and vambrace with rivets, rondels, gold on every hem. Bastion pauldrons under 17: standing ailettes that rise past the helm, a full collar, flank plates, tassets to the knee, a 18: heater shield on the left arm 19: """ 20: import math 21: 22: from mathutils import Vector 23: 24: from knightkit import Sheet, addon as escutcheon, band, bead, cap, joint_covers, lames, lin, put, rim, rivets, smooth, strip, tent 25: from lib import rot, transform 26: from lib import clip, copy, mirror_x 27: from makers import atelier 28: from makers.atelier import bearing_at, by, lr 29: 30: IVORY, WINE = "accent", "main" 31: 32: 33: def pale(P, name, bm, joint, left=IVORY, right=WINE, bevel=.012): 34: """A plate across the centre line, split there: its left half (+X) in one role, its right in the other.""" 35: lo = clip(copy(bm), x=(0.0, 60)) 36: hi = clip(bm, x=(-60, 0.0)) 37: P.solid(f"{name}_l", lo, left, joint, bevel=bevel) 38: P.solid(f"{name}_r", hi, right, joint, bevel=bevel) 39: 40: 41: def sides(P, name, bm, jl, jr, left, right, bevel=.012): 42: """A left plate and its mirror on the right, each side its own role.""" 43: P.solid(f"{name}.L", copy(bm), left, jl, bevel=bevel) 44: P.solid(f"{name}.R", mirror_x(bm), right, jr, bevel=bevel) 45: bm.free() 46: 47: 48: def heater(u, z, grow=0.0, k=0.0): 49: """The breastplate's surface: a broad shallow dome, k wider for the grade.""" 50: a = math.radians(u) 51: h = min(max((z - 12.0) / 3.0, 0.0), 1.0) 52: r = 1.38 + k + .12 * math.sin(math.pi * h) + .22 * math.sin(math.pi * min(h / .8, 1.0)) * max(0.0, -math.sin(a)) ** 2 + grow 53: return (r * 1.12 * math.cos(a), -.2 + r * .98 * math.sin(a), z) 54: 55: 56: def chest(P, J, g): 57: T, C = J["torso"], J["cockpit"] 58: k = by(g, -.14, 0.0, .14) 59: # a heater: square shouldered, straight down the sides, curving to a point at the belly 60: bot = lambda u: 12.15 + 1.25 * (1 - tent(u, -90, 82) ** .6) 61: top = lambda u: 15.0 - .12 * tent(u, -90, 60) - .55 * smooth(abs(u + 90), 50, 84) # the corners run under the shoulder roots 62: s = Sheet(lambda u, v: heater(u, bot(u) + (top(u) - bot(u)) * v, 0, k), lin(-186, 6, 44), lin(0, 1, 14), .24, inside=(0, 0, 13.6)) 63: # the whole shield is the hatch: it leaves with the pod, its chevron and rim with it. The light's cockpit is 64: # the core block behind, so its breast stays on the torso, all ivory 65: j = T if g == "light" else C 66: if g == "light": 67: P.solid("breast", s.bm(), IVORY, T, bevel=.012) 68: else: 69: pale(P, "breast", s.bm(), C) 70: P.solid("breast_rim", bead(s.edge("v0", out=.03) + list(reversed(s.edge("v1", out=.03))), .1, closed=True), "trim", j, bevel=0) 71: # a raised gold chevron across the breast 72: for sx in (1, -1): 73: ch = strip(lambda s, sx=sx: (-90 + sx * 64 * s, 14.25 - 1.15 * s), .4, .07, lambda u, z, o: heater(u, z, .05, k)) 74: P.solid(f"chevron{'L' if sx > 0 else 'R'}", ch.bm(), "trim", j, bevel=.01) 75: bearing_at("chest", (.8, -1.75 - k, 14.4), (0, -1, 0), T, .8) 76: back = band((0, .15), 12.3, lambda u: 15.0 - .4 * smooth(u, 55, 80), [1.1 + k, 1.5 + k, 1.56 + k, 1.5 + k], lin(14, 82, 10), nv=8, kx=1.04, 77: ky=.92, t=.16) 78: sides(P, "backplate", back.bm(), T, T, IVORY, WINE) 79: if g == "light": 80: gor = band((0, .05), 14.85, 15.3, [1.1, 1.0, .92], lin(-170, -10, 24), nv=4, kx=1.05, t=.12) 81: put(P, "gorget", gor, WINE, T) 82: return 83: # the collar: a high band round the helm, low at the front, flaring as it rises. The castellan's closes higher 84: hi, dip = by(g, 0, 16.0, 16.5), by(g, 0, 1.0, .75) 85: ctop = lambda u: hi - dip * tent((u + 270) % 360 - 180, 0, 100) ** 1.2 86: for nm, us in (("collar_l", lin(-62, 92, 26)), ("collar_r", lin(88, 242, 26))): 87: cb = band((0, .2), 14.9, ctop, lambda u, v: 1.04 + k * .5 + .5 * v * v, us, nv=8, kx=1.05, t=.14) 88: P.solid(nm, cb.bm(), WINE if nm == "collar_l" else IVORY, T, bevel=.012) 89: rim(P, f"{nm}_rim", cb.edge("v1", out=.02), .08, T) 90: if g == "heavy": 91: # flank plates over the ribs, small heaters, counterchanged 92: fl = band((1.1, 0), lambda u: 12.5 + .4 * (1 - tent(u, 0, 50)), 14.5, [.88, .92, .9], lin(-58, 58, 16), nv=6, t=.16) 93: sides(P, "flank", fl.bm(), T, T, WINE, IVORY) 94: rim(P, "flank_rim", fl.edge("v0", out=.02), .07, T, T) 95: 96: 97: def waist(P, J, g): 98: W = J["waist"] 99: k = by(g, -.06, 0.0, .14) 100: s = band((0, -.1), 11.3, 12.3, [.92 + k, .84 + k, .94 + k], lin(-170, -10, 26), nv=6, kx=1.08, t=.16)read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-95.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-95.log" }result, 2 lines
Showing lines 1-1 of 1
1: atelier_b: FAILED page.goto: Timeout 30000ms exceeded.
agent
+5:30reasoning
The timeout on page.goto within task-95 stems from spawnSync blocking the Node event loop where createServer is also running. spawnSync's synchronous blocking prevents the Vite server, which is in the same process, from servicing incoming requests. Killing task-95 to allow the server to operate correctly may resolve this.
manage_task{"Action":"kill","TaskId":"abb0eba5-92ad-4ab4-8738-458f4e606a27/task-95"}
input
{ "Action": "kill", "TaskId": "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-95" }result, 1 line
Task "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-95" cancelled.
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { spawn } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: \"error\" });\nawait srv.listen();\nconst port = srv.config.server.port;\nconst env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: \"1200\", H: \"800\" };\nconst child = spawn(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait new Promise((res) => child.on(\"exit\", res));\nawait srv.close();\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render test views of existing models asynchronously"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { spawn } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: \"error\" });\nawait srv.listen();\nconst port = srv.config.server.port;\nconst env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: \"1200\", H: \"800\" };\nconst child = spawn(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait new Promise((res) => child.on(\"exit\", res));\nawait srv.close();\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render test views of existing models asynchronously" }result, 24 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-104 Task Description: node -e ' import { createServer } from "vite"; import { spawn } from "node:child_process"; const srv = await createServer({ server: { port: 5199, strictPort: false }, logLevel: "error" }); await srv.listen(); const port = srv.config.server.port; const env = { ...process.env, SORTIE_URL: `http://localhost:${port}`, W: "1200", H: "800" }; const child = spawn("node", [ "tools/shoot.mjs", "/tmp/inspect", "atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10", "atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10", "pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard", "striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field", "striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit", "lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit" ], { stdio: "inherit", env }); await new Promise((res) => child.on("exit", res)); await srv.close(); ' --input-type=module Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn. DO NOTHING ELSE. When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.resultTool execution was canceled
Tool execution was canceled
Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-95.log
read_file{"EndLine":120,"Path":"~/work/sortie/kit/heavy.py","StartLine":1}
input
{ "EndLine": 120, "Path": "~/work/sortie/kit/heavy.py", "StartLine": 1 }result, 121 lines
Showing lines 1-120 of 1054 1: """Heavy frames: 24 m, hip at half the height, shoulders about half the height wide, a small head sunk 2: between high collars, thick thighs, wide feet, layered skirts and a big reactor pack. Same joint names 3: as the striker (src/render/mech.ts JOINTS), so poses and part swapping carry over. 4: 5: Detail density follows real size, so a heavy frame carries more, smaller plates than a grown striker 6: would: limbs are layered shells over a dark frame, big forms are subdivided cages with creased edges, 7: and plates are split with real seams. Parts are authored on the left (+X) in world rest-pose 8: coordinates and mirrored. Max half width is 6 m (a 12 m bay). 9: 10: A bulwark tower shield on the left arm, layered pauldrons, drum reactor pack 11: B artillery long cannon on the right shoulder, missile box on the left, bracing outriggers on the feet 12: C assault big thruster pack with booster pods, oversized forearms, horned crown 13: """ 14: import math 15: 16: import bpy 17: from mathutils import Matrix, Vector 18: 19: from figure import pilot 20: from lib import (attach, circle, clip, copy, cylinder, empty, fold, halves, loft, merge, mirror_x, nozzle, octo, panels, piston, prism, rot, 21: slats, solid, subd, transform, two_view) 22: from mech import gltf_dir, place 23: 24: HEIGHT = 24.0 25: HALF_WIDTH = 6.0 26: 27: 28: def box(x0, x1, y0, y1, z0, z1): 29: r = [(x0, y0), (x1, y0), (x1, y1), (x0, y1)] 30: return loft([(z0, r), (z1, r)]) 31: 32: 33: def sv(front, side, top=None, lv=2, sharp=40): 34: """A sculpted two-view: the intersection smoothed by subdivision, sharp edges creased.""" 35: return subd(two_view(front, side, top), lv, sharp) 36: 37: 38: def split(bm, a, b, gap=.06, view="xz"): 39: """Two plates from one solid, cut along the line a->b of the front (xz) or side (yz) view.""" 40: if view == "xz": 41: A, B = Vector((a[0], 0, a[1])), Vector((b[0], 0, b[1])) 42: d = (B - A).normalized() 43: n = Vector((-d.z, 0, d.x)) 44: else: 45: A, B = Vector((0, a[0], a[1])), Vector((0, b[0], b[1])) 46: d = (B - A).normalized() 47: n = Vector((0, -d.z, d.y)) 48: return halves(bm, A, n, gap) 49: 50: 51: def side_slats(x, y0, y1, z0, z1, n, out=.06, sx=1): 52: """Horizontal vent bars on a surface facing +X (sx=1) or -X at x.""" 53: h = (z1 - z0) / n 54: bars = [prism([(y0, z0 + i * h), (y1, z0 + i * h), (y1, z0 + i * h + h * .5), (y0, z0 + i * h + h * .5)], 55: x - .05 * sx if sx > 0 else x - out, x + out if sx > 0 else x + .05, "yz") for i in range(n)] 56: return merge(*bars) 57: 58: 59: def rear_slats(x0, x1, z0, z1, y, n, out=.06): 60: """Horizontal vent bars standing out of a rear-facing (+Y) surface at depth y.""" 61: h = (z1 - z0) / n 62: return merge(*[prism([(x0, z0 + i * h), (x1, z0 + i * h), (x1, z0 + i * h + h * .5), (x0, z0 + i * h + h * .5)], y - .06, y + out, "xz") 63: for i in range(n)]) 64: 65: 66: def centre(bm): 67: return sum((v.co for v in bm.verts), Vector()) / max(len(bm.verts), 1) 68: 69: 70: def pack_panels(k, name, body, cuts, role_of, j="backpack"): 71: """Cut a pack body into panels and give each a role from its centre.""" 72: for i, p in enumerate(panels(body, cuts, .07)): 73: k.one(f"{name}{i}", p, role_of(centre(p)), j, smooth=True) 74: 75: 76: class Kit: 77: """Names parts per variant, mirrors pairs onto L/R joints, applies an optional authoring offset.""" 78: 79: def __init__(self, v): 80: self.v = v 81: self.J = {} 82: self.m = None 83: 84: def j(self, j, side=None): 85: if not isinstance(j, str): 86: return j 87: return self.J[j, side] if side and (j, side) in self.J else self.J[j] 88: 89: def one(self, name, bm, role, j, bevel=0.0, **kw): 90: if self.m is not None: 91: transform(bm, self.m) 92: return solid(f"{self.v}_{name}", bm, role, self.j(j), bevel=bevel, **kw) 93: 94: def two(self, name, bm, role, j, bevel=0.0, **kw): 95: if self.m is not None: 96: transform(bm, self.m) 97: r = mirror_x(bm) 98: a = solid(f"{self.v}_{name}.L", bm, role, self.j(j, "L"), bevel=bevel, **kw) 99: b = solid(f"{self.v}_{name}.R", r, role, self.j(j, "R"), bevel=bevel, **kw) 100: return [a, b] 101: 102: def side(self, s, name, bm, role, j, bevel=0.0, **kw): 103: """One part on one side only; authored on the left, mirrored when s is R.""" 104: if self.m is not None: 105: transform(bm, self.m) 106: if s == "R": 107: bm = mirror_x(bm) 108: return solid(f"{self.v}_{name}.{s}", bm, role, self.j(j, s), bevel=bevel, **kw) 109: 110: def twos(self, name, bms, role, j, **kw): 111: out = [] 112: for i, bm in enumerate(bms): 113: out += self.two(f"{name}{i}", bm, role, j, **kw) 114: return out 115: 116: def smooth2(self, name, bm, role, j, **kw): 117: return self.two(name, bm, role, j, smooth=True, **kw) 118: 119: def thruster(self, kind, at, d, r, length, j, s=None, housing=True): 120: p, d = Vector(at), Vector(d).normalized()read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log" }result, 1 line
File is empty
agent
+6:10reasoning
task-104's persistent runtime with an empty log requires further investigation. The shoot.mjs script might be the source of this delay. Reviewing the loading process of /?view=... and how window.__ready is set will help clarify the block.
read_file{"Path":"~/work/sortie/src/main.ts"}
input
{ "Path": "~/work/sortie/src/main.ts" }result, 46 lines
Showing lines 1-45 of 45 1: import '@fontsource/chakra-petch/400.css'; 2: import '@fontsource/chakra-petch/600.css'; 3: import '@fontsource/share-tech-mono/400.css'; 4: import './hud/hud.css'; 5: import { startViewer } from './view/viewer'; 6: import { installHelp } from './hud/help'; 7: 8: const canvas = document.getElementById('view') as HTMLCanvasElement; 9: const q = new URLSearchParams(location.search); 10: 11: if (window.matchMedia?.('(pointer: coarse)').matches && !window.matchMedia('(pointer: fine)').matches) { 12: const note = document.createElement('div'); 13: note.className = 'touch-note'; 14: note.textContent = 'Sortie needs a keyboard and mouse.'; 15: document.body.appendChild(note); 16: } 17: 18: if (q.has('sheet')) { 19: import('./view/sheet').then(({ startSheet }) => startSheet(canvas, q)); 20: } else if (q.get('view') === 'thrusters') { 21: import('./view/thrusters').then(({ startThrusterBench }) => startThrusterBench(canvas, q)); 22: } else if (q.get('view') === 'clip') { 23: import('./view/clip').then(({ startClip }) => startClip(canvas, q)); 24: } else if (q.has('view')) { 25: startViewer(canvas, q); 26: } else { 27: // F1 or H: the controls, over the picker and the game 28: installHelp(); 29: // On an artifact page, published updates reload the page; the viewer's hot hook hands back what 30: // the last version saved, so a republish doesn't throw the pilot back into the hangar. 31: const hot = (window as unknown as { claude?: { hot?: HotHook } }).claude?.hot; 32: // a republish hands back a saved game: skip the picker then, the save knows its frame 33: const start = (data: unknown) => 34: import('./game/picker').then(({ pickFrame, restoreFrame }) => (data ? restoreFrame(q) : pickFrame(q))) 35: .then(() => import('./game/game')) 36: .then(({ startGame }) => startGame(canvas, document.getElementById('hud')!, q, data, hot)); 37: if (hot?.ready) hot.ready(start); 38: else start(hot?.data ?? null); 39: } 40: 41: export interface HotHook { 42: ready?: (start: (data: unknown) => void) => void; 43: data?: unknown; 44: snapshot?: (save: () => unknown) => void; 45: }read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log" }result, 1 line
File is empty
agent
+6:23reasoning
The environment variable SORTIE_URL is used in one script and the other script starts a server on a dynamic port. There is a strong possibility of a port conflict. Investigating how the port is passed between these two scripts. Initial thought is the server's dynamic port is not being correctly passed.
manage_task{"Action":"kill","TaskId":"abb0eba5-92ad-4ab4-8738-458f4e606a27/task-104"}
input
{ "Action": "kill", "TaskId": "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-104" }result, 1 line
Task "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-104" cancelled.
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { spawn } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst env = { ...process.env, SORTIE_URL: base, W: \"1200\", H: \"800\" };\nconst child = spawn(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait new Promise((res) => child.on(\"exit\", res));\nawait srv.close();\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render test views of existing models with resolvedUrls"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { spawn } from \"node:child_process\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst env = { ...process.env, SORTIE_URL: base, W: \"1200\", H: \"800\" };\nconst child = spawn(\"node\", [\n \"tools/shoot.mjs\", \"/tmp/inspect\",\n \"atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10\",\n \"atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10\",\n \"pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard\",\n \"striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field\",\n \"striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\",\n \"lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit\"\n], { stdio: \"inherit\", env });\nawait new Promise((res) => child.on(\"exit\", res));\nawait srv.close();\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render test views of existing models with resolvedUrls" }result, 24 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-117 Task Description: node -e ' import { createServer } from "vite"; import { spawn } from "node:child_process"; const srv = await createServer({ server: { port: 0 }, logLevel: "error" }); await srv.listen(); const base = srv.resolvedUrls.local[0].replace(/\/$/, ""); const env = { ...process.env, SORTIE_URL: base, W: "1200", H: "800" }; const child = spawn("node", [ "tools/shoot.mjs", "/tmp/inspect", "atelier_b=/?view=lab_atelier_b&yaw=28&pitch=10", "atelier_a=/?view=lab_atelier_a&yaw=28&pitch=10", "pattern_m=/?view=pattern_m&yaw=32&pitch=10&pose=guard", "striker_field=/?view=striker&yaw=32&pitch=10&pose=guard&look=field", "striker_kit=/?view=striker&yaw=32&pitch=10&pose=guard&look=kit", "lancer_kit=/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit" ], { stdio: "inherit", env }); await new Promise((res) => child.on("exit", res)); await srv.close(); ' --input-type=module Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-117.log YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn. DO NOTHING ELSE. When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.resultTool execution was canceled
Tool execution was canceled
Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-104.log
read_file{"EndLine":100,"Path":"~/work/sortie/kit/figure.py","StartLine":1}
input
{ "EndLine": 100, "Path": "~/work/sortie/kit/figure.py", "StartLine": 1 }result, 101 lines
Showing lines 1-100 of 383 1: """A 1.75 m pilot in a flight suit, for scale in labs and lineups and to sit in the light cockpit. 2: 3: A fitted dark undersuit with armoured plates on the chest, shoulders, forearms, thighs and shins, a 4: high collar, a life support pack, gloves and boots, and a sculpted helmet with a recessed dark visor, 5: ear pods and a crest stripe. Plates are the body's own surface grown outward and cut by an outline, 6: so they sit on the body like moulded armour and their edges read as real thickness. 7: 8: The body is modelled once standing (rest pose: facing -Y, Z up, feet on z=0) and posed rigidly per 9: joint, forward kinematics from the pelvis. Poses: 10: stand standing at ease, arms a little out 11: bike seated on a bike-style seat, leaning forward, hands forward on two grips (light cockpit) 12: `points(pose)` gives the posed eye, grips, seat and foot pegs without building anything, so a 13: cockpit can be laid out around the pilot. 14: 15: Roles: undersuit and gloves "suit", plates "main", secondary panels "accent", the crest stripe and 16: small markings the `role` argument. "hazard" paints world-space stripes a metre and a half apart, 17: which cut a person in half, so it falls back to "trim" here. 18: """ 19: import math 20: 21: import bmesh 22: import bpy 23: from mathutils import Matrix, Vector 24: 25: from lib import boolean, halves, link, loft, merge, prism, solid, subd, transform 26: 27: # ---- the skeleton, rest pose ------------------------------------------------------------------------------- 28: # joint: (parent, pivot). Pivots for the left side (+X); the right side mirrors x. 29: SKELETON = { 30: "pelvis": (None, (0, 0, .93)), 31: "chest": ("pelvis", (0, .01, 1.06)), 32: "head": ("chest", (0, .015, 1.5)), 33: "upperarm": ("chest", (.19, .01, 1.42)), 34: "forearm": ("upperarm", (.2, .02, 1.13)), 35: "hand": ("forearm", (.205, .01, .865)), 36: "thigh": ("pelvis", (.095, 0, .91)), 37: "shin": ("thigh", (.1, -.005, .5)), 38: "foot": ("shin", (.1, .02, .085)), 39: } 40: SIDED = {"upperarm", "forearm", "hand", "thigh", "shin", "foot"} 41: 42: # Joint rotations in degrees: (pitch about X, sideways about Y, twist about Z), applied in rest axes. 43: # A positive pitch tips an upward bone forward (-Y) and a downward bone back. A positive sideways 44: # value tips a downward left bone toward the centre line, mirrored on the right. 45: # `fingers` curls the fingers (degrees per knuckle), `thumb` closes the thumb. 46: POSES = { 47: "stand": dict(lift=0.0, joints={ 48: "upperarm": (-3, -7, 0), "forearm": (-12, 2, -20), "hand": (-4, 0, 0), 49: "thigh": (0, -1.5, 0), "shin": (2, 0, 0), "foot": (-2, 0, 0), "head": (-2, 0, 0)}, 50: fingers=(22, 18), thumb=10), 51: "bike": dict(lift=0.0, joints={ 52: "pelvis": (24, 0, 0), "chest": (18, 0, 0), "head": (-42, 0, 0), 53: "upperarm": (-124, -11, 0), "forearm": (-8, 4, -84), "hand": (8, 0, 6), 54: "thigh": (-86, -5, 0), "shin": (112, 3, 0), "foot": (-32, 0, 0)}, 55: fingers=(78, 72), thumb=55), 56: } 57: 58: # Points of interest in the rest pose, by joint: the eye (between the eyes, inside the helmet), the 59: # grip in each hand, the seat contact under the pelvis, the ball of each foot. 60: MARKS = {"eye": ("head", (0, -.085, 1.645)), "grip": ("hand", (.2, -.004, .79)), "seat": ("pelvis", (0, .0, .86)), 61: "peg": ("foot", (.1, -.07, .02))} 62: 63: 64: def _rot(p, r, t): 65: return Matrix.Rotation(math.radians(p), 4, "X") @ Matrix.Rotation(math.radians(r), 4, "Y") @ Matrix.Rotation(math.radians(t), 4, "Z") 66: 67: 68: def rig(pose="stand"): 69: """World matrices per joint (keys like "thigh.L") for a pose, feet-on-the-ground for stand.""" 70: P = POSES[pose] 71: M = {} 72: for name, (parent, piv) in SKELETON.items(): 73: for s, sx in ((("L", 1), ("R", -1)) if name in SIDED else (("", 1),)): 74: key = f"{name}.{s}" if s else name 75: pk = None if parent is None else (f"{parent}.{s}" if parent in SIDED else parent) 76: p, r, t = P["joints"].get(name, (0, 0, 0)) 77: c = Vector((piv[0] * sx, piv[1], piv[2])) 78: local = Matrix.Translation(c) @ _rot(p, r * sx, t * sx) @ Matrix.Translation(-c) 79: M[key] = (M[pk] if pk else Matrix.Translation((0, 0, P["lift"]))) @ local 80: return M 81: 82: 83: def place(at=(0.0, 0.0), z=0.0, turn=0.0): 84: """The placement of a built pilot: turned `turn` degrees about Z, then moved to (at, z).""" 85: return Matrix.Translation((at[0], at[1], z)) @ Matrix.Rotation(math.radians(turn), 4, "Z") 86: 87: 88: def points(pose="stand", at=(0.0, 0.0), z=0.0, turn=0.0): 89: """Posed marks in world space: eye, grip.L/R, seat, peg.L/R.""" 90: M = rig(pose) 91: off = place(at, z, turn) 92: out = {} 93: for mark, (joint, p) in MARKS.items(): 94: if joint in SIDED: 95: for s, sx in (("L", 1), ("R", -1)): 96: out[f"{mark}.{s}"] = off @ M[f"{joint}.{s}"] @ Vector((p[0] * sx, p[1], p[2])) 97: else: 98: out[mark] = off @ M[joint] @ Vector(p) 99: return out 100:read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-117.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-117.log" }result, 1 line
File is empty
agent
+7:05reasoning
The hang in task-117 during shoot.mjs execution is likely tied to the lab_atelier or lab_atelier_ name check within the src/view/viewer.ts file, specifically lines 165-177. Examining the code block will reveal the condition causing the process to hang, most likely due to an infinite loop, or a blocking operation. This condition is triggered by the name variable passed into the function, so that is the key parameter to evaluate.
manage_task{"Action":"kill","TaskId":"abb0eba5-92ad-4ab4-8738-458f4e606a27/task-117"}
input
{ "Action": "kill", "TaskId": "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-117" }result, 1 line
Task "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-117" cancelled.
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nimport { mkdirSync } from \"node:fs\";\nmkdirSync(\"/tmp/inspect\", { recursive: true });\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst page = await browser.newPage({ viewport: { width: 1200, height: 800 } });\npage.on(\"pageerror\", (e) => console.error(\"PAGEERROR:\", e));\npage.on(\"console\", (m) => { if (m.type() === \"error\") console.error(\"CONSOLE:\", m.text()); });\nfor (const [name, q] of [\n [\"striker_field\", \"/?view=striker&yaw=32&pitch=10&pose=guard&look=field&nolabel=1\"],\n [\"striker_kit\", \"/?view=striker&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"lancer_kit\", \"/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"pattern_m\", \"/?view=pattern_m&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"atelier_b\", \"/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.evaluate(\"window.__ready = false\").catch(() => {});\n await page.goto(base + q);\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render test screenshots with console error logging"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nimport { mkdirSync } from \"node:fs\";\nmkdirSync(\"/tmp/inspect\", { recursive: true });\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst page = await browser.newPage({ viewport: { width: 1200, height: 800 } });\npage.on(\"pageerror\", (e) => console.error(\"PAGEERROR:\", e));\npage.on(\"console\", (m) => { if (m.type() === \"error\") console.error(\"CONSOLE:\", m.text()); });\nfor (const [name, q] of [\n [\"striker_field\", \"/?view=striker&yaw=32&pitch=10&pose=guard&look=field&nolabel=1\"],\n [\"striker_kit\", \"/?view=striker&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"lancer_kit\", \"/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"pattern_m\", \"/?view=pattern_m&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1\"],\n [\"atelier_b\", \"/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.evaluate(\"window.__ready = false\").catch(() => {});\n await page.goto(base + q);\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render test screenshots with console error logging" }result, 34 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-126 Task Description: node -e ' import { createServer } from "vite"; import { chromium } from "playwright"; import { mkdirSync } from "node:fs"; mkdirSync("/tmp/inspect", { recursive: true }); const srv = await createServer({ server: { port: 0 }, logLevel: "error" }); await srv.listen(); const base = srv.resolvedUrls.local[0].replace(/\/$/, ""); const browser = await chromium.launch({ args: ["--use-angle=swiftshader", "--enable-unsafe-swiftshader", "--ignore-gpu-blocklist"] }); const page = await browser.newPage({ viewport: { width: 1200, height: 800 } }); page.on("pageerror", (e) => console.error("PAGEERROR:", e)); page.on("console", (m) => { if (m.type() === "error") console.error("CONSOLE:", m.text()); }); for (const [name, q] of [ ["striker_field", "/?view=striker&yaw=32&pitch=10&pose=guard&look=field&nolabel=1"], ["striker_kit", "/?view=striker&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1"], ["lancer_kit", "/?view=light_lancer&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1"], ["pattern_m", "/?view=pattern_m&yaw=32&pitch=10&pose=guard&look=kit&nolabel=1"], ["atelier_b", "/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1"] ]) { const t0 = Date.now(); await page.evaluate("window.__ready = false").catch(() => {}); await page.goto(base + q); await page.waitForFunction("window.__ready === true", null, { timeout: 60000 }); await page.screenshot({ path: `/tmp/inspect/${name}.png` }); console.log(name, Date.now() - t0, "ms"); } await browser.close(); await srv.close(); ' --input-type=module Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-126.log YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn. DO NOTHING ELSE. When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.resultTool execution was canceled
Tool execution was canceled
Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-117.log
read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-126.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-126.log" }result, 1 line
File is empty
agent
+7:46reasoning
The viewer endpoint's hang is likely due to differences between viewer.ts and clip.ts. Focusing on viewer.ts, line 25 shows an asynchronous function startViewer that takes a canvas and query parameters. Investigating q and the logic that uses it in startViewer should identify the source of the hang.
The loop() function, triggered by requestAnimationFrame, appears to be rendering frames before the page load completes, potentially starving the browser's load event. This rendering process, specifically the pipe.render() call, consumes substantial main thread time, explaining the observed timeouts during page navigation. The initial hypothesis of a hang in startViewer is a symptom of this root cause. The issue is not in the initialization itself, but rather the rendering loop's impact on the browser's event loop.
manage_task{"Action":"kill","TaskId":"abb0eba5-92ad-4ab4-8738-458f4e606a27/task-126"}
input
{ "Action": "kill", "TaskId": "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-126" }result, 1 line
Task "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-126" cancelled.
run_command{"CommandLine":"ls -lh /tmp/inspect/","WaitMsBeforeAsync":5000,"toolSummary":"Check /tmp/inspect output files"}
input
{ "CommandLine": "ls -lh /tmp/inspect/", "WaitMsBeforeAsync": 5000, "toolSummary": "Check /tmp/inspect output files" }result, 4 lines
Command exited with code 0.

Command output:
total 0
resultTool execution was canceled
Tool execution was canceled
Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-126.log
agent
+8:05reasoning
The page.goto hang in task-126 contrasts with the successful execution of clip.mjs. Examining clip.mjs's server setup, a dynamic port is used, avoiding a potential port conflict that may be blocking task-126. This suggests the issue lies in port assignment within the failing task.
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconsole.log(\"1: createServer\");\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"info\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconsole.log(\"2: listening at\", base);\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconsole.log(\"3: browser launched\");\nconst page = await browser.newPage({ viewport: { width: 960, height: 540 } });\nconsole.log(\"4: goto\");\nawait page.goto(base + \"/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\", { waitUntil: \"domcontentloaded\" });\nconsole.log(\"5: goto done, waiting for __ready\");\nawait page.waitForFunction(\"window.__ready === true\", null, { timeout: 20000 });\nconsole.log(\"6: ready!\");\nawait page.screenshot({ path: \"/tmp/inspect/striker_kit.png\" });\nawait browser.close();\nawait srv.close();\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Debug step-by-step Vite and Playwright launch"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconsole.log(\"1: createServer\");\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"info\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconsole.log(\"2: listening at\", base);\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconsole.log(\"3: browser launched\");\nconst page = await browser.newPage({ viewport: { width: 960, height: 540 } });\nconsole.log(\"4: goto\");\nawait page.goto(base + \"/?view=striker&yaw=32&pitch=10&pose=guard&look=kit\", { waitUntil: \"domcontentloaded\" });\nconsole.log(\"5: goto done, waiting for __ready\");\nawait page.waitForFunction(\"window.__ready === true\", null, { timeout: 20000 });\nconsole.log(\"6: ready!\");\nawait page.screenshot({ path: \"/tmp/inspect/striker_kit.png\" });\nawait browser.close();\nawait srv.close();\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Debug step-by-step Vite and Playwright launch" }result, 33 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-136
Task Description: node -e '
import { createServer } from "vite";
import { chromium } from "playwright";
console.log("1: createServer");
const srv = await createServer({ server: { port: 0 }, logLevel: "info" });
await srv.listen();
const base = srv.resolvedUrls.local[0].replace(/\/$/, "");
console.log("2: listening at", base);
const browser = await chromium.launch({ args: ["--use-angle=swiftshader", "--enable-unsafe-swiftshader", "--ignore-gpu-blocklist"] });
console.log("3: browser launched");
const page = await browser.newPage({ viewport: { width: 960, height: 540 } });
console.log("4: goto");
await page.goto(base + "/?view=striker&yaw=32&pitch=10&pose=guard&look=kit", { waitUntil: "domcontentloaded" });
console.log("5: goto done, waiting for __ready");
await page.waitForFunction("window.__ready === true", null, { timeout: 20000 });
console.log("6: ready!");
await page.screenshot({ path: "/tmp/inspect/striker_kit.png" });
await browser.close();
await srv.close();
' --input-type=module
Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-136.log
Log output:
1: createServer
2: listening at http://localhost:46587
3: browser launched
4: goto
5: goto done, waiting for __ready
6: ready!

YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn.
 DO NOTHING ELSE.
 When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.
agent
+8:27reasoning
Initial observation: Task 136 printed "6: ready!" quickly, and the Node process didn't exit as expected after the server closed. The page.goto function's return was premature due to waitUntil: "domcontentloaded".
read_file{"Path":"/tmp/inspect/striker_kit.png"}
input
{ "Path": "/tmp/inspect/striker_kit.png" }result, 1 line
Showing binary file of type image/png
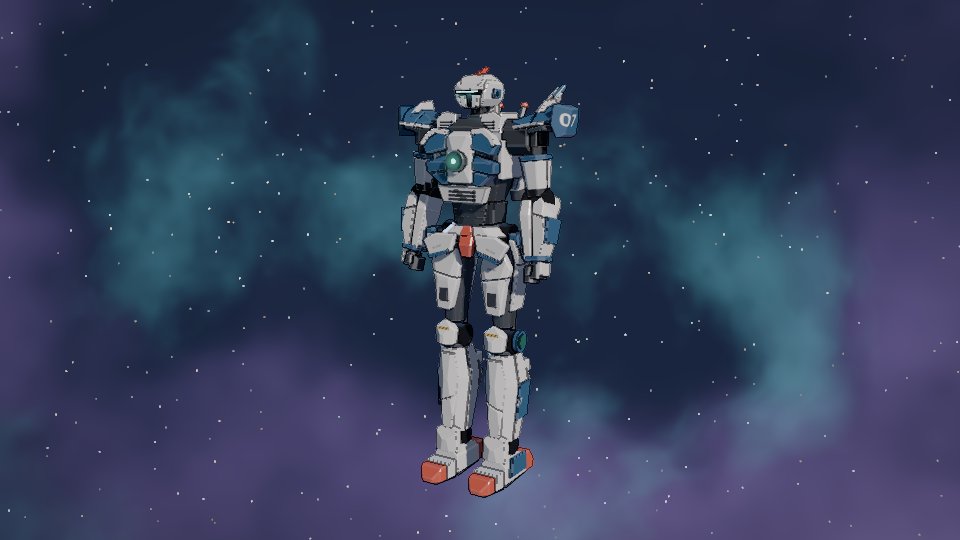
step_138_media_0.jpg
agent
+8:49reasoning
` hangs when the browser's main frame navigation is blocked. Checking the task logs for network errors during the screenshot attempt, focusing on why navigation might have stalled. Suspect a network resource failing to load, preventing the screenshot from completing.
The performance issue stems from the viewer.ts file's continuous animation loop blocking the main thread during screenshot capture. This contrasts with the efficient single-frame rendering in clip.ts, which avoids the problem. Possible solutions include stopping the animation loop, using a query parameter to control the animation, or employing canvas.toDataURL for immediate screenshot generation. This explains why the tool times out in headless environments, as the constant animation starves the screenshot process.
manage_task{"Action":"kill","TaskId":"abb0eba5-92ad-4ab4-8738-458f4e606a27/task-136"}error
input
{
  "Action": "kill",
  "TaskId": "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-136"
}
result, error, 1 line
Encountered error in step execution: cannot kill task "abb0eba5-92ad-4ab4-8738-458f4e606a27/task-136": task is not running (status: DONE)
resultCommand exited with code 0.
Command exited with code 0.

Command output:
1: createServer
2: listening at http://localhost:46587
3: browser launched
4: goto
5: goto done, waiting for __ready
6: ready!

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-136.log
agent
+9:14reasoning
striker_kit.png shows the figure in a rigid, non-guard pose despite the input. The source code reveals that a pose parameter is passed. Further investigation is needed to determine why the pose parameter is ignored.
The pose parameter is checked against a hardcoded list of poses. The observed posture discrepancy arises because the input guard pose is not present in this allowed pose list. The code uses MechRig to apply decals and poses only to the 'striker' figure. Consequently, striker_kit.png appears in a default stance, and not the requested guard pose.
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst context = await browser.newContext({ viewport: { width: 1200, height: 800 } });\nawait context.addInitScript(\"const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };\");\nconst page = await context.newPage();\nfor (const [name, q] of [\n [\"striker_a\", \"/?view=striker_a&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"light_lancer\", \"/?view=light_lancer&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"heavy_C\", \"/?view=heavy_C&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"pattern_m\", \"/?view=pattern_m&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"atelier_a\", \"/?view=lab_atelier_a&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_b\", \"/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_c\", \"/?view=lab_atelier_c&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_d\", \"/?view=lab_atelier_d&yaw=22&pitch=10&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.goto(base + q, { waitUntil: \"domcontentloaded\" });\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\nprocess.exit(0);\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render batch of existing models quickly with RAF guard"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst context = await browser.newContext({ viewport: { width: 1200, height: 800 } });\nawait context.addInitScript(\"const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };\");\nconst page = await context.newPage();\nfor (const [name, q] of [\n [\"striker_a\", \"/?view=striker_a&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"light_lancer\", \"/?view=light_lancer&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"heavy_C\", \"/?view=heavy_C&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"pattern_m\", \"/?view=pattern_m&yaw=32&pitch=10&look=kit&nolabel=1\"],\n [\"atelier_a\", \"/?view=lab_atelier_a&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_b\", \"/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_c\", \"/?view=lab_atelier_c&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_d\", \"/?view=lab_atelier_d&yaw=22&pitch=10&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.goto(base + q, { waitUntil: \"domcontentloaded\" });\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\nprocess.exit(0);\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render batch of existing models quickly with RAF guard" }result, 35 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-143
Task Description: node -e '
import { createServer } from "vite";
import { chromium } from "playwright";
const srv = await createServer({ server: { port: 0 }, logLevel: "error" });
await srv.listen();
const base = srv.resolvedUrls.local[0].replace(/\/$/, "");
const browser = await chromium.launch({ args: ["--use-angle=swiftshader", "--enable-unsafe-swiftshader", "--ignore-gpu-blocklist"] });
const context = await browser.newContext({ viewport: { width: 1200, height: 800 } });
await context.addInitScript("const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };");
const page = await context.newPage();
for (const [name, q] of [
  ["striker_a", "/?view=striker_a&yaw=32&pitch=10&look=kit&nolabel=1"],
  ["light_lancer", "/?view=light_lancer&yaw=32&pitch=10&look=kit&nolabel=1"],
  ["heavy_C", "/?view=heavy_C&yaw=32&pitch=10&look=kit&nolabel=1"],
  ["pattern_m", "/?view=pattern_m&yaw=32&pitch=10&look=kit&nolabel=1"],
  ["atelier_a", "/?view=lab_atelier_a&yaw=22&pitch=10&nolabel=1"],
  ["atelier_b", "/?view=lab_atelier_b&yaw=22&pitch=10&nolabel=1"],
  ["atelier_c", "/?view=lab_atelier_c&yaw=22&pitch=10&nolabel=1"],
  ["atelier_d", "/?view=lab_atelier_d&yaw=22&pitch=10&nolabel=1"]
]) {
  const t0 = Date.now();
  await page.goto(base + q, { waitUntil: "domcontentloaded" });
  await page.waitForFunction("window.__ready === true", null, { timeout: 60000 });
  await page.screenshot({ path: `/tmp/inspect/${name}.png` });
  console.log(name, Date.now() - t0, "ms");
}
await browser.close();
await srv.close();
process.exit(0);
' --input-type=module
Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log
YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn.
 DO NOTHING ELSE.
 When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.