A mech game prototype, pushed by Gemini 4 Argon
agent
+51:36reasoning
Initial hypothesis: adding 'block_dummy' as a model and frame will enable headless Blender to build the asset. The goal is to verify the build process for this new asset. Registering the name in the specified files is the first step.
edit_file{"Path":"~/work/sortie/src/render/assets.ts","Replacement":" | 'wreck_field' | 'salvage_pod' | 'escape_pod' | 'raider_grunt' | 'raider_brawler' | 'raider_boss'\n | 'pattern_m' | 'estoc' | 'pilot' | 'block_dummy';","Target":" | 'wreck_field' | 'salvage_pod' | 'escape_pod' | 'raider_grunt' | 'raider_brawler' | 'raider_boss'\n | 'pattern_m' | 'estoc' | 'pilot';"}
input
{ "Path": "~/work/sortie/src/render/assets.ts", "Replacement": " | 'wreck_field' | 'salvage_pod' | 'escape_pod' | 'raider_grunt' | 'raider_brawler' | 'raider_boss'\n | 'pattern_m' | 'estoc' | 'pilot' | 'block_dummy';", "Target": " | 'wreck_field' | 'salvage_pod' | 'escape_pod' | 'raider_grunt' | 'raider_brawler' | 'raider_boss'\n | 'pattern_m' | 'estoc' | 'pilot';" }result, 1 line
Made 1 replacement in ~/work/sortie/src/render/assets.ts starting at line 17 (+1/-1 lines).
edit_file{"Path":"~/work/sortie/src/view/viewer.ts","Replacement":"const FRAMES: string[] = ['striker_a', 'striker_b', 'light', 'light_line', 'light_lancer', 'heavy', 'heavy_B', 'heavy_C', 'pattern_m', 'estoc', 'block_dummy'];","Target":"const FRAMES: string[] = ['striker_a', 'striker_b', 'light', 'light_line', 'light_lancer', 'heavy', 'heavy_B', 'heavy_C', 'pattern_m', 'estoc'];"}
input
{ "Path": "~/work/sortie/src/view/viewer.ts", "Replacement": "const FRAMES: string[] = ['striker_a', 'striker_b', 'light', 'light_line', 'light_lancer', 'heavy', 'heavy_B', 'heavy_C', 'pattern_m', 'estoc', 'block_dummy'];", "Target": "const FRAMES: string[] = ['striker_a', 'striker_b', 'light', 'light_line', 'light_lancer', 'heavy', 'heavy_B', 'heavy_C', 'pattern_m', 'estoc'];" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/viewer.ts starting at line 23 (+1/-1 lines).
run_command{"CommandLine":"npm run -s kit -- block_dummy","WaitMsBeforeAsync":10000,"toolSummary":"Build block_dummy (YF-09 Kestrel) in headless Blender"}
input
{ "CommandLine": "npm run -s kit -- block_dummy", "WaitMsBeforeAsync": 10000, "toolSummary": "Build block_dummy (YF-09 Kestrel) in headless Blender" }result, 553 lines
Command exited with code 0.

Command output:
Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)
00:00.129  system.path      | WARNING Could not get a list of mounted file-systems
INFO Draco is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_draco_bridge.so
INFO MeshOptimizer is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_meshopt_bridge.so
02:44:46 | INFO: Starting glTF 2.0 export
02:44:46 | INFO: Extracting primitive: belt_girdle.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: codpiece_crest.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: codpiece_hi.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: codpiece_lo.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_collar.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_collar.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_trunnion.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_trunnion.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pelvis_core.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_lip.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_front_lip.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_rear_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_rear_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_rear_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_rear_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_vane.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: skirt_side_vane.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_ball_joint.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: achilles_piston.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf.L.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_thruster_pod.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_thruster_trim.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_vents.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_ball.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_collar.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_spat.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_spat_trim.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_heel.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_instep.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_toe.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_toe_claw.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sole_front.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sole_heel.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_2.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_3.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_disc.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_drum.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_piston.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_ring.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_sensor.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_hi.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_lo.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_spike.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: shin_core.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_core.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_louver_trim.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_ram_b.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_ram_f.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_2.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_3.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: hip_ball_joint.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: achilles_piston.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf.R.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_thruster_pod.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_thruster_trim.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: calf_vents.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_ball.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_collar.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_spat.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: ankle_spat_trim.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_heel.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_instep.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_toe.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sabaton_toe_claw.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sole_front.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: sole_heel.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_2.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: greave_shell_3.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_disc.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_drum.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_piston.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_ring.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: knee_sensor.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_hi.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_lo.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: kneecap_spike.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: shin_core.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_core.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_louver_trim.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_ram_b.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_ram_f.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_2.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: thigh_shell_3.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: abs_plate_0.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: abs_plate_1.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: abs_plate_2.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: spine_core
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: spine_ring_0.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: spine_ring_1.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: spine_ring_2.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: back_carapace_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: back_carapace_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: back_carapace_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: back_carapace_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_boom.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_capacitor.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_collar.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_hinge.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_nozzle.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_nozzle.L.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_hi.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_lo.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_trim.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_boom.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_capacitor.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_collar.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_hinge.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_nozzle.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_nozzle.R.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_hi.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_lo.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: binder_wing_trim.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main.L.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main.R.glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main_housing.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main_housing.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main_shroud.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: main_shroud.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_hull_hi.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_hull_lo.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_spine_fin.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_tank.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_tank.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_tank_band.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_tank_band.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_turbine
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_turbine_collar
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pack_turbine_glow
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_2.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: chest_nacelle_2.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: cockpit_canopy.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: cockpit_frame_trim.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: cockpit_hud_slit
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: cockpit_prow_hi.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: cockpit_prow_lo.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_shroud_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_shroud_0.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_shroud_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_shroud_1.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_trim.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: collar_trim.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: intake_lip.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: intake_lip.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: intake_vanes.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: intake_vanes.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_antenna.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_antenna.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_cheek.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_cheek.R.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_cranium.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_ear_lens.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_ear_lens.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_eye.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_eye.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_jaw.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_mast.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_mast_sensor
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: head_visor.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: neck_collar.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: neck_column
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: neck_piston.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: neck_piston.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_coil.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_coil.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_drum.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_drum.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_glow.L
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: reactor_glow.R
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pauldron_shell_0.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pauldron_shell_1.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pauldron_shell_2.L.001
02:44:46 | INFO: Primitives created: 1
02:44:46 | INFO: Extracting primitive: pauldron_shell_3.L.001
02:44:46 | INFO: Primitives created: 1
153 more lines not shown.
agent
+51:57reasoning
Inspecting the asset loading reveals the 'block_dummy' model loaded successfully. Next step is integrating a yardstick display mode, modifying viewer and clip components to enable side-by-side comparison of the model. This will provide a visual inspection tool.
Implementing yardstick display mode involves modifying the viewer and clip components. Within the viewer, if the URL includes 'yardstick', the main model is positioned at a negative X coordinate, and the yardstick model at a positive X coordinate, both using the specified pose. Thrusters and exhaust effects will be applied when 'thrust' is present in the URL. Similar logic extends to the clip component, positioning the main and yardstick models with adjusted X coordinates.
In the render function, the thruster effects and rotations need to be applied to both the main and yardstick rigs. When in "turn" or "orbit" mode with yardstick active, the camera yaw should be fixed, and both mechs rotated on their local Y-axes to prevent occlusion and maintain the side-by-side view. This simplifies the logic by having each mech rotate independently.
edit_file{"Path":"~/work/sortie/src/view/viewer.ts","Replacement":" if (q.has('thrust')) {\n const state = q.get('thrust');\n const reading = {\n x: 0, y: 0, z: state === 'cruise' ? 0.35 : 1,\n boosting: state !== 'cruise',\n assault: state === 'assault',\n quick: state === 'quick' ? 0.06 : 0.12,\n };\n for (let i = 0; i < 60; i++) rig.thrust(reading, 0.5 + i * (1 / 120), 1 / 120);\n root.updateMatrixWorld(true);\n const exLight = new THREE.PointLight(0xffffff, 0, 22, 1.6);\n scene.add(exLight);\n rig.lightExhaust(exLight, 0.75);\n }\n if (q.has('yardstick')) {\n const yName = (q.get('yardstick') || 'striker') as ModelName;\n const sep = Number(q.get('sep') ?? 4.6);\n root.position.x = x - sep;\n const mYaw = THREE.MathUtils.degToRad(Number(q.get('myaw') ?? 0));\n root.rotation.y = mYaw;\n const yRoot = await model(yName, palette);\n yRoot.position.x = x + sep;\n yRoot.rotation.y = mYaw;\n scene.add(yRoot);\n if (yName === 'striker') applyDecals(yRoot, STRIKER_DECALS);\n treatEyes(yRoot, (q.get('eye') ?? 'spill') as EyeMode);\n const yRig = new MechRig(yRoot);\n if (pose !== 'flight') yRoot.position.y = -yRig.soles(p);\n else yRig.apply(p);\n if (yName === 'striker') yRig.hold(await model('rifle', palette));\n if (q.has('thrust')) {\n const state = q.get('thrust');\n const reading = {\n x: 0, y: 0, z: state === 'cruise' ? 0.35 : 1,\n boosting: state !== 'cruise',\n assault: state === 'assault',\n quick: state === 'quick' ? 0.06 : 0.12,\n };\n for (let i = 0; i < 60; i++) yRig.thrust(reading, 0.5 + i * (1 / 120), 1 / 120);\n yRoot.updateMatrixWorld(true);\n const yLight = new THREE.PointLight(0xffffff, 0, 22, 1.6);\n scene.add(yLight);\n yRig.lightExhaust(yLight, 0.75);\n }\n }\n return root;","Target":" return root;"}
input
{ "Path": "~/work/sortie/src/view/viewer.ts", "Replacement": " if (q.has('thrust')) {\n const state = q.get('thrust');\n const reading = {\n x: 0, y: 0, z: state === 'cruise' ? 0.35 : 1,\n boosting: state !== 'cruise',\n assault: state === 'assault',\n quick: state === 'quick' ? 0.06 : 0.12,\n };\n for (let i = 0; i < 60; i++) rig.thrust(reading, 0.5 + i * (1 / 120), 1 / 120);\n root.updateMatrixWorld(true);\n const exLight = new THREE.PointLight(0xffffff, 0, 22, 1.6);\n scene.add(exLight);\n rig.lightExhaust(exLight, 0.75);\n }\n if (q.has('yardstick')) {\n const yName = (q.get('yardstick') || 'striker') as ModelName;\n const sep = Number(q.get('sep') ?? 4.6);\n root.position.x = x - sep;\n const mYaw = THREE.MathUtils.degToRad(Number(q.get('myaw') ?? 0));\n root.rotation.y = mYaw;\n const yRoot = await model(yName, palette);\n yRoot.position.x = x + sep;\n yRoot.rotation.y = mYaw;\n scene.add(yRoot);\n if (yName === 'striker') applyDecals(yRoot, STRIKER_DECALS);\n treatEyes(yRoot, (q.get('eye') ?? 'spill') as EyeMode);\n const yRig = new MechRig(yRoot);\n if (pose !== 'flight') yRoot.position.y = -yRig.soles(p);\n else yRig.apply(p);\n if (yName === 'striker') yRig.hold(await model('rifle', palette));\n if (q.has('thrust')) {\n const state = q.get('thrust');\n const reading = {\n x: 0, y: 0, z: state === 'cruise' ? 0.35 : 1,\n boosting: state !== 'cruise',\n assault: state === 'assault',\n quick: state === 'quick' ? 0.06 : 0.12,\n };\n for (let i = 0; i < 60; i++) yRig.thrust(reading, 0.5 + i * (1 / 120), 1 / 120);\n yRoot.updateMatrixWorld(true);\n const yLight = new THREE.PointLight(0xffffff, 0, 22, 1.6);\n scene.add(yLight);\n yRig.lightExhaust(yLight, 0.75);\n }\n }\n return root;", "Target": " return root;" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/viewer.ts starting at line 101 (+45/-0 lines).
edit_file{"Path":"~/work/sortie/src/view/viewer.ts","Replacement":" } else if (FRAMES.includes(name)) {\n const root = await frame((q.get('palette') ?? 'merc') as PaletteName, 0, name);\n new THREE.Box3().setFromObject(root).getCenter(target);\n if (q.has('yardstick')) target.x = 0;\n } else {","Target":" } else if (FRAMES.includes(name)) {\n const root = await frame((q.get('palette') ?? 'merc') as PaletteName, 0, name);\n new THREE.Box3().setFromObject(root).getCenter(target);\n } else {"}
input
{ "Path": "~/work/sortie/src/view/viewer.ts", "Replacement": " } else if (FRAMES.includes(name)) {\n const root = await frame((q.get('palette') ?? 'merc') as PaletteName, 0, name);\n new THREE.Box3().setFromObject(root).getCenter(target);\n if (q.has('yardstick')) target.x = 0;\n } else {", "Target": " } else if (FRAMES.includes(name)) {\n const root = await frame((q.get('palette') ?? 'merc') as PaletteName, 0, name);\n new THREE.Box3().setFromObject(root).getCenter(target);\n } else {" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/viewer.ts starting at line 156 (+1/-0 lines).
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" const name = (q.get('model') ?? 'striker') as ModelName;\n const palette = (q.get('palette') ?? 'merc') as PaletteName;\n const yardName = q.get('yardstick') as ModelName | null;\n const sep = yardName ? Number(q.get('sep') ?? 4.3) : 0;\n const root = await model(name, palette);\n root.position.x = -sep;\n if (name === 'striker') applyDecals(root, STRIKER_DECALS);\n treatEyes(root, 'spill');\n scene.add(root);\n const rig = new MechRig(root);\n root.updateMatrixWorld(true);\n rig.apply(POSES.stand);\n root.updateMatrixWorld(true);\n const box = new THREE.Box3().setFromObject(root);\n const height = box.getSize(new THREE.Vector3()).y;\n const footY = box.min.y;\n const size = height / 17.6;\n\n const light = new THREE.PointLight('#ffffff', 0, 0, 2);\n scene.add(light);\n\n let yardRoot: THREE.Object3D | null = null;\n let yardRig: MechRig | null = null;\n const yardLight = new THREE.PointLight('#ffffff', 0, 0, 2);\n if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = sep;\n if (yardName === 'striker') applyDecals(yardRoot, STRIKER_DECALS);\n treatEyes(yardRoot, 'spill');\n scene.add(yardRoot);\n yardRig = new MechRig(yardRoot);\n if (yardName === 'striker') yardRig.hold(await model('rifle', palette));\n yardRig.apply(POSES.stand);\n yardRoot.updateMatrixWorld(true);\n scene.add(yardLight);\n }","Target":" const name = (q.get('model') ?? 'striker') as ModelName;\n const palette = (q.get('palette') ?? 'merc') as PaletteName;\n const root = await model(name, palette);\n if (name === 'striker') applyDecals(root, STRIKER_DECALS);\n treatEyes(root, 'spill');\n scene.add(root);\n const rig = new MechRig(root);\n root.updateMatrixWorld(true);\n rig.apply(POSES.stand);\n root.updateMatrixWorld(true);\n const box = new THREE.Box3().setFromObject(root);\n const height = box.getSize(new THREE.Vector3()).y;\n const footY = box.min.y;\n const size = height / 17.6;\n\n const light = new THREE.PointLight('#ffffff', 0, 0, 2);\n scene.add(light);"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " const name = (q.get('model') ?? 'striker') as ModelName;\n const palette = (q.get('palette') ?? 'merc') as PaletteName;\n const yardName = q.get('yardstick') as ModelName | null;\n const sep = yardName ? Number(q.get('sep') ?? 4.3) : 0;\n const root = await model(name, palette);\n root.position.x = -sep;\n if (name === 'striker') applyDecals(root, STRIKER_DECALS);\n treatEyes(root, 'spill');\n scene.add(root);\n const rig = new MechRig(root);\n root.updateMatrixWorld(true);\n rig.apply(POSES.stand);\n root.updateMatrixWorld(true);\n const box = new THREE.Box3().setFromObject(root);\n const height = box.getSize(new THREE.Vector3()).y;\n const footY = box.min.y;\n const size = height / 17.6;\n\n const light = new THREE.PointLight('#ffffff', 0, 0, 2);\n scene.add(light);\n\n let yardRoot: THREE.Object3D | null = null;\n let yardRig: MechRig | null = null;\n const yardLight = new THREE.PointLight('#ffffff', 0, 0, 2);\n if (yardName) {\n yardRoot = await model(yardName, palette);\n yardRoot.position.x = sep;\n if (yardName === 'striker') applyDecals(yardRoot, STRIKER_DECALS);\n treatEyes(yardRoot, 'spill');\n scene.add(yardRoot);\n yardRig = new MechRig(yardRoot);\n if (yardName === 'striker') yardRig.hold(await model('rifle', palette));\n yardRig.apply(POSES.stand);\n yardRoot.updateMatrixWorld(true);\n scene.add(yardLight);\n }", "Target": " const name = (q.get('model') ?? 'striker') as ModelName;\n const palette = (q.get('palette') ?? 'merc') as PaletteName;\n const root = await model(name, palette);\n if (name === 'striker') applyDecals(root, STRIKER_DECALS);\n treatEyes(root, 'spill');\n scene.add(root);\n const rig = new MechRig(root);\n root.updateMatrixWorld(true);\n rig.apply(POSES.stand);\n root.updateMatrixWorld(true);\n const box = new THREE.Box3().setFromObject(root);\n const height = box.getSize(new THREE.Vector3()).y;\n const footY = box.min.y;\n const size = height / 17.6;\n\n const light = new THREE.PointLight('#ffffff', 0, 0, 2);\n scene.add(light);" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 37 (+19/-0 lines).
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n if (yardRig && yardRoot) {\n yardRig.thrust(reading, clock, dt);\n yardRoot.updateMatrixWorld(true);\n yardRig.lightExhaust(yardLight);\n }\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 0) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(p);\n root.updateMatrixWorld(true);\n if (yardRoot && yardRig) {\n yardRoot.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n yardRig.apply(p);\n yardRoot.updateMatrixWorld(true);\n }\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase && !yardName ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase && !yardName) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const dist = height * (yardName ? (v.chase ? 2.45 : 2.55) : v.dist);\n const yaw = THREE.MathUtils.degToRad(camYaw);\n const pitch = THREE.MathUtils.degToRad(v.chase ? 10 : v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n camera.up.copy(up);\n camera.lookAt(centre);\n }","Target":" rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n root.rotation.y = THREE.MathUtils.degToRad(v.mechYaw);\n rig.apply(v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose]);\n root.updateMatrixWorld(true);\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const dist = height * v.dist;\n const yaw = THREE.MathUtils.degToRad(v.camYaw);\n const pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n camera.up.copy(up);\n camera.lookAt(centre);\n }"}error
input
{
  "Path": "~/work/sortie/src/view/clip.ts",
  "Replacement": "    rig.thrust(reading, clock, dt);\n    rig.lightExhaust(light);\n    if (yardRig && yardRoot) {\n      yardRig.thrust(reading, clock, dt);\n      yardRoot.updateMatrixWorld(true);\n      yardRig.lightExhaust(yardLight);\n    }\n  };\n\n  const render = (i: number) => {\n    const f = frames[i];\n    const v = shotView(f);\n    // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n    const dt = f.cut ? 0 : 1 / fps;\n    if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n    for (let s = 0; s < dt - 1e-9; s += DT) {\n      clock += DT;\n      feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n    }\n    if (dt === 0) feed(f.state, f.stateT, 0);\n\n    const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n    const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw) : v.mechYaw;\n    const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 0) : v.camYaw;\n    root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n    rig.apply(p);\n    root.updateMatrixWorld(true);\n    if (yardRoot && yardRig) {\n      yardRoot.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n      yardRig.apply(p);\n      yardRoot.updateMatrixWorld(true);\n    }\n    ground.visible = v.ground;\n    centre.set(0, footY + height * v.lookAt, 0);\n    const fov = v.chase && !yardName ? chase.camera.fov : 35;\n    if (camera.fov !== fov) {\n      camera.fov = fov;\n      camera.updateProjectionMatrix();\n    }\n    if (v.chase && !yardName) {\n      // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n      yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n      offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n      camera.position.copy(centre).add(offset);\n      look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n      camera.up.copy(up);\n      camera.lookAt(look_);\n    } else {\n      const dist = height * (yardName ? (v.chase ? 2.45 : 2.55) : v.dist);\n      const yaw = THREE.MathUtils.degToRad(camYaw);\n      const pitch = THREE.MathUtils.degToRad(v.chase ? 10 : v.pitch);\n      camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n      camera.up.copy(up);\n      camera.lookAt(centre);\n    }",
  "Target": "    rig.thrust(reading, clock, dt);\n    rig.lightExhaust(light);\n  };\n\n  const render = (i: number) => {\n    const f = frames[i];\n    const v = shotView(f);\n    // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n    const dt = f.cut ? 0 : 1 / fps;\n    if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n    for (let s = 0; s < dt - 1e-9; s += DT) {\n      clock += DT;\n      feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n    }\n    if (dt === 0) feed(f.state, f.stateT, 0);\n\n    root.rotation.y = THREE.MathUtils.degToRad(v.mechYaw);\n    rig.apply(v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose]);\n    root.updateMatrixWorld(true);\n    ground.visible = v.ground;\n    centre.set(0, footY + height * v.lookAt, 0);\n    const fov = v.chase ? chase.camera.fov : 35;\n    if (camera.fov !== fov) {\n      camera.fov = fov;\n      camera.updateProjectionMatrix();\n    }\n    if (v.chase) {\n      // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n      yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n      offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n      camera.position.copy(centre).add(offset);\n      look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n      camera.up.copy(up);\n      camera.lookAt(look_);\n    } else {\n      const dist = height * v.dist;\n      const yaw = THREE.MathUtils.degToRad(v.camYaw);\n      const pitch = THREE.MathUtils.degToRad(v.pitch);\n      camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n      camera.up.copy(up);\n      camera.lookAt(centre);\n    }"
}
result, error, 1 line
Encountered error in step execution: target content not found in the file; the Target must exactly match existing file text, including whitespace
read_file{"EndLine":158,"Path":"~/work/sortie/src/view/clip.ts","StartLine":80}
input
{ "EndLine": 158, "Path": "~/work/sortie/src/view/clip.ts", "StartLine": 80 }result, 80 lines
Showing lines 80-158 of 158
80:   const pilot = await model('lab_pilot' as ModelName, palette);
81:   pilot.traverse((o) => { if (/^slot\d+$/.test(o.name) && o.name !== 'slot0') o.visible = false; });
82:   // lab slot 0 stands at x = -.55: bring the pilot beside the frame's foot, facing the camera
83:   pilot.position.set(0.55 + height * 0.3, footY, height * 0.16);
84:   pilot.rotation.y = 0.4;
85:   ground.add(pilot);
86:   scene.add(ground);
87:
88:   // the game's chase camera, read for its numbers: this view moves its own camera
89:   const chase = new CameraRig();
90:   const reading: ThrustReading = { x: 0, y: 0, z: 0, boosting: false };
91:   const centre = new THREE.Vector3();
92:   const offset = new THREE.Vector3();
93:   const look_ = new THREE.Vector3();
94:   const up = new THREE.Vector3(0, 1, 0);
95:   const yawQ = new THREE.Quaternion();
96:   const DT = 1 / 120;
97:   let clock = 0;
98:
99:   const feed = (state: Parameters<typeof benchInput>[0], t: number, dt: number) => {
100:     const f = benchInput(state, t);
101:     reading.x = f.thrust.x;
102:     reading.y = f.thrust.y;
103:     reading.z = f.thrust.z;
104:     reading.boosting = f.boosting;
105:     reading.assault = f.assault;
106:     reading.quick = f.quick;
107:     rig.thrust(reading, clock, dt);
108:     rig.lightExhaust(light);
109:   };
110:
111:   const render = (i: number) => {
112:     const f = frames[i];
113:     const v = shotView(f);
114:     // thrusters step at 120 Hz whatever the clip's frame rate, as a game would
115:     const dt = f.cut ? 0 : 1 / fps;
116:     if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }
117:     for (let s = 0; s < dt - 1e-9; s += DT) {
118:       clock += DT;
119:       feed(f.state, Math.max(0, f.stateT - dt + s), DT);
120:     }
121:     if (dt === 0) feed(f.state, f.stateT, 0);
122:
123:     root.rotation.y = THREE.MathUtils.degToRad(v.mechYaw);
124:     rig.apply(v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose]);
125:     root.updateMatrixWorld(true);
126:     ground.visible = v.ground;
127:     centre.set(0, footY + height * v.lookAt, 0);
128:     const fov = v.chase ? chase.camera.fov : 35;
129:     if (camera.fov !== fov) {
130:       camera.fov = fov;
131:       camera.updateProjectionMatrix();
132:     }
133:     if (v.chase) {
134:       // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame
135:       yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));
136:       offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);
137:       camera.position.copy(centre).add(offset);
138:       look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);
139:       camera.up.copy(up);
140:       camera.lookAt(look_);
141:     } else {
142:       const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);
143:       camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);
144:       if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck
145:       camera.up.copy(up);
146:       camera.lookAt(centre);
147:     }
148:     camera.updateMatrixWorld(true);
149:     followSun(sun, centre);
150:     pipe.render();
151:     // read straight after the draw, in the same task, while the buffer still holds it
152:     return canvas.toDataURL('image/jpeg', 0.93);
153:   };
154:
155:   const win = window as unknown as { __clip: unknown; __ready: boolean };
156:   win.__clip = { frames: frames.length, fps, render };
157:   win.__ready = true;
158: }
agent
+53:03reasoning
Initial hypothesis: passing the --yardstick striker flag is not correctly propagated. The code at tools/clip.mjs line 28 iterates through flags, and it needs modification to include the --yardstick striker parameter as well. Examining the flag handling to understand the propagation mechanism is necessary. Now editing src/view/clip.ts and tools/clip.mjs to address this issue and ensure proper flag passing.
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n if (yardRig && yardRoot) {\n yardRig.thrust(reading, clock, dt);\n yardRoot.updateMatrixWorld(true);\n yardRig.lightExhaust(yardLight);\n }\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(p);\n root.updateMatrixWorld(true);\n if (yardRoot && yardRig) {\n yardRoot.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n yardRig.apply(p);\n yardRoot.updateMatrixWorld(true);\n }\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase && !yardName ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase && !yardName) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const dist = (yardName ? (v.chase ? 2.35 : 2.55) : v.dist) * height;\n const yaw = THREE.MathUtils.degToRad(camYaw), pitch = THREE.MathUtils.degToRad(v.chase ? 10 : v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }","Target":" rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n root.rotation.y = THREE.MathUtils.degToRad(v.mechYaw);\n rig.apply(v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose]);\n root.updateMatrixWorld(true);\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n if (yardRig && yardRoot) {\n yardRig.thrust(reading, clock, dt);\n yardRoot.updateMatrixWorld(true);\n yardRig.lightExhaust(yardLight);\n }\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n const p = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n const inPlaceYaw = yardName ? (v.chase ? v.mechYaw : v.camYaw - 180) : v.mechYaw;\n const camYaw = yardName ? (v.chase ? 180 + v.camYaw * 0.35 : 180) : v.camYaw;\n root.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n rig.apply(p);\n root.updateMatrixWorld(true);\n if (yardRoot && yardRig) {\n yardRoot.rotation.y = THREE.MathUtils.degToRad(inPlaceYaw);\n yardRig.apply(p);\n yardRoot.updateMatrixWorld(true);\n }\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase && !yardName ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase && !yardName) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const dist = (yardName ? (v.chase ? 2.35 : 2.55) : v.dist) * height;\n const yaw = THREE.MathUtils.degToRad(camYaw), pitch = THREE.MathUtils.degToRad(v.chase ? 10 : v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }", "Target": " rig.thrust(reading, clock, dt);\n rig.lightExhaust(light);\n };\n\n const render = (i: number) => {\n const f = frames[i];\n const v = shotView(f);\n // thrusters step at 120 Hz whatever the clip's frame rate, as a game would\n const dt = f.cut ? 0 : 1 / fps;\n if (f.cut) for (let k = 0; k < 120; k++) { clock += DT; feed('idle', k * DT, DT); }\n for (let s = 0; s < dt - 1e-9; s += DT) {\n clock += DT;\n feed(f.state, Math.max(0, f.stateT - dt + s), DT);\n }\n if (dt === 0) feed(f.state, f.stateT, 0);\n\n root.rotation.y = THREE.MathUtils.degToRad(v.mechYaw);\n rig.apply(v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose]);\n root.updateMatrixWorld(true);\n ground.visible = v.ground;\n centre.set(0, footY + height * v.lookAt, 0);\n const fov = v.chase ? chase.camera.fov : 35;\n if (camera.fov !== fov) {\n camera.fov = fov;\n camera.updateProjectionMatrix();\n }\n if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 107 (+20/-6 lines).
edit_file{"Path":"~/work/sortie/tools/clip.mjs","Replacement":"for (const k of ['shots', 'look', 'yardstick', 'sep']) if (flag(k)) params.set(k, flag(k));","Target":"for (const k of ['shots', 'look']) if (flag(k)) params.set(k, flag(k));"}
input
{ "Path": "~/work/sortie/tools/clip.mjs", "Replacement": "for (const k of ['shots', 'look', 'yardstick', 'sep']) if (flag(k)) params.set(k, flag(k));", "Target": "for (const k of ['shots', 'look']) if (flag(k)) params.set(k, flag(k));" }result, 1 line
Made 1 replacement in ~/work/sortie/tools/clip.mjs starting at line 28 (+1/-1 lines).
agent
+53:29reasoning
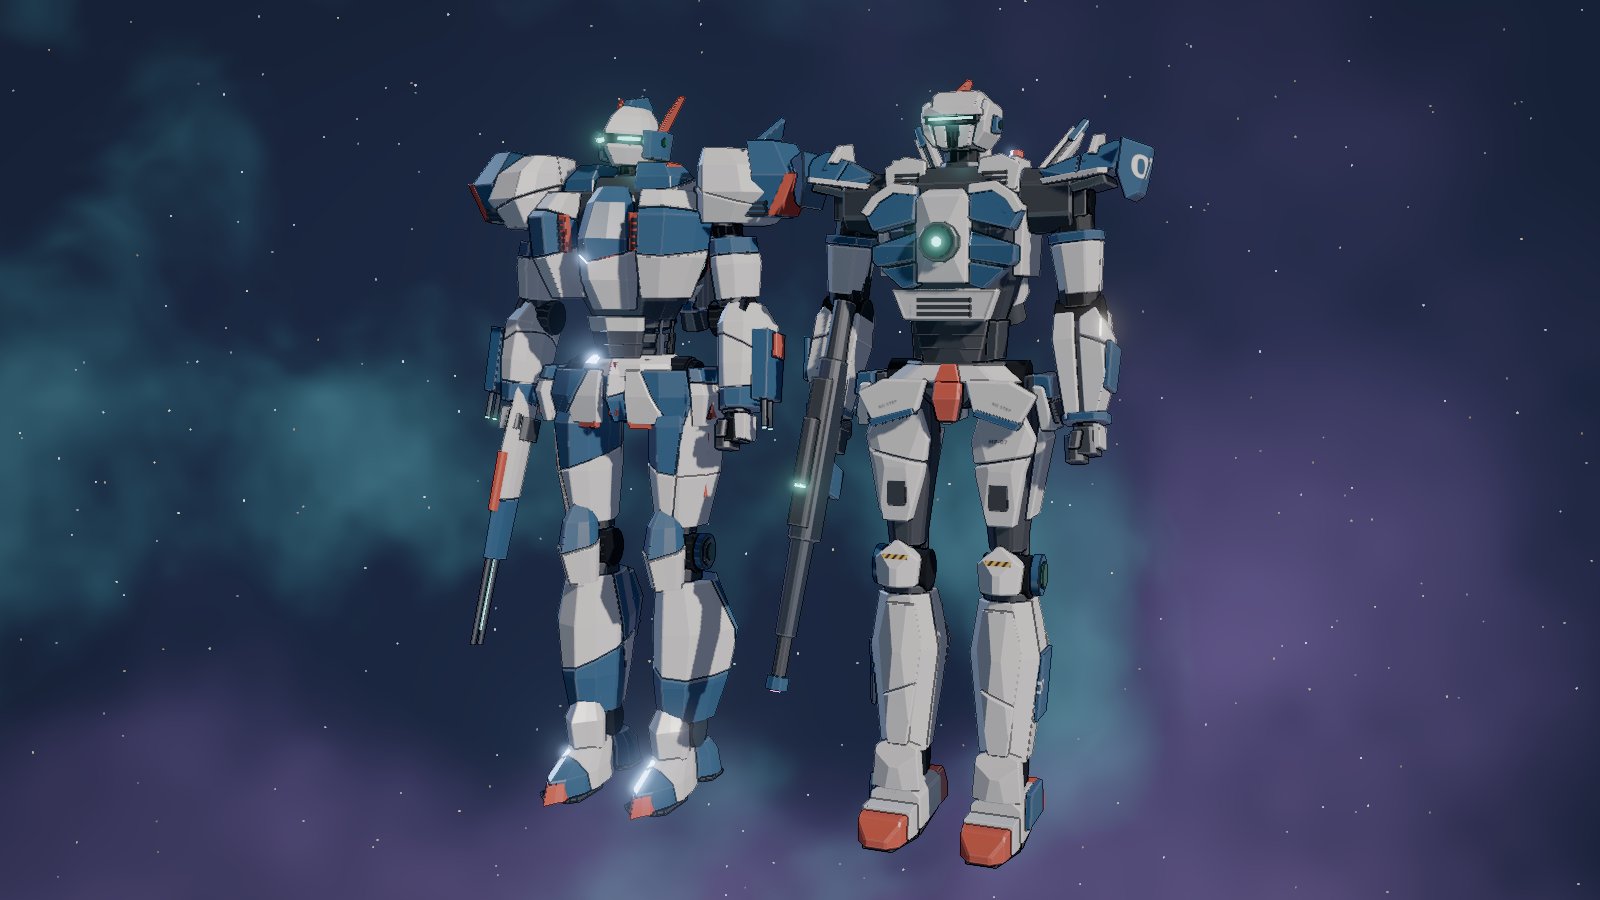
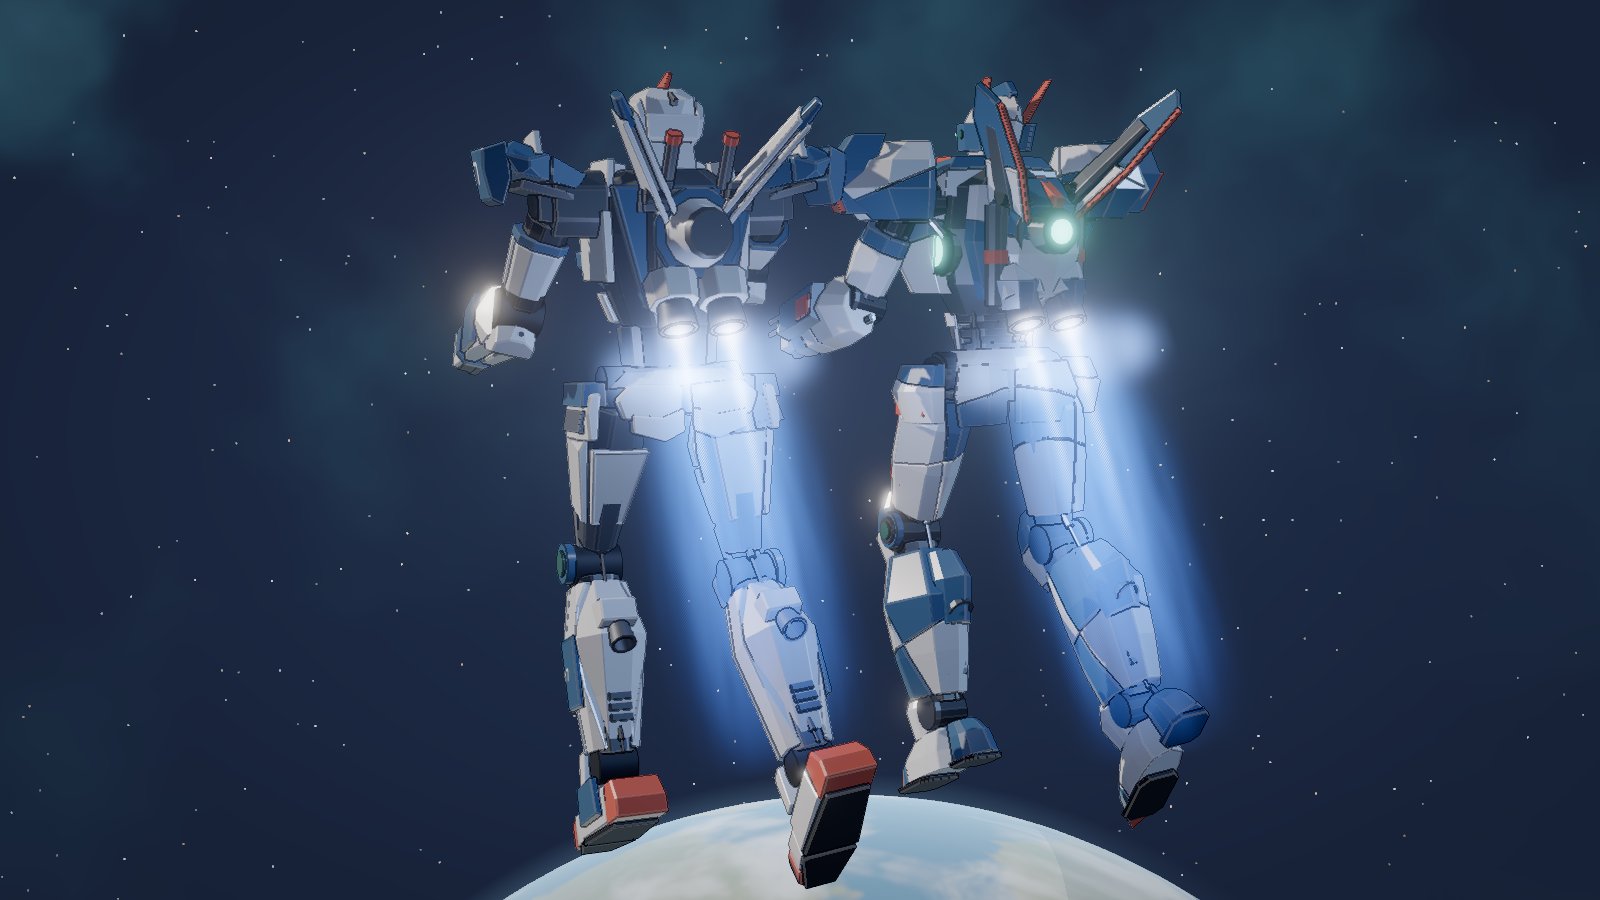
Generating diagnostic images of block_dummy and striker from two perspectives. The first image will be a front three-quarter view with a yardstick, and the second will be a rear-flight view including plumes. These images will assist in understanding the relative positioning and visual characteristics of the objects.
run_command{"CommandLine":"mkdir -p /tmp/inspect && npx vite --port 5199 --strictPort >/tmp/vite.log 2>&1 &\nVPID=$!\nfor i in $(seq 1 30); do curl -s http://localhost:5199 >/dev/null && break; sleep 0.2; done\nW=1600 H=900 node tools/shoot.mjs /tmp/inspect \\\n 'kestrel_front=/?view=block_dummy&yardstick=striker&sep=4.2&pose=stand&look=kit&yaw=22&pitch=6&dist=35' \\\n 'kestrel_rear_flight=/?view=block_dummy&yardstick=striker&sep=4.2&pose=flight&thrust=boost&look=kit&yaw=156&pitch=10&dist=36'\nkill $VPID 2>/dev/null || true","WaitMsBeforeAsync":10000,"toolSummary":"Shoot front and rear-flight yardstick diagnostics of block_dummy vs striker"}
input
{ "CommandLine": "mkdir -p /tmp/inspect && npx vite --port 5199 --strictPort >/tmp/vite.log 2>&1 &\nVPID=$!\nfor i in $(seq 1 30); do curl -s http://localhost:5199 >/dev/null && break; sleep 0.2; done\nW=1600 H=900 node tools/shoot.mjs /tmp/inspect \\\n 'kestrel_front=/?view=block_dummy&yardstick=striker&sep=4.2&pose=stand&look=kit&yaw=22&pitch=6&dist=35' \\\n 'kestrel_rear_flight=/?view=block_dummy&yardstick=striker&sep=4.2&pose=flight&thrust=boost&look=kit&yaw=156&pitch=10&dist=36'\nkill $VPID 2>/dev/null || true", "WaitMsBeforeAsync": 10000, "toolSummary": "Shoot front and rear-flight yardstick diagnostics of block_dummy vs striker" }result, 15 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-403
Task Description: mkdir -p /tmp/inspect && npx vite --port 5199 --strictPort >/tmp/vite.log 2>&1 &
VPID=$!
for i in $(seq 1 30); do curl -s http://localhost:5199 >/dev/null && break; sleep 0.2; done
W=1600 H=900 node tools/shoot.mjs /tmp/inspect \
  'kestrel_front=/?view=block_dummy&yardstick=striker&sep=4.2&pose=stand&look=kit&yaw=22&pitch=6&dist=35' \
  'kestrel_rear_flight=/?view=block_dummy&yardstick=striker&sep=4.2&pose=flight&thrust=boost&look=kit&yaw=156&pitch=10&dist=36'
kill $VPID 2>/dev/null || true
Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-403.log
Log output:
kestrel_front: 7481 ms

YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn.
 DO NOTHING ELSE.
 When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.
read_file{"Path":"/tmp/inspect/kestrel_front.png"}
input
{ "Path": "/tmp/inspect/kestrel_front.png" }result, 1 line
Showing binary file of type image/png
step_405_media_0.jpg resultCommand exited with code 0.
Command exited with code 0.

Command output:
kestrel_front: 7481 ms
kestrel_rear_flight: 7145 ms

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-403.log
read_file{"Path":"/tmp/inspect/kestrel_rear_flight.png"}
input
{ "Path": "/tmp/inspect/kestrel_rear_flight.png" }result, 1 line
Showing binary file of type image/png
step_408_media_0.jpg