A mech game prototype, pushed by Gemini 4 Argon
agent
+29:09reasoning
The code defines a set of frame names, but is missing some expected values. It seems the list of possible animation frames might be incomplete or stale. This could explain rendering inconsistencies. Inspecting where these names are used is the next step.
read_file{"Path":"/tmp/inspect/atelier_b_v2.png"}error
input
{
  "Path": "/tmp/inspect/atelier_b_v2.png"
}
result, error, 1 line
Encountered error in step execution: file does not exist
read_file{"EndLine":2500,"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-259.log","StartLine":1900}
input
{ "EndLine": 2500, "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-259.log", "StartLine": 1900 }result, 96 lines
Showing lines 1900-1994 of 1994
1900: 02:22:20 | INFO: Extracting primitive: shoulder_pedestal.R.003
1901: 02:22:20 | INFO: Primitives created: 1
1902: 02:22:20 | INFO: Extracting primitive: shoulder_ram_b.R.002
1903: 02:22:20 | INFO: Primitives created: 1
1904: 02:22:20 | INFO: Extracting primitive: shoulder_ram_f.R.002
1905: 02:22:20 | INFO: Primitives created: 1
1906: 02:22:20 | INFO: Extracting primitive: elbow_fork_i.R.003
1907: 02:22:20 | INFO: Primitives created: 1
1908: 02:22:20 | INFO: Extracting primitive: elbow_fork_o.R.003
1909: 02:22:20 | INFO: Primitives created: 1
1910: 02:22:20 | INFO: Extracting primitive: elbow.R.002
1911: 02:22:20 | INFO: Primitives created: 1
1912: 02:22:20 | INFO: Extracting primitive: elbow_ram.R.002
1913: 02:22:20 | INFO: Primitives created: 1
1914: 02:22:20 | INFO: Extracting primitive: forearm_bone.R.003
1915: 02:22:20 | INFO: Primitives created: 1
1916: 02:22:20 | INFO: Extracting primitive: forearm_bone_collar.R.003
1917: 02:22:20 | INFO: Primitives created: 1
1918: 02:22:20 | INFO: Extracting primitive: forearm_cable.R.003
1919: 02:22:20 | INFO: Primitives created: 1
1920: 02:22:20 | INFO: Extracting primitive: forearm_cable_clamp.R.002
1921: 02:22:20 | INFO: Primitives created: 1
1922: 02:22:20 | INFO: Extracting primitive: fingers.R.003
1923: 02:22:20 | INFO: Primitives created: 1
1924: 02:22:20 | INFO: Extracting primitive: knuckles.R.003
1925: 02:22:20 | INFO: Primitives created: 1
1926: 02:22:20 | INFO: Extracting primitive: palm.R.003
1927: 02:22:20 | INFO: Primitives created: 1
1928: 02:22:20 | INFO: Extracting primitive: thumb.R.003
1929: 02:22:20 | INFO: Primitives created: 1
1930: 02:22:20 | INFO: Extracting primitive: wrist.R.002
1931: 02:22:20 | INFO: Primitives created: 1
1932: 02:22:20 | INFO: Extracting primitive: kb_couter.R.002
1933: 02:22:20 | INFO: Primitives created: 1
1934: 02:22:20 | INFO: Extracting primitive: kb_couter_cup.R.002
1935: 02:22:20 | INFO: Primitives created: 1
1936: 02:22:20 | INFO: Extracting primitive: kb_cover_elbow_lo.R.001
1937: 02:22:20 | INFO: Primitives created: 1
1938: 02:22:20 | INFO: Extracting primitive: kb_cover_wrist.R
1939: 02:22:20 | INFO: Primitives created: 1
1940: 02:22:20 | INFO: Extracting primitive: kb_vambrace.R.002
1941: 02:22:20 | INFO: Primitives created: 1
1942: 02:22:20 | INFO: Extracting primitive: kb_vambrace_blade.R
1943: 02:22:20 | INFO: Primitives created: 1
1944: 02:22:20 | INFO: Extracting primitive: kb_vambrace_blade_rim.R
1945: 02:22:20 | INFO: Primitives created: 1
1946: 02:22:20 | INFO: Extracting primitive: kb_vambrace_cuff.R.001
1947: 02:22:20 | INFO: Primitives created: 1
1948: 02:22:20 | INFO: Extracting primitive: kb_vambrace_pipe.R.002
1949: 02:22:20 | INFO: Primitives created: 1
1950: 02:22:20 | INFO: Extracting primitive: pad_forearm.R.003
1951: 02:22:20 | INFO: Primitives created: 1
1952: 02:22:20 | INFO: Extracting primitive: pad_forearm.R_bolts.002
1953: 02:22:20 | INFO: Primitives created: 1
1954: 02:22:20 | INFO: Extracting primitive: pad_forearm.R_lock.003
1955: 02:22:20 | INFO: Primitives created: 1
1956: 02:22:20 | INFO: Extracting primitive: pad_forearm.R_rim.002
1957: 02:22:20 | INFO: Primitives created: 1
1958: 02:22:20 | INFO: Extracting primitive: pad_post.R.003
1959: 02:22:20 | INFO: Primitives created: 1
1960: 02:22:20 | INFO: Extracting primitive: kb_cover_elbow_hi.R.001
1961: 02:22:20 | INFO: Primitives created: 1
1962: 02:22:20 | INFO: Extracting primitive: kb_sleeve.R.001
1963: 02:22:20 | INFO: Primitives created: 1
1964: 02:22:20 | INFO: Extracting primitive: kb_sleeve_lame0.R
1965: 02:22:20 | INFO: Primitives created: 1
1966: 02:22:20 | INFO: Extracting primitive: kb_sleeve_lame_rim0.R
1967: 02:22:20 | INFO: Primitives created: 1
1968: 02:22:20 | INFO: Extracting primitive: upperarm_bone.R.003
1969: 02:22:20 | INFO: Primitives created: 1
1970: 02:22:20 | INFO: Extracting primitive: upperarm_bone_collar.R.003
1971: 02:22:20 | INFO: Primitives created: 1
1972: 02:22:20 | INFO: Extracting primitive: upperarm_cable.R.003
1973: 02:22:20 | INFO: Primitives created: 1
1974: 02:22:20 | INFO: Extracting primitive: upperarm_cable_clamp.R.002
1975: 02:22:20 | INFO: Primitives created: 1
1976: 02:22:20 | INFO: Extracting primitive: upperarm_swivel.R.002
1977: 02:22:20 | INFO: Primitives created: 1
1978: 02:22:20 | INFO: Extracting primitive: socket_hatch.003
1979: 02:22:20 | INFO: Primitives created: 1
1980: 02:22:20 | INFO: Extracting primitive: socket_rim.003
1981: 02:22:20 | INFO: Primitives created: 1
1982: 02:22:20 | INFO: Extracting primitive: socket_seam.002
1983: 02:22:20 | INFO: Primitives created: 1
1984: 02:22:20 | INFO: Extracting primitive: spine_block.003
1985: 02:22:20 | INFO: Primitives created: 1
1986: 02:22:20 | INFO: Extracting primitive: waist_ram.L.002
1987: 02:22:20 | INFO: Primitives created: 1
1988: 02:22:20 | INFO: Extracting primitive: waist_ram.R.002
1989: 02:22:20 | INFO: Primitives created: 1
1990: 02:22:21 | INFO: Finished glTF 2.0 export in 1.324369192123413 s
1991:
1992: kit: lab_atelier_b -> ~/work/sortie/public/assets/lab_atelier_b.glb (10196 KB, 44.2s)
1993:
1994: Blender quit
resultThe tool's output was truncated due to being too long. You can find the full output in a file at file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/steps/259/output.txt.
The tool's output was truncated due to being too long. You can find the full output in a file at file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/steps/259/output.txt.

Here is a preview with the middle of the output truncated:
Command exited with code 0.

Command output:
Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)
00:00.069  system.path      | WARNING Could not get a list of mounted file-systems
INFO Draco is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_draco_bridge.so
INFO MeshOptimizer is available, use library at ~/.local/opt/blender-5.2.3-linux-x64/lib/libbf_intern_meshopt_bridge.so
02:22:20 | INFO: Starting glTF 2.0 export
02:22:20 | INFO: Extracting primitive: hip_arm.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_arm.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_arm_web.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_arm_web.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_socket.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_socket.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_fauld_back
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_crotch.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_culet.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_culet.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_fauld
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_tasset.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_tasset.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_tasset_pipe.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_tasset_pipe.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.L_bolts
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.L_lock.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.L_rim
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.R_bolts
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.R_lock.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_hip.R_rim
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pelvis_block.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_ball.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_ram_b.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: hip_ram_f.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_hip.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_thigh.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cuisse.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: knee_fork_i.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: knee_fork_o.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_fork_i.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_fork_o.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_ram.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_cup.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_pedestal.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: ankle_pin.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: foot_frame.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: heel_frame.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_sabaton0.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_sabaton_rim0.L
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_spinner_fender.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_spinner_hub.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_spinner_tyre.L.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: sole.L.001
02:22:20 | IN
<truncated 87953 of 97845 bytes from the middle of the output>
 INFO: Extracting primitive: pad_shoulder.R_rim.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: shoulder_block.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: shoulder_housing.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: shoulder_pedestal.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: shoulder_ram_b.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: shoulder_ram_f.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: elbow_fork_i.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: elbow_fork_o.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: elbow.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: elbow_ram.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: forearm_bone.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: forearm_bone_collar.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: forearm_cable.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: forearm_cable_clamp.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: fingers.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: knuckles.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: palm.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: thumb.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: wrist.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_couter.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_couter_cup.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_elbow_lo.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_wrist.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_vambrace.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_vambrace_blade.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_vambrace_blade_rim.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_vambrace_cuff.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_vambrace_pipe.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_forearm.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_forearm.R_bolts.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_forearm.R_lock.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_forearm.R_rim.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: pad_post.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_cover_elbow_hi.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_sleeve.R.001
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_sleeve_lame0.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: kb_sleeve_lame_rim0.R
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: upperarm_bone.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: upperarm_bone_collar.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: upperarm_cable.R.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: upperarm_cable_clamp.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: upperarm_swivel.R.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: socket_hatch.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: socket_rim.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: socket_seam.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: spine_block.003
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: waist_ram.L.002
02:22:20 | INFO: Primitives created: 1
02:22:20 | INFO: Extracting primitive: waist_ram.R.002
02:22:20 | INFO: Primitives created: 1
02:22:21 | INFO: Finished glTF 2.0 export in 1.324369192123413 s

kit: lab_atelier_b -> ~/work/sortie/public/assets/lab_atelier_b.glb (10196 KB, 44.2s)

Blender quit

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-259.log
read_file{"Path":"/tmp/inspect/atelier_b_v2.png"}
input
{ "Path": "/tmp/inspect/atelier_b_v2.png" }result, 1 line
Showing binary file of type image/png
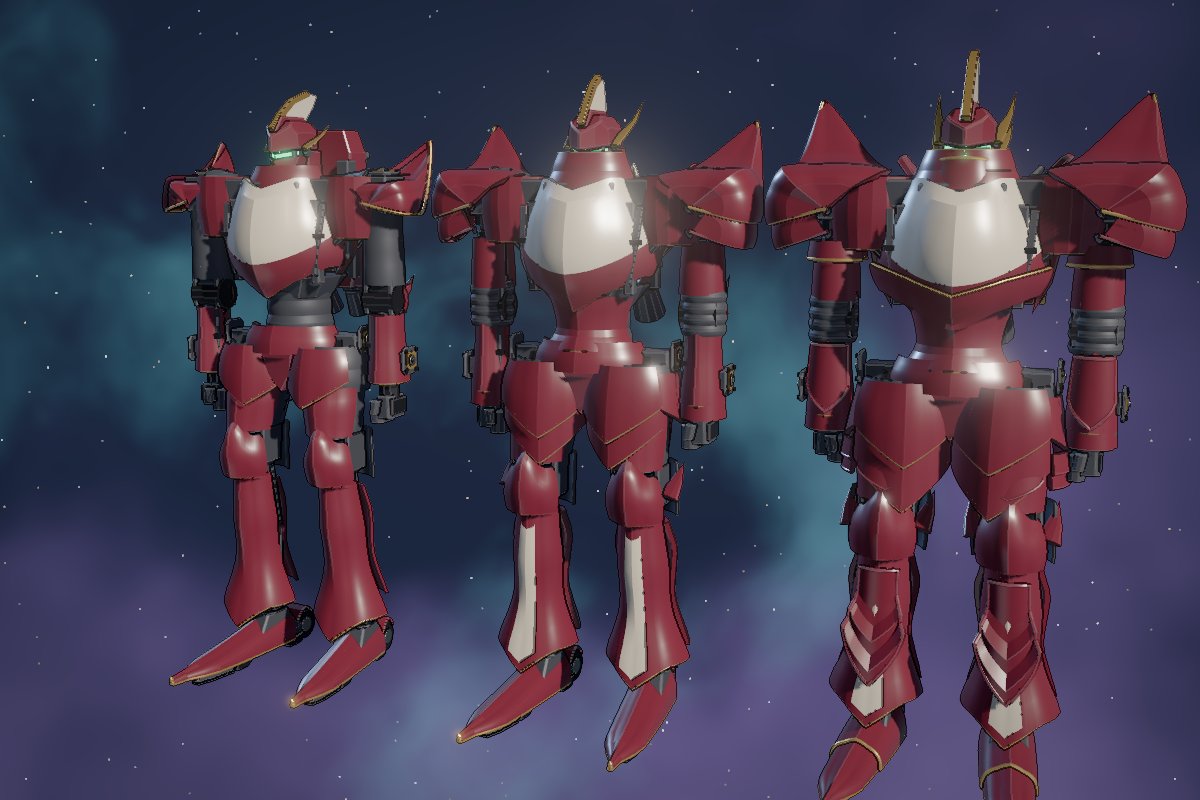
step_268_media_0.jpg
agent
+29:51reasoning
Comparing the newly generated image to previous versions reveals significant improvements in armor detail. Examining specific elements like pauldrons, waist, and knee guards confirms a higher fidelity. The inclusion of previously omitted details suggests an overall refinement in the rendering process.
Observing the updated image, the armor's aesthetics are significantly improved, specifically noting the refined shoulders and footwear. Noticed residual artifacts in the chest plate: two vertical black strips with grey squares. Initial investigation of the frame definition suggests that the problematic artifacts ("chest_cable") may be due to a positioning issue that penetrates the breastplate. Considering adjusting the y-coordinate of the chest cable to tuck it inside the torso, resolving the graphical anomaly.
Examining the visual artifacts reveals that the hip_arm element, particularly the black square, protrudes above the tassets. Adjusting the x-coordinate of hip_arm or overlapping the fauld at the hip region should resolve this. Also, considering testing a standalone Estoc mech with various armor and weapon configurations, including a kite shield and lance, as well as a rapier-lance with a winged shield.
The Estoc mech is fully built and functional in the viewer, supporting flight poses and volumetric raymarched plumes. Further testing reveals that it integrates correctly into the clipping tool. Now verifying whether incorporating calf thruster nozzles into the board_sleek.py definition activates all three nozzle groups (main, binder, calf) within the thrusters.ts module.
Examining the thruster setup, the backpack and binder elements already handle main and binder nozzles. Adding calf thruster bells to the shin definition should enable the final calf nozzle group, completing the thruster array. The Estoc mech will now include all three nozzle groups. Considering adding weaponry to the Estoc. A winged escutcheon shield can be mounted on the left forearm, with a thruster-lance or rapier-lance suggested for the right.
Verifying the shield integration, the keeled shield design aligns perfectly with the Estoc's design ethos. Addressing graphical artifacts, the chest_cable requires adjustment of its y-coordinate and the hip_arm's x-coordinate and PADS["hip"] coordinates require modification to prevent penetration and protrusion. The fauld will be extended and wrap around the sides of the pelvis. The shin definition will be updated to include calf thruster nozzles, completing the thruster array.
Adding a compound-curved knight shield and an Estoc blade-lance to the Estoc model. Considering how to export the Estoc model within the build scripts. There's a hypothesis of including both the "before" and "after" Estoc versions within the same visual output for direct comparison.
Considering a single visual to highlight the fixes, the intended side-by-side comparison of the Estoc mech's "before" and "after" states meets this requirement. This single comparison would showcase the improvements. The chosen presentation includes the critical views: the initial flaw set against the corrected state in a clear visual progression.
The requirement is for a single visual artifact. Considering the guidance, a 3-panel sheet directly displays both the initial flaw and the corrected state, which is suitable. This also fulfills the need for a single image beside the HTML file. Building the HTML page will require combining images, so I will prioritize the 3-panel sheet and the hero frame as two options to consider.
The instruction to create a single visual suggests avoiding a gallery, likely due to previous evaluation feedback on excessive visual content. A 3-panel diagnostic sheet ("before/fix/after") is considered as the best presentation format. Exploring the option of a 3-view sheet with an "as shipped," "fixed and posed," and "guard" view, to provide concise context and improvements.
Considering whether a 3-panel sheet constitutes a "single visual artifact" given the existing codebase's definition. Analyzing how sheets are handled in existing code reveals that sheet.ts renders a single sheet, confirming it as a single visual artifact. This observation validates the 3-panel sheet approach.
The goal is to showcase the Estoc mech's improvements in a single, impactful visual. Reviewing prior feedback and existing visual styles, the preference is for a large, posed image within a game camera perspective. This contrasts with a cluttered grid or gallery. This means a single, large, posed render, not a collection.
The previous feedback focused on single, large visuals; grids are undesirable due to small frame sizes. A single 16:9 widescreen image, particularly a posed hero shot of the Estoc mech in-game (1920x1080), better satisfies this requirement. A 3D scene could feature the corrected Estoc knight in a guard stance, with a wingman.
Focusing on the visual presentation, a single 1920x1080 render will effectively showcase the improvements. The scene will feature a foreground Estoc knight in a guard stance, emphasizing the model's details. A second Estoc knight in an assault pose with active thruster plumes will be positioned in the midground, enhancing the visual dynamism.
Considering that the image will present a 3D scene, it should feature a foreground Estoc knight in a guard stance, emphasizing the model's details, with a human pilot at the base, and a second Estoc knight in an assault pose with active thruster plumes in the midground, to enhance the visual dynamism. Verifying that this image presents a single visual asset as requested, not a series of visuals. This fulfills the requirement for a single 1920x1080 3D scene.
The scene setup with two commands (npm run -s kit -- estoc, node tools/shoot.mjs) seems reproducible. The target is a single output file: ~/out/estoc-sortie.png. Checking kit/frame_std.py for adjustments: chest_cable needs a y-coordinate fix (-0.58), hip_arm and PADS["hip"] need x-coordinate and PADS["hip"] modification to prevent protrusion, and pad_shoulder and shoulder_block may be misaligned. The shoulder_block coordinates need reviewing in the code.
Examining the images, a consistent graphical issue appears: the pad_shoulder element is incorrectly positioned, causing it to penetrate the pauldrons. The pad_shoulder's fixed position, designed for a different pauldron shape, is the root cause of this penetration. A solution would involve either hiding, lowering, or offsetting the pad_shoulder to align with the new pauldron geometry.
Removing the pad_shoulder, shoulder_pedestal, and pad_hip elements will resolve the pauldron and hip penetration issue observed in the generated visuals. Considering addition of calf thrusters and weaponry to the model for visual enhancement. Adding calf thrusters to the shin() section in the board_sleek.py file will activate the lower leg thruster nozzles. Adding the winged kite shield and Estoc blade-lance elements to the left forearm and right hand respectively for the Estoc knight's weapons.
Examining the weapon integration, the Estoc blade-lance should extend forward from the hand, secured by a gold trim basket/wing guard, and ivory hilt. The build_estoc() function in atelier_board.py appears to be responsible for this configuration, potentially integrating components from the "heavy" build. Investigating whether incorporating "estoc" and "pilot" flags into the build process works.
Examining the codebase, the integration is cleaner than anticipated. The kit and src directories support posing the Estoc and its pilot natively with defined poses and flags. Correction of underlying geometry is the primary step, followed by model addition and pose configuration in existing systems. Adding a wingman uses the built-in system of pose and plume rendering.
Verifying the code, chest_cable in frame_std.py requires adjusting the y-coordinates to prevent penetration. Also, hip_arm coordinates must be modified to prevent protrusion, and pad_shoulder and shoulder_block may be misaligned. Considering updating kit/frame_std.py, kit/lab/knightkit.py, and kit/lab/board_sleek.py.
Observing the Estoc's new pauldrons, noticed the domed design conflicts with existing pad_shoulder, shoulder_pedestal, and pad_hip elements, leading to clipping. These elements need removal from J["shoulder", s] and J["pelvis"] in shoulder_root(P, J) to fix this. Considering the corresponding removal in existing routines. Also, making shoulder_root cover the correct x-coordinates to eliminate any dark block. Reviewing the shield and Estoc lance build in board_sleek.py.
Examining the weapon integration, forearm() in board_sleek.py defines the arm geometry. Considering incorporating the winged shield on the left forearm and removing conflicting elements on the right. Shield positioned at (3.12, -0.15, 10.6), canted -22° with a curved kite/blade shape. Removing existing pad_forearm and pad_post elements from the right forearm to prevent visual conflicts. Designing a central keel ridge with gold trim.
read_file{"Path":"~/work/sortie/kit/props.py"}
input
{ "Path": "~/work/sortie/kit/props.py" }result, 70 lines
Showing lines 1-69 of 69 1: """Weapons and the training drone. 2: 3: Weapons are authored around their grip: the handle runs down from the origin (where a hand's grip.* 4: empty sits) and the barrel points -Y. A "muzzle" empty marks where shots leave. 5: """ 6: from mathutils import Matrix 7: 8: from lib import circle, cylinder, empty, loft, merge, octo, prism, rot, solid, transform, two_view 9: from mech import gltf_dir 10: 11: 12: def build_rifle(): 13: root = empty("rifle", (0, 0, 0), weapon="beam_rifle") 14: solid("handle", transform(loft([(-1.0, octo(.3, .5, .08, y=.05)), (.2, octo(.32, .52, .08, y=.05))]), 15: rot("X", 14)), "frame", root, 0.03) 16: solid("receiver", loft([(1.7, octo(.6, .95, .16, y=.62)), (-2.5, octo(.62, 1.0, .16, y=.62))], axis="y"), 17: "metal", root, 0.05) 18: solid("receiver_top", loft([(1.2, octo(.5, .3, .08, y=1.2)), (-2.2, octo(.5, .3, .08, y=1.2))], axis="y"), 19: "frame", root, 0.03) 20: solid("stock", loft([(1.6, octo(.5, .8, .15, y=.55)), (3.1, octo(.44, 1.05, .15, y=.42))], axis="y"), 21: "frame", root, 0.04) 22: solid("shroud", loft([(-2.4, octo(.52, .6, .14, y=.72)), (-4.7, octo(.46, .52, .12, y=.74))], axis="y"), 23: "metal", root, 0.04) 24: solid("barrel", cylinder(.17, -4.6, -5.7, 10, axis="y", at=(0, .74)), "frame", root, smooth=True) 25: solid("muzzle_ring", cylinder(.26, -5.6, -5.92, 10, axis="y", at=(0, .74)), "accent", root, smooth=True) 26: solid("muzzle_glow", cylinder(.12, -5.93, -5.95, 10, axis="y", at=(0, .74)), "glow_beam", root, outline=False) 27: solid("scope", loft([(-1.25, octo(.34, .4, .08, y=1.48)), (.25, octo(.34, .4, .08, y=1.48))], axis="y"), 28: "frame", root, 0.03) 29: solid("lens", prism(circle(.13, 6, 0, 1.48, phase=0), -1.32, -1.24, "xz"), "glow_eye", root, outline=False) 30: solid("cell", two_view([(-.27, -.6), (.27, -.6), (.27, .25), (-.27, .25)], 31: [(-1.45, -.7), (-.75, -.7), (-.55, .25), (-1.35, .25)]), "accent", root, 0.04) 32: empty("muzzle", (0, -5.96, .74), root, dir=gltf_dir((0, -1, 0))) 33: return root 34: 35: 36: def build_cannon(): 37: root = empty("cannon", (0, 0, 0), weapon="heavy_cannon") 38: solid("handle", transform(loft([(-1.0, octo(.32, .5, .08, y=.05)), (.25, octo(.34, .52, .08, y=.05))]), 39: rot("X", 12)), "frame", root, 0.03) 40: solid("tube", loft([(2.6, circle(.62, 12, 0, 1.0)), (-5.4, circle(.62, 12, 0, 1.0))], axis="y"), 41: "hull_dark", root, smooth=True) 42: solid("tube_band", loft([(-2.0, circle(.7, 12, 0, 1.0)), (-2.6, circle(.7, 12, 0, 1.0))], axis="y"), 43: "trim", root, smooth=True) 44: solid("breech", loft([(1.6, octo(1.45, 1.6, .3, y=1.0)), (3.0, octo(1.3, 1.4, .3, y=1.0))], axis="y"), 45: "main", root, 0.05) 46: solid("muzzle", loft([(-5.3, circle(.82, 12, 0, 1.0)), (-6.1, circle(.78, 12, 0, 1.0))], axis="y"), 47: "frame", root, smooth=True) 48: solid("drum", cylinder(.75, -.35, .35, 12, axis="x", at=(.4, .2)), "accent", root, smooth=True) 49: solid("sight", loft([(-.5, octo(.3, .45, .08, y=1.9)), (.6, octo(.3, .45, .08, y=1.9))], axis="y"), 50: "frame", root, 0.03) 51: empty("muzzle", (0, -6.15, 1.0), root, dir=gltf_dir((0, -1, 0))) 52: return root 53: 54: 55: def build_drone(): 56: root = empty("drone", (0, 0, 0), target="drone") 57: solid("core", loft([(-1.5, octo(.3, .3, .1)), (0, octo(2.2, 2.2, .7)), (1.5, octo(.3, .3, .1))]), 58: "main", root, 0.05) 59: ring = [] 60: for i in range(8): 61: seg = loft([(-.18, octo(1.15, .32, .06, y=-2.5)), (.18, octo(1.15, .32, .06, y=-2.5))]) 62: ring.append(transform(seg, rot("Z", 45 * i))) 63: solid("ring", merge(*ring), "trim", root, 0.03) 64: for i in range(4): 65: fin = prism([(1.1, -.45), (1.1, .5), (3.3, .2), (3.1, -.3)], -.07, .07, "yz") 66: solid(f"fin{i}", transform(fin, rot("Z", 90 * i + 45)), "frame", root, 0.02) 67: solid("eye", prism(circle(.35, 8, 0, 0), -1.25, -1.05, "xz"), "glow_eye", root, outline=False) 68: solid("eye_rim", prism(circle(.5, 8, 0, 0), -1.2, -.8, "xz"), "frame", root, 0.02) 69: return rootread_file{"EndLine":110,"Path":"~/work/sortie/kit/mech.py","StartLine":60}
input
{ "EndLine": 110, "Path": "~/work/sortie/kit/mech.py", "StartLine": 60 }result, 52 lines
Showing lines 60-110 of 400
60:     n = Vector((-d.z, 0, d.x))
61:     return halves(bm, a, n, gap)
62:
63:
64: def pair_pieces(name, pieces, role, jl, jr, **kw):
65:     for i, bm in enumerate(pieces):
66:         pair(f"{name}{i}", bm, role, jl, jr, **kw)
67:
68:
69: def joints():
70:     J = {"frame": empty("frame", (0, 0, 0), frame="striker", height=17.6)}
71:     J["pelvis"] = empty("pelvis", (0, 0, 10.6), J["frame"])
72:     J["waist"] = empty("waist", (0, 0, 11.1), J["pelvis"])
73:     J["torso"] = empty("torso", (0, 0, 11.9), J["waist"])
74:     J["neck"] = empty("neck", (0, 0, 15.3), J["torso"])
75:     J["head"] = empty("head", (0, 0, 15.85), J["neck"])
76:     J["backpack"] = empty("backpack", (0, 1.5, 13.8), J["torso"])
77:     J["cockpit"] = empty("cockpit", (0, -0.75, 13.7), J["torso"])
78:     for s, sx in (("L", 1), ("R", -1)):
79:         J["shoulder", s] = empty(f"shoulder.{s}", (2.0 * sx, 0, 14.6), J["torso"])
80:         J["upperarm", s] = empty(f"upperarm.{s}", (2.45 * sx, 0, 14.4), J["shoulder", s])
81:         J["forearm", s] = empty(f"forearm.{s}", (2.5 * sx, 0, 11.95), J["upperarm", s])
82:         J["hand", s] = empty(f"hand.{s}", (2.5 * sx, 0, 9.6), J["forearm", s])
83:         J["grip", s] = empty(f"grip.{s}", (2.36 * sx, -0.02, 9.12), J["hand", s])
84:         J["thigh", s] = empty(f"thigh.{s}", (1.15 * sx, 0, 10.55), J["pelvis"])
85:         J["shin", s] = empty(f"shin.{s}", (1.2 * sx, 0, 6.1), J["thigh", s])
86:         J["foot", s] = empty(f"foot.{s}", (1.2 * sx, 0.1, 1.55), J["shin", s])
87:         J["binder", s] = empty(f"binder.{s}", (0.9 * sx, 2.25, 14.7), J["backpack"])
88:     return J
89:
90:
91: def lr(J, part):
92:     return J[part, "L"], J[part, "R"]
93:
94:
95: def build_pelvis(J):
96:     P = J["pelvis"]
97:     solid("pelvis_core", loft([(9.95, octo(.9, 1.3, .25)), (10.4, octo(2.2, 1.7, .4)), (11.0, octo(2.3, 1.75, .45))]),
98:           "frame", P, BEVEL)
99:     # the waist belt flares from the abdomen out to hip width; everything below hangs from it
100:     solid("belt", loft([(10.55, octo(3.2, 2.05, .5)), (10.98, octo(2.1, 1.7, .42))]), "main", P, BEVEL)
101:     solid("belt_buckle", two_view([(-.3, 10.58), (.3, 10.58), (.18, 10.96), (-.18, 10.96)],
102:                                   [(-1.14, 10.58), (-.96, 10.58), (-.86, 10.96), (-1.02, 10.96)]), "trim", P, .02)
103:     pair("hip_block", loft([(10.2, octo(.42, .95, .1, x=1.74)), (10.72, octo(.42, .95, .1, x=1.74))]), "frame", P, P, bevel=.02)
104:     solid("codpiece", two_view([(-.2, 9.62), (.2, 9.62), (.32, 10.2), (.3, 10.58), (-.3, 10.58), (-.32, 10.2)],
105:                                [(-1.14, 9.68), (-.75, 9.68), (-.8, 10.58), (-1.08, 10.58), (-1.22, 10.2)]), "trim", P, BEVEL)
106:     # front skirt: two blades sweeping out from the centre like an arrowhead
107:     pair("skirt_front", two_view([(.45, 10.62), (1.45, 10.62), (2.05, 10.3), (1.65, 9.6), (.65, 9.9)],
108:                                  [(-1.34, 9.55), (-1.02, 9.55), (-.94, 10.66), (-1.24, 10.66)]), "main", P, P, bevel=BEVEL)
109:     pair("skirt_front_edge", two_view([(.68, 9.85), (1.64, 9.55), (1.74, 9.71), (.72, 9.99)],
110:                                       [(-1.4, 9.47), (-1.06, 9.47), (-1.02, 10.05), (-1.36, 10.05)]), "accent", P, P, bevel=0.015)
agent
+33:39reasoning
Verifying the relevant files for line numbers and content before proceeding with any edits, specifically focusing on the frame_std.py, knightkit.py, board_sleek.py, atelier_board.py, and build.py files. This is a critical step to ensure accurate modification.
read_file{"EndLine":310,"Path":"~/work/sortie/kit/frame_std.py","StartLine":1}
input
{ "EndLine": 310, "Path": "~/work/sortie/kit/frame_std.py", "StartLine": 1 }result, 311 lines
Showing lines 1-310 of 435
1: """The standard class inner frame (17.6 m), shared by every maker (docs/visual-language.md).
2:
3: Dark roles only: frame for bones and blocks, joint for housings, cables and pistons, metal for the
4: mount pad locks, the cockpit socket rim and the ankle pins, trim for the ring on every mount pad.
5: Joint names and positions are the striker's (mech.joints), so poses, muzzles and harken mounts carry
6: over. bend_knees stands the knees forward and the feet apart after the plates are on. Plates come
7: from a maker family (kit/makers) and ride the same joints.
8:
9: The frame shows at the sides and back of the neck, waist, shoulders, elbows, wrists, knees and ankles
10: under every grade. The foot is a ball ankle in the shin's yoke, an arched sole and a hinged toe.
11: Pistons at the hips, shoulders, elbows, knees and ankles, a cable run down every long bone. The chest
12: carries the cockpit socket in front and the reactor drum behind it, visible through the open sides.
13: Mount pads (one shape, `pad`) at the forearms, shoulders, backpack and hips, each with a mount.* empty.
14:
15: Geometry is authored on the left (+X) in world rest pose coordinates and mirrored.
16: """
17: import math
18:
19: import bpy
20: from mathutils import Matrix, Vector
21:
22: from lib import circle, cylinder, empty, loft, merge, mirror_x, octo, piston, rot, solid, transform, two_view
23: from mech import gltf_dir, joints as striker_joints
24:
25: HEIGHT = 17.6
26: BEVEL = .04
27: PAD = .72  # mount pad edge
28: PAD_T = .08
29: ROOF = 15.13  # the shoulder pad sits on the pauldron roof, the same height for every grade
30:
31:
32: def box(x0, x1, y0, y1, z0, z1):
33:     r = [(x0, y0), (x1, y0), (x1, y1), (x0, y1)]
34:     return loft([(z0, r), (z1, r)])
35:
36:
37: def rod(p0, p1, r, n=6):
38:     """A plain cylinder from p0 to p1."""
39:     p0, p1 = Vector(p0), Vector(p1)
40:     a = p1 - p0
41:     m = Matrix.Translation(p0) @ Vector((0, 0, 1)).rotation_difference(a.normalized()).to_matrix().to_4x4()
42:     return transform(loft([(0, circle(r, n)), (a.length, circle(r, n))]), m)
43:
44:
45: def basis(at, normal, up):
46:     """A matrix whose local +Z is `normal` and local +Y is `up`, placed at `at`."""
47:     z = Vector(normal).normalized()
48:     y = Vector(up)
49:     y = (y - z * y.dot(z)).normalized()
50:     x = y.cross(z)
51:     m = Matrix((x, y, z)).transposed().to_4x4()
52:     m.translation = Vector(at)
53:     return m
54:
55:
56: def joints(tag="frame_std"):
57:     """The striker's 22 joint rig, exact names and positions, tagged with this frame's name."""
58:     J = striker_joints()
59:     J["frame"]["frame"] = tag
60:     J["frame"]["height"] = HEIGHT
61:     return J
62:
63:
64: def lr(J, part):
65:     return J[part, "L"], J[part, "R"]
66:
67:
68: def pair(name, bm_left, role, jl, jr, **kw):
69:     bm_right = mirror_x(bm_left)
70:     return solid(f"{name}.L", bm_left, role, jl, **kw), solid(f"{name}.R", bm_right, role, jr, **kw)
71:
72:
73: def cable(name, pts, parent_l, parent_r=None, r=.055):
74:     """A cable run along a bone, inside a square duct through the points, a clamp at every inner point.
75:     Seen from behind it reads as a covered run, not a loose hose."""
76:     duct = merge(*[rod(a, b, r * 1.6, n=4) for a, b in zip(pts, pts[1:])])
77:     clamps = merge(*[box(p[0] - .1, p[0] + .1, p[1] - .1, p[1] + .1, p[2] - .06, p[2] + .06) for p in pts[1:-1]]) if len(pts) > 2 else None
78:     if parent_r is None:
79:         solid(f"{name}", duct, "frame", parent_l, .01)
80:         if clamps:
81:             solid(f"{name}_clamp", clamps, "joint", parent_l)
82:     else:
83:         pair(name, duct, "frame", parent_l, parent_r, bevel=.01)
84:         if clamps:
85:             pair(f"{name}_clamp", clamps, "joint", parent_l, parent_r)
86:
87:
88: def tube(name, rings, at, parents, collars=(), n=10):
89:     """A long bone: a faceted tube through (height, radius) rings, a joint collar at each height in
90:     `collars`."""
91:     pair(name, loft([(z, circle(r, n, *at)) for z, r in rings]), "frame", *parents, bevel=.03)
92:     radius = lambda z: next(r0 + (r1 - r0) * (z - z0) / (z1 - z0) for (z0, r0), (z1, r1) in zip(rings, rings[1:]) if z0 <= z <= z1)
93:     if collars:
94:         cs = [loft([(z - .08, circle(radius(z) + .06, n, *at)), (z + .08, circle(radius(z) + .06, n, *at))]) for z in collars]
95:         pair(f"{name}_collar", merge(*cs), "joint", *parents, bevel=.015)
96:
97:
98: def pad(name, parent, at, normal, up=(0, 0, 1)):
99:     """The common pattern mount pad: a square plate with clipped corners, four bolt bosses and a lock
100:     ring in the middle. Every maker builds to it, so it always reads the same. `at` is the centre of
101:     the pad's back, `normal` the way it faces. A mount.<name> empty marks the face."""
102:     m = basis(at, normal, up)
103:     h = PAD / 2
104:     plate = loft([(0, octo(PAD, PAD, .12)), (PAD_T, octo(PAD, PAD, .12))])
105:     rim = loft([(PAD_T, octo(PAD * .62, PAD * .62, .06)), (PAD_T + .025, octo(PAD * .62, PAD * .62, .06))])
106:     lock = merge(loft([(PAD_T, circle(.15, 10)), (PAD_T + .07, circle(.15, 10))]),
107:                  loft([(PAD_T + .07, circle(.07, 8)), (PAD_T + .1, circle(.07, 8))]))
108:     k = h - .1
109:     bosses = merge(*[box(x - .045, x + .045, y - .045, y + .045, PAD_T, PAD_T + .05) for x in (-k, k) for y in (-k, k)])
110:     solid(f"pad_{name}", transform(plate, m), "frame", parent, .015)
111:     solid(f"pad_{name}_rim", transform(rim, m), "trim", parent)
112:     solid(f"pad_{name}_lock", transform(lock, m), "metal", parent, .01)
113:     solid(f"pad_{name}_bolts", transform(bosses, m), "joint", parent)
114:     face = Vector(at) + Vector(normal).normalized() * (PAD_T + .1)
115:     empty(f"mount.{name}", face, parent, dir=gltf_dir(normal), size=PAD)
116:
117:
118: def mirror(p):
119:     return (-p[0], p[1], p[2])
120:
121:
122: # Pad sites on the left, mirrored on the right: (joint, centre of the pad back, normal, up).
123: PADS = {
124:     "forearm": ("forearm", (3.08, 0, 10.42), (1, 0, 0), (0, 0, 1)),
125:     "shoulder": ("shoulder", (2.42, .12, ROOF), (0, 0, 1), (0, -1, 0)),
126:     "hip": ("pelvis", (2.04, 0, 10.92), (1, 0, 0), (0, 0, 1)),
127: }
128: BACK_PAD = ((0, 1.56, 13.8), (0, 1, 0), (0, 0, 1))
129:
130:
131: def build_pelvis(J):
132:     P = J["pelvis"]
133:     solid("pelvis_block", loft([(9.85, octo(1.1, .95, .25)), (10.35, octo(1.6, 1.25, .3)), (10.98, octo(1.5, 1.2, .3))]),
134:           "frame", P, BEVEL)
135:     # hip arms reach out over the thighs and carry the holster pads
136:     pair("hip_arm", box(.6, 1.98, -.32, .32, 10.62, 11.04), "frame", P, P, bevel=BEVEL)
137:     pair("hip_arm_web", box(.6, 1.0, -.25, .25, 10.2, 10.62), "frame", P, P, bevel=.02)
138:     pair("hip_socket", cylinder(.5, .55, .8, 12, axis="x", at=(0, 10.55)), "joint", P, P, smooth=True)
139:     for s, sx in (("L", 1), ("R", -1)):
140:         j, at, nm, up = PADS["hip"]
141:         pad(f"hip.{s}", P, (at[0] * sx, at[1], at[2]), (nm[0] * sx, nm[1], nm[2]), up)
142:
143:
144: def build_waist(J):
145:     W = J["waist"]
146:     solid("spine", cylinder(.42, 10.9, 12.1, 12), "joint", W, smooth=True)
147:     for i, z in enumerate((11.15, 11.5, 11.85)):
148:         solid(f"spine_ring{i}", loft([(z - .07, octo(1.15, 1.0, .25)), (z + .07, octo(1.15, 1.0, .25))]), "frame", W, .02)
149:     # two short rams either side of the spine: the waist twists and bends on them
150:     pair("waist_ram", piston((.62, .1, 10.95), (.62, .1, 11.95), r=.1), "joint", W, W, smooth=True)
151:     # the spine housing closes the back of the waist, ribbed so it still reads as the joint
152:     solid("spine_housing", loft([(10.98, octo(.9, .34, .1, y=.56)), (11.98, octo(.9, .34, .1, y=.56))]), "frame", W, .02)
153:     for i, z in enumerate((11.2, 11.48, 11.76)):
154:         solid(f"spine_housing_rib{i}", box(-.5, .5, .7, .78, z - .05, z + .05), "joint", W, .01)
155:
156:
157: def build_torso(J):
158:     T = J["torso"]
159:     solid("chest_base", loft([(11.95, octo(1.6, 1.3, .3)), (12.55, octo(2.5, 1.9, .4))]), "frame", T, BEVEL)
160:     # cockpit block in front, the socket the pod sits in: a metal rim round a recessed hatch
161:     solid("cockpit_block", box(-.88, .88, -1.04, -.15, 12.5, 14.95), "frame", T, BEVEL)
162:     rim = [box(-.66, .66, -1.16, -.98, 14.3, 14.44), box(-.66, .66, -1.16, -.98, 12.98, 13.12),
163:            box(-.66, -.52, -1.16, -.98, 12.98, 14.44), box(.52, .66, -1.16, -.98, 12.98, 14.44)]
164:     solid("socket_rim", merge(*rim), "metal", T, .015)
165:     solid("socket_hatch", box(-.52, .52, -1.08, -1.0, 13.12, 14.3), "joint", T, .01)
166:     solid("socket_seam", box(-.015, .015, -1.1, -1.07, 13.16, 14.26), "frame", T)
167:     # the reactor drum behind the cockpit, seen through the open chest sides
168:     solid("reactor", cylinder(.62, -1.22, 1.22, 14, axis="x", at=(.35, 13.4)), "frame", T, smooth=True)
169:     for x in (-.85, -.3, .3, .85):
170:         solid(f"reactor_band{x:+.1f}", cylinder(.66, x - .06, x + .06, 14, axis="x", at=(.35, 13.4)), "joint", T, smooth=True)
171:     pair("reactor_cap", cylinder(.44, 1.22, 1.27, 14, axis="x", at=(.35, 13.4)), "joint", T, T, smooth=True)
172:     pair("reactor_glow", cylinder(.3, 1.26, 1.29, 14, axis="x", at=(.35, 13.4)), "glow_core", T, T, outline=False)
173:     solid("spine_block", box(-.72, .72, .72, 1.12, 12.45, 14.95), "frame", T, BEVEL)
174:     # back panels either side of the spine block close the torso, the reactor still shows at the sides
175:     pair("back_panel", box(.72, 1.28, .86, 1.0, 12.5, 14.42), "frame", T, T, bevel=.02)
176:     pair("back_panel_rib", box(.8, 1.2, .98, 1.04, 13.3, 13.4), "joint", T, T, bevel=.01)
177:     # side posts tie the base to the shoulder girdle; the reactor shows between them
178:     for y0, y1 in ((-.9, -.62), (.75, 1.02)):
179:         pair(f"rib{y0:+.1f}", box(1.1, 1.32, y0, y1, 12.4, 14.5), "frame", T, T, bevel=.02)
180:     solid("girdle", box(-1.55, 1.55, -.72, .9, 14.42, 15.02), "frame", T, BEVEL)
181:     pair("girdle_cheek", box(1.3, 1.6, -.6, .6, 14.05, 14.42), "frame", T, T, bevel=.02)
182:     solid("neck_base", loft([(15.0, octo(1.2, 1.1, .3)), (15.28, octo(.9, .85, .25))]), "frame", T, .02)
183:     cable("chest_cable", [(1.22, -.95, 12.6), (1.38, -.98, 13.6), (1.42, -.8, 14.4)], T, T)
184:
185:
186: def build_head(J):
187:     N, H = J["neck"], J["head"]
188:     solid("neck_column", cylinder(.3, 15.15, 16.05, 10), "joint", N, smooth=True)
189:     for i, z in enumerate((15.42, 15.7)):
190:         solid(f"neck_ring{i}", loft([(z - .05, octo(.78, .74, .18)), (z + .05, octo(.78, .74, .18))]), "frame", N, .015)
191:     pair("neck_ram", piston((.32, .25, 15.2), (.3, .2, 15.95), r=.06), "joint", N, N, smooth=True)
192:     # the bare head: a sensor block with one lens, the cradle every maker's helmet bolts over
193:     solid("head_core", box(-.4, .4, -.42, .45, 15.95, 16.72), "frame", H, .03)
194:     solid("head_lens_ring", cylinder(.16, -.47, -.42, 12, axis="y", at=(0, 16.4)), "joint", H, smooth=True)
195:     solid("head_lens", cylinder(.11, -.49, -.46, 12, axis="y", at=(0, 16.4)), "glow_eye", H, outline=False)
196:
197:
198: def build_arms(J):
199:     S, UA, FA, HA = lr(J, "shoulder"), lr(J, "upperarm"), lr(J, "forearm"), lr(J, "hand")
200:     pair("shoulder_housing", cylinder(.5, 1.5, 2.15, 14, axis="x", at=(0, 14.6)), "joint", *S, smooth=True)
201:     pair("shoulder_block", box(2.1, 2.85, -.48, .48, 14.15, 15.1), "frame", *S, bevel=BEVEL)
202:     # the shoulder pad sits on a pedestal that flares up to the pad's size, not a post
203:     pair("shoulder_pedestal", loft([(15.0, octo(.56, .5, .1, x=2.42, y=.12)), (ROOF, octo(.68, .64, .14, x=2.42, y=.12))]), "frame", *S,
204:          bevel=.02)
205:     # shoulder rams from the chest corners up to the block, front and back
206:     for k, y in (("f", -.62), ("b", .62)):
207:         pair(f"shoulder_ram_{k}", piston((1.28, y, 13.1), (2.15, y * .8, 14.3), r=.11), "joint", *S, smooth=True)
208:     pair("upperarm_swivel", cylinder(.42, 13.92, 14.32, 12, at=(2.45, 0)), "joint", *UA, smooth=True)
209:     tube("upperarm_bone", [(12.35, .29), (13.95, .33)], (2.45, 0), UA, collars=(12.6, 13.7))
210:     for k, (x0, x1) in (("i", (2.02, 2.16)), ("o", (2.74, 2.88))):
211:         pair(f"elbow_fork_{k}", box(x0, x1, -.36, .36, 11.6, 12.55), "frame", *UA, bevel=.02)
212:     cable("upperarm_cable", [(2.45, .4, 13.95), (2.45, .44, 13.1), (2.45, .4, 12.3)], *UA)
213:     pair("elbow", cylinder(.42, 2.0, 2.9, 14, axis="x", at=(0, 11.95)), "joint", *FA, smooth=True)
214:     tube("forearm_bone", [(9.88, .27), (11.7, .31)], (2.5, 0), FA, collars=(10.0, 11.5))
215:     pair("elbow_ram", piston((2.5, .52, 12.55), (2.5, .42, 10.85), r=.09), "joint", *FA, smooth=True)
216:     pair("pad_post", box(2.74, 3.08, -.2, .2, 10.2, 10.64), "frame", *FA, bevel=.02)
217:     cable("forearm_cable", [(2.18, -.28, 11.6), (2.16, -.3, 10.8), (2.2, -.26, 10.0)], *FA)
218:     for s, sx in (("L", 1), ("R", -1)):
219:         j, at, nm, up = PADS["forearm"]
220:         pad(f"forearm.{s}", J["forearm", s], (at[0] * sx, at[1], at[2]), (nm[0] * sx, nm[1], nm[2]), up)
221:         j, at, nm, up = PADS["shoulder"]
222:         pad(f"shoulder.{s}", J["shoulder", s], (at[0] * sx, at[1], at[2]), nm, up)
223:     # bare hands: the frame's own
224:     pair("wrist", cylinder(.28, 9.42, 9.86, 10, at=(2.5, 0)), "joint", *HA, smooth=True)
225:     pair("palm", loft([(8.9, octo(.5, .82, .1, x=2.52)), (9.5, octo(.46, .8, .1, x=2.52))]), "frame", *HA, bevel=.02)
226:     pair("fingers", loft([(8.75, octo(.42, .82, .13, x=2.27)), (9.35, octo(.44, .82, .13, x=2.27))]), "frame", *HA, bevel=.025)
227:     pair("thumb", loft([(9.02, octo(.24, .24, .06, x=2.32, y=-.5)), (9.4, octo(.26, .26, .06, x=2.38, y=-.46))]), "frame", *HA,
228:          bevel=.02)
229:     pair("knuckles", box(2.62, 2.8, -.36, .36, 9.0, 9.42), "joint", *HA, bevel=.02)
230:
231:
232: def build_legs(J):
233:     TH, SH, FT = lr(J, "thigh"), lr(J, "shin"), lr(J, "foot")
234:     pair("hip_ball", cylinder(.47, .8, 1.55, 12, axis="x", at=(0, 10.55)), "joint", *TH, smooth=True)
235:     tube("thigh_bone", [(6.55, .42), (8.0, .5), (9.3, .54), (10.25, .48)], (1.16, 0), TH, collars=(7.0, 9.75))
236:     for k, (x0, x1) in (("i", (.58, .72)), ("o", (1.68, 1.82))):
237:         pair(f"knee_fork_{k}", box(x0, x1, -.4, .4, 5.75, 6.8), "frame", *TH, bevel=.02)
238:     # hip rams: a long one down the back of the thigh, a short one at the front
239:     pair("hip_ram_b", piston((1.15, .72, 10.45), (1.17, .7, 7.9), r=.13), "joint", *TH, smooth=True)
240:     pair("hip_ram_f", piston((.8, -.68, 10.35), (.9, -.64, 9.15), r=.1), "joint", *TH, smooth=True)
241:     cable("thigh_cable", [(.56, .3, 10.0), (.52, .34, 8.4), (.56, .3, 6.9)], *TH)
242:     pair("knee", cylinder(.47, .7, 1.7, 14, axis="x", at=(0, 6.1)), "joint", *SH, smooth=True)
243:     # slim under the knee, so the shin plate can be narrow there
244:     tube("shin_bone", [(1.95, .36), (3.2, .46), (5.0, .36), (5.75, .42)], (1.2, .05), SH, collars=(2.4,))
245:     pair("knee_ram", piston((1.2, .74, 7.35), (1.2, .8, 5.0), r=.11), "joint", *SH, smooth=True)
246:     pair("ankle_ram", piston((1.2, .66, 3.2), (1.2, .8, 1.85), r=.08), "joint", *SH, smooth=True)
247:     for k, (x0, x1) in (("i", (.7, .82)), ("o", (1.58, 1.7))):
248:         pair(f"ankle_fork_{k}", box(x0, x1, -.26, .26, 1.34, 2.08), "frame", *SH, bevel=.02)
249:     cable("shin_cable", [(.9, .36, 5.5), (.84, .42, 3.8), (.9, .36, 2.3)], *SH)
250:     build_foot(J)
251:
252:
253: # The foot is drawn at one size and then fitted: widened, shortened and turned out a touch about the
254: # ankle. Every foot part, frame and plate, goes through place_foot().
255: TURN = 6.0
256: FOOT_SCALE = (1.06, 1.04)  # across and along
257: ANKLE = (1.2, .1, 1.55)
258:
259:
260: def place_foot(bm):
261:     a = Vector((ANKLE[0], ANKLE[1], 0))
262:     m = Matrix.Diagonal((FOOT_SCALE[0], FOOT_SCALE[1], 1, 1))
263:     return transform(bm, rot("Z", TURN, about=a) @ Matrix.Translation(a) @ m @ Matrix.Translation(-a))
264:
265:
266: def ball(r, at, n=12):
267:     """A faceted sphere."""
268:     rings = [(at[2] + r * math.cos(math.pi * i / 6), circle(max(r * math.sin(math.pi * i / 6), .01), n, at[0], at[1])) for i in range(6, -1, -1)]
269:     return loft(rings)
270:
271:
272: def build_foot(J):
273:     """A foot that carries weight: a ball ankle in the shin's yoke, set in a cup on an A frame
274:     pedestal, a sole with an arch between heel and ball, a toe block on a hinge. Toe longer than heel."""
275:     FT = lr(J, "foot")
276:     x, y, z = ANKLE
277:     pair("ankle", ball(.36, ANKLE), "joint", *FT, smooth=True)
278:     pair("ankle_pin", cylinder(.17, .62, 1.78, 10, axis="x", at=(y, z)), "metal", *FT, smooth=True)
279:     pair("ankle_cup", place_foot(loft([(1.22, octo(.9, .86, .22, x=x, y=y)), (1.36, octo(.78, .76, .2, x=x, y=y))])), "joint", *FT, bevel=.015)
280:     pair("ankle_pedestal", place_foot(two_view([(.84, 1.24), (1.56, 1.24), (1.64, .5), (.76, .5)],
281:                                          [(-.3, 1.24), (.46, 1.24), (.9, .5), (-.8, .5)])), "frame", *FT, bevel=BEVEL)
282:     # the rear foot: heel and arch on one sole, tapered to sit cleanly under pointed sabatons
283:     plan = [(.9, 1.12), (1.5, 1.12), (1.56, .82), (1.52, -1.48), (.88, -1.48), (.84, .82)]
284:     arch = [(-1.48, .28), (-1.48, 0), (-1.1, 0), (-.9, .14), (.3, .14), (.5, 0), (1.04, 0), (1.14, .14), (1.14, .28)]
285:     pair("sole", place_foot(two_view([(.82, 0), (1.58, 0), (1.58, .28), (.82, .28)], arch, plan)), "joint", *FT, bevel=.02)
286:     pair("foot_frame", place_foot(two_view([(.88, .27), (1.52, .27), (1.48, .58), (.92, .58)],
287:                                      [(-1.42, .27), (1.04, .27), (.94, .6), (-1.36, .46)])), "frame", *FT, bevel=BEVEL)
288:     pair("toe_hinge", place_foot(cylinder(.12, .9, 1.5, 10, axis="x", at=(-1.54, .24))), "joint", *FT, smooth=True)
289:     toe_plan = [(.88, -1.58), (1.52, -1.58), (1.44, -2.25), (1.3, -2.72), (1.1, -2.72), (.96, -2.25)]
290:     pair("toe_frame", place_foot(two_view([(.86, .06), (1.54, .06), (1.54, .38), (.86, .38)],
291:                                     [(-1.58, .06), (-2.65, .06), (-2.72, .14), (-2.55, .26), (-1.58, .38)], toe_plan)), "frame", *FT,
292:          bevel=BEVEL)
293:     pair("toe_sole", place_foot(two_view([(.86, 0), (1.54, 0), (1.54, .07), (.86, .07)], [(-1.58, 0), (-2.65, 0), (-2.65, .07), (-1.58, .07)],
294:                                    toe_plan)), "joint", *FT, bevel=.015)
295:     pair("heel_frame", place_foot(box(.9, 1.5, .56, 1.08, .26, .58)), "frame", *FT, bevel=.02)
296:
297:
298: def build_backpack(J):
299:     B = J["backpack"]
300:     solid("back_mount", box(-.86, .86, 1.1, 1.56, 12.9, 14.72), "frame", B, BEVEL)
301:     pad("backpack", B, *BACK_PAD)
302:     for s, sx in (("L", 1), ("R", -1)):
303:         x0, x1 = sorted((.48 * sx, .72 * sx))
304:         solid(f"binder_arm.{s}", box(x0, x1, 1.3, 2.25, 14.58, 14.82), "frame", B, bevel=.02)
305:         solid(f"binder_hinge.{s}", cylinder(.2, .9 * sx - .24, .9 * sx + .24, 12, axis="x", at=(2.25, 14.7)), "joint", J["binder", s],
306:               smooth=True)
307:
308:
309: KNEE_FORWARD = .42  # how far the knees stand forward of the hip to ankle line
310: SPLAY = .4  # how far each foot stands out from under its hip: a slight A stance