A mech game prototype, pushed by Gemini 4 Argon
agent
+9:45reasoning
task-143 is running; will check logs shortly. Reviewing the shoot.mjs script reveals a missing waitUntil: 'domcontentloaded' parameter in the page.goto call, which might be the root cause of the observed slowness. This parameter's omission could explain the performance bottleneck during page loading.
read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log" }result, 2 lines
Showing lines 1-1 of 1
1: striker_a 9919 ms
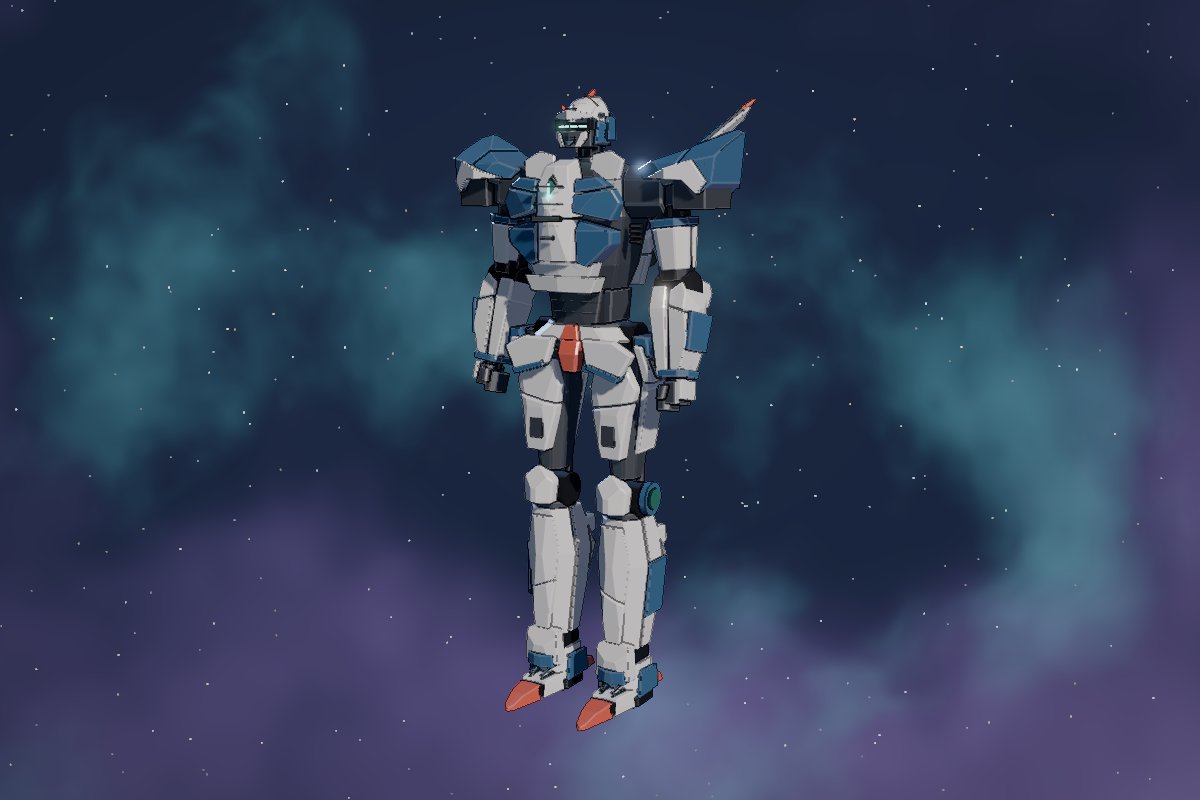
read_file{"Path":"/tmp/inspect/striker_a.png"}
input
{ "Path": "/tmp/inspect/striker_a.png" }result, 1 line
Showing binary file of type image/png
step_147_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log" }result, 4 lines
Showing lines 1-3 of 3
1: striker_a 9919 ms
2: light_lancer 8629 ms
3: heavy_C 9748 ms
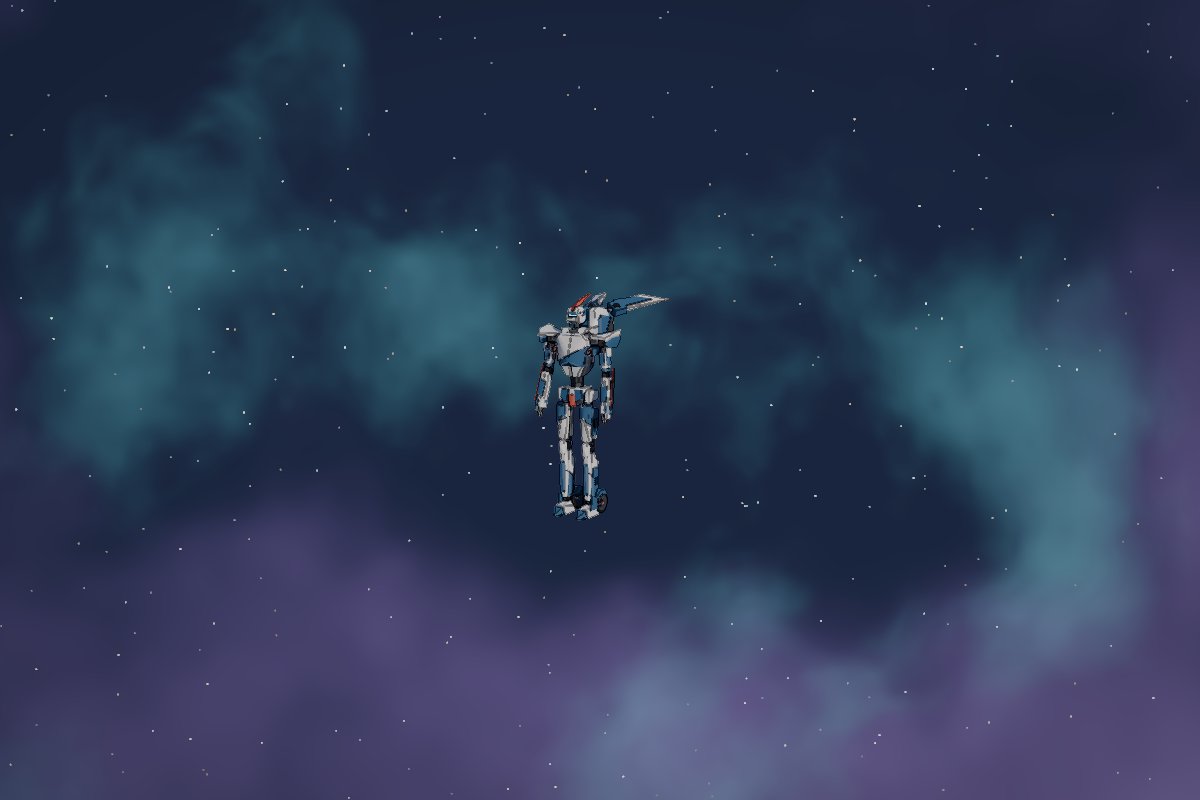
read_file{"Path":"/tmp/inspect/light_lancer.png"}
input
{ "Path": "/tmp/inspect/light_lancer.png" }result, 1 line
Showing binary file of type image/png
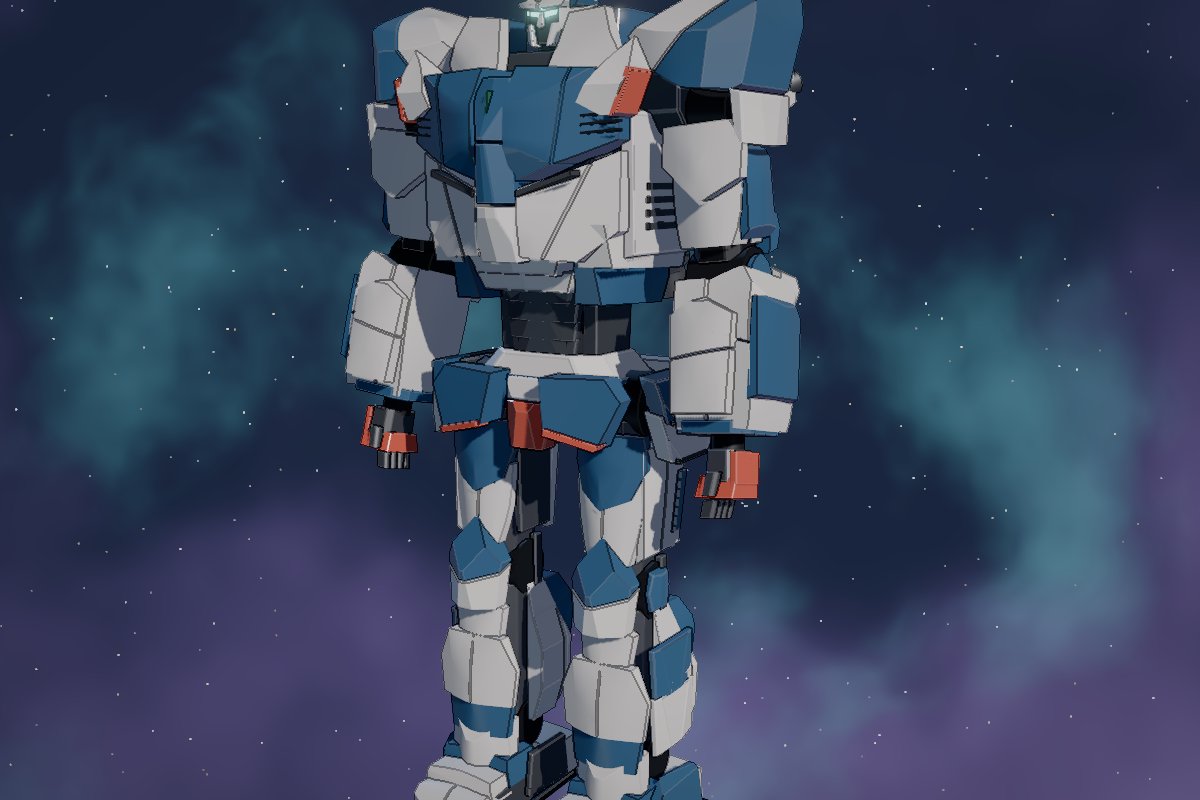
step_151_media_0.jpg read_file{"Path":"/tmp/inspect/heavy_C.png"}
input
{ "Path": "/tmp/inspect/heavy_C.png" }result, 1 line
Showing binary file of type image/png
step_152_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log" }result, 6 lines
Showing lines 1-5 of 5
1: striker_a 9919 ms
2: light_lancer 8629 ms
3: heavy_C 9748 ms
4: pattern_m 8461 ms
5: atelier_a 13378 ms
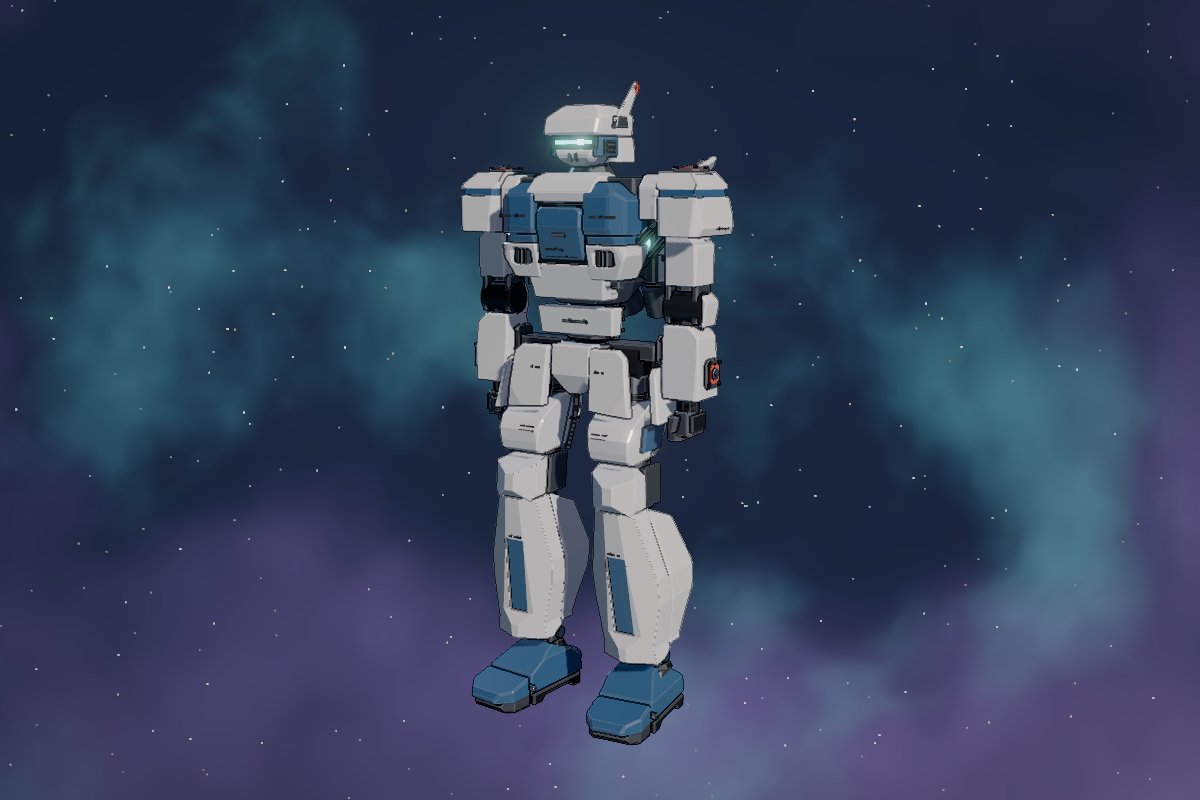
read_file{"Path":"/tmp/inspect/pattern_m.png"}
input
{ "Path": "/tmp/inspect/pattern_m.png" }result, 1 line
Showing binary file of type image/png
step_156_media_0.jpg read_file{"Path":"/tmp/inspect/atelier_a.png"}
input
{ "Path": "/tmp/inspect/atelier_a.png" }result, 1 line
Showing binary file of type image/png
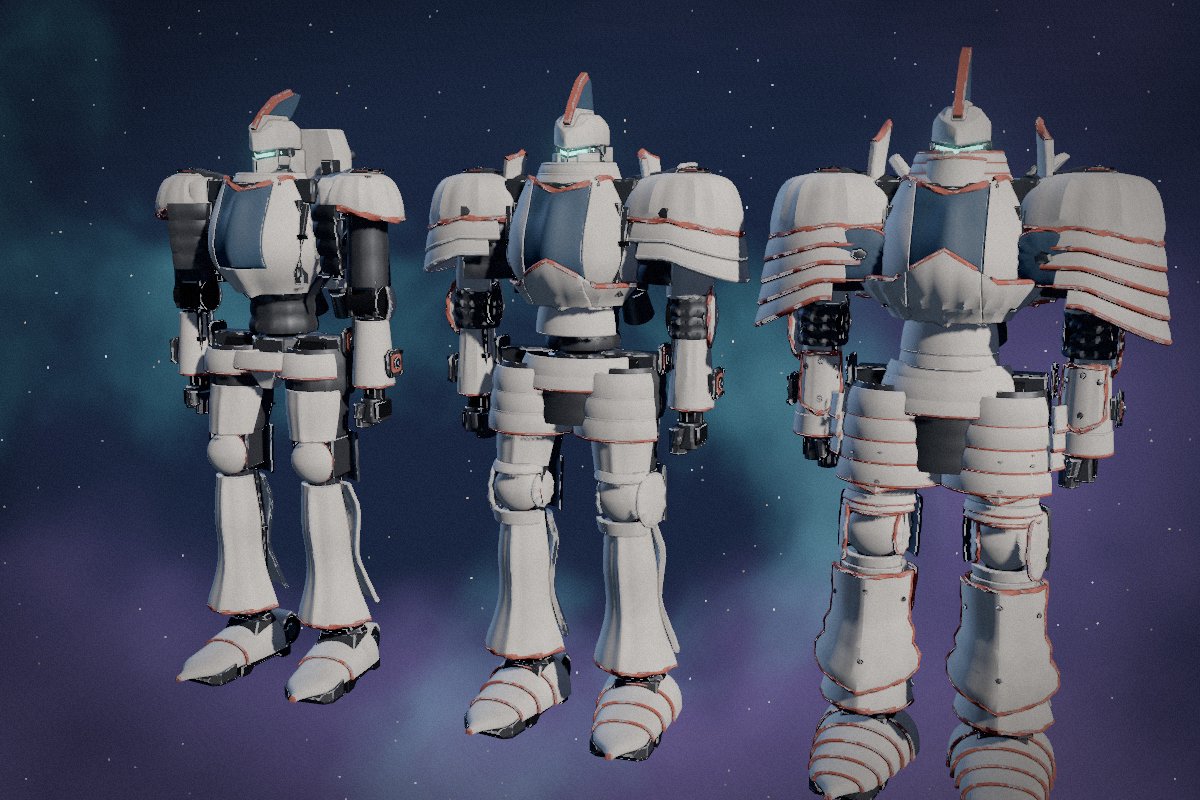
step_157_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log" }result, 7 lines
Showing lines 1-6 of 6
1: striker_a 9919 ms
2: light_lancer 8629 ms
3: heavy_C 9748 ms
4: pattern_m 8461 ms
5: atelier_a 13378 ms
6: atelier_b 10647 ms
read_file{"Path":"/tmp/inspect/atelier_b.png"}
input
{ "Path": "/tmp/inspect/atelier_b.png" }result, 1 line
Showing binary file of type image/png
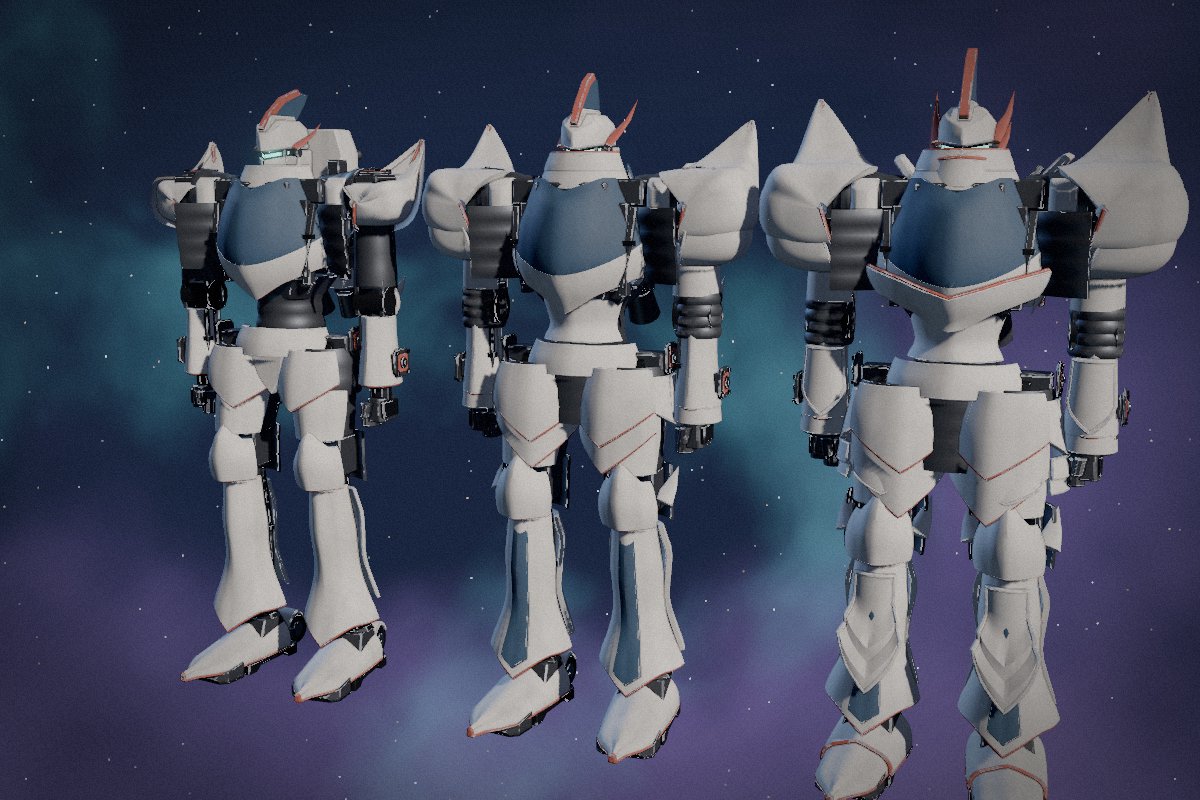
step_161_media_0.jpg read_file{"Path":"/tmp/inspect/atelier_c.png"}
input
{ "Path": "/tmp/inspect/atelier_c.png" }result, 1 line
Showing binary file of type image/png
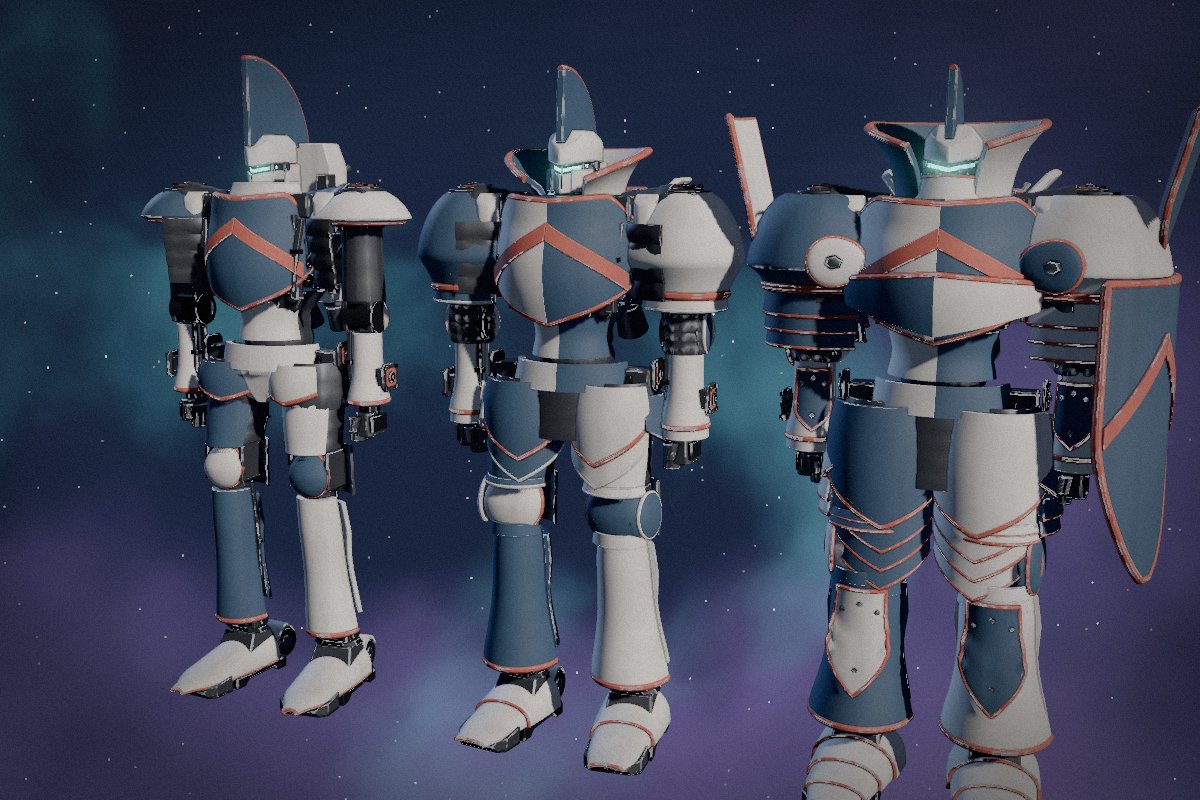
step_163_media_0.jpg read_file{"Path":"/tmp/inspect/atelier_d.png"}
input
{ "Path": "/tmp/inspect/atelier_d.png" }result, 1 line
Showing binary file of type image/png
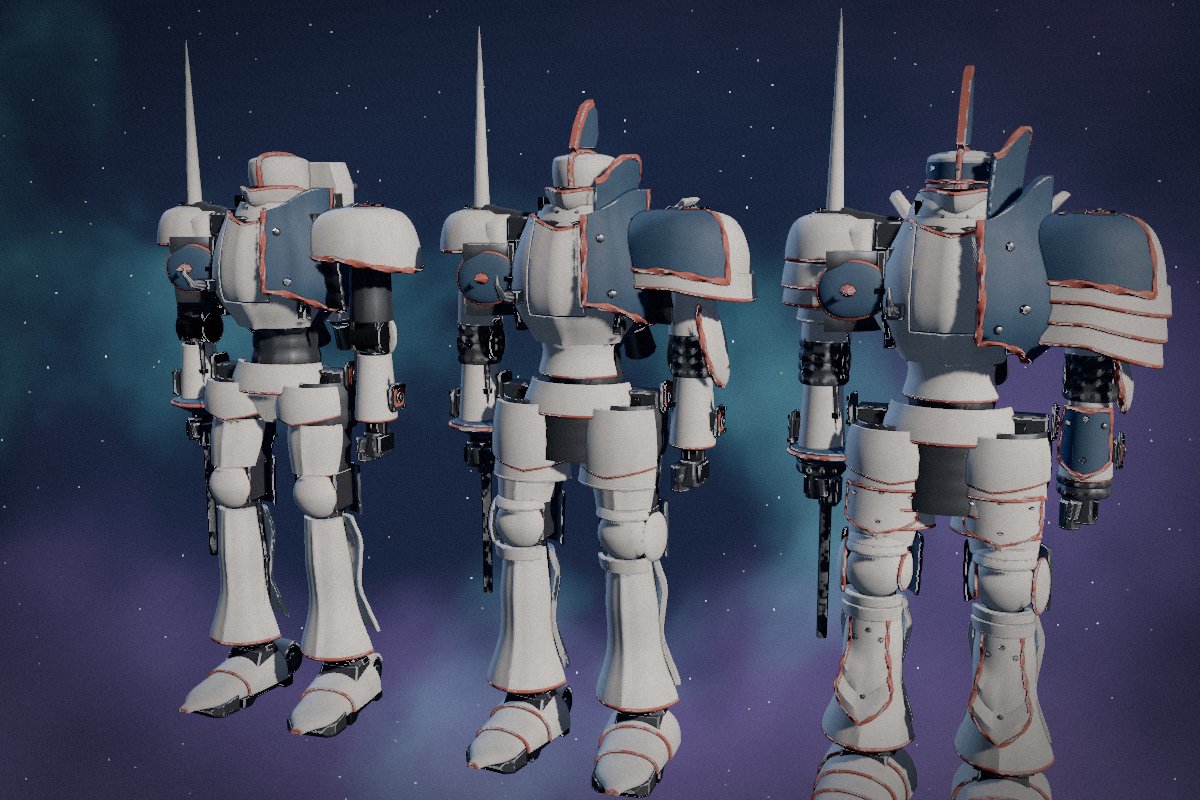
step_164_media_0.jpg resultCommand exited with code 0.
Command exited with code 0.

Command output:
striker_a 9919 ms
light_lancer 8629 ms
heavy_C 9748 ms
pattern_m 8461 ms
atelier_a 13378 ms
atelier_b 10647 ms
atelier_c 11918 ms
atelier_d 11986 ms

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-143.log
agent
+11:10reasoning
Initial observation: A set of images requires review, spanning a project's 15-day history. The aim is to understand the complete project context via visual data. This suggests a potential visual representation of the project's evolution.
The initial hypothesis was that the visual representation was incorrect due to palette and shader parameters. viewer.ts was found to be using incorrect defaults. Specifically, the intended "houses" palette wasn't being used, and the default "field" look introduces unnecessary grime and matte effects. Examining the model geometry reveals the "use_smooth" setting and lack of sharp edges are causing normal smoothing issues and inflating the appearance of sheets.
The visual representation problem stems from the overly simplistic and blocky appearance of the models. The comparison reveals the current approach uses extruded 2D boxes with black gaps and oversized foot elements, confirming the "cleaner, but blander" feedback. The earlier model, built with faceted and beveled elements, offers a crisper, more detailed aesthetic.
The viewer's configuration shows that only the "striker" model receives proper posing and decals, while others are rendered in a static T-pose. Further investigation into the codebase reveals hardcoded conditional logic restricting these features to the "striker" model. This explains the observed lack of detail and dynamic presentation for all other models.
The codebase's conditional logic, specifically within the viewer and sheet components, restricts posing and decal application to only the "striker" model. Despite a shared joint hierarchy designed for pose and animation transfer across all humanoid frames, other models are rendered statically due to this hardcoded constraint, leading to a discrepancy between the intended dynamic representation and the observed static presentation. This also means that pose and decal parameters, such as the flight pose, will not apply to other models.
The small size of light_lancer.png suggests a bounding box issue. The code calculates the camera distance based on the model's bounding box size; a much larger box would explain the tiny image. The model's bounding box calculation needs investigation, as does the image cropping in other cases. The camera's field of view and distance calculation result in very little vertical margin, which explains the clipping of tall models.
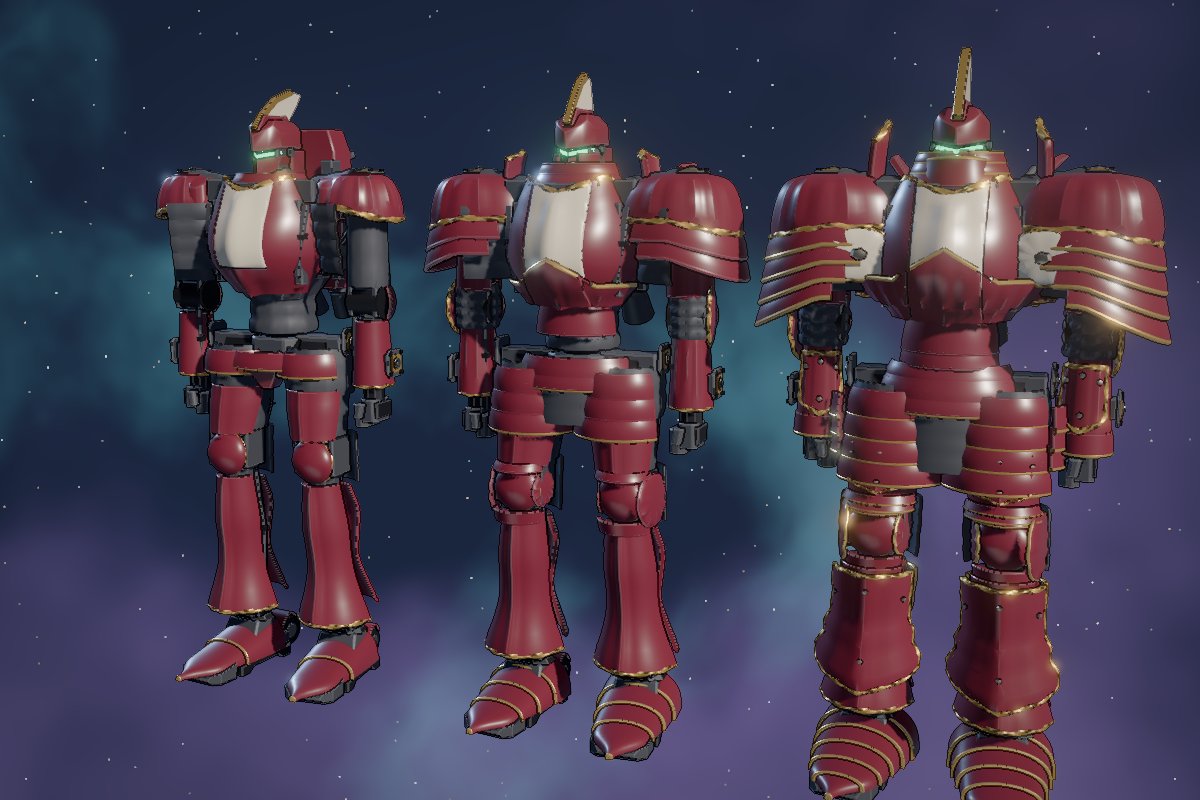
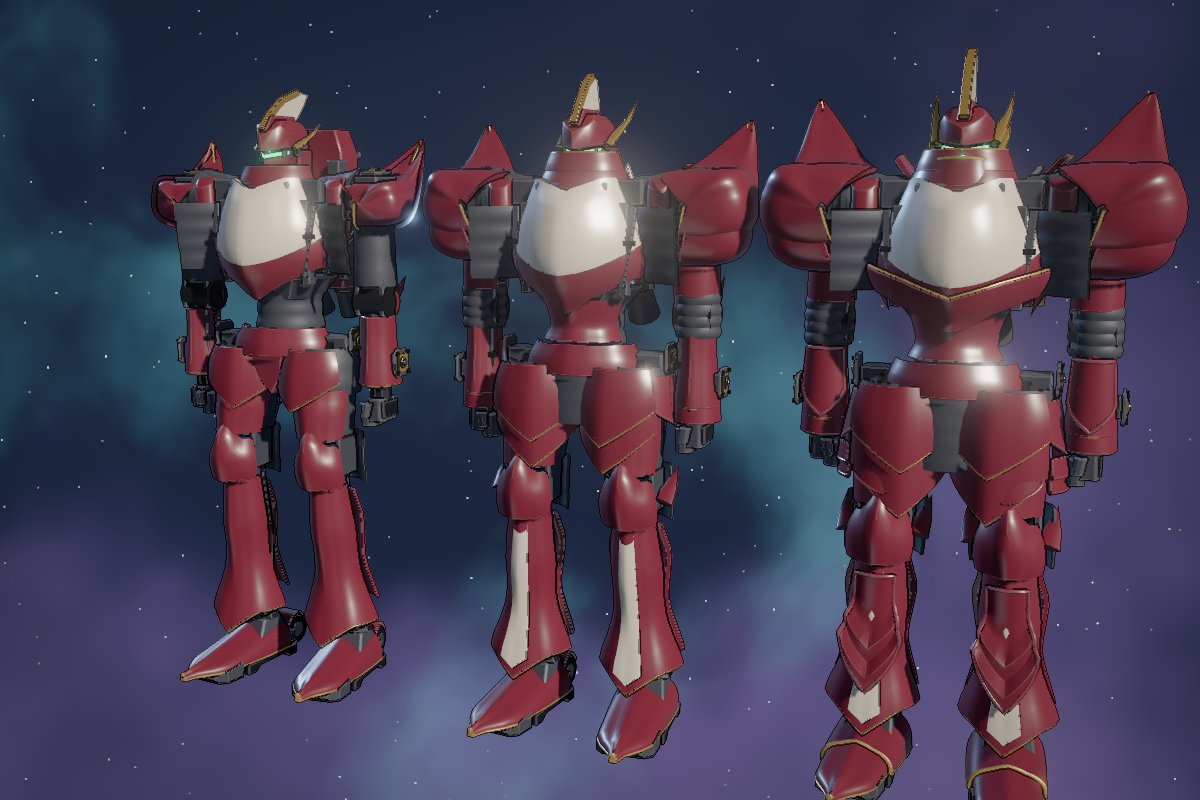
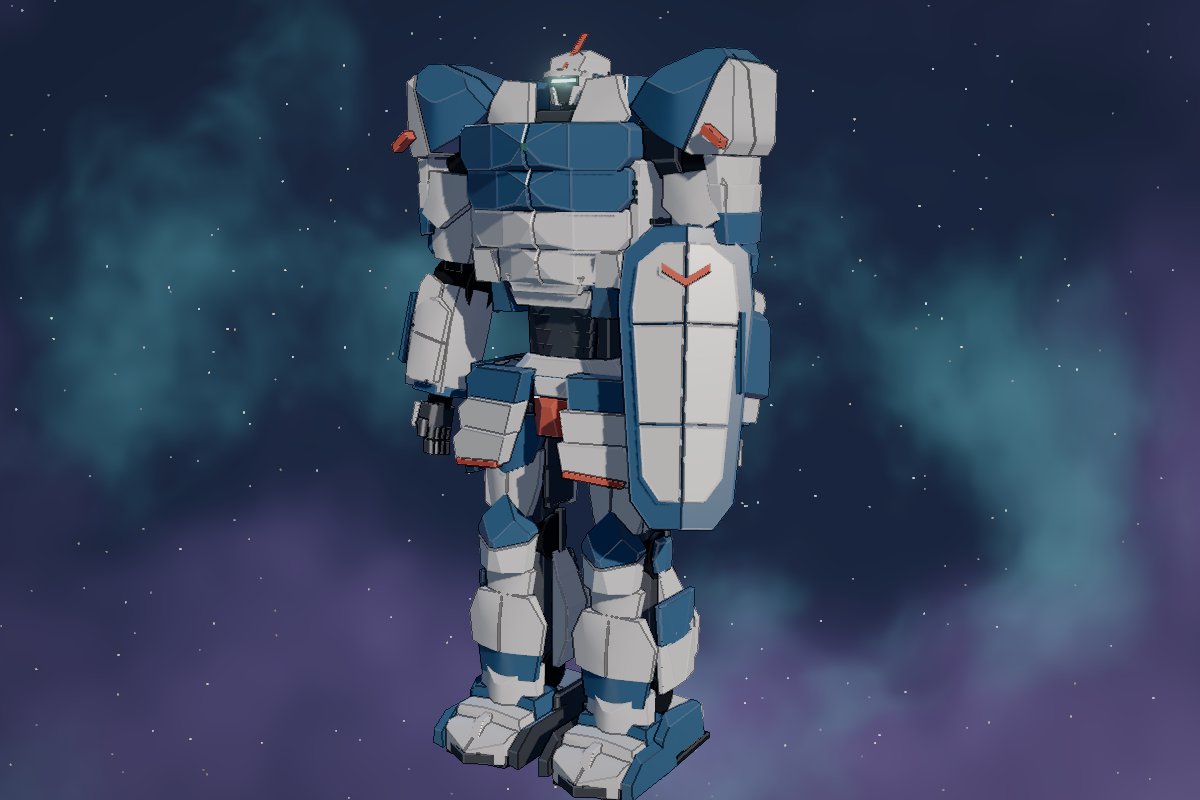
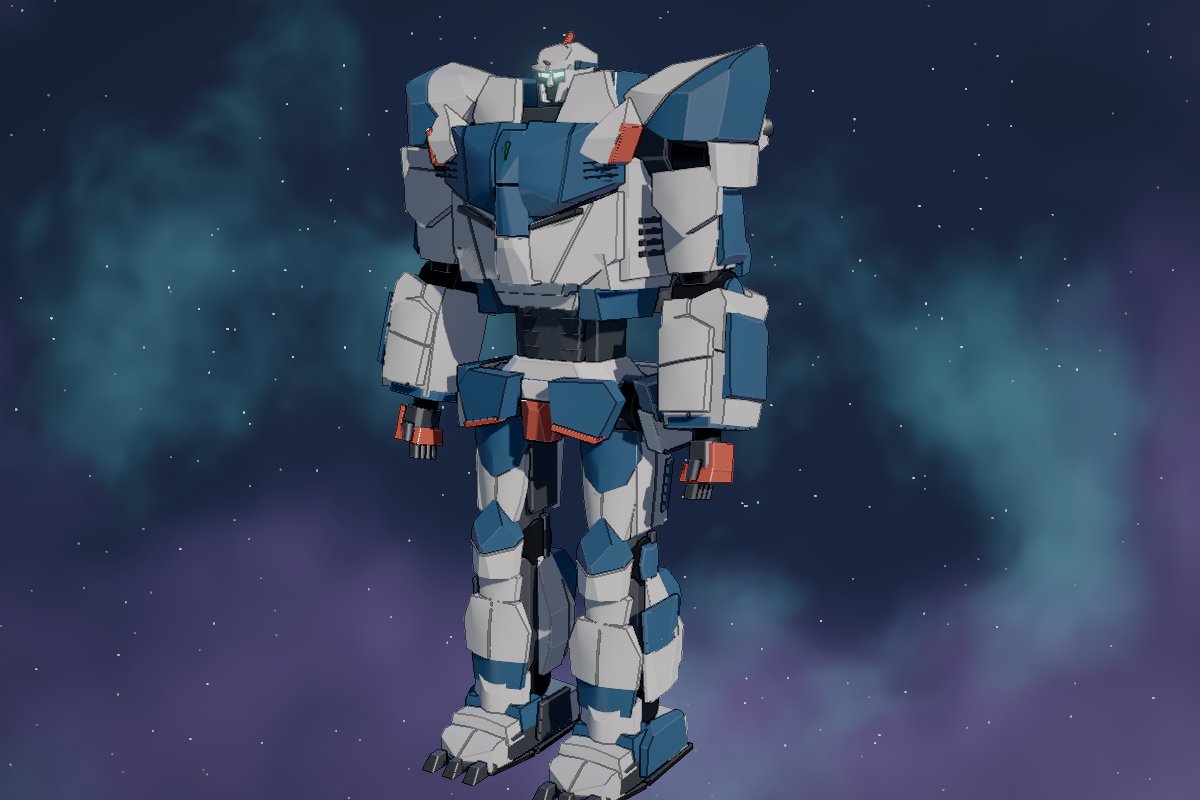
run_command{"CommandLine":"node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst context = await browser.newContext({ viewport: { width: 1200, height: 800 } });\nawait context.addInitScript(\"const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };\");\nconst page = await context.newPage();\nfor (const [name, q] of [\n [\"atelier_a_houses\", \"/?view=lab_atelier_a&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_b_houses\", \"/?view=lab_atelier_b&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1\"],\n [\"heavy_A\", \"/?view=heavy&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1\"],\n [\"heavy_C_wide\", \"/?view=heavy_C&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1\"],\n [\"raider_boss\", \"/?view=raider_boss&palette=raider&look=kit&yaw=32&pitch=10&dist=40&nolabel=1\"],\n [\"thruster_heavy_C\", \"/?view=thrusters&frame=heavy_C&palette=merc&state=assault&t=0.5&yaw=145&pitch=12&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.goto(base + q, { waitUntil: \"domcontentloaded\" });\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\nprocess.exit(0);\n' --input-type=module","WaitMsBeforeAsync":10000,"toolSummary":"Render houses palette and thruster bench test views"}
input
{ "CommandLine": "node -e '\nimport { createServer } from \"vite\";\nimport { chromium } from \"playwright\";\nconst srv = await createServer({ server: { port: 0 }, logLevel: \"error\" });\nawait srv.listen();\nconst base = srv.resolvedUrls.local[0].replace(/\\/$/, \"\");\nconst browser = await chromium.launch({ args: [\"--use-angle=swiftshader\", \"--enable-unsafe-swiftshader\", \"--ignore-gpu-blocklist\"] });\nconst context = await browser.newContext({ viewport: { width: 1200, height: 800 } });\nawait context.addInitScript(\"const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };\");\nconst page = await context.newPage();\nfor (const [name, q] of [\n [\"atelier_a_houses\", \"/?view=lab_atelier_a&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1\"],\n [\"atelier_b_houses\", \"/?view=lab_atelier_b&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1\"],\n [\"heavy_A\", \"/?view=heavy&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1\"],\n [\"heavy_C_wide\", \"/?view=heavy_C&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1\"],\n [\"raider_boss\", \"/?view=raider_boss&palette=raider&look=kit&yaw=32&pitch=10&dist=40&nolabel=1\"],\n [\"thruster_heavy_C\", \"/?view=thrusters&frame=heavy_C&palette=merc&state=assault&t=0.5&yaw=145&pitch=12&nolabel=1\"]\n]) {\n const t0 = Date.now();\n await page.goto(base + q, { waitUntil: \"domcontentloaded\" });\n await page.waitForFunction(\"window.__ready === true\", null, { timeout: 60000 });\n await page.screenshot({ path: `/tmp/inspect/${name}.png` });\n console.log(name, Date.now() - t0, \"ms\");\n}\nawait browser.close();\nawait srv.close();\nprocess.exit(0);\n' --input-type=module", "WaitMsBeforeAsync": 10000, "toolSummary": "Render houses palette and thruster bench test views" }result, 33 lines
Tool is running as a background task with task id: abb0eba5-92ad-4ab4-8738-458f4e606a27/task-167 Task Description: node -e ' import { createServer } from "vite"; import { chromium } from "playwright"; const srv = await createServer({ server: { port: 0 }, logLevel: "error" }); await srv.listen(); const base = srv.resolvedUrls.local[0].replace(/\/$/, ""); const browser = await chromium.launch({ args: ["--use-angle=swiftshader", "--enable-unsafe-swiftshader", "--ignore-gpu-blocklist"] }); const context = await browser.newContext({ viewport: { width: 1200, height: 800 } }); await context.addInitScript("const _raf = window.requestAnimationFrame; window.requestAnimationFrame = (cb) => { if (!window.__ready) return _raf(cb); return 0; };"); const page = await context.newPage(); for (const [name, q] of [ ["atelier_a_houses", "/?view=lab_atelier_a&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1"], ["atelier_b_houses", "/?view=lab_atelier_b&palette=houses&look=kit&yaw=22&pitch=10&nolabel=1"], ["heavy_A", "/?view=heavy&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1"], ["heavy_C_wide", "/?view=heavy_C&palette=merc&look=kit&yaw=32&pitch=10&dist=42&nolabel=1"], ["raider_boss", "/?view=raider_boss&palette=raider&look=kit&yaw=32&pitch=10&dist=40&nolabel=1"], ["thruster_heavy_C", "/?view=thrusters&frame=heavy_C&palette=merc&state=assault&t=0.5&yaw=145&pitch=12&nolabel=1"] ]) { const t0 = Date.now(); await page.goto(base + q, { waitUntil: "domcontentloaded" }); await page.waitForFunction("window.__ready === true", null, { timeout: 60000 }); await page.screenshot({ path: `/tmp/inspect/${name}.png` }); console.log(name, Date.now() - t0, "ms"); } await browser.close(); await srv.close(); process.exit(0); ' --input-type=module Task logs are available at: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn. DO NOTHING ELSE. When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.read_file{"EndLine":950,"Path":"~/work/sortie/kit/light.py","StartLine":800}
input
{ "EndLine": 950, "Path": "~/work/sortie/kit/light.py", "StartLine": 800 }result, 110 lines
Showing lines 800-908 of 908
800:         _bpy.context.view_layer.update()
801:     for o in meshes:
802:         inv = o.matrix_world.inverted()
803:         W = before[o.name]
804:         for vtx in o.data.vertices:
805:             vtx.co = inv @ f(W @ vtx.co)
806:         o.data.update()
807:
808:
809: def proportion(J, v):
810:     """Give each variant its own build on the shared skeleton: the grunt broad and waisty with short
811:     shins and its helm sunk into the collar, the lancer slim and long-shinned."""
812:     k = SHAPE[v]
813:     frame = J["frame"]
814:     lo, hi = .4, 1.78  # ankle to knee
815:     if k["shin"] != 1.0:
816:         d = (k["shin"] - 1) * (hi - lo)
817:
818:         def zmap(p, d=d):
819:             p = p.copy()
820:             if p.z >= hi:
821:                 p.z += d
822:             elif p.z > lo:
823:                 p.z = lo + (p.z - lo) * k["shin"]
824:             return p
825:         remap(_tree(frame)[1:], zmap)
826:     for s, sx in (("L", 1), ("R", -1)):
827:         for part, dx in (("shoulder", k["sho"]), ("thigh", k["hip"])):
828:             if dx:
829:                 remap(_tree(J[part, s]), lambda p, dx=dx * sx: p + Vector((dx, 0, 0)))
830:         for part in ("upperarm", "forearm", "thigh", "shin"):
831:             f = k["thigh"] if part == "thigh" else k["limb"]
832:             if f != 1.0:
833:                 j = J[part, s]
834:                 c = j.matrix_world.translation.copy()
835:                 remap([o for o in j.children if o.type == "MESH"],
836:                       lambda p, c=c, f=f: Vector((c.x + (p.x - c.x) * f, c.y + (p.y - c.y) * f, p.z)))
837:         # the pauldrons grow outward from the shoulder joint so the arm hangs under them
838:         j = J["shoulder", s]
839:         c = j.matrix_world.translation.copy()
840:         shells = [o for o in j.children if o.type == "MESH" and not any(t in o.name for t in ("shoulder_block", "trunnion"))]
841:         remap(shells, lambda p, c=c: Vector((c.x + (p.x - c.x) * k["pd"], c.y + (p.y - c.y) * 1.06, c.z + (p.z - c.z) * 1.04)))
842:     if k["waist"] != 1.0:
843:         mid = [o for jn in ("pelvis", "waist") for o in J[jn].children if o.type == "MESH"]
844:         remap(mid, lambda p: Vector((p.x * k["waist"], p.y, p.z)))
845:     if k["head"]:
846:         remap(_tree(J["neck"]), lambda p: p + Vector((0, 0, k["head"])))
847:
848:
849: # ---- frames -------------------------------------------------------------------------------------------------
850: VARIANTS = ("knight", "line", "lancer")
851:
852:
853: def build_light(variant="knight", n=None, shutters_open=False):
854:     n = n or variant[0]
855:     SWAP.clear()
856:     if variant == "line":
857:         SWAP.update(main="accent", accent="main")
858:     J = joints(variant)
859:     inner(J, n)
860:     core_block(J, n, variant)
861:     {"knight": chest_knight, "line": chest_line, "lancer": chest_lancer}[variant](J, n)
862:     if variant == "knight":
863:         head_knight(J, n)
864:     elif variant == "line":
865:         head_line(J, n, shutters_open)
866:     else:
867:         head_lancer(J, n)
868:     # lumbar plates close the lower back under the block
869:     lumbar = sc([(.02, 3.84), (.2, 3.84), (.38, 4.1), (.42, 4.4), (.02, 4.4)], [(.12, 3.84), (.3, 3.84), (.38, 4.4), (.18, 4.4)],
870:                 top=[(.02, .12), (.44, .12), (.44, .28), (.2, .4), (.02, .42)], sharp=34)
871:     for i, p in enumerate(split(lumbar, [((0, 0, 4.12), (0, 0, 1))], gap=.025)):
872:         two(f"{n}_lumbar{i}", p, "main" if centre(p).z > 4.12 else "accent", J["torso"], J["torso"])
873:     pelvis(J, n, variant)
874:     arms(J, n, variant)
875:     legs(J, n, variant)
876:     float_pack(J, n, variant)
877:     harken(J, n, (min(CORE[variant]["w"] / 2 + .07, .62), -.22, 4.5), {"knight": "accent", "line": "main", "lancer": "accent"}[variant])
878:     stretch_arms(J, 1.08)
879:     proportion(J, variant)
880:     SWAP.clear()
881:     return J["frame"]
882:
883:
884:
885:
886: LAB = [("knight", "A: knight, the lead frame", False), ("line", "B: line, the grunt, factsphere open", True),
887:        ("lancer", "C: lancer, fast assault", False), ("line", "D: line, factsphere shut", False)]
888:
889:
890: def build_light_lab():
891:     """The light frames side by side, 5 m apart, a 1.75 m pilot beside slot 0. LIGHT_ONLY=0,2 builds a
892:     subset in place (for iterating on one frame)."""
893:     import os
894:     only = os.environ.get("LIGHT_ONLY")
895:     keep = {int(i) for i in only.split(",")} if only else None
896:     root = empty("lab", (0, 0, 0))
897:     for i, (v, label, shut) in enumerate(LAB):
898:         if keep is not None and i not in keep:
899:             continue
900:         slot = empty(f"slot{i}", (i * 5.0, 0, 0), root, label=label)
901:         frame = build_light(v, f"{v[0]}{i}", shut)
902:         attach(frame, slot)
903:         frame.matrix_parent_inverse = Matrix.Identity(4)
904:         frame.location = (0, 0, 0)
905:         bpy.context.view_layer.update()
906:         if i == 0:
907:             pilot(slot, at=(-1.35, -.4))
908:     return root
agent
+12:13reasoning
Initial assumption was that the max function was using the height of the light_lancer model, however, this model is 6m tall. The max function includes 6 as a possible option. It's likely that 6 is being used instead of the calculated maximum of the other two sizes.
The viewer.ts file's line 154 calculates distance based on model dimensions, with a hardcoded 6 as a potential maximum. Investigating why 'light_lancer' appeared small suggests checking its dimensions in the python script. Dimensions of light_lancer from kit/light.py will determine how this hardcoded 6 is affecting the dist calculation.
read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log" }result, 3 lines
Showing lines 1-2 of 2
1: atelier_a_houses 12775 ms
2: atelier_b_houses 11269 ms
read_file{"Path":"/tmp/inspect/atelier_a_houses.png"}
input
{ "Path": "/tmp/inspect/atelier_a_houses.png" }result, 1 line
Showing binary file of type image/png
step_173_media_0.jpg read_file{"Path":"/tmp/inspect/atelier_b_houses.png"}
input
{ "Path": "/tmp/inspect/atelier_b_houses.png" }result, 1 line
Showing binary file of type image/png
step_174_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log" }result, 6 lines
Showing lines 1-5 of 5
1: atelier_a_houses 12775 ms
2: atelier_b_houses 11269 ms
3: heavy_A 7622 ms
4: heavy_C_wide 7366 ms
5: raider_boss 7949 ms
read_file{"Path":"/tmp/inspect/heavy_A.png"}
input
{ "Path": "/tmp/inspect/heavy_A.png" }result, 1 line
Showing binary file of type image/png
step_178_media_0.jpg read_file{"Path":"/tmp/inspect/heavy_C_wide.png"}
input
{ "Path": "/tmp/inspect/heavy_C_wide.png" }result, 1 line
Showing binary file of type image/png
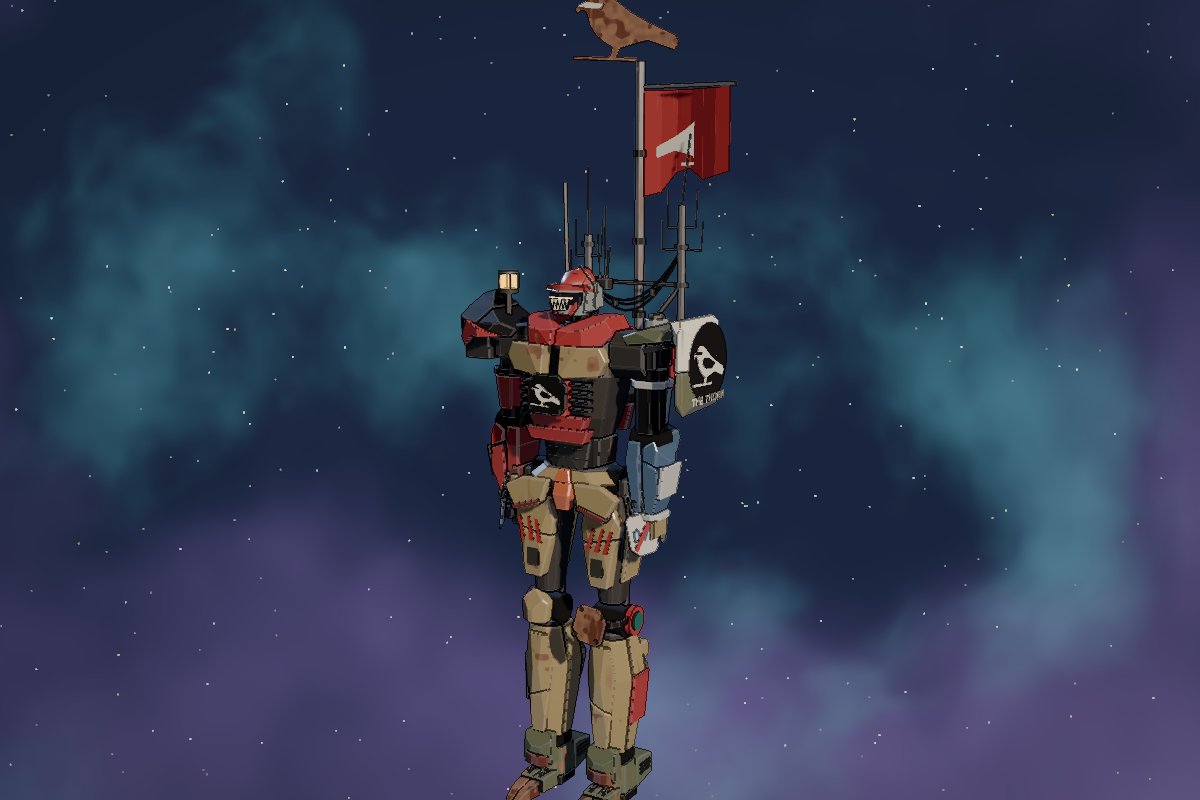
step_179_media_0.jpg read_file{"Path":"/tmp/inspect/raider_boss.png"}
input
{ "Path": "/tmp/inspect/raider_boss.png" }result, 1 line
Showing binary file of type image/png
step_180_media_0.jpg resultCommand exited with code 0.
Command exited with code 0.

Command output:
atelier_a_houses 12775 ms
atelier_b_houses 11269 ms
heavy_A 7622 ms
heavy_C_wide 7366 ms
raider_boss 7949 ms
thruster_heavy_C 8175 ms

Log: file://~/.gemini/antigravity-cli/brain/abb0eba5-92ad-4ab4-8738-458f4e606a27/.system_generated/tasks/task-167.log
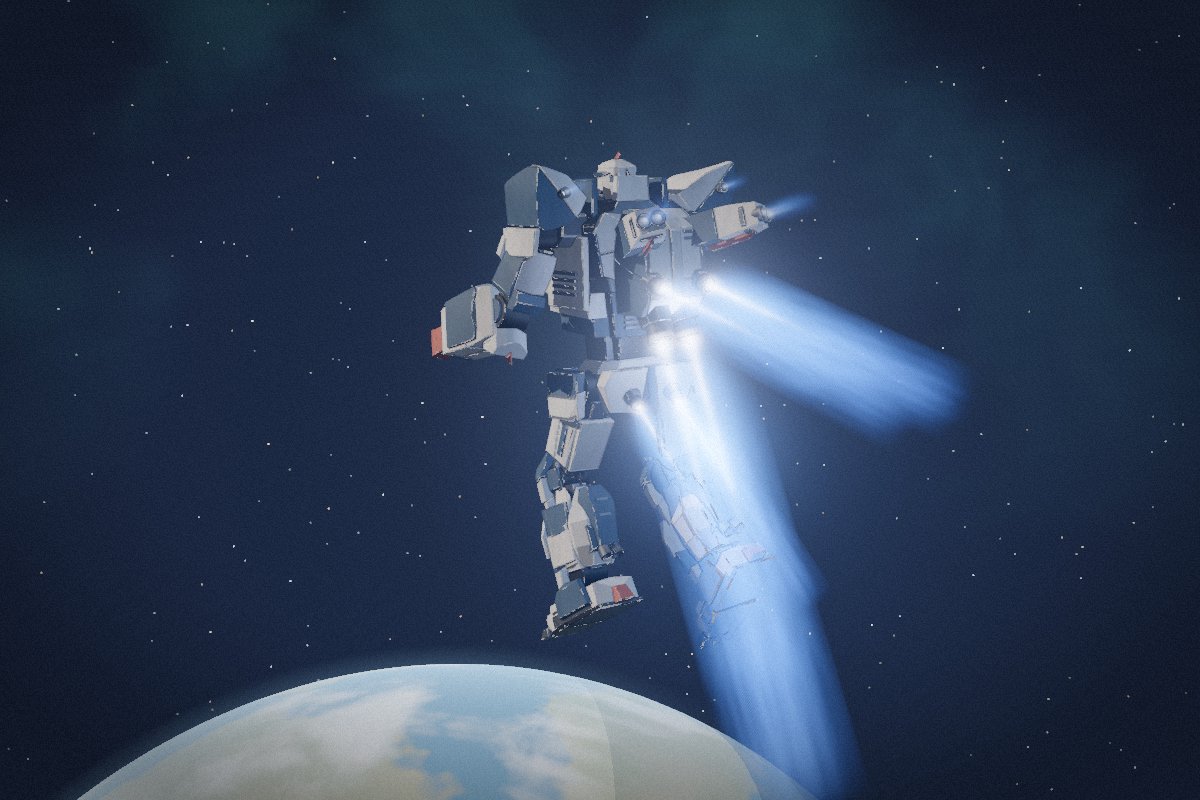
read_file{"Path":"/tmp/inspect/thruster_heavy_C.png"}
input
{ "Path": "/tmp/inspect/thruster_heavy_C.png" }result, 1 line
Showing binary file of type image/png
step_183_media_0.jpg