A mech game prototype, pushed by Gemini 4 Carbon
agent
+1:03:15reasoning
feed(...) appears to be modifying root.position and root2.position, which are then immediately overwritten. This explains why the visual elements are not updating as expected. The rendering logic needs to be reordered to update positions after feed(...) has completed its work on the visual data.
read_file{"EndLine":160,"Path":"~/work/sortie/src/render/mech.ts","StartLine":1}
input
{ "EndLine": 160, "Path": "~/work/sortie/src/render/mech.ts", "StartLine": 1 }result, 161 lines
Showing lines 1-160 of 209 1: import * as THREE from 'three'; 2: import { find, nodes } from './assets'; 3: import { Exhaust, KINDS, type NozzleKind, type ThrustReading } from './exhaust'; 4: import { PALETTES, type PaletteName } from './palette'; 5: import { PLUME_HULL, plumeMaterial, plumeVisible, setPlume } from './plume'; 6: 7: /** Joint rotations in degrees, glTF axes: X pitches a limb (negative swings it forward), Z swings it 8: * sideways (positive moves a left limb outward), Y twists. */ 9: export type Pose = Partial<Record<Joint, [number, number, number]>>; 10: 11: export const JOINTS = [ 12: 'pelvis', 'waist', 'torso', 'neck', 'head', 'backpack', 13: 'shoulder.L', 'upperarm.L', 'forearm.L', 'hand.L', 'shoulder.R', 'upperarm.R', 'forearm.R', 'hand.R', 14: 'thigh.L', 'shin.L', 'foot.L', 'thigh.R', 'shin.R', 'foot.R', 'binder.L', 'binder.R', 15: ] as const; 16: export type Joint = (typeof JOINTS)[number]; 17: 18: export const POSES = { 19: stand: { 20: 'upperarm.L': [0, 0, 6], 'upperarm.R': [0, 0, -6], 'forearm.L': [-12, 0, 0], 'forearm.R': [-12, 0, 0], 21: }, 22: /** Standing on the catapult: knees bent, leaning into the launch. */ 23: launch: { 24: pelvis: [8, 0, 0], torso: [10, 0, 0], head: [-14, 0, 0], 25: 'thigh.L': [-38, 0, 2], 'thigh.R': [-38, 0, -2], 'shin.L': [58, 0, 0], 'shin.R': [58, 0, 0], 26: 'foot.L': [-20, 0, 0], 'foot.R': [-20, 0, 0], 27: 'upperarm.L': [-18, 0, 14], 'forearm.L': [-40, 0, 0], 'upperarm.R': [-30, 0, -8], 'forearm.R': [-50, 0, 0], 28: 'binder.L': [18, 0, 0], 'binder.R': [18, 0, 0], 29: }, 30: /** The launch crouch for a heavy: 24 m in a 26 m tube, so knees deep, head down and binders folded, 31: * which brings it under the tube's signal box. */ 32: launch_heavy: { 33: pelvis: [12, 0, 0], torso: [12, 0, 0], head: [-20, 0, 0], 34: 'thigh.L': [-58, 0, 3], 'thigh.R': [-58, 0, -3], 'shin.L': [106, 0, 0], 'shin.R': [106, 0, 0], 35: 'foot.L': [-48, 0, 0], 'foot.R': [-48, 0, 0], 36: 'upperarm.L': [-18, 0, 14], 'forearm.L': [-40, 0, 0], 'upperarm.R': [-30, 0, -8], 'forearm.R': [-50, 0, 0], 37: 'binder.L': [40, 0, 0], 'binder.R': [40, 0, 0], 38: }, 39: /** Free flight, rifle up. */ 40: flight: { 41: pelvis: [6, 0, 0], torso: [-4, 0, 0], head: [-2, 0, 0], 42: 'thigh.L': [-22, 0, 4], 'thigh.R': [6, 0, -3], 'shin.L': [42, 0, 0], 'shin.R': [30, 0, 0], 43: 'foot.L': [8, 0, 0], 'foot.R': [18, 0, 0], 44: 'upperarm.L': [-22, 0, 16], 'forearm.L': [-46, 0, 0], 45: 'upperarm.R': [-62, -8, -6], 'forearm.R': [-26, 0, 0], 'hand.R': [0, 0, 0], 46: 'binder.L': [-6, 0, 0], 'binder.R': [-6, 0, 0], 47: }, 48: } satisfies Record<string, Pose>; 49: export type PoseName = keyof typeof POSES; 50: 51: /** The catapult pose for a size class: the striker's, with a deeper crouch for heavies. */ 52: export const launchPose = (cls: string): Pose => (cls === 'heavy' ? POSES.launch_heavy : POSES.launch); 53: 54: export interface Nozzle { 55: node: THREE.Object3D; 56: dir: THREE.Vector3; // exhaust direction in the node's parent space 57: radius: number; 58: kind: NozzleKind; 59: plume: THREE.Mesh; 60: } 61: 62: const tmpQ = new THREE.Quaternion(); 63: const _sum = new THREE.Vector3(); 64: const _at = new THREE.Vector3(); 65: const _white = new THREE.Color(1, 1, 1); 66: const tmpE = new THREE.Euler(); 67: const D = THREE.MathUtils.DEG2RAD; 68: 69: /** A frame model's joints, posed by rotation, with weapons held at grip.R and thruster plumes. */ 70: export class MechRig { 71: readonly joints = new Map<Joint, THREE.Object3D>(); 72: readonly nozzles: Nozzle[] = []; 73: readonly cockpit: THREE.Object3D; 74: readonly grip: THREE.Object3D; 75: held: THREE.Object3D | null = null; 76: /** Plume state, stepped by thrust(). */ 77: readonly exhaust = new Exhaust(); 78: /** One plume material per nozzle kind: a kind fires together. */ 79: private plumeMats: Record<NozzleKind, THREE.ShaderMaterial>; 80: private exhaustColor: THREE.Color; 81: private targets = new Map<Joint, THREE.Quaternion>(); 82: 83: constructor(readonly root: THREE.Object3D) { 84: const map = nodes(root); 85: for (const j of JOINTS) { 86: const n = find(map, j); 87: if (n) this.joints.set(j, n); 88: } 89: this.cockpit = find(map, 'cockpit') ?? root; 90: this.grip = find(map, 'grip.R') ?? root; 91: const paint = PALETTES[(root.userData.palette as PaletteName | undefined) ?? 'merc'].glow_exhaust; 92: this.exhaustColor = new THREE.Color(paint.color); 93: this.plumeMats = { 94: main: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 0), 95: binder: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 17.3), 96: calf: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 41.7), 97: }; 98: root.traverse((o) => { 99: const dir = o.userData.dir as number[] | undefined; 100: if (!dir || !/^nozzle/.test(o.name)) return; 101: const kind: NozzleKind = /main/.test(o.name) ? 'main' : /binder/.test(o.name) ? 'binder' : 'calf'; 102: const radius = (o.userData.radius as number) ?? 0.5; 103: // the plume's own space is in nozzle radii (render/plume.ts) 104: const plume = new THREE.Mesh(PLUME_HULL, this.plumeMats[kind]); 105: const d = new THREE.Vector3(...(dir as [number, number, number])); 106: plume.quaternion.setFromUnitVectors(new THREE.Vector3(0, 0, 1), d); 107: plume.scale.setScalar(radius); 108: plume.visible = false; 109: plume.renderOrder = 2; 110: o.add(plume); 111: this.nozzles.push({ node: o, dir: d, radius, kind, plume }); 112: }); 113: } 114: 115: /** Any named node of the model (extras like harken.L), or null. */ 116: node(name: string): THREE.Object3D | null { 117: return find(nodes(this.root), name) ?? null; 118: } 119: 120: /** Snap to a pose. */ 121: apply(pose: Pose) { 122: for (const [j, node] of this.joints) { 123: const r = pose[j] ?? [0, 0, 0]; 124: node.quaternion.setFromEuler(tmpE.set(r[0] * D, r[1] * D, r[2] * D)); 125: } 126: } 127: 128: /** Snap to a pose and measure how high its soles sit above the root, in world metres (root 129: * upright). A crouch lifts the feet, so the frame drops by this much to stand on its clamps. */ 130: soles(pose: Pose): number { 131: this.apply(pose); 132: this.root.updateMatrixWorld(true); 133: const v = new THREE.Vector3(); 134: let min = Infinity; 135: for (const j of ['foot.L', 'foot.R'] as const) { 136: this.joints.get(j)?.traverse((o) => { 137: const p = (o as THREE.Mesh).isMesh ? (o as THREE.Mesh).geometry.attributes.position : null; 138: if (!p) return; 139: for (let i = 0; i < p.count; i++) min = Math.min(min, v.fromBufferAttribute(p, i).applyMatrix4(o.matrixWorld).y); 140: }); 141: } 142: return Number.isFinite(min) ? min - this.root.getWorldPosition(v).y : 0; 143: } 144: 145: /** Ease toward a blend of poses; weights need not sum to 1 (the rest is the rest pose). */ 146: blend(poses: [Pose, number][], rate: number, dt: number) { 147: const k = 1 - Math.exp(-rate * dt); 148: for (const [j, node] of this.joints) { 149: let x = 0, y = 0, z = 0; 150: for (const [p, w] of poses) { 151: const r = p[j]; 152: if (r) { 153: x += r[0] * w; 154: y += r[1] * w; 155: z += r[2] * w; 156: } 157: } 158: let t = this.targets.get(j); 159: if (!t) this.targets.set(j, (t = new THREE.Quaternion())); 160: t.setFromEuler(tmpE.set(x * D, y * D, z * D));read_file{"EndLine":209,"Path":"~/work/sortie/src/render/mech.ts","StartLine":161}
input
{ "EndLine": 209, "Path": "~/work/sortie/src/render/mech.ts", "StartLine": 161 }result, 50 lines
Showing lines 161-209 of 209
161:       node.quaternion.slerp(t, k);
162:     }
163:   }
164:
165:   /** Turn one joint by an extra rotation on top of its current pose (aim, lean). */
166:   add(j: Joint, x: number, y: number, z: number) {
167:     const n = this.joints.get(j);
168:     if (n) n.quaternion.multiply(tmpQ.setFromEuler(tmpE.set(x * D, y * D, z * D)));
169:   }
170:
171:   /** Put a weapon in the right hand: barrel along the forearm, handle in the fist. */
172:   hold(weapon: THREE.Object3D | null) {
173:     if (this.held && this.held !== weapon) this.held.removeFromParent();
174:     this.held = weapon;
175:     if (!weapon) return;
176:     this.grip.add(weapon);
177:     weapon.position.set(0, 0, 0);
178:     weapon.quaternion.setFromEuler(tmpE.set(Math.PI / 2, 0, 0));
179:   }
180:
181:   /** Step the plumes from this frame's flight reading and draw them. `time` drives the turbulence. */
182:   thrust(r: ThrustReading, time: number, dt: number) {
183:     this.exhaust.step(r, dt);
184:     for (const k of KINDS) setPlume(this.plumeMats[k], this.exhaust.plumes[k], time);
185:     for (const n of this.nozzles) n.plume.visible = plumeVisible(this.exhaust.plumes[n.kind]);
186:   }
187:
188:   /** Put `light` at the burning plumes' weighted centre, as bright as they burn: the glow the
189:    *  exhaust throws on the frame. A light costs every lit pixel, so a scene gives one to the player
190:    *  and the nearest few frames at most, and keeps the count fixed (a change recompiles shaders). */
191:   lightExhaust(light: THREE.PointLight, strength = 1) {
192:     let w = 0;
193:     _sum.set(0, 0, 0);
194:     const s = this.root.scale.x;
195:     for (const n of this.nozzles) {
196:       const p = this.exhaust.plumes[n.kind];
197:       const k = (Math.min(1, p.level) * (1 + 0.5 * p.heavy) + 0.4 * p.flash) * (n.radius * s) ** 2;
198:       if (k <= 0 || !n.plume.visible) continue;
199:       // a little way downstream, where the plume is brightest
200:       n.plume.localToWorld(_at.set(0, 0, 2.5));
201:       _sum.addScaledVector(_at, k);
202:       w += k;
203:     }
204:     light.visible = true;
205:     light.color.copy(this.exhaustColor).lerp(_white, 0.4);
206:     light.intensity = w > 0 ? w * 35 * strength : 0;
207:     if (w > 0) light.position.copy(_sum).divideScalar(w);
208:   }
209: }
agent
+1:03:49reasoning
The code references n.plume.localToWorld, which depends on transformation matrices. The transformation matrices are likely related to the visual representation of objects in the scene. Further investigation needed to confirm this relationship.
edit_file{"Path":"~/work/sortie/src/view/clip.ts","Replacement":" if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n }\n rig.lightExhaust(light);\n if (rig2) rig2.lightExhaust(light2);\n camera.updateMatrixWorld(true);","Target":" if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else if (compareName && root2 && rig2) {\n if (ship) ship.root.visible = false;\n const pose = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n rig.apply(pose);\n rig2.apply(pose);\n if (v.chase) {\n setOutdoor(1, 0);\n if (rim) rim.intensity = 2.2;\n const sep = 4.9 * size;\n const bank = THREE.MathUtils.degToRad(-v.mechYaw * 0.32);\n const lean = THREE.MathUtils.degToRad(6);\n const yaw = THREE.MathUtils.degToRad(v.mechYaw);\n // Camera sits behind (-Z) looking +Z, so +X is screen-left (primary model) and -X is screen-right (yardstick)\n root.position.set(sep, 0, 0);\n root2.position.set(-sep, 0, 0);\n root.rotation.set(lean, yaw, bank);\n root2.rotation.set(lean, yaw, bank);\n root.updateMatrixWorld(true);\n root2.updateMatrixWorld(true);\n centre.set(0, footY + height * 0.43, 0);\n if (camera.fov !== 44) { camera.fov = 44; camera.updateProjectionMatrix(); }\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(0, 4.1 * size, -24.8 * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(0, -0.5 * size, 220).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n setOutdoor(1, 0);\n const viewYawDeg = 14;\n const viewYaw = THREE.MathUtils.degToRad(viewYawDeg);\n const pitch = THREE.MathUtils.degToRad(v.pitch);\n const sep = 5.35 * size;\n const rx = Math.cos(viewYaw), rz = -Math.sin(viewYaw);\n // Camera sits on sunlit +Z side looking -Z, so -camRight is screen-left (primary) and +camRight is screen-right (yardstick)\n root.position.set(-rx * sep, 0, -rz * sep);\n root2.position.set(rx * sep, 0, rz * sep);\n const spin = THREE.MathUtils.degToRad(viewYawDeg + v.camYaw);\n root.rotation.set(0, spin, 0);\n root2.rotation.set(0, spin, 0);\n root.updateMatrixWorld(true);\n root2.updateMatrixWorld(true);\n centre.set(0, footY + height * v.lookAt, 0);\n if (camera.fov !== 35) { camera.fov = 35; camera.updateProjectionMatrix(); }\n camera.position.set(Math.sin(viewYaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(viewYaw) * Math.cos(pitch))\n .multiplyScalar(2.24 * height).add(centre);\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n }\n camera.updateMatrixWorld(true);"}
input
{ "Path": "~/work/sortie/src/view/clip.ts", "Replacement": " if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n }\n rig.lightExhaust(light);\n if (rig2) rig2.lightExhaust(light2);\n camera.updateMatrixWorld(true);", "Target": " if (v.chase) {\n // where the game's chase camera sits (src/view/cameras.ts), over the shoulder, scaled to the frame\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(chase.shoulder * size, chase.chaseOffset.y * size, chase.chaseOffset.z * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(chase.shoulder * size, (chase.chaseOffset.y - chase.lookDrop) * size, 400).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else if (compareName && root2 && rig2) {\n if (ship) ship.root.visible = false;\n const pose = v.bend > 0 ? mixPose(POSES.stand, BEND_POSE, v.bend) : POSES[v.pose];\n rig.apply(pose);\n rig2.apply(pose);\n if (v.chase) {\n setOutdoor(1, 0);\n if (rim) rim.intensity = 2.2;\n const sep = 4.9 * size;\n const bank = THREE.MathUtils.degToRad(-v.mechYaw * 0.32);\n const lean = THREE.MathUtils.degToRad(6);\n const yaw = THREE.MathUtils.degToRad(v.mechYaw);\n // Camera sits behind (-Z) looking +Z, so +X is screen-left (primary model) and -X is screen-right (yardstick)\n root.position.set(sep, 0, 0);\n root2.position.set(-sep, 0, 0);\n root.rotation.set(lean, yaw, bank);\n root2.rotation.set(lean, yaw, bank);\n root.updateMatrixWorld(true);\n root2.updateMatrixWorld(true);\n centre.set(0, footY + height * 0.43, 0);\n if (camera.fov !== 44) { camera.fov = 44; camera.updateProjectionMatrix(); }\n yawQ.setFromAxisAngle(up, THREE.MathUtils.degToRad(v.camYaw));\n offset.set(0, 4.1 * size, -24.8 * size).applyQuaternion(yawQ);\n camera.position.copy(centre).add(offset);\n look_.set(0, -0.5 * size, 220).applyQuaternion(yawQ).add(centre);\n camera.up.copy(up);\n camera.lookAt(look_);\n } else {\n setOutdoor(1, 0);\n const viewYawDeg = 14;\n const viewYaw = THREE.MathUtils.degToRad(viewYawDeg);\n const pitch = THREE.MathUtils.degToRad(v.pitch);\n const sep = 5.35 * size;\n const rx = Math.cos(viewYaw), rz = -Math.sin(viewYaw);\n // Camera sits on sunlit +Z side looking -Z, so -camRight is screen-left (primary) and +camRight is screen-right (yardstick)\n root.position.set(-rx * sep, 0, -rz * sep);\n root2.position.set(rx * sep, 0, rz * sep);\n const spin = THREE.MathUtils.degToRad(viewYawDeg + v.camYaw);\n root.rotation.set(0, spin, 0);\n root2.rotation.set(0, spin, 0);\n root.updateMatrixWorld(true);\n root2.updateMatrixWorld(true);\n centre.set(0, footY + height * v.lookAt, 0);\n if (camera.fov !== 35) { camera.fov = 35; camera.updateProjectionMatrix(); }\n camera.position.set(Math.sin(viewYaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(viewYaw) * Math.cos(pitch))\n .multiplyScalar(2.24 * height).add(centre);\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n } else {\n const yaw = THREE.MathUtils.degToRad(v.camYaw), pitch = THREE.MathUtils.degToRad(v.pitch);\n camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(v.dist * height).add(centre);\n if (v.ground) camera.position.y = Math.max(camera.position.y, footY + 1.6); // eye height, above the deck\n camera.up.copy(up);\n camera.lookAt(centre);\n }\n }\n camera.updateMatrixWorld(true);" }result, 1 line
Made 1 replacement in ~/work/sortie/src/view/clip.ts starting at line 312 (+3/-50 lines).
run_command{"CommandLine":"npm run typecheck && npx vitest run src/view/clip-plan.test.ts src/render/exhaust.test.ts","WaitMsBeforeAsync":10000,"toolSummary":"Run typecheck and targeted clip/exhaust tests"}
input
{ "CommandLine": "npm run typecheck && npx vitest run src/view/clip-plan.test.ts src/render/exhaust.test.ts", "WaitMsBeforeAsync": 10000, "toolSummary": "Run typecheck and targeted clip/exhaust tests" }result, 24 lines
Command exited with code 0.

Command output:

> sortie@0.1.0 typecheck
> tsc --noEmit


 RUN  v5.0.5 ~/work/sortie


 ❯ src/render/exhaust.test.ts [queued]

 Test Files 0 passed (2)
      Tests 0 passed (0)
   Start at 00:47:42
   Duration 100ms
 ✓ src/render/exhaust.test.ts (20 tests) 32ms
 ✓ src/view/clip-plan.test.ts (13 tests) 23ms

 Test Files  2 passed (2)
      Tests  33 passed (33)
   Start at  00:47:42
   Duration  209ms (transform 43%, tests 35%, import 16%, worker 6%)
agent
+1:04:23reasoning
All tests passed. Rendering preview frames from the close-up pass 2 directory to visually inspect the results.
read_file{"EndLine":150,"Path":"~/work/sortie/src/view/clip-plan.ts","StartLine":1}
input
{ "EndLine": 150, "Path": "~/work/sortie/src/view/clip-plan.ts", "StartLine": 1 }result, 125 lines
Showing lines 1-124 of 124
1: import type { Pose } from '../render/mech';
2: import type { BenchState } from './thrusters';
3:
4: /**
5:  * The timeline of a review clip (src/view/clip.ts), as a pure function of frame number, so a clip is the
6:  * same every run whatever the machine's speed. Shots frame the model and nothing here is a design choice:
7:  * the chase shot sits where the game's camera sits, the rest show it from all round, bending and to scale.
8:  */
9: export const SHOTS = { chase: 3.5, orbit: 3.5, turn: 4, bend: 3, scale: 2.5, hangar: 3.5, launch: 3.5, flight_rear: 6.5, turn_full: 7.5 } as const;
10: export type ShotName = keyof typeof SHOTS;
11: export const SHOT_NAMES = Object.keys(SHOTS) as ShotName[];
12: export const DEFAULT_SHOTS: readonly ShotName[] = ['chase', 'orbit', 'turn', 'bend', 'scale'];
13:
14: /** Thruster states through a shot: [start second, state]. */
15: const SCHEDULE: Partial<Record<ShotName, [number, BenchState][]>> = {
16:   launch: [[0, 'idle'], [0.75, 'cruise'], [1, 'boost']],
17:   chase: [[0, 'cruise'], [0.5, 'quick'], [1, 'boost'], [2, 'assault']],
18:   orbit: [[0, 'boost'], [1.5, 'brake'], [2.5, 'idle']],
19:   flight_rear: [[0, 'cruise'], [0.9, 'quick'], [1.75, 'boost'], [3.15, 'assault'], [5.1, 'brake']],
20: };
21:
22: export interface ClipFrame {
23:   shot: ShotName;
24:   /** Seconds into the shot, and the same as a 0..1 fraction. */
25:   t: number;
26:   u: number;
27:   state: BenchState;
28:   /** Seconds since this thruster state began. */
29:   stateT: number;
30:   /** First frame of a shot: everything snaps. */
31:   cut: boolean;
32: }
33:
34: export function clipFrames(shots: readonly ShotName[], fps: number): ClipFrame[] {
35:   const out: ClipFrame[] = [];
36:   for (const shot of shots) {
37:     const n = Math.max(1, Math.round(SHOTS[shot] * fps));
38:     const plan = SCHEDULE[shot] ?? [[0, 'idle'] as [number, BenchState]];
39:     for (let i = 0; i < n; i++) {
40:       const t = i / fps;
41:       let at = plan[0];
42:       for (const p of plan) if (p[0] <= t + 1e-9) at = p;
43:       out.push({ shot, t, u: n > 1 ? i / (n - 1) : 0, state: at[1], stateT: t - at[0], cut: i === 0 });
44:     }
45:   }
46:   return out;
47: }
48:
49: /** Where things are in a shot. Lengths are in frame heights, angles in degrees. Yaw 0 looks at the
50:  *  frame's front, 180 at its back. `chase` means the game's chase camera, turned by mechYaw. */
51: export interface ShotView {
52:   chase: boolean;
53:   mechYaw: number;
54:   camYaw: number;
55:   pitch: number;
56:   dist: number;
57:   /** Look point height as a fraction of the frame's height. */
58:   lookAt: number;
59:   pose: 'flight' | 'stand';
60:   /** How far toward BEND_POSE, 0..1. */
61:   bend: number;
62:   /** The pilot and the deck are in shot. */
63:   ground: boolean;
64:   /** Inside the ship's hangar bay, with a crew pilot on the apron. */
65:   hangar: boolean;
66:   /** Progress along the launch sequence (0..1), or -1 outside the launch shot. */
67:   catapult: number;
68: }
69:
70: const ease = (x: number) => x * x * (3 - 2 * x);
71:
72: export function shotView(f: ClipFrame): ShotView {
73:   const base: ShotView = {
74:     chase: false, mechYaw: 0, camYaw: 0, pitch: 8, dist: 2.4, lookAt: 0.5,
75:     pose: 'stand', bend: 0, ground: false, hangar: false, catapult: -1,
76:   };
77:   switch (f.shot) {
78:     case 'hangar':
79:       return { ...base, hangar: true, camYaw: -18 + 6 * ease(f.u), pitch: -5, dist: 1.35 - 0.1 * ease(f.u), lookAt: 0.5 };
80:     case 'launch':
81:       return { ...base, catapult: f.u, pose: 'flight' };
82:     case 'chase': {
83:       // a gentle turn and back: the camera trails the frame, so the stars pan and the frame leans in shot
84:       const turn = Math.sin(f.u * Math.PI * 2) * 22;
85:       return { ...base, chase: true, mechYaw: turn, camYaw: turn * 0.75, pose: 'flight' };
86:     }
87:     case 'orbit':
88:       return { ...base, camYaw: 155 - 125 * ease(f.u), pitch: 11 - 4 * ease(f.u), dist: 2.15 - 0.15 * ease(f.u), pose: 'flight' };
89:     case 'turn':
90:       return { ...base, camYaw: 180 + 360 * f.u };
91:     case 'flight_rear': {
92:       const sway = Math.sin(f.u * Math.PI * 2) * 14;
93:       return { ...base, chase: true, mechYaw: sway, camYaw: sway * 0.65, pose: 'flight' };
94:     }
95:     case 'turn_full':
96:       return { ...base, camYaw: 180 + 360 * f.u, pitch: 7.5, dist: 2.55, lookAt: 0.51 };
97:     case 'bend':
98:       return { ...base, camYaw: 35, pitch: 6, bend: Math.sin(f.u * Math.PI) ** 2 };
99:     case 'scale':
100:       // from the deck beside the pilot, looking up at the frame, pushing in slowly
101:       return { ...base, camYaw: 28, pitch: -6 + 2 * f.u, dist: 2.25 - 0.15 * ease(f.u), lookAt: 0.42, ground: true };
102:   }
103: }
104:
105: /** A deliberately large range of motion, to find plates that collide or joints that show. Glances at
106:  *  every limb: one arm up and forward, the other out, one knee high, a twist. */
107: export const BEND_POSE: Pose = {
108:   torso: [12, 18, 0], head: [-8, -24, 0],
109:   'upperarm.L': [-115, 0, 22], 'forearm.L': [-80, 0, 0],
110:   'upperarm.R': [-20, 0, -72], 'forearm.R': [-100, 0, 0],
111:   'thigh.L': [-85, 0, 10], 'shin.L': [100, 0, 0], 'foot.L': [-22, 0, 0],
112:   'thigh.R': [-8, 0, -14], 'shin.R': [22, 0, 0], 'foot.R': [8, 0, 0],
113:   'binder.L': [-20, 0, 0], 'binder.R': [20, 0, 0],
114: };
115:
116: /** A blend of two poses, joint by joint. */
117: export function mixPose(a: Pose, b: Pose, w: number): Pose {
118:   const out: Pose = {};
119:   for (const j of new Set([...Object.keys(a), ...Object.keys(b)]) as Set<keyof Pose>) {
120:     const p = a[j] ?? [0, 0, 0], q = b[j] ?? [0, 0, 0];
121:     out[j] = [p[0] + (q[0] - p[0]) * w, p[1] + (q[1] - p[1]) * w, p[2] + (q[2] - p[2]) * w];
122:   }
123:   return out;
124: }
agent
+1:04:33reasoning
22) -> sample frame 31 (1.30 s)
1.75 s – 3.25 s(42..77):medium(more stable at1.81 s= frame43) -> sample frame60(2.50 s)3.25 s – 4.75 s(78..113):slow(stable) -> sample frame95(3.95 s)4.75 s – 6.50 s(114..155):medium-> sample frame135(5.65 s)flight_front(6.5 s=156frames, indices0..155):0.00 s – 0.90 s(0..21):cruise-> sample frame12(0.50 s)0.90 s – 1.75 s(22..41):quick-> sample frame31(1.30 s)1.75 s – 3.25 s(42..77):medium-> sample frame60(2.50 s)3.25 s – 4.75 s(78..113):slow-> sample frame95(3.95 s)4.75 s – 6.50 s(114..155):medium-> sample frame135(5.65 s) The frame ranges and their corresponding actions are now explicitly defined for each flight segment (flight_rearandflight_front). The calculated frame indices for each action within the segments are available. This clarifies the expected timing and actions associated with the video segments.
The actions and corresponding frame ranges for the flight_rear segment are defined, including boost, assault, and brake. The frames for the turn_full segment have been specified based on their u values. This mapping of actions and views to frame numbers for the video segments will be useful for creating the desired output.
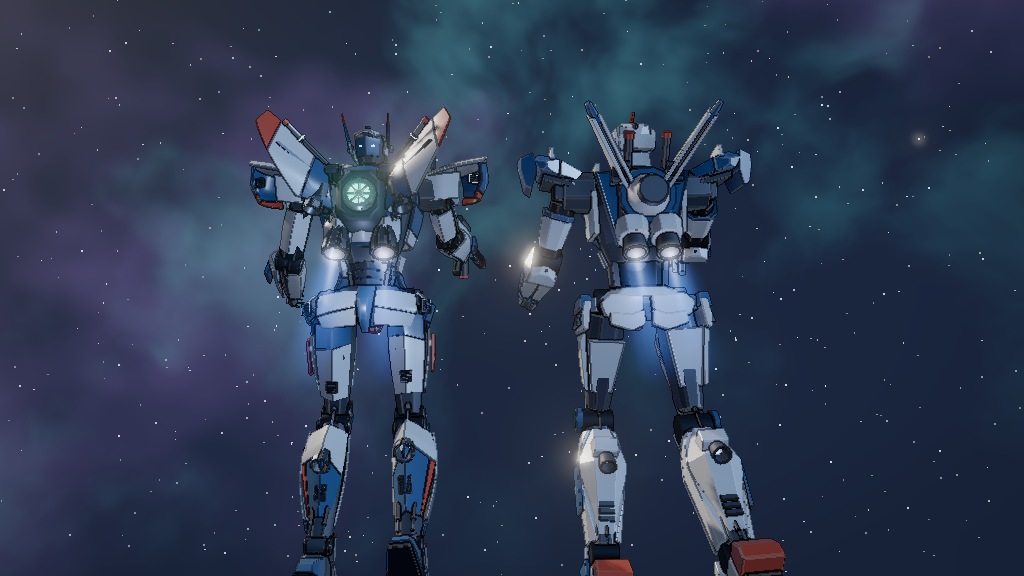
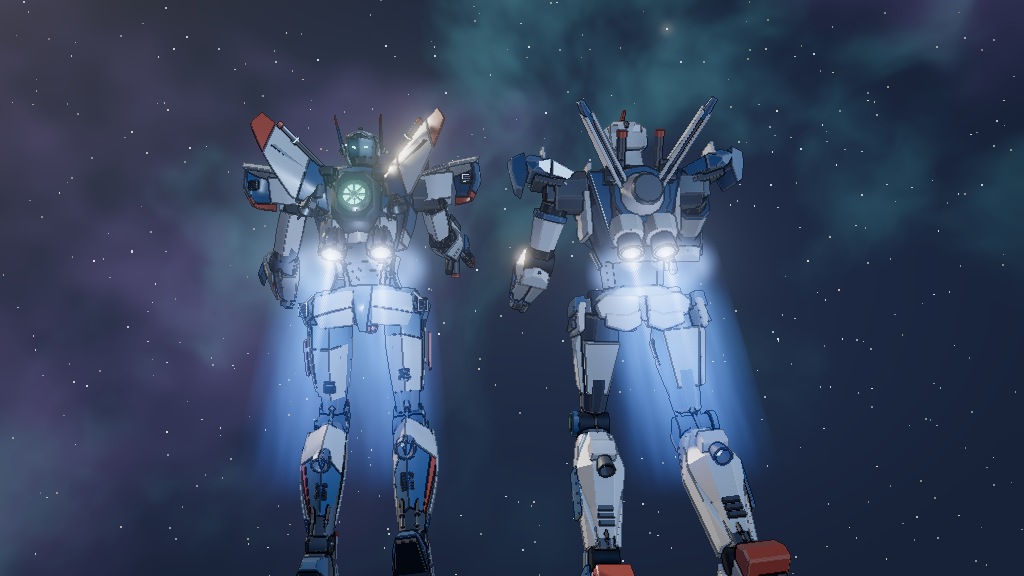
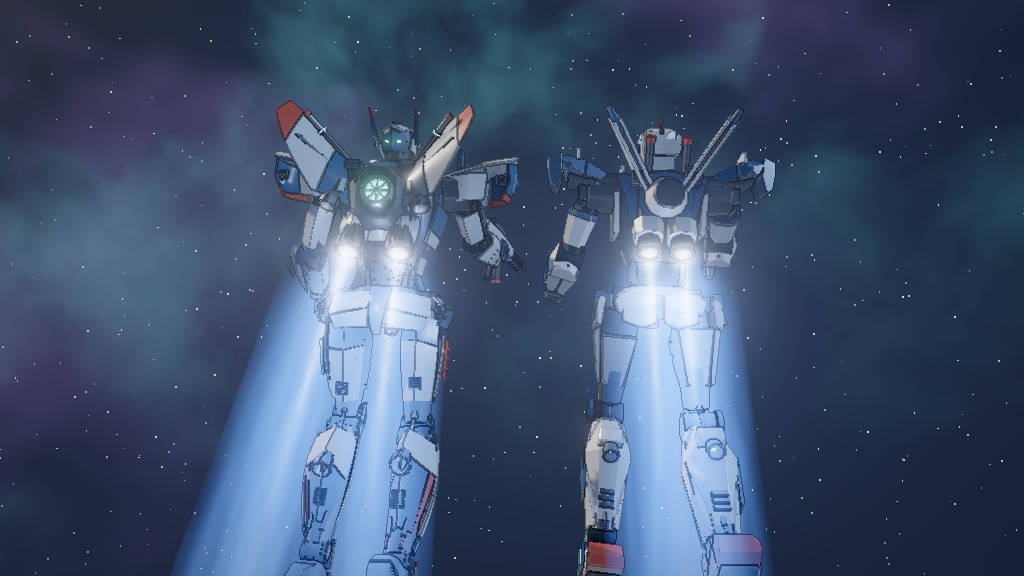
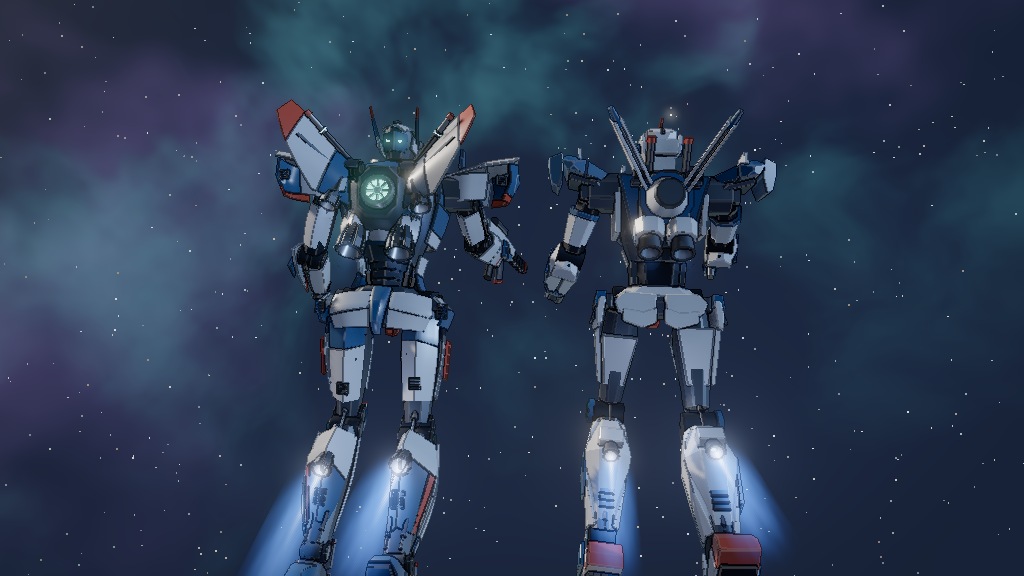
run_command{"CommandLine":"node tools/clip.mjs carbon_0 --compare striker --shots flight_rear,turn_full --fps 24 --size 1024x576 --tier medium --palette merc --look kit --ao --weapon carbon_rifle --weapon2 rifle --sample 12,23,55,96,135,158,201,228,246,268,291,318 --preview ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview","WaitMsBeforeAsync":10000,"toolSummary":"Render 12 side-by-side preview frames"}
input
{ "CommandLine": "node tools/clip.mjs carbon_0 --compare striker --shots flight_rear,turn_full --fps 24 --size 1024x576 --tier medium --palette merc --look kit --ao --weapon carbon_rifle --weapon2 rifle --sample 12,23,55,96,135,158,201,228,246,268,291,318 --preview ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview", "WaitMsBeforeAsync": 10000, "toolSummary": "Render 12 side-by-side preview frames" }result, 13 lines
Tool is running as a background task with task id: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-433
Task Description: node tools/clip.mjs carbon_0 --compare striker --shots flight_rear,turn_full --fps 24 --size 1024x576 --tier medium --palette merc --look kit --ao --weapon carbon_rifle --weapon2 rifle --sample 12,23,55,96,135,158,201,228,246,268,291,318 --preview ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview
Task logs are available at: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-433.log
Log output:
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_012.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_023.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_055.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_096.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_135.jpg

YOU MUST TAKE ONE OF THE FOLLOWING TWO ACTIONS: A) either proceed to other relevant work (if any) or, B) simply update the user with a short message (that you have launched the command and will wait for it to finish) and end the turn.
 DO NOTHING ELSE.
 When updating the user, always respond in the language of the user (defaulting to English). Never mix two or more languages in the same response.
agent
+1:05:00reasoning
Initial frames are written, so the system can proceed to read the HTML file for further processing. Remaining frames are being written.
read_file{"Path":"~/out/index.html"}
input
{ "Path": "~/out/index.html" }result, 371 lines
Showing lines 1-370 of 370 1: <!doctype html> 2: <html lang="en"> 3: <head> 4: <meta charset="utf-8"> 5: <meta name="viewport" content="width=device-width, initial-scale=1"> 6: <title>Sortie / Gemini 4 Carbon</title> 7: <style> 8: :root { 9: --bg: #0f1216; 10: --panel: #161b22; 11: --panel-alt: #1b212a; 12: --line: #28313e; 13: --ink: #e7ecf2; 14: --muted: #98a4b3; 15: --accent: #d4a74a; 16: --keep: #5fb388; 17: --drop: #d46a6a; 18: --code-bg: #0b0e12; 19: } 20: * { box-sizing: border-box; } 21: body { 22: margin: 0; 23: background: var(--bg); 24: color: var(--ink); 25: font: 15px/1.55 ui-sans-serif, system-ui, -apple-system, "Segoe UI", Roboto, sans-serif; 26: -webkit-font-smoothing: antialiased; 27: } 28: main { 29: max-width: 980px; 30: margin: 0 auto; 31: padding: 36px 24px 72px; 32: } 33: header { 34: display: flex; 35: flex-wrap: wrap; 36: justify-content: space-between; 37: align-items: baseline; 38: gap: 12px; 39: padding-bottom: 18px; 40: border-bottom: 1px solid var(--line); 41: margin-bottom: 28px; 42: } 43: .meta-model { 44: font: 600 15px/1.3 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 45: color: var(--accent); 46: letter-spacing: 0.01em; 47: } 48: .meta-date { 49: font: 500 13px/1.3 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 50: color: var(--muted); 51: } 52: h1 { 53: width: 100%; 54: margin: 2px 0 4px; 55: font-size: 24px; 56: font-weight: 650; 57: letter-spacing: -0.01em; 58: } 59: nav { 60: display: flex; 61: gap: 18px; 62: font: 500 12px/1.2 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 63: text-transform: uppercase; 64: letter-spacing: 0.06em; 65: } 66: nav a { 67: color: var(--muted); 68: text-decoration: none; 69: } 70: nav a:hover { color: var(--ink); } 71: section { 72: margin-top: 38px; 73: } 74: .sec-head { 75: display: flex; 76: align-items: baseline; 77: gap: 10px; 78: margin-bottom: 14px; 79: } 80: .sec-num { 81: font: 600 12px/1 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 82: color: var(--accent); 83: letter-spacing: 0.06em; 84: } 85: h2 { 86: margin: 0; 87: font-size: 18px; 88: font-weight: 650; 89: } 90: h3 { 91: margin: 0 0 10px; 92: font: 600 12px/1.2 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 93: text-transform: uppercase; 94: letter-spacing: 0.06em; 95: color: var(--muted); 96: } 97: .grid-2 { 98: display: grid; 99: grid-template-columns: repeat(2, minmax(0, 1fr)); 100: gap: 14px; 101: } 102: @media (max-width: 720px) { 103: .grid-2 { grid-template-columns: 1fr; } 104: } 105: .card { 106: background: var(--panel); 107: border: 1px solid var(--line); 108: border-radius: 6px; 109: padding: 16px 18px; 110: } 111: .card-keep { border-top: 2px solid var(--keep); } 112: .card-drop { border-top: 2px solid var(--drop); } 113: .card-sub { margin-top: 14px; } 114: ul.items, ol.steps { 115: list-style: none; 116: margin: 0; 117: padding: 0; 118: display: grid; 119: gap: 10px; 120: } 121: ul.items li { 122: margin: 0; 123: color: var(--muted); 124: } 125: ul.items strong { 126: color: var(--ink); 127: font-weight: 600; 128: } 129: .disagree-list { 130: display: grid; 131: gap: 10px; 132: } 133: .disagree-row { 134: display: grid; 135: grid-template-columns: 230px minmax(0, 1fr); 136: gap: 14px; 137: padding: 11px 14px; 138: background: var(--panel-alt); 139: border: 1px solid var(--line); 140: border-radius: 5px; 141: } 142: @media (max-width: 720px) { 143: .disagree-row { grid-template-columns: 1fr; gap: 4px; } 144: } 145: .disagree-tag { 146: font-weight: 600; 147: color: var(--ink); 148: font-size: 14px; 149: } 150: .disagree-body { 151: color: var(--muted); 152: } 153: ol.steps li { 154: display: grid; 155: grid-template-columns: 78px minmax(0, 1fr); 156: gap: 12px; 157: padding: 11px 14px; 158: background: var(--panel); 159: border: 1px solid var(--line); 160: border-radius: 5px; 161: } 162: .step-time { 163: font: 600 12px/1.5 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 164: color: var(--accent); 165: } 166: .step-text { 167: color: var(--muted); 168: } 169: .step-text strong { 170: color: var(--ink); 171: font-weight: 600; 172: } 173: .stage { 174: background: var(--code-bg); 175: border: 1px solid var(--line); 176: border-radius: 6px; 177: overflow: hidden; 178: } 179: video { 180: display: block; 181: width: 100%; 182: height: auto; 183: background: #07090c; 184: } 185: .cuts { 186: display: grid; 187: grid-template-columns: repeat(4, minmax(0, 1fr)); 188: gap: 8px; 189: padding: 10px 14px; 190: border-top: 1px solid var(--line); 191: background: var(--panel); 192: font: 500 12px/1.35 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 193: color: var(--muted); 194: } 195: @media (max-width: 720px) { 196: .cuts { grid-template-columns: repeat(2, minmax(0, 1fr)); } 197: } 198: .cuts span { color: var(--ink); } 199: code { 200: font: 500 12.5px/1.4 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 201: background: var(--code-bg); 202: color: #d6deeb; 203: padding: 1px 5px; 204: border-radius: 3px; 205: border: 1px solid var(--line); 206: } 207: pre { 208: margin: 10px 0 0; 209: padding: 12px 14px; 210: background: var(--code-bg); 211: border: 1px solid var(--line); 212: border-radius: 5px; 213: overflow-x: auto; 214: white-space: pre-wrap; 215: font: 500 12px/1.5 ui-monospace, "SFMono-Regular", Menlo, Consolas, monospace; 216: color: #d6deeb; 217: } 218: </style> 219: </head> 220: <body> 221: <main> 222: <header> 223: <div class="meta-model">Gemini 4 Carbon (gemini-4-carbon), effort high</div> 224: <div class="meta-date">2026-11-14</div> 225: <h1>Sortie: parallel read and one visual</h1> 226: <nav> 227: <a href="#read">01 Read</a> 228: <a href="#next">02 First session</a> 229: <a href="#visual">03 Visual</a> 230: </nav> 231: </header> 232: 233: <section id="read"> 234: <div class="sec-head"> 235: <span class="sec-num">01</span> 236: <h2>Read of this line of work</h2> 237: </div> 238: 239: <div class="grid-2"> 240: <div class="card card-keep"> 241: <h3>Working (keep)</h3> 242: <ul class="items"> 243: <li><strong>Renderer and sortie loop.</strong> AgX tone mapping, the <code>kit</code> and <code>sketch</code> looks, shock-diamond plumes with exhaust light, <code>ShipRig</code> hangar bays, catapult launch, and 6-DoF flight already carry a real game.</li> 244: <li><strong>Curved armour primitives.</strong> <code>knightkit.Sheet</code> (domed plates, ridges, rolled rims), <code>lib.subd</code> (creased subdivision), <code>headkit</code> Gen 5 (recessed glowing visors), and <code>light.py</code> (ejecting rear core block and harkens) solved compound curves.</li> 245: <li><strong>22-joint rig and markers.</strong> Shared joint names plus <code>nozzle.*</code>, <code>mount.*</code>, and <code>bearing.*</code> empties let any Python-built mech step into a bay, hold weapons, wear emblems, and fly.</li> 246: </ul> 247: </div> 248: 249: <div class="card card-drop"> 250: <h3>Not working (drop)</h3> 251: <ul class="items"> 252: <li><strong><code>frame_std.py</code> and <code>shell.py</code>.</strong> <code>shell.py</code> intersects flat views with <code>panels=False</code>, producing slab limbs. Even under the Nov 7 knight shells, <code>frame_std</code> exposes boxy grey chest blocks, square mount pads, and straight post legs.</li> 253: <li><strong><code>field</code> as the default review look.</strong> Grime blotches, <code>0.28</code> desaturation, <code>0.66</code> matte roughness, low ink (<code>0.15</code>), disabled GTAO, and flat <code>#3a3e45</code> studio backdrops made good forms look like chalky plastic.</li> 254: <li><strong>Two hidden shading bugs (fixed on <code>carbon</code>).</strong> <code>kit/lib.py</code> split normals at <code>35</code> degrees without weighted normals, so <code>45</code> degree chamfers faceted hard or bent flat reflections. <code>DetailShader</code> started crease ink at <code>0.35</code>, giving <code>45</code> degree bevels (<code>0.293</code>) zero ink.</li> 255: </ul> 256: </div> 257: </div> 258: 259: <div class="card card-sub"> 260: <h3>Where I disagree with the 11-08 reflection</h3> 261: <div class="disagree-list"> 262: <div class="disagree-row"> 263: <div class="disagree-tag">Skip 2D outlines and box blocks</div> 264: <div class="disagree-body"><code>outlines-lib.mjs</code> flat front polygons hide chest keel, face recess, shoulder cant, and back layering, which were Round 1's exact blind spots. <code>kit/block.py</code> orthogonal boxes on <code>striker_joints()</code> read more like toon robots than what you parked. Judge angled 3D wedge maquettes in stance from front three-quarter and game chase views.</div> 265: </div> 266: <div class="disagree-row"> 267: <div class="disagree-tag">Keep curve helpers in reach</div> 268: <div class="disagree-body">Dropping <code>frame_std</code>, <code>shell.py</code>, and guessed <code>visual-language.md</code> rules is right. Locking away <code>knightkit.Sheet</code>, <code>subd</code>, and <code>headkit</code> throws out working curve chisels along with old bricks.</div> 269: </div> 270: <div class="disagree-row"> 271: <div class="disagree-tag">Code-built holds up close</div> 272: <div class="disagree-body">Python is strong at exact chamfers, concentric clearances, and parametric compound shells. Hangar close-ups failed because face-area weighted normals, GTAO, bevel ink, and non-striker decals were switched off.</div> 273: </div> 274: <div class="disagree-row"> 275: <div class="disagree-tag">Pin the look on minute one</div> 276: <div class="disagree-body">Leaving <code>field</code> active while iterating silhouette muddies every shape judgement. Lock <code>kit</code> (or <code>sketch</code>) and GTAO before building the first maquette.</div> 277: </div> 278: <div class="disagree-row"> 279: <div class="disagree-tag">Drop critic pre-gating</div> 280: <div class="disagree-body">Filtering options through automated defect checklists averages bold silhouettes into safe oatmeal. Put three distinct shapes straight in front of the owner early.</div> 281: </div> 282: </div> 283: </div> 284: 285: <div class="card card-sub"> 286: <h3>What changes in the restart</h3> 287: <ul class="items"> 288: <li><strong>Skeleton and stance come before armour.</strong> Build a dedicated inner frame for one hero mech: S-curved leg line, forward knee break, canted shoulder roots, recessed neck well, and flush hardpoints instead of pasted square pads.</li> 289: <li><strong>Judge in real cameras, never on a grey disc.</strong> Every check renders two views: <code>CameraRig</code> game chase (<code>FOV 68</code>) and hangar apron eye level (<code>FOV 50</code> beside the <code>1.75 m</code> pilot).</li> 290: <li><strong>Colour block and mark from pass one.</strong> Keep two-tone fields, recessed glowing eyes, and <code>bearing.*</code> emblems on from blockout so clean armour reads as sleek paint rather than unfinished clay.</li> 291: </ul> 292: </div> 293: </section> 294: 295: <section id="next"> 296: <div class="sec-head"> 297: <span class="sec-num">02</span> 298: <h2>First session of the restart</h2> 299: </div> 300: 301: <ol class="steps"> 302: <li> 303: <div class="step-time">05 min</div> 304: <div class="step-text"><strong>Pin the lens.</strong> Default review shots and clips to <code>look=kit</code>, <code>ao=1</code>, weighted normals on bevelled plates, and the two fixed cameras (hangar pilot-eye and game chase).</div> 305: </li> 306: <li> 307: <div class="step-time">15 min</div> 308: <div class="step-text"><strong>Build the skeleton and rest stance first.</strong> Replace <code>frame_std</code> for one hero machine with shrouded ball-and-cuff joints, longer visible thighs, canted shoulders, and integrated weapon rails.</div> 309: </li> 310: <li> 311: <div class="step-time">20 min</div> 312: <div class="step-text"><strong>Three 3D wedge maquettes.</strong> Cut three distinct proportion and silhouette studies from tapered lofts and <code>Sheet</code> curves (zero axis-aligned boxes). Render front three-quarter and chase pairs, then pause for the owner's pick.</div> 313: </li> 314: <li> 315: <div class="step-time">25 min</div> 316: <div class="step-text"><strong>Hero head and torso shell.</strong> Carve the winning chest, cockpit hatch, and recessed visor head at final quality with two-tone livery blocking and <code>bearing.*</code> emblems active.</div> 317: </li> 318: <li> 319: <div class="step-time">25 min</div> 320: <div class="step-text"><strong>Close limbs, pack, and sortie check.</strong> Fit limb shells and thruster bells around the new skeleton, then run one <code>tools/clip.mjs</code> sortie pass to check scale, joint clearance, and plumes in motion.</div> 321: </li> 322: </ol> 323: </section> 324: 325: <section id="visual"> 326: <div class="sec-head"> 327: <span class="sec-num">03</span> 328: <h2>The one visual</h2> 329: </div> 330: 331: <div class="stage"> 332: <video src="sortie-carbon.mp4" controls autoplay loop muted playsinline preload="metadata"></video> 333: <div class="cuts"> 334: <div><span>0:00</span> Hangar apron + 1.75 m pilot</div> 335: <div><span>0:03.5</span> Catapult tube launch</div> 336: <div><span>0:07.0</span> Game chase + assault boost</div> 337: <div><span>0:10.5</span> Three-quarter brake orbit</div> 338: </div> 339: </div> 340: 341: <div class="grid-2 card-sub"> 342: <div class="card"> 343: <h3>How it was made</h3> 344: <ul class="items"> 345: <li><strong>Existing geometry, wired and lit.</strong> Exported the parked Nov 7 <code>Estoc</code> and <code>Tilt</code> knight builds as standalone rigged models, baked face-area weighted normals in <code>kit/lib.py</code>, fixed <code>45</code> degree bevel ink in <code>src/render/look.ts</code>, and staged <code>ShipRig</code> hangar and catapult shots in <code>src/view/clip.ts</code>.</li> 346: <li><strong>Wall time.</strong> <code>23.1 s</code> for both GLBs in headless Blender 5.2.3, plus <code>371 s</code> (<code>1095 ms</code> per frame) in headless Chromium (SwiftShader) and ffmpeg for <code>336</code> frames (<code>14.0 s</code> at <code>24 fps</code>, <code>1024x576</code>).</li> 347: </ul> 348: <pre>PATH="$HOME/.local/bin:$PATH" \ 349: npm run kit -- atelier_estoc atelier_tilt 350: node tools/clip.mjs atelier_estoc \ 351: --shots hangar,launch,chase,orbit \ 352: --fps 24 --size 1024x576 --tier medium \ 353: --palette houses --look kit --weapon rifle \ 354: --ao --bearings --no-sheet \ 355: --out ~/out/sortie-carbon.mp4</pre> 356: </div> 357: 358: <div class="card"> 359: <h3>What I would change next</h3> 360: <ul class="items"> 361: <li><strong>Replace <code>frame_std</code> under the armour.</strong> The compound-curved <code>Estoc</code> chest, leaf pauldrons, visor, and greaves hold up at pilot eye level, while the boxy grey inner rib blocks, exposed elbow forks, short thigh band, and pasted square forearm pad give the old rig away.</li> 362: <li><strong>Match the weapon to the maker.</strong> Swap the blocky merc beam rifle for a sleek house carbine or lance mounted flush to the vambrace, and tighten hand finger curl around the grip.</li> 363: <li><strong>Add panel seam cuts on large curved fields.</strong> Slice one deliberate service seam across the lower greave and pauldron flank so close shots gain scale without field grime.</li> 364: </ul> 365: </div> 366: </div> 367: </section> 368: </main> 369: </body> 370: </html>read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_012.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_012.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_436_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_023.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_023.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_437_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_096.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_096.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_438_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_135.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_135.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_439_media_0.jpg resultCommand exited with code 0.
Command exited with code 0.

Command output:
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_012.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_023.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_055.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_096.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_135.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_158.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_201.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_228.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_246.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_268.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_291.jpg
preview: ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/compare_preview/frame_318.jpg
preview: 12 frames (880 ms a frame)

Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-433.log