A mech game prototype, pushed by Gemini 4 Carbon
agent
+52:11reasoning
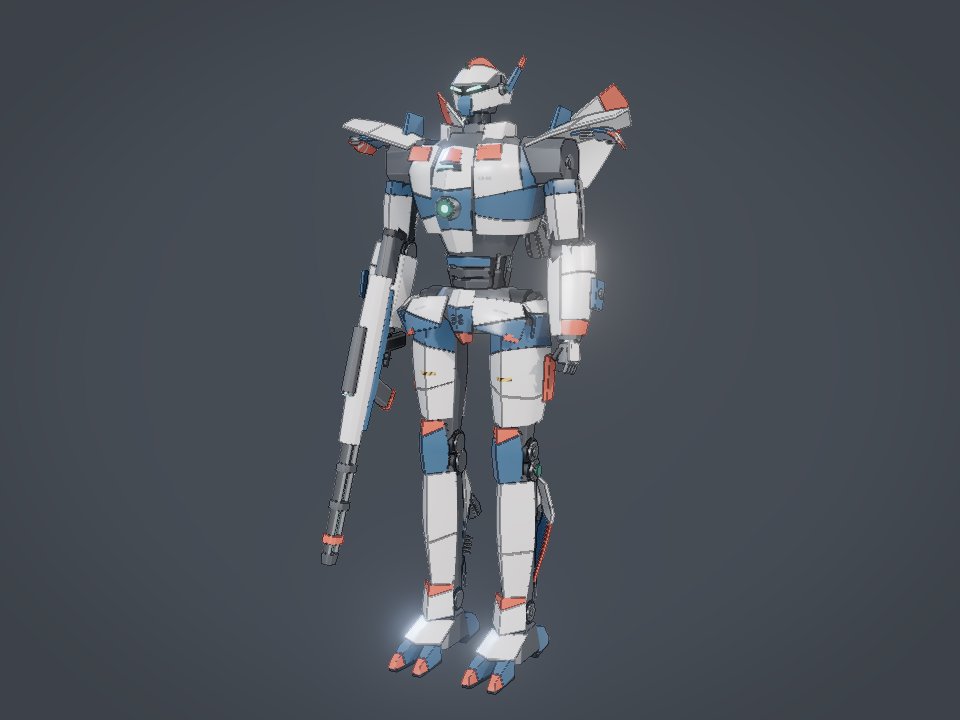
Analyzing the saved image, while simultaneously reviewing the test file for the side-by-side clip comparison architecture. This dual approach aims to leverage the current available data and anticipate potential needs as the remaining shots render.
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png" }result, 1 line
Showing binary file of type image/png
step_351_media_0.jpg read_file{"EndLine":100,"Path":"~/work/sortie/src/view/clip-plan.test.ts","StartLine":1}
input
{ "EndLine": 100, "Path": "~/work/sortie/src/view/clip-plan.test.ts", "StartLine": 1 }result, 85 lines
Showing lines 1-84 of 84
1: import { describe, expect, it } from 'vitest';
2: import { BEND_POSE, SHOTS, SHOT_NAMES, clipFrames, mixPose, shotView } from './clip-plan';
3:
4: describe('clip timeline', () => {
5:   it('runs every shot for its length, in the order asked', () => {
6:     const f = clipFrames(['turn', 'chase'], 24);
7:     expect(f).toHaveLength(Math.round(SHOTS.turn * 24) + Math.round(SHOTS.chase * 24));
8:     expect(f[0].shot).toBe('turn');
9:     expect(f[f.length - 1].shot).toBe('chase');
10:   });
11:
12:   it('marks the first frame of each shot as a cut, and no others', () => {
13:     const f = clipFrames(['chase', 'orbit'], 24);
14:     expect(f.filter((x) => x.cut).map((x) => x.shot)).toEqual(['chase', 'orbit']);
15:     expect(f[0].cut).toBe(true);
16:   });
17:
18:   it('runs u from 0 to 1 in a shot', () => {
19:     const f = clipFrames(['turn'], 24);
20:     expect(f[0].u).toBe(0);
21:     expect(f[f.length - 1].u).toBe(1);
22:   });
23:
24:   it('starts each thruster state at zero and counts up from there', () => {
25:     const f = clipFrames(['chase'], 24);
26:     const boost = f.filter((x) => x.state === 'boost');
27:     expect(boost[0].stateT).toBeCloseTo(0, 6);
28:     expect(boost[1].stateT).toBeCloseTo(1 / 24, 6);
29:     expect(f.map((x) => x.state)).toContain('quick');
30:   });
31:
32:   it('holds idle in shots with no schedule', () => {
33:     expect(clipFrames(['scale'], 24).every((x) => x.state === 'idle')).toBe(true);
34:   });
35:
36:   it('gives the same frames every run', () => {
37:     expect(clipFrames(SHOT_NAMES, 24)).toEqual(clipFrames(SHOT_NAMES, 24));
38:   });
39: });
40:
41: describe('shot views', () => {
42:   const at = (shot: 'chase' | 'turn' | 'bend' | 'scale', i: number) => shotView(clipFrames([shot], 24)[i]);
43:
44:   it('turns a full circle in the turn shot, starting from behind', () => {
45:     const f = clipFrames(['turn'], 24);
46:     expect(shotView(f[0]).camYaw).toBe(180);
47:     expect(shotView(f[f.length - 1]).camYaw).toBe(540);
48:   });
49:
50:   it('uses the game camera only for the chase shot', () => {
51:     expect(at('chase', 0).chase).toBe(true);
52:     expect(at('turn', 0).chase).toBe(false);
53:   });
54:
55:   it('starts and ends the bend shot unbent', () => {
56:     const f = clipFrames(['bend'], 24);
57:     expect(shotView(f[0]).bend).toBeCloseTo(0, 6);
58:     expect(shotView(f[f.length - 1]).bend).toBeCloseTo(0, 6);
59:     expect(Math.max(...f.map((x) => shotView(x).bend))).toBeGreaterThan(0.95);
60:   });
61:
62:   it('has the pilot and deck in the scale shot only', () => {
63:     expect(at('scale', 0).ground).toBe(true);
64:     expect(at('chase', 0).ground).toBe(false);
65:   });
66:
67:   it('stages hangar and launch shots with their own flags and boost schedule', () => {
68:     const h = clipFrames(['hangar'], 24);
69:     expect(shotView(h[0]).hangar).toBe(true);
70:     expect(shotView(h[0]).ground).toBe(false);
71:     const l = clipFrames(['launch'], 24);
72:     expect(shotView(l[0]).catapult).toBe(0);
73:     expect(shotView(l[l.length - 1]).catapult).toBe(1);
74:     expect(l.map((x) => x.state)).toContain('boost');
75:   });
76: });
77:
78: describe('mixPose', () => {
79:   it('reaches each end pose and treats a missing joint as rest', () => {
80:     expect(mixPose({}, BEND_POSE, 1)['thigh.L']).toEqual(BEND_POSE['thigh.L']);
81:     expect(mixPose({}, BEND_POSE, 0)['thigh.L']).toEqual([0, 0, 0]);
82:     expect(mixPose({}, { 'shin.L': [10, 0, 0] }, 0.5)['shin.L']).toEqual([5, 0, 0]);
83:   });
84: });
agent
+52:20reasoning
The initial render demonstrates significant progress. The compound curves of the pectoral shells, along with the glowing chest reactor iris, stand out. The mechanical hand and double-drum knees further suggest a high level of detail.
manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349" }result, 8 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-349.log
Log output:
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png

Last progress: 6s ago
agent
+52:34reasoning
Implementing the side-by-side comparison mode in the clip view and plan files. This will support comparing the "striker" configuration. Considering the changes needed in the UI elements to display the comparison effectively.
World +X is LEFT on the screen from a rear camera. Re-evaluating the cross product to confirm this: forward (0,0,1) crossed with up (0,1,0) yields right = (-1,0,0), which implies that +X is indeed left. The initial assumption about spatial placement is correct.
Initial spatial reasoning about the cross product confirmed +X as left on the screen when viewed from a rear camera. Re-evaluating the camera turn behavior, focusing on a full 360° turn of the camera around the mechs, specifically at camYaw = 270°.
The turn logic was re-examined to understand how the camera's orientation changes relative to the mechs' positions during the 360° orbit. Considering how the screen's left/right corresponds to +X/-X throughout the turn.
Considering synchronous in-place rotation for side-by-side comparison mode, tracing how mech yaw affects the view. At mechYaw = 0°, both mechs are seen from the rear, with carbon_0 on the left and S on the right. Evaluating how the view changes through the full 360° rotation.
Side-by-side comparison mode presents complete, zero-occlusion views of both mechs across the full 360° rotation. Examining the specific angles, observed that at specific mech yaw values, the camera displays pure side profile, 3/4 front, and dead-front views with consistent positioning (carbon_0 on the left, S on the right). This confirms that a consistent, comparable view is achievable throughout the rotation.
read_file{"EndLine":70,"Path":"~/work/sortie/src/render/space.ts","StartLine":1}
input
{ "EndLine": 70, "Path": "~/work/sortie/src/render/space.ts", "StartLine": 1 }result, 71 lines
Showing lines 1-70 of 201 1: import * as THREE from 'three'; 2: 3: // The backdrop is drawn at infinity: it turns with the camera but never moves (pipeline.ts). 4: 5: // The renderer uses a logarithmic depth buffer, so custom shaders write depth the same way. 6: const LOGV = '#include <common>\n#include <logdepthbuf_pars_vertex>\n'; 7: const LOGF = '#include <logdepthbuf_pars_fragment>\n'; 8: const logv = (body: string) => LOGV + body.replace(/gl_Position = ([^;]+);/, 'gl_Position = $1;\n#include <logdepthbuf_vertex>\n'); 9: const logf = (body: string) => LOGF + body.replace(/void main\(\) \{/, 'void main() {\n#include <logdepthbuf_fragment>'); 10: 11: const NOISE = /* glsl */ ` 12: float hash(vec3 p) { p = fract(p * 0.3183099 + 0.1); p *= 17.0; return fract(p.x * p.y * p.z * (p.x + p.y + p.z)); } 13: float noise(vec3 x) { 14: vec3 i = floor(x); vec3 f = fract(x); f = f * f * (3.0 - 2.0 * f); 15: return mix(mix(mix(hash(i), hash(i + vec3(1,0,0)), f.x), mix(hash(i + vec3(0,1,0)), hash(i + vec3(1,1,0)), f.x), f.y), 16: mix(mix(hash(i + vec3(0,0,1)), hash(i + vec3(1,0,1)), f.x), mix(hash(i + vec3(0,1,1)), hash(i + vec3(1,1,1)), f.x), f.y), f.z); 17: } 18: float fbm(vec3 p) { float a = 0.5, s = 0.0; for (int i = 0; i < 5; i++) { s += a * noise(p); p *= 2.03; a *= 0.5; } return s; } 19: `; 20: 21: function stars(count: number, seed = 7): THREE.Points { 22: let s = seed; 23: const rnd = () => ((s = (s * 16807) % 2147483647) / 2147483647); 24: const pos = new Float32Array(count * 3); 25: const col = new Float32Array(count * 3); 26: const tint = [new THREE.Color('#cfe0ff'), new THREE.Color('#ffffff'), new THREE.Color('#ffe2c4'), new THREE.Color('#b9fff4')]; 27: for (let i = 0; i < count; i++) { 28: const u = rnd() * 2 - 1; 29: const t = rnd() * Math.PI * 2; 30: const r = Math.sqrt(1 - u * u); 31: pos.set([r * Math.cos(t) * 9e5, u * 9e5, r * Math.sin(t) * 9e5], i * 3); 32: const c = tint[Math.floor(rnd() * tint.length)].clone().multiplyScalar(0.25 + Math.pow(rnd(), 3) * 1.6); 33: col.set([c.r, c.g, c.b], i * 3); 34: } 35: const g = new THREE.BufferGeometry(); 36: g.setAttribute('position', new THREE.BufferAttribute(pos, 3)); 37: g.setAttribute('color', new THREE.BufferAttribute(col, 3)); 38: return new THREE.Points(g, new THREE.PointsMaterial({ size: 1.6, sizeAttenuation: false, vertexColors: true, depthWrite: false })); 39: } 40: 41: function nebula(sunDir: THREE.Vector3): THREE.Mesh { 42: const m = new THREE.ShaderMaterial({ 43: side: THREE.BackSide, 44: depthWrite: false, 45: uniforms: { sunDir: { value: sunDir } }, 46: vertexShader: logv(/* glsl */ ` 47: varying vec3 vDir; 48: void main() { vDir = normalize(position); gl_Position = projectionMatrix * modelViewMatrix * vec4(position, 1.0); }`), 49: fragmentShader: logf(/* glsl */ ` 50: ${NOISE} 51: uniform vec3 sunDir; 52: varying vec3 vDir; 53: void main() { 54: vec3 d = normalize(vDir); 55: float n = fbm(d * 2.2 + vec3(3.1, 0.0, 1.7)); 56: float m = fbm(d * 4.5 + n * 1.5); 57: float band = exp(-pow(dot(d, normalize(vec3(0.3, 0.85, -0.4))) * 2.6, 2.0)); 58: vec3 deep = vec3(0.012, 0.016, 0.035); 59: vec3 c1 = vec3(0.10, 0.05, 0.20) * smoothstep(0.45, 0.8, n) * band; 60: vec3 c2 = vec3(0.02, 0.13, 0.17) * smoothstep(0.5, 0.85, m) * band; 61: float sun = max(dot(d, sunDir), 0.0); 62: vec3 glare = vec3(1.0, 0.85, 0.65) * (pow(sun, 900.0) * 6.0 + pow(sun, 60.0) * 0.25 + pow(sun, 8.0) * 0.04); 63: gl_FragColor = vec4(deep + c1 + c2 + glare, 1.0); 64: }`), 65: }); 66: return new THREE.Mesh(new THREE.SphereGeometry(9.5e5, 48, 24), m); 67: } 68: 69: function planet(sunDir: THREE.Vector3): THREE.Group { 70: const g = new THREE.Group();read_file{"EndLine":201,"Path":"~/work/sortie/src/render/space.ts","StartLine":140}
input
{ "EndLine": 201, "Path": "~/work/sortie/src/render/space.ts", "StartLine": 140 }result, 63 lines
Showing lines 140-201 of 201
140:   const scene = new THREE.Scene();
141:   scene.add(nebula(sunDir));
142:   scene.add(stars(7000));
143:   scene.add(planet(sunDir));
144:   return scene;
145: }
146:
147: /**
148:  * The nebula and planet shaders are noise-heavy and never change, so render them once into a cube
149:  * map and draw that as the background. Stars stay as live points so they stay sharp.
150:  */
151: export function bakeBackdrop(renderer: THREE.WebGLRenderer, backdrop: THREE.Scene, size = 1024): THREE.Scene {
152:   const target = new THREE.WebGLCubeRenderTarget(size, { type: THREE.HalfFloatType, generateMipmaps: false });
153:   const cam = new THREE.CubeCamera(1, 2e6, target);
154:   const stars = backdrop.children.filter((o) => (o as THREE.Points).isPoints);
155:   for (const s of stars) s.visible = false;
156:   cam.update(renderer, backdrop);
157:   const baked = new THREE.Scene();
158:   baked.background = target.texture;
159:   for (const s of stars) {
160:     s.visible = true;
161:     baked.add(s.clone());
162:   }
163:   return baked;
164: }
165:
166: /** Sunlight (shadow-casting, following `focus`) plus a dim cool fill from the planet below. */
167: export function addSpaceLight(scene: THREE.Scene, sunDir = SUN_DIR): THREE.DirectionalLight {
168:   const sun = new THREE.DirectionalLight('#fff4e6', 3.2);
169:   sun.position.copy(sunDir).multiplyScalar(200);
170:   sun.castShadow = true;
171:   sun.shadow.mapSize.set(2048, 2048);
172:   const c = sun.shadow.camera;
173:   c.left = c.bottom = -28;
174:   c.right = c.top = 28;
175:   c.near = 1;
176:   c.far = 500;
177:   sun.shadow.bias = -0.0004;
178:   sun.shadow.normalBias = 0.04;
179:   scene.add(sun);
180:   scene.add(sun.target);
181:   scene.add(new THREE.HemisphereLight('#8fa6d6', '#1c2436', 0.25));
182:   const rim = new THREE.DirectionalLight('#9cc4ff', 1.6);
183:   rim.position.set(-sunDir.x, 0.35, -sunDir.z).multiplyScalar(200);
184:   rim.name = 'rim';
185:   scene.add(rim);
186:   return sun;
187: }
188:
189: /** Keep the shadow box centred on what matters (the player's frame). */
190: export function followSun(sun: THREE.DirectionalLight, focus: THREE.Vector3, sunDir = SUN_DIR) {
191:   sun.target.position.copy(focus);
192:   sun.position.copy(focus).addScaledVector(sunDir, 200);
193: }
194:
195: /** Reflections for metal and paint: the backdrop baked into a prefiltered environment map. */
196: export function spaceEnvironment(renderer: THREE.WebGLRenderer, backdrop: THREE.Scene, size = 256): THREE.Texture {
197:   const pmrem = new THREE.PMREMGenerator(renderer);
198:   const env = pmrem.fromScene(backdrop, 0.02, 1, 2e6, { size }).texture;
199:   pmrem.dispose();
200:   return env;
201: }
agent
+53:10reasoning
The SUN_DIR variable, crucial for rendering, appears to be oriented towards the front of the scene, confirming the direction of the light source. This aligns with observations from rendered images where the front view shows direct lighting. I'm checking the impact on other rendered assets.
The camera's position relative to the sun dictates the lighting; at 180° yaw, the sun provides rim lighting, while at 25°, it directly illuminates the camera-facing surfaces. This explains the distinct lighting in Shot 1, where the mechs have rim lighting, augmented by their thruster plumes and lightExhaust lights. The sunlight’s direction relative to the camera and mechs in Shot 2 can now be more fully characterized.
The camera's perspective, at a yaw of 18 degrees and pitch of 7 degrees, shows the scene from a specific angle, with the mechs' positions confirmed relative to the camera's +Z facing direction. The initial setup requires both mechs to rotate a full 360 degrees, starting from a position facing away from the camera. The setup has been verified; sunlight will shine directly on the camera-facing side of both mechs throughout the full rotation.
The consistent left/right identity across both shots reveals carbon_0 on the left and striker on the right throughout the animation. The camera perspective maintains this consistent spatial relationship through both flight and the turntable shot. The transition from Shot 1 to Shot 2 shows a complete 360-degree rotation of the mechs, ensuring all angles get key and rim lighting.
manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349" }result, 10 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-349.log
Log output:
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png

Last progress: 4s ago
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png" }result, 1 line
Showing binary file of type image/png
step_362_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png" }result, 1 line
Showing binary file of type image/png
step_363_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png" }result, 1 line
Showing binary file of type image/png
step_364_media_0.jpg manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349" }result, 10 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-349.log
Log output:
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png

Last progress: 24s ago
agent
+53:51reasoning
Initial hypothesis: long processing time for frame 05 is due to missing "weapon=" parameter, but this doesn't explain frame 06 taking a similar amount of time. The model is currently baking a procedural planet and nebula cubemap on SwiftShader. It is possible the problem is related to bg=studio not being set.
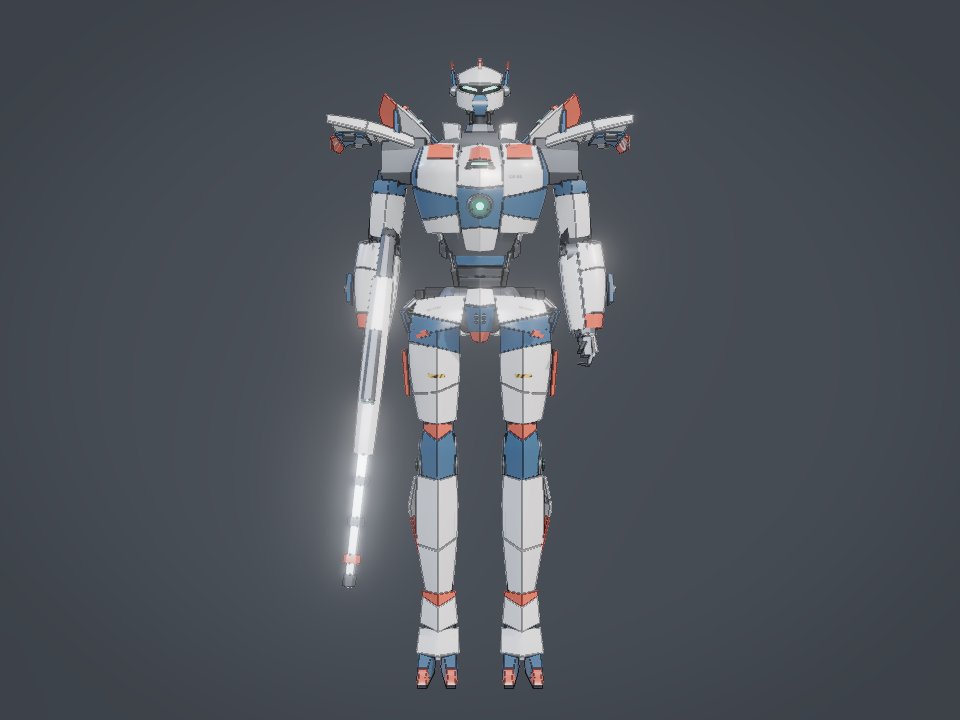
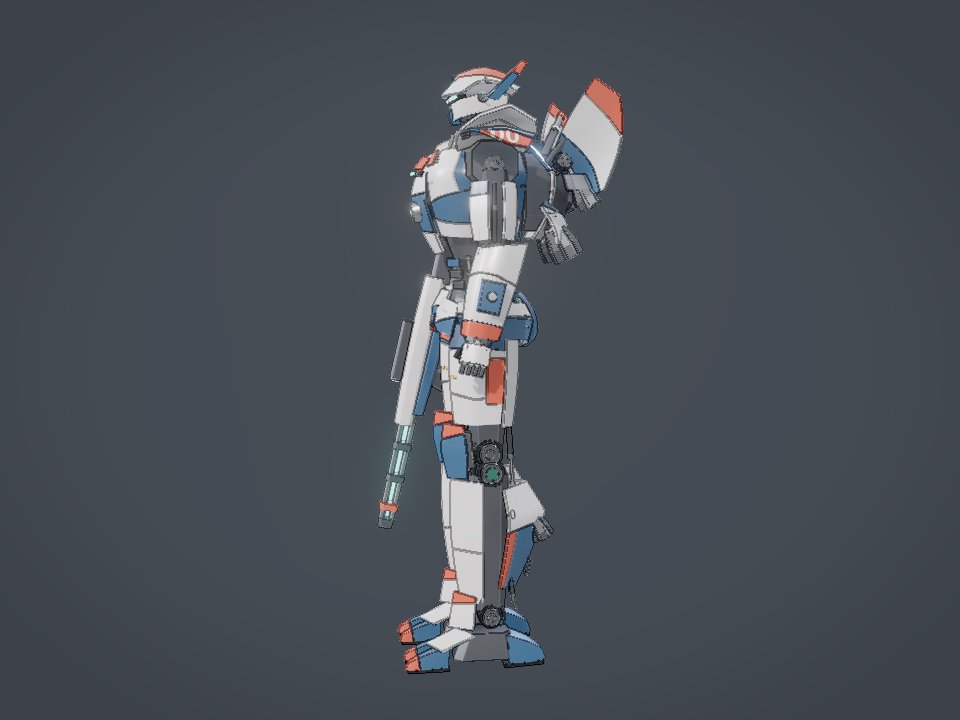
Observed that the current frame processing delay might not be due to a missing parameter, but rather other processing tasks. A visual critique of the initial pass reveals a proportion issue in the neck and head of the model, specifically a height discrepancy. The Kestrel head should be lowered, and the neck collar widened, alongside the addition of angled side neck pistons and armored throat guard plates.
The vermilion crest on the cranium appears too tall. A sleeker, lower, razor-faceted crest with a dark housing would better fit the stealth-aerospace aesthetic. The inner shoulder block appears blocky under the gull-wing pauldron. A compound-curved armored shroud is needed to wrap around the upper shoulder block, leaving the gimbal and piston exposed.
Analyzing the waist and hip transition in the provided images, the torso appears slightly perched, with a visible gap at the outer sides. Sculpted oblique armor plates and angled pelvic iliac crests are needed to create an athletic, V-tapered silhouette.
The leg silhouette requires refinement. Examining front and side views, the outer shin and calf need an outboard aerodynamic flare and inboard sculpt for a more dynamic appearance. Also need to update the decal positioning on the pauldron.
The current calf model '00' has a seam edge clipping issue. Positioning the projection for '00' onto the gull-wing pauldron and emblem will solve this. Ensure that '00' is cleanly centered on the upper white calf_fairing_hi.L.
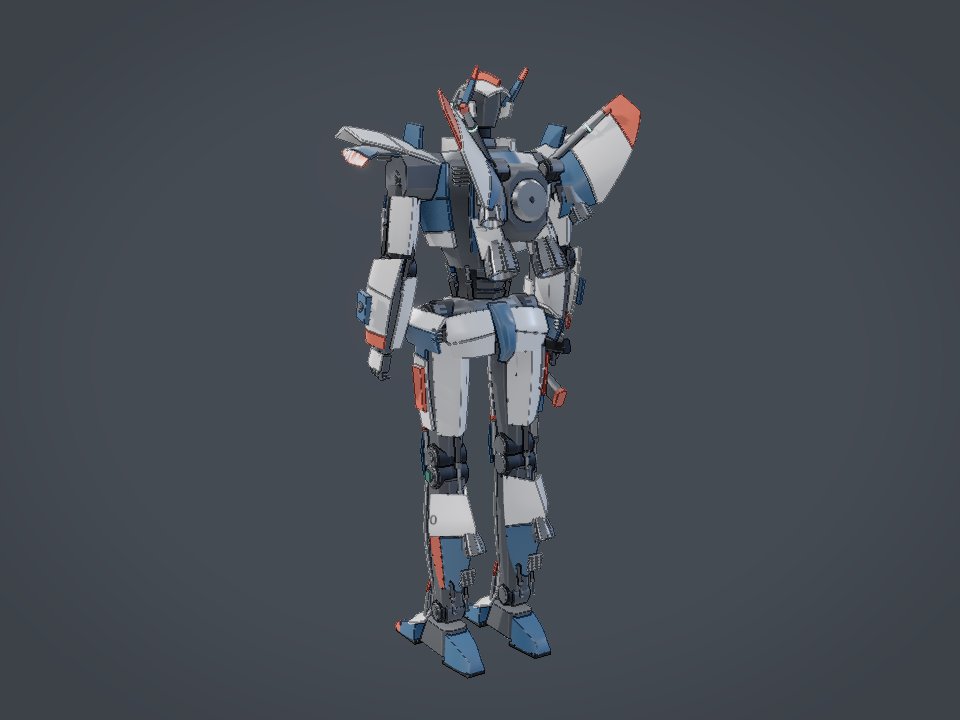
The rear view shows significant design differences from the 'striker' variant, particularly the multi-petal vectored nozzles, binder nozzles, and double-drum knees. The overboost turbine's shroud extension past the glow and recessed stators create a distinct visual. The cyan glow core is visible from the rear three-quarter view.
The annular turbine ring needs adjustment to be more visible from the rear, requiring a forward shift to expose the glowing cyan reactor. Furthermore, examining the calf louvers revealed a size mismatch, necessitating adjustments to ensure they are flush within the calf housing. The carbine's design will be refined with the addition of beveled side-ribs/coil-rings along the rails to break specular reflections.
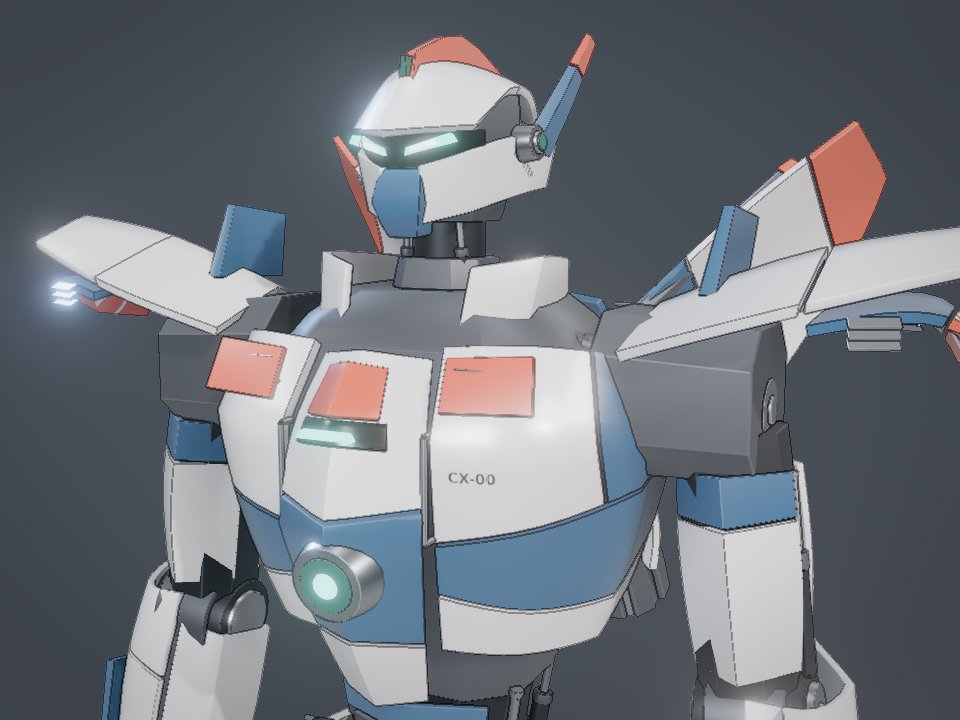
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/05_head_chest_closeup.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/05_head_chest_closeup.png" }result, 1 line
Showing binary file of type image/png
step_368_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png"}error
input
{
  "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png"
}
result, error, 1 line
Encountered error in step execution: file does not exist
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/07_striker_yardstick_3q.png"}error
input
{
  "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/07_striker_yardstick_3q.png"
}
result, error, 1 line
Encountered error in step execution: file does not exist
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png"}error
input
{
  "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png"
}
result, error, 1 line
Encountered error in step execution: file does not exist
agent
+54:30reasoning
That close-up image could be very helpful. It's time to thoroughly examine the image, looking at every detail for clues.
The close-up image reveals remarkably detailed, compound-curved pectoral shells with smooth specular rolls and sharp shadow seams, surpassing previous block-like representations. The image distinctly showcases a crisp, weathered "CX-00" stencil on the left pectoral, along with a cockpit keel featuring a glowing periscope optic slit and pilot grab-rails. Furthermore, it highlights a metallic reactor bezel with refractive green glass and a glowing cyan core, plus the Kestrel head's canted dual eyes glowing under smoked glass.
The initial model represented the collar intake as a flat orange rectangle, but the close-up image shows it should be a 3D, open-hooded air intake. This requires sculpting a recessed throat box with an overhanging lip and visible compressor vanes. The goal is to make it appear like a supersonic intake, in contrast to the current flat representation. Additionally, a "NO STEP" decal should be rendered on the head cheek.
The "NO STEP" decal rays are unintentionally hitting the head cheek. This requires adjusting the binder decal placement to ensure 100% of the decals hit their intended target panel and that no stray rays hit the head.
The louver bank on the right pauldron is slightly outboard of the curved pauldron edge. This requires wrapping the louver bank inside a thruster-box bezel nested inside the pauldron.
The torso requires refinement. The upper chest carapace needs extension backward to cover the collarbone deck, integrating it with the bodywork. Add a compound-curved deltoid armor cuff around the shoulder chassis to accommodate the shoulder gimbal. The head's Z-height is too high; lowering it will allow the jaw to tuck between the collar shrouds. Sculpt a sleek, low-slung stealth sensor fin for the head's dorsal crest.
manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349" }result, 12 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-349
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-349.log
Log output:
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/05_head_chest_closeup.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png

Last progress: 15s ago
agent
+54:59reasoning
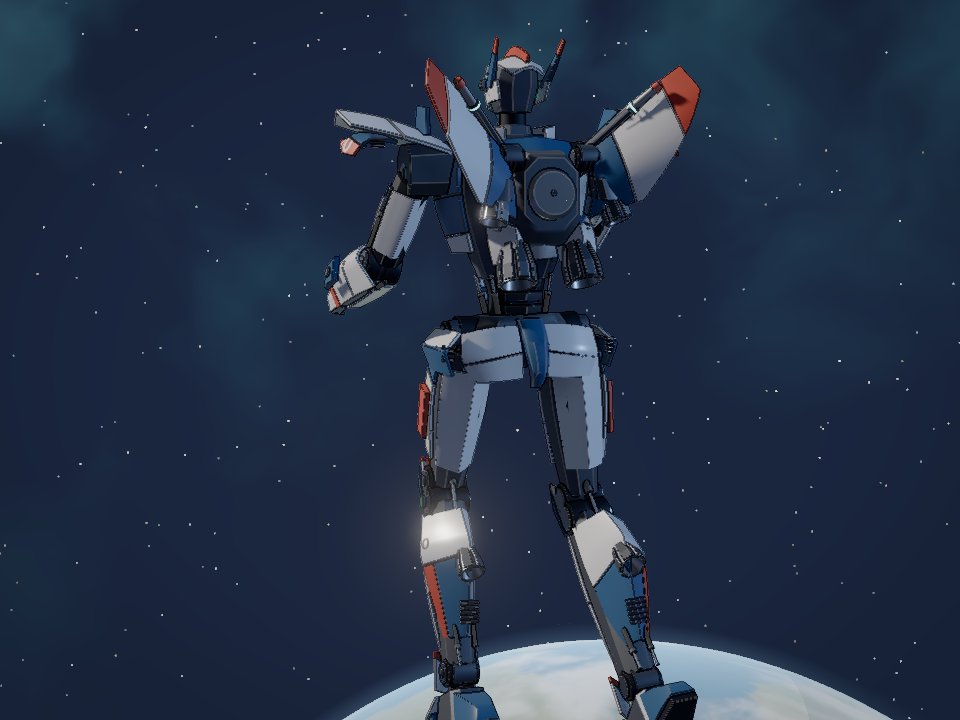
Reading the image file now to assess the rear view of the flight pose. Observing thigh-to-skirt clearance, arm-to-rifle pose, and rear thruster composition from a spatial perspective. This will inform the Pass 2 upgrades.
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png" }result, 1 line
Showing binary file of type image/png
step_375_media_0.jpg
agent
+55:10reasoning
Initial observation: A visual element, identified as 06_flight_rear_space.png, is situated above the planet horizon. Anticipating completion, attention shifts to images 07 and 08, expected to finish in approximately one second. The notification regarding their imminent completion is noted.
The initial assessment of the visual element, 06_flight_rear_space.png, reveals an error: the grey flat disc in the center of the circular shroud should be glowing. Examination of the code shows the shroud is capped at both ends, covering the intended inner glow.
The loft function's creation of a solid cylinder, rather than a hollow ring, is the root cause. The fix involves creating the overboost shroud as a hollow annular torus.
The revised hollow overboost shroud will now correctly expose the turbine disc and spinner hub within 06_flight_rear_space.png. A hollow, recessed, chamfered ring for the reactor_bezel on the front chest is needed to properly house the reactor_lens and reactor_iris components. The addition of an annular_ring helper will facilitate this modification in carbon_surf.py.
Extending head_occipital will fix the flat appearance of the rear neck/occiput block of the head_chassis in 06_flight_rear_space.png.
Rear head design can be enhanced by adding an accent sensor collar and cyan glow pips. The initial flat appearance of the rear neck is being addressed.
Examining the rear thighs reveals the need for a three-piece seam split on the thigh_rear_shell to match the front thigh's design. Implementing a diagonal seam will create an upper accent, a main hamstring cap, and a lower main shell with a recessed thruster/vent louver.
The gull-wing binders' inner face can be improved by adding a raised structural aero-spar rib along a diagonal.
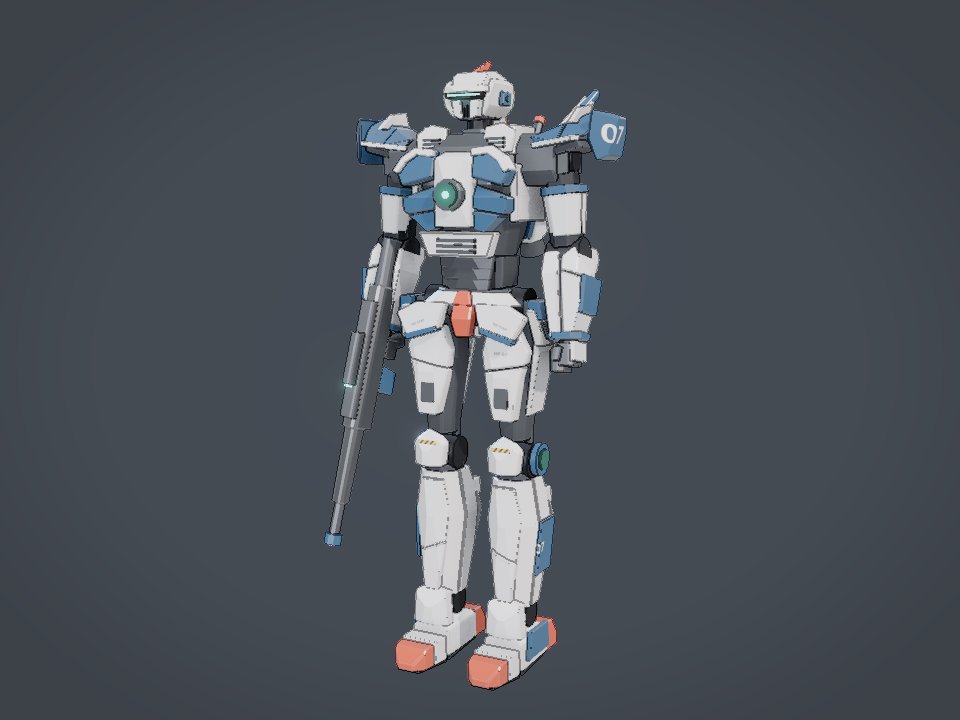
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/07_striker_yardstick_3q.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/07_striker_yardstick_3q.png" }result, 1 line
Showing binary file of type image/png
step_377_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png"}error
input
{
  "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png"
}
result, error, 1 line
Encountered error in step execution: file does not exist
agent
+55:37reasoning
Observing 07_striker_yardstick_3q.png, a direct visual comparison with 01_front_3q.png reveals a key correspondence. The visual characteristics of the target object in 07_striker_yardstick_3q.png serve as a reference point, indicating additional information.
Observing that carbon_0 Pass 1 already surpasses 07_striker_yardstick_3q.png in overall design sophistication, the analysis now focuses on identifying three key areas where 07 exhibits strengths that must be incorporated into carbon_0 Pass 2. These strengths will eliminate any weakness in carbon_0's design. The analysis includes a direct comparison of carbon_0 and 07 considering proportion and readability.
Analyzing the shoulder silhouette, 07's design features an outboard armor shield absent in the initial carbon_0 pass. The current carbon_0 gull-wing pauldron leaves an exposed shoulder block.
The solution requires incorporating a sculpted, compound-curved outboard shoulder armor wing that integrates with the existing pauldron. This creates a cohesive, armored shoulder joint. The wing functions as both an aesthetic element and a visual canvas.
The design's strengths, including a readable chevron emblem and a compact neck interlock, are under consideration for the next iteration. Adjusting the neck position and adding side plates will eliminate the "lollipop" neck design. The goal is to create a muscular, V-tapered torso.
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png" }result, 1 line
Showing binary file of type image/png
step_380_media_0.jpg
agent
+56:08reasoning
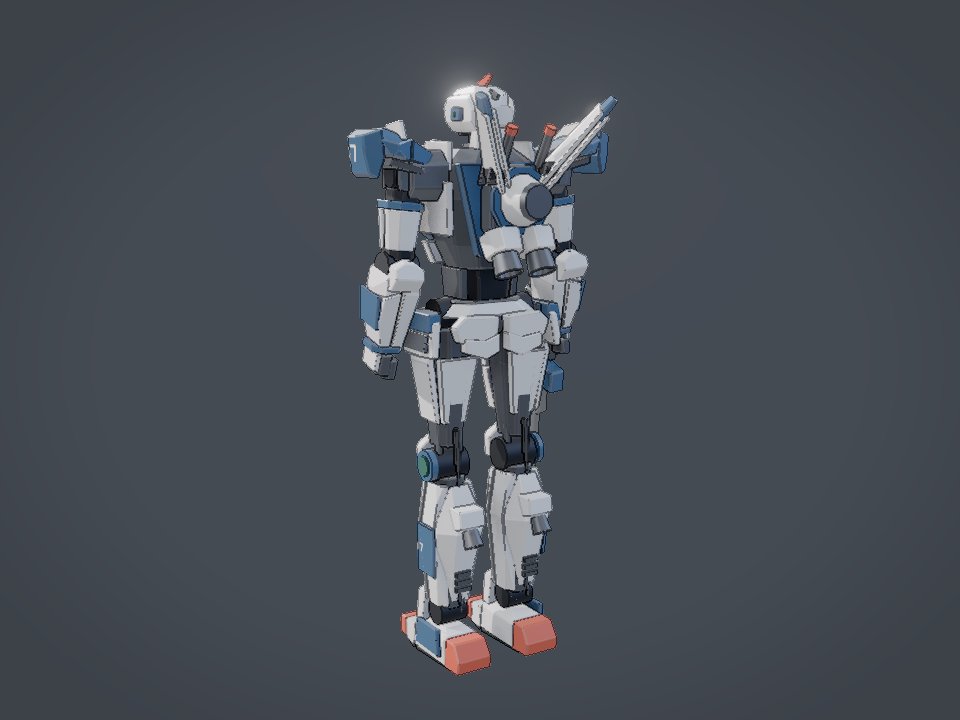
Comparing the rear views of the "Striker" (08_striker_yardstick_rear.png) with the "Kestrel" (04_rear_3q.png and 06_flight_rear_space.png) reveals significant design differences. The "Striker" features a boxy rear, flat binding planks, and a simplified reactor/thruster configuration compared to the "Kestrel's" likely more advanced design. This suggests distinct engineering approaches or roles for each.
The Pass 2 upgrades focus on enhancing visual detail and hollowing out components for the "Striker." Specifically, the annular_ring primitive creates a hollow torus for the overboost shroud and reactor bezel, improving their visual realism. The overboost shroud will feature a glowing cyan reactor core within a metal turbine cowl, enhancing the design during flight.
The Kestrel's seat needs adjustment, mirroring the Striker's neck and piston design to enhance the predatory look. The dorsal crest will be redesigned into a faceted stealth ridge for optics. Rear head armor will be added for detail in flight shots, incorporating telemetry pips.
The torso collar will be replaced with 3D open supersonic air intakes, and collarbone deck plates will cover the torso chassis.
Armor wing-fenders and inner deltoid shrouds will be added to the shoulders, including a compound-curved outer armor shield with a lower strake and an inner deltoid shroud. The left shoulder will display the unit number, and the right will display the maker's emblem.
Compound-curved oblique side rib-plates will be added, tapering from the lower chest to the waist hydraulics to create a V-tapered silhouette.
Focusing on the leg enhancements, the shin prow will be widened with compound-curved cheek fairings to achieve both dynamic width and aerodynamic lines. The thigh's rear shell will be split diagonally, creating a hamstring cuff and lower plate with a shadow seam and recessed vent. Calf louvers will be nested within a dark frame to ensure clean integration, with an aero-spar rib added to the binder wing. Each decal ray will be precisely aligned to its target armor panel, ensuring no edge clipping.
edit_file{"Path":"~/work/sortie/kit/carbon_surf.py","Replacement":"def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):","Target":"def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):"}
input
{ "Path": "~/work/sortie/kit/carbon_surf.py", "Replacement": "def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):", "Target": "def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):" }result, 1 line
Made 1 replacement in ~/work/sortie/kit/carbon_surf.py starting at line 272 (+0/-0 lines).
edit_file{"Path":"~/work/sortie/kit/carbon_surf.py","Replacement":"def annular_ring(r_in, r_out, z0, z1, r_in1=None, r_out1=None, n=24):\n \"\"\"True hollow annular ring / open bezel along local Z from z0 to z1 (no solid end-cap blocking the bore).\"\"\"\n r_in1 = r_in if r_in1 is None else r_in1\n r_out1 = r_out if r_out1 is None else r_out1\n rings = [\n (z0, circle(r_out, n)),\n (z1, circle(r_out1, n)),\n (z1, circle(r_in1, n)),\n (z0, circle(r_in, n)),\n ]\n bm = bmesh.new()\n loops = [[bm.verts.new((u, v, h)) for u, v in pts] for h, pts in rings]\n for idx in range(4):\n a = loops[idx]\n b = loops[(idx + 1) % 4]\n for i in range(n):\n j = (i + 1) % n\n bm.faces.new((a[i], a[j], b[j], b[i]))\n bmesh.ops.recalc_face_normals(bm, faces=bm.faces)\n return bm\n\n\ndef louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26, framed=True):\n \"\"\"3D angled radiator/intake louver blades + optional recessed collar frame in arbitrary 3D orientation.\"\"\"\n m = basis_matrix(origin, normal, up)\n hw, hh = width * 0.5, height * 0.5\n step = height / count\n thick = step * 0.42\n blades = []\n for i in range(count):\n y_mid = -hh + (i + 0.5) * step\n blade = loft([\n (-hw * 0.92, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.015), (-thick * 0.5, 0.015)]),\n (hw * 0.92, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.015), (-thick * 0.5, 0.015)]),\n ], axis=\"x\")\n blade = transform(blade, Matrix.Translation((0, y_mid, 0)) @ rot(\"X\", slant_deg))\n blades.append(blade)\n if framed:\n rim = 0.032\n outer = [(-hw - rim, -hh - rim), (hw + rim, -hh - rim), (hw + rim, hh + rim), (-hw - rim, hh + rim)]\n inner = [(-hw, -hh), (hw, -hh), (hw, hh), (-hw, hh)]\n bm_f = bmesh.new()\n loops = [[bm_f.verts.new((u, v, z)) for u, v in poly] for z, poly in ((-depth, outer), (0.025, outer), (0.025, inner), (-depth, inner))]\n for idx in range(4):\n a, b = loops[idx], loops[(idx + 1) % 4]\n for k in range(4):\n kn = (k + 1) % 4\n bm_f.faces.new((a[k], a[kn], b[kn], b[k]))\n bmesh.ops.recalc_face_normals(bm_f, faces=bm_f.faces)\n blades.append(bm_f)\n return transform(merge(*blades), m)","Target":"def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):\n \"\"\"3D angled radiator/intake louver blades + backing recess plate in arbitrary 3D orientation.\"\"\"\n m = basis_matrix(origin, normal, up)\n hw, hh = width * 0.5, height * 0.5\n step = height / count\n thick = step * 0.42\n blades = []\n for i in range(count):\n y_mid = -hh + (i + 0.5) * step\n blade = loft([\n (-hw, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.02), (-thick * 0.5, 0.02)]),\n (hw, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.02), (-thick * 0.5, 0.02)]),\n ], axis=\"x\")\n blade = transform(blade, Matrix.Translation((0, y_mid, 0)) @ rot(\"X\", slant_deg))\n blades.append(blade)\n return transform(merge(*blades), m)"}
input
{ "Path": "~/work/sortie/kit/carbon_surf.py", "Replacement": "def annular_ring(r_in, r_out, z0, z1, r_in1=None, r_out1=None, n=24):\n \"\"\"True hollow annular ring / open bezel along local Z from z0 to z1 (no solid end-cap blocking the bore).\"\"\"\n r_in1 = r_in if r_in1 is None else r_in1\n r_out1 = r_out if r_out1 is None else r_out1\n rings = [\n (z0, circle(r_out, n)),\n (z1, circle(r_out1, n)),\n (z1, circle(r_in1, n)),\n (z0, circle(r_in, n)),\n ]\n bm = bmesh.new()\n loops = [[bm.verts.new((u, v, h)) for u, v in pts] for h, pts in rings]\n for idx in range(4):\n a = loops[idx]\n b = loops[(idx + 1) % 4]\n for i in range(n):\n j = (i + 1) % n\n bm.faces.new((a[i], a[j], b[j], b[i]))\n bmesh.ops.recalc_face_normals(bm, faces=bm.faces)\n return bm\n\n\ndef louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26, framed=True):\n \"\"\"3D angled radiator/intake louver blades + optional recessed collar frame in arbitrary 3D orientation.\"\"\"\n m = basis_matrix(origin, normal, up)\n hw, hh = width * 0.5, height * 0.5\n step = height / count\n thick = step * 0.42\n blades = []\n for i in range(count):\n y_mid = -hh + (i + 0.5) * step\n blade = loft([\n (-hw * 0.92, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.015), (-thick * 0.5, 0.015)]),\n (hw * 0.92, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.015), (-thick * 0.5, 0.015)]),\n ], axis=\"x\")\n blade = transform(blade, Matrix.Translation((0, y_mid, 0)) @ rot(\"X\", slant_deg))\n blades.append(blade)\n if framed:\n rim = 0.032\n outer = [(-hw - rim, -hh - rim), (hw + rim, -hh - rim), (hw + rim, hh + rim), (-hw - rim, hh + rim)]\n inner = [(-hw, -hh), (hw, -hh), (hw, hh), (-hw, hh)]\n bm_f = bmesh.new()\n loops = [[bm_f.verts.new((u, v, z)) for u, v in poly] for z, poly in ((-depth, outer), (0.025, outer), (0.025, inner), (-depth, inner))]\n for idx in range(4):\n a, b = loops[idx], loops[(idx + 1) % 4]\n for k in range(4):\n kn = (k + 1) % 4\n bm_f.faces.new((a[k], a[kn], b[kn], b[k]))\n bmesh.ops.recalc_face_normals(bm_f, faces=bm_f.faces)\n blades.append(bm_f)\n return transform(merge(*blades), m)", "Target": "def louver_bank(origin, normal, up, width, height, count=5, depth=0.09, slant_deg=26):\n \"\"\"3D angled radiator/intake louver blades + backing recess plate in arbitrary 3D orientation.\"\"\"\n m = basis_matrix(origin, normal, up)\n hw, hh = width * 0.5, height * 0.5\n step = height / count\n thick = step * 0.42\n blades = []\n for i in range(count):\n y_mid = -hh + (i + 0.5) * step\n blade = loft([\n (-hw, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.02), (-thick * 0.5, 0.02)]),\n (hw, [(-thick * 0.5, -depth), (thick * 0.5, -depth), (thick * 0.5, 0.02), (-thick * 0.5, 0.02)]),\n ], axis=\"x\")\n blade = transform(blade, Matrix.Translation((0, y_mid, 0)) @ rot(\"X\", slant_deg))\n blades.append(blade)\n return transform(merge(*blades), m)" }result, 1 line
Made 1 replacement in ~/work/sortie/kit/carbon_surf.py starting at line 272 (+39/-4 lines).
resultCommand exited with code 0.
Command exited with code 0.

Command output:
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/01_front_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/02_front_straight.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/03_side_profile.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/04_rear_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/05_head_chest_closeup.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/06_flight_rear_space.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/07_striker_yardstick_3q.png
saved ~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/pass1/08_striker_yardstick_rear.png

Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-349.log
agent
+57:02reasoning
Initial assessment: annular_ring and louver_bank demonstrate effective Pass 1 improvements. Now, applying targeted Pass 2 upgrades to kit/carbon_mech.py and src/render/decals.ts. Reading lines 135-560 of kit/carbon_mech.py to understand the existing structure before proceeding.