A mech game prototype, pushed by Gemini 4 Carbon
agent
+3:21reasoning
The swift processing time for striker_a_kit suggests efficient handling within the system's current configuration. Shifting focus to other components, the analysis will now involve examining several specific scripts (kit/mech.py, kit/lab/board_sleek.py, and others within kit/lab) to understand their roles and interactions. This investigation will ensure a comprehensive understanding of the project's overall structure and functionality.
read_file{"EndLine":160,"Path":"~/work/sortie/kit/mech.py","StartLine":1}
input
{ "EndLine": 160, "Path": "~/work/sortie/kit/mech.py", "StartLine": 1 }result, 161 lines
Showing lines 1-160 of 400 1: """Mech frames. A frame is a tree of joint empties with rigid armour parented to them, so the game 2: poses it by rotating joints (no skinning). Left is +X (the model faces -Y). 3: 4: Joint tree (names are the contract with src/render/mech.ts): 5: frame > pelvis > waist > torso > neck > head 6: torso > shoulder.L > upperarm.L > forearm.L > hand.L > grip.L 7: torso > backpack > binder.L 8: torso > cockpit 9: pelvis > thigh.L > shin.L > foot.L 10: Thruster exits are empties named nozzle.* with a "dir" extra (exhaust direction, glTF axes). 11: 12: Proportions follow measured Gundam 00 line art (review/out/refs/proportions.md): head about a tenth 13: of the height, hip joint at 60%, shoulder span about half the height on shells that stand off a 14: compact chest, a waist a ninth of the height, every limb in layered shells over a dark inner frame. 15: """ 16: from mathutils import Matrix, Vector 17: 18: from lib import (circle, clip, copy, cylinder, empty, halves, loft, merge, mirror_x, nozzle, octo, piston, prism, rot, slats, solid, 19: transform, two_view) 20: 21: BEVEL = 0.05 22: 23: 24: def gltf_dir(v): 25: v = Vector(v).normalized() 26: return [round(v.x, 4), round(v.z, 4), round(-v.y, 4)] 27: 28: 29: def place(bm, at, direction): 30: """Turn a part built along -Z to point along `direction`, then move it to `at`.""" 31: q = Vector((0, 0, -1)).rotation_difference(Vector(direction).normalized()) 32: return transform(bm, Matrix.Translation(Vector(at)) @ q.to_matrix().to_4x4()) 33: 34: 35: def pair(name, bm_left, role, jl, jr, **kw): 36: """Make the left part and its mirror on the right.""" 37: bm_right = mirror_x(bm_left) 38: return solid(f"{name}.L", bm_left, role, jl, **kw), solid(f"{name}.R", bm_right, role, jr, **kw) 39: 40: 41: def nozzle_pair(name, at, direction, r, length, jl, jr, shell="frame", housing=True): 42: ex = Vector(at) 43: for side, j, sx in (("L", jl, 1), ("R", jr, -1)): 44: p = Vector((ex.x * sx, ex.y, ex.z)) 45: d = Vector((direction[0] * sx, direction[1], direction[2])) 46: bell, glow = nozzle(r, length) 47: solid(f"{name}.{side}", place(bell, p, d), shell, j, smooth=True) 48: solid(f"{name}.{side}.glow", place(glow, p, d), "glow_thruster", j, outline=False) 49: # an armoured housing around the throat, so the nozzle reads as mounted, not floating 50: if housing: 51: house = loft([(length * .5, octo(r * 2.5, r * 2.5, r * .6)), (-length * .3, octo(r * 2.3, r * 2.3, r * .55))]) 52: solid(f"{name}_housing.{side}", place(house, p, d), "main", j, bevel=.02, panels=False) 53: empty(f"nozzle.{name}.{side}", p + d.normalized() * length, j, dir=gltf_dir(d), radius=r) 54: 55: 56: def seam(bm, a, b, gap=.05): 57: """Split a solid along the line a->b of the front view (x, z): two plates with a real seam.""" 58: a, b = Vector((a[0], 0, a[1])), Vector((b[0], 0, b[1])) 59: d = (b - a).normalized() 60: n = Vector((-d.z, 0, d.x)) 61: return halves(bm, a, n, gap) 62: 63: 64: def pair_pieces(name, pieces, role, jl, jr, **kw): 65: for i, bm in enumerate(pieces): 66: pair(f"{name}{i}", bm, role, jl, jr, **kw) 67: 68: 69: def joints(): 70: J = {"frame": empty("frame", (0, 0, 0), frame="striker", height=17.6)} 71: J["pelvis"] = empty("pelvis", (0, 0, 10.6), J["frame"]) 72: J["waist"] = empty("waist", (0, 0, 11.1), J["pelvis"]) 73: J["torso"] = empty("torso", (0, 0, 11.9), J["waist"]) 74: J["neck"] = empty("neck", (0, 0, 15.3), J["torso"]) 75: J["head"] = empty("head", (0, 0, 15.85), J["neck"]) 76: J["backpack"] = empty("backpack", (0, 1.5, 13.8), J["torso"]) 77: J["cockpit"] = empty("cockpit", (0, -0.75, 13.7), J["torso"]) 78: for s, sx in (("L", 1), ("R", -1)): 79: J["shoulder", s] = empty(f"shoulder.{s}", (2.0 * sx, 0, 14.6), J["torso"]) 80: J["upperarm", s] = empty(f"upperarm.{s}", (2.45 * sx, 0, 14.4), J["shoulder", s]) 81: J["forearm", s] = empty(f"forearm.{s}", (2.5 * sx, 0, 11.95), J["upperarm", s]) 82: J["hand", s] = empty(f"hand.{s}", (2.5 * sx, 0, 9.6), J["forearm", s]) 83: J["grip", s] = empty(f"grip.{s}", (2.36 * sx, -0.02, 9.12), J["hand", s]) 84: J["thigh", s] = empty(f"thigh.{s}", (1.15 * sx, 0, 10.55), J["pelvis"]) 85: J["shin", s] = empty(f"shin.{s}", (1.2 * sx, 0, 6.1), J["thigh", s]) 86: J["foot", s] = empty(f"foot.{s}", (1.2 * sx, 0.1, 1.55), J["shin", s]) 87: J["binder", s] = empty(f"binder.{s}", (0.9 * sx, 2.25, 14.7), J["backpack"]) 88: return J 89: 90: 91: def lr(J, part): 92: return J[part, "L"], J[part, "R"] 93: 94: 95: def build_pelvis(J): 96: P = J["pelvis"] 97: solid("pelvis_core", loft([(9.95, octo(.9, 1.3, .25)), (10.4, octo(2.2, 1.7, .4)), (11.0, octo(2.3, 1.75, .45))]), 98: "frame", P, BEVEL) 99: # the waist belt flares from the abdomen out to hip width; everything below hangs from it 100: solid("belt", loft([(10.55, octo(3.2, 2.05, .5)), (10.98, octo(2.1, 1.7, .42))]), "main", P, BEVEL) 101: solid("belt_buckle", two_view([(-.3, 10.58), (.3, 10.58), (.18, 10.96), (-.18, 10.96)], 102: [(-1.14, 10.58), (-.96, 10.58), (-.86, 10.96), (-1.02, 10.96)]), "trim", P, .02) 103: pair("hip_block", loft([(10.2, octo(.42, .95, .1, x=1.74)), (10.72, octo(.42, .95, .1, x=1.74))]), "frame", P, P, bevel=.02) 104: solid("codpiece", two_view([(-.2, 9.62), (.2, 9.62), (.32, 10.2), (.3, 10.58), (-.3, 10.58), (-.32, 10.2)], 105: [(-1.14, 9.68), (-.75, 9.68), (-.8, 10.58), (-1.08, 10.58), (-1.22, 10.2)]), "trim", P, BEVEL) 106: # front skirt: two blades sweeping out from the centre like an arrowhead 107: pair("skirt_front", two_view([(.45, 10.62), (1.45, 10.62), (2.05, 10.3), (1.65, 9.6), (.65, 9.9)], 108: [(-1.34, 9.55), (-1.02, 9.55), (-.94, 10.66), (-1.24, 10.66)]), "main", P, P, bevel=BEVEL) 109: pair("skirt_front_edge", two_view([(.68, 9.85), (1.64, 9.55), (1.74, 9.71), (.72, 9.99)], 110: [(-1.4, 9.47), (-1.06, 9.47), (-1.02, 10.05), (-1.36, 10.05)]), "accent", P, P, bevel=0.015) 111: # side skirts flare out toward the bottom, tips swept back 112: # side skirts hinge from the hip blocks: a cap plate over a ridged main plate 113: pair("skirt_side", two_view([(2.0, 9.5), (2.34, 9.5), (2.12, 10.5), (1.86, 10.52)], 114: [(-.6, 9.5), (1.05, 9.5), (.95, 10.54), (-.9, 10.54)], 115: top=[(1.8, -1.0), (2.17, -1.0), (2.42, .05), (2.17, 1.15), (1.8, 1.15)]), "main", P, P, bevel=BEVEL) 116: pair("skirt_side_cap", two_view([(1.86, 10.28), (2.3, 10.22), (2.22, 10.74), (1.86, 10.76)], 117: [(-.72, 10.22), (.92, 10.22), (.86, 10.76), (-.78, 10.76)]), "accent", P, P, bevel=0.025) 118: pair("skirt_side_plate", two_view([(2.26, 9.66), (2.4, 9.69), (2.26, 10.16), (2.12, 10.14)], 119: [(-.4, 9.66), (.85, 9.66), (.78, 10.16), (-.55, 10.16)]), "frame", P, P, bevel=0.015) 120: # rear skirt as two overlapping scales with a gap over the hip mechanism 121: # rear skirt: descending chevrons, a gap at the centre 122: pair("skirt_rear", two_view([(.14, 10.6), (1.26, 10.66), (1.61, 10.35), (1.46, 9.92), (.64, 9.82), (.18, 10.05)], 123: [(.92, 9.75), (1.26, 9.75), (1.32, 10.7), (.94, 10.7)]), "main", P, P, bevel=BEVEL) 124: pair("skirt_rear_low", two_view([(.14, 10.1), (.62, 9.93), (1.3, 10.02), (1.3, 9.63), (.6, 9.4), (.14, 9.6)], 125: [(1.02, 9.36), (1.36, 9.36), (1.36, 10.14), (1.02, 10.14)]), "main", P, P, bevel=0.03) 126: 127: 128: def build_waist(J): 129: W = J["waist"] 130: solid("abdomen", loft([(10.9, octo(1.6, 1.4, .35)), (11.95, octo(1.85, 1.55, .38))]), "joint", W, 0.03) 131: # three stacked plates in front, each a little wider and further forward than the one below 132: for i, (z0, z1, hw, y) in enumerate(((10.98, 11.34, .64, -.84), (11.28, 11.64, .72, -.88), (11.58, 11.96, .8, -.92))): 133: solid(f"abs{i}", two_view([(-hw, z0), (hw, z0), (hw + .06, z1), (-hw - .06, z1)], 134: [(y + .02, z0), (y + .24, z0), (y + .24, z1), (y - .02, z1)], 135: top=[(-hw - .1, y + .3), (hw + .1, y + .3), (hw + .1, y + .1), (0, y - .06), (-hw - .1, y + .1)]), 136: "frame", W, 0.02) 137: pair("abs_side", two_view([(.72, 11.0), (.96, 11.05), (1.02, 11.92), (.78, 11.92)], 138: [(-.5, 11.0), (.5, 11.0), (.56, 11.92), (-.56, 11.92)]), "frame", W, W, bevel=0.02) 139: 140: 141: def build_torso(J): 142: T = J["torso"] 143: # a dark structural core; the armour is separate plates over it 144: solid("chest", loft([(11.9, octo(1.9, 1.6, .4, y=.05)), (12.6, octo(2.4, 2.05, .45)), (13.9, octo(3.0, 2.45, .55, y=-.05)), 145: (14.9, octo(2.8, 2.25, .5)), (15.3, octo(1.8, 1.55, .4))]), "frame", T, BEVEL) 146: # central hatch: a ridged block down the chest front that carries the reactor lens 147: solid("hatch", two_view([(-.55, 12.75), (.55, 12.75), (.6, 14.5), (.4, 14.78), (-.4, 14.78), (-.6, 14.5)], 148: [(-1.62, 12.75), (-1.2, 12.75), (-1.3, 14.78), (-1.66, 14.62), (-1.8, 13.8)], 149: top=[(-.7, -1.0), (.7, -1.0), (.7, -1.55), (0, -1.84), (-.7, -1.55)]), "main", T, .03) 150: pair("chest_plate", two_view([(.58, 14.82), (1.18, 14.88), (1.55, 14.62), (1.78, 14.28), (1.55, 13.85), (.6, 14.08)], 151: [(-1.64, 13.6), (-1.1, 13.6), (-1.26, 14.88), (-1.5, 14.88), (-1.72, 13.85)]), 152: "accent", T, T, bevel=BEVEL) 153: rib = two_view([(.6, 12.7), (.9, 12.6), (1.6, 13.2), (1.62, 13.54), (.6, 13.88)], 154: [(-1.49, 12.5), (-.95, 12.5), (-1.1, 13.92), (-1.35, 13.92), (-1.57, 13.55)]) 155: pair_pieces("rib_plate", seam(rib, (.6, 13.22), (1.62, 13.05)), "accent", T, T, bevel=0.03) 156: pair("chest_strip", two_view([(.6, 14.84), (1.18, 14.9), (1.57, 14.64), (1.8, 14.28), (1.64, 14.2), (1.42, 14.5), (1.1, 14.7), 157: (.6, 14.64)], 158: [(-1.72, 13.9), (-1.22, 13.9), (-1.36, 14.96), (-1.6, 14.96), (-1.8, 14.2)]), "main", T, T, bevel=0.02) 159: pair("side_plate", two_view([(1.42, 12.9), (1.62, 12.9), (1.68, 14.4), (1.48, 14.6)], 160: [(-.95, 12.9), (.9, 12.9), (.95, 14.4), (-1.05, 14.45)]), "main", T, T, bevel=0.03)read_file{"EndLine":160,"Path":"~/work/sortie/kit/lab/board_sleek.py","StartLine":1}
input
{ "EndLine": 160, "Path": "~/work/sortie/kit/lab/board_sleek.py", "StartLine": 1 }result, 161 lines
Showing lines 1-160 of 316 1: """Estoc (line B), sleek knight: few strong shapes in smooth compound curves, every one ending in a sharp 2: tapered point (docs/study-atelier.md). Knightmare elegance on the atelier's stance. 3: 4: Leaf pauldrons swept back to a rising point, a keeled breastplate whose hem runs to a V, a corseted 5: waist, long blade tassets pointed at the hem, spiked couters, knee guards rising to a point, greaves 6: that sweep to a point over the instep, twin blades swept back from the helm. Thin gold piping on the 7: hems only. Long smooth faces carry long highlights: this direction leans hardest on the sheen. 8: 9: Grades by plate count (plates(J, P, g)): the light a smaller leaf, a bellows waist, short blade tassets, 10: an arming sleeve, one pair of short blades on the helm, the core block. The medium the board's line 11: knight. The heavy a second leaf under the first and a blade under that, a V plate over the lower breast, 12: flank blades, tassets in two layers, blade add-ons over the vambraces, cuisses and greaves, knee blades, 13: two pairs of helm blades. 14: """ 15: import math 16: 17: from knightkit import Sheet, addon, band, by, curve, horn, joint_covers, lames, lin, put, put2, rim, smooth, tent 18: from lib import copy 19: from makers import atelier 20: from makers.atelier import bearing_at, lr 21: from makers.shell import subtract 22: 23: FRONT = lin(-172, -8, 32) 24: breast_r = curve([1.0, 1.34, 1.52, 1.52, 1.42, 1.26, 1.1]) 25: 26: 27: def keel(u, z, grow=0.0, z0=12.1, z1=15.05): 28: r = breast_r(min(max((z - z0) / (z1 - z0), 0), 1)) + grow 29: a = math.radians(u) 30: return (r * 1.08 * math.cos(a), -.15 + r * math.sin(a), z) 31: 32: 33: def chest(P, J, g): 34: T, C = J["torso"], J["cockpit"] 35: H = T if g == "light" else C # the light's cockpit is the core block: its breast does not open 36: bot = lambda u: 12.1 + .7 * (1 - tent(u, -90, 70)) # the hem runs down to a V 37: top = lambda u: 15.05 - .28 * tent(u, -90, 40) - .55 * smooth(abs(u + 90), 56, 80) 38: ridge = lambda u, v: .2 * tent(u, -90, 34) * (1 - smooth(v, .85, 1)) # a keel, crisp on its crest 39: hi = lambda u: 12.9 + 1.2 * (1 - tent(u, -90, 100)) ** 1.6 # the ivory field above a second V, clear of the socket 40: s = Sheet(lambda u, v: keel(u, bot(u) + (top(u) - bot(u)) * v), FRONT, lin(0, 1, 16), .15, disp=ridge, inside=(0, 0, 13.6)) 41: bm = s.bm() 42: up = subtract(copy(bm), _below(hi)) 43: lo = subtract(bm, _above(hi)) 44: # the ivory field above the V is the hatch: it leaves with the pod, so no box is cut in the breast 45: P.solid("hatch", up, "accent", H, bevel=.012) 46: P.solid("breast_lo", lo, "main", T, bevel=.012) 47: rim(P, "breast_pipe", s.edge("v0", out=.01), .045, T) 48: bearing_at("chest", (1.0, -1.55, 14.3), (0, -1, 0), T, .8) 49: back = band((0, .15), 12.3, lambda u: 15.0 - .4 * smooth(u, 55, 80), [1.0, 1.42, 1.56, 1.5, 1.3], lin(14, 82, 10), nv=10, kx=1.04, ky=.92, t=.14) 50: put(P, "backplate", back, "main", T, T) 51: gg = band((0, .05), 14.8, 15.36, [1.14, 1.04, .92], lin(-168, -12, 24), nv=5, kx=1.05, t=.12) 52: put(P, "gorget", gg, "main", T) 53: if g == "light": 54: return 55: g2 = band((0, .05), 15.2, 15.62, [1.0, .94, .86], lin(-164, -16, 22), nv=4, kx=1.05, t=.1) 56: put(P, "gorget2", g2, "main", T) 57: rim(P, "gorget2_pipe", g2.edge("v1", out=.01), .04, T) 58: if g != "heavy": 59: return 60: # the castellan: a V plate over the lower breast, blades down the flanks 61: vb = lambda u: 12.0 + .7 * (1 - tent(u, -90, 70)) 62: vt = lambda u: 12.75 + .5 * (1 - tent(u, -90, 70)) 63: v = Sheet(lambda u, v: keel(u, vb(u) + (vt(u) - vb(u)) * v, .17), lin(-158, -22, 28), lin(0, 1, 5), .14, 64: disp=lambda u, v: .2 * tent(u, -90, 34), inside=(0, 0, 13.0)) 65: put(P, "breast_v", v, "main", T) 66: rim(P, "breast_v_pipe", v.edge("v1", out=.01), .045, T) 67: P.solid("flank_blade", horn([(1.5, -.3, 14.3), (1.62, -.2, 13.6), (1.6, -.1, 12.9), (1.42, 0, 12.2)], .26, n=10, power=1.0, squash=.3, 68: up=(1, 0, 0)), "main", T, T, bevel=0) 69: 70: 71: def _below(h): 72: """A solid under the curve z = h(u) on the chest front (u in plan degrees).""" 73: return _split(h, -1) 74: 75: 76: def _above(h): 77: return _split(h, 1) 78: 79: 80: def _split(h, side): 81: import bmesh 82: bm = bmesh.new() 83: us = lin(-178, -2, 120) 84: far = 30 if side > 0 else -30 85: rings = [] 86: for z in (None, far): 87: ring = [] 88: for u in us: 89: a = math.radians(u) 90: zz = h(u) if z is None else h(u) + far 91: ring += [bm.verts.new((.2 * math.cos(a), -.15 + .2 * math.sin(a), zz)), bm.verts.new((4 * math.cos(a), -.15 + 4 * math.sin(a), zz))] 92: rings.append(ring) 93: n = len(us) 94: A, B = rings 95: for i in range(n - 1): 96: a0, a1, b0, b1 = A[2 * i], A[2 * i + 1], A[2 * i + 2], A[2 * i + 3] 97: c0, c1, d0, d1 = B[2 * i], B[2 * i + 1], B[2 * i + 2], B[2 * i + 3] 98: bm.faces.new((a0, b0, b1, a1)) 99: bm.faces.new((c0, c1, d1, d0)) 100: bm.faces.new((a1, b1, d1, c1)) 101: bm.faces.new((a0, c0, d0, b0)) 102: bm.faces.new((A[0], A[1], B[1], B[0])) 103: bm.faces.new((A[-2], B[-2], B[-1], A[-1])) 104: bmesh.ops.recalc_face_normals(bm, faces=bm.faces) 105: return bm 106: 107: 108: def waist(P, J, g): 109: W = J["waist"] 110: if g == "light": 111: return # a bellows waist (joint_covers) 112: s = band((0, -.1), 11.3, 12.3, [.94, .8, .86, .96], lin(-170, -10, 26), nv=8, kx=1.08, t=.16, 113: disp=lambda u, v: .08 * tent(u, -90, 30)) 114: put(P, "corset", s, "main", W) 115: 116: 117: def pelvis(P, J, g): 118: Pv = J["pelvis"] 119: heavy = g == "heavy" 120: f = band((0, 0), 10.55, 11.25, [1.42, 1.36, 1.2], lin(-172, -8, 30), nv=5, kx=1.06, ky=.84, t=.16, disp=lambda u, v: .1 * tent(u, -90, 30)) 121: put(P, "fauld", f, "main", Pv) 122: P.solid("crotch", atelier.sheet([(-.5, 10.6), (.5, 10.6), (.36, 10.0), (0, 9.5), (-.36, 10.0)], 123: [(-1.04, 10.6), (-.38, 10.6), (-.38, 9.5), (-.9, 9.5)], None), "main", Pv) 124: # a long blade tasset over each thigh, pointed at the hem 125: hem = by(g, lambda u: 9.2 + .7 * (1 - tent(u, -100, 62)), lambda u: 8.35 + .95 * (1 - tent(u, -100, 62)), 126: lambda u: 8.0 + 1.0 * (1 - tent(u, -100, 62))) 127: t = band((1.1, -.12), hem, 10.72, lambda u, v: 1.18 - .22 * v + .06 * math.sin(math.pi * v), lin(-164, -36, 24), nv=10, t=.14, 128: disp=lambda u, v: .07 * tent(u, -100, 22)) 129: put(P, "tasset", t, "main", Pv, Pv) 130: rim(P, "tasset_pipe", t.edge("v0", out=.01), .04, Pv, Pv) 131: if g != "light": 132: # a shorter blade over the long one: the tasset in two layers 133: oh = lambda u: 9.0 + .8 * (1 - tent(u, -100, 56)) 134: t2 = band((1.1, -.12), oh, 10.76, lambda u, v: 1.3 - .22 * v + .06 * math.sin(math.pi * v), lin(-156, -44, 20), nv=8, t=.13, 135: disp=lambda u, v: .07 * tent(u, -100, 22)) 136: put(P, "tasset_over", t2, "main", Pv, Pv) 137: rim(P, "tasset_over_pipe", t2.edge("v0", out=.01), .045, Pv, Pv) 138: if heavy: 139: lames(P, "tasset_side_lame", (1.3, 0), 9.4, 2, .4, .32, 1.12, -.03, lin(-46, 46, 12), Pv, Pv, "main", "main") 140: if g == "light": 141: c = band((0, 0), 10.0, 10.95, [1.36, 1.28, 1.22], lin(10, 88, 12), nv=4, ky=.92, t=.12) 142: put(P, "culet", c, "main", Pv, Pv) 143: return 144: side = band((1.3, 0), lambda u: 9.25 + .5 * (1 - tent(u, 0, 50)), 10.55, [1.12, .86], lin(-50, 50, 12), nv=6, t=.12) 145: put(P, "tasset_side", side, "main", Pv, Pv) 146: c = band((0, 0), lambda u: 9.6 + .5 * smooth(u, 20, 80), 10.95, [1.42, 1.3, 1.22], lin(10, 88, 12), nv=6, ky=.92, t=.14) 147: put(P, "culet", c, "main", Pv, Pv) 148: 149: 150: def shoulder(P, J, g): 151: """A leaf: one shell over the shoulder, blunt in front, drawn back and up into a point. The castellan 152: layers a second leaf under it and a blade under that.""" 153: S = lr(J, "shoulder") 154: # light one small leaf, medium a leaf over a second, heavy one great leaf over a long swept mantle: the 155: # extra mass goes into one gesture, the surfaces stay smooth 156: leaves = by(g, [(.82, 0.0, 2.0, 1.75)], [(1.0, 0.0, 2.0, 1.75), (.9, -.55, 1.4, 1.75)], [(1.12, 0.0, 2.2, 1.75), (1.0, -.5, 1.0, 2.9)]) 157: for i, (k, dz, rise, length) in enumerate(leaves): 158: leaf(P, S, f"pauldron{i}" if i else "pauldron", k, dz, rise, ridge=i == 0, pipe="trim" if i == 0 else "main", length=length) 159: for side, j, sx in (("L", S[0], 1), ("R", S[1], -1)): 160: bearing_at(f"shoulder.{side}", (3.8 * sx, .1, 14.2), (sx, 0, 0), j, .5)read_file{"Path":"~/work/sortie/src/view/cameras.ts"}
input
{ "Path": "~/work/sortie/src/view/cameras.ts" }result, 103 lines
Showing lines 1-102 of 102 1: import * as THREE from 'three'; 2: 3: export type ViewMode = 'cockpit' | 'chase'; 4: 5: const FLIP = new THREE.Quaternion().setFromAxisAngle(new THREE.Vector3(0, 1, 0), Math.PI); 6: const _p = new THREE.Vector3(); 7: const _look = new THREE.Matrix4(); 8: const _up = new THREE.Vector3(); 9: 10: /** 11: * Cockpit: the camera sits at the frame's cockpit node, looking along the frame's nose. 12: * Chase (F5): over the frame's right shoulder, so the frame sits left of centre and the crosshair 13: * (screen centre) has clear space. Position follows rigidly; only the orientation is smoothed, so the 14: * frame never drifts toward or away from the camera when it speeds up or slows down. 15: */ 16: export class CameraRig { 17: mode: ViewMode = 'chase'; 18: readonly camera: THREE.PerspectiveCamera; 19: /** Chase offset in the frame's axes (+X is the frame's left, +Z forward). X is set from `shoulder`. */ 20: chaseOffset = new THREE.Vector3(0, 4.5, -30); 21: /** How far over the right shoulder the chase camera sits in flight (negative X is the frame's right). */ 22: shoulder = -8.5; 23: /** How far below the camera the look point sits, so the frame rides low in the view. */ 24: lookDrop = 1.5; 25: /** Scales the chase distance and height. On the catapult a heavy's camera pulls in to the 26: * striker's distance, so it stays near the tube mouth instead of deep in the hangar. */ 27: reach = 1; 28: /** 0 centred behind the frame (on the catapult), 1 fully over the shoulder. Eases toward `shoulderWanted`. */ 29: private shoulderBlend = 0; 30: shoulderWanted = 0; 31: private smoothed = new THREE.Quaternion(); 32: private shake = 0; 33: private time = 0; 34: 35: constructor(fov = 68) { 36: this.camera = new THREE.PerspectiveCamera(fov, 1, 0.5, 60000); 37: } 38: 39: toggle() { 40: this.mode = this.mode === 'cockpit' ? 'chase' : 'cockpit'; 41: } 42: 43: /** Jolt the view (catapult, hits). Decays on its own. */ 44: kick(amount: number) { 45: this.shake = Math.max(this.shake, amount); 46: } 47: 48: update(mech: { pos: THREE.Vector3; rot: THREE.Quaternion }, cockpit: THREE.Object3D, dt: number, snap = false) { 49: this.time += dt; 50: const cam = this.camera; 51: if (snap) this.smoothed.copy(mech.rot); 52: else this.smoothed.slerp(mech.rot, 1 - Math.exp(-10 * dt)); 53: this.shoulderBlend = snap ? this.shoulderWanted : this.shoulderBlend + (this.shoulderWanted - this.shoulderBlend) * (1 - Math.exp(-1.8 * dt)); 54: this.chaseOffset.x = this.shoulder * THREE.MathUtils.smoothstep(this.shoulderBlend, 0, 1); 55: if (this.mode === 'cockpit') { 56: cockpit.getWorldPosition(cam.position); 57: cam.quaternion.copy(mech.rot).multiply(FLIP); 58: } else { 59: const q = this.smoothed; 60: const o = this.chaseOffset, r = this.reach; 61: cam.position.set(o.x, o.y * r, o.z * r).applyQuaternion(q).add(mech.pos); 62: // look straight ahead from the shoulder, parallel to the frame's nose 63: _p.set(o.x, (o.y - this.lookDrop) * r, 400).applyQuaternion(q).add(mech.pos); 64: _up.set(0, 1, 0).applyQuaternion(q); 65: _look.lookAt(cam.position, _p, _up); 66: cam.quaternion.setFromRotationMatrix(_look); 67: } 68: this.applyShake(dt); 69: } 70: 71: /** 72: * The wreck seen from outside: a slow orbit round the drifting frame that pulls back as it goes, 73: * starting from the chase spot behind the heading it had when it was hit. `t` is seconds since 74: * the wreck and `size` the frame's scale, so the shot is a pure function of time. 75: */ 76: wreck(target: THREE.Vector3, heading: THREE.Quaternion, t: number, size: number, dt: number) { 77: this.time += dt; 78: const cam = this.camera; 79: const ease = 1 - Math.exp(-t * 0.8); 80: const dist = (32 + 95 * ease) * size; 81: const yaw = 0.35 * t + 0.25 * ease; 82: const rise = 0.18 + 0.32 * ease; 83: _p.set(Math.sin(yaw) * Math.cos(rise), Math.sin(rise), -Math.cos(yaw) * Math.cos(rise)).multiplyScalar(dist); 84: cam.position.copy(_p.applyQuaternion(heading)).add(target); 85: _up.set(0, 1, 0).applyQuaternion(heading); 86: _look.lookAt(cam.position, target, _up); 87: cam.quaternion.setFromRotationMatrix(_look); 88: this.smoothed.copy(heading); 89: this.applyShake(dt); 90: } 91: 92: private applyShake(dt: number) { 93: const cam = this.camera; 94: if (this.shake > 0.001) { 95: const s = this.shake; 96: cam.position.x += (Math.sin(this.time * 71) + Math.sin(this.time * 113)) * 0.05 * s; 97: cam.position.y += (Math.sin(this.time * 89) + Math.sin(this.time * 131)) * 0.05 * s; 98: cam.rotateZ(Math.sin(this.time * 47) * 0.004 * s); 99: this.shake *= Math.exp(-4 * dt); 100: } 101: } 102: }read_file{"EndLine":140,"Path":"~/work/sortie/src/view/thrusters.ts","StartLine":1}
input
{ "EndLine": 140, "Path": "~/work/sortie/src/view/thrusters.ts", "StartLine": 1 }result, 141 lines
Showing lines 1-140 of 166 1: import * as THREE from 'three'; 2: import { model, type ModelName } from '../render/assets'; 3: import { MechRig, POSES } from '../render/mech'; 4: import type { PaletteName } from '../render/palette'; 5: import { Pipeline } from '../render/pipeline'; 6: import { addSpaceLight, createBackdrop, followSun, spaceEnvironment } from '../render/space'; 7: import { STRIKER_DECALS, applyDecals } from '../render/decals'; 8: import { treatEyes } from '../render/eyes'; 9: import type { ThrustReading } from '../render/exhaust'; 10: 11: /** 12: * Thruster bench: one frame in a fixed thruster state at a fixed time, for judging plumes as stills. 13: * /?view=thrusters&state=quick&t=0.06 a quick boost 60 ms after onset 14: * /?view=thrusters&state=boost&close=main close on one main nozzle 15: * /?view=thrusters&state=cycle&play=1 every state in turn, live 16: * /?view=thrusters&cells=quick:0,quick:0.05,boost:0.5:main&cols=4&cw=480&ch=300 a sheet of stills 17: * &frame=heavy_C &palette=raider &yaw=150 &pitch=12 &dist=40 &light=0 &tier=low 18: * States: idle, cruise, boost, quick, assault, brake, strafe. `t` is seconds since the state began. 19: */ 20: export const BENCH_STATES = ['idle', 'cruise', 'boost', 'quick', 'assault', 'brake', 'strafe'] as const; 21: export type BenchState = (typeof BENCH_STATES)[number]; 22: 23: /** A scripted flight reading for a bench state `t` seconds in: local thrust (left, up, forward as a 24: * fraction of boosted forward thrust) and the boost flags, as the sim would report them. */ 25: export function benchInput(state: BenchState, t: number) { 26: const thrust = new THREE.Vector3(); 27: let boosting = false, assault = false, quick = Infinity; 28: if (state === 'cruise') thrust.set(0, 0, 0.35); 29: else if (state === 'boost') (thrust.set(0, 0, 1), (boosting = true)); 30: else if (state === 'quick') (thrust.set(0, 0, 0.05), (quick = t)); 31: else if (state === 'assault') (thrust.set(0, 0, 1), (boosting = true), (assault = true)); 32: else if (state === 'brake') thrust.set(0, 0.15, -0.6); 33: else if (state === 'strafe') thrust.set(0.55, 0, 0.1); 34: return { thrust, boosting, assault, quick }; 35: } 36: 37: export async function startThrusterBench(canvas: HTMLCanvasElement, q: URLSearchParams) { 38: await document.fonts.ready; 39: const scene = new THREE.Scene(); 40: const camera = new THREE.PerspectiveCamera(Number(q.get('fov') ?? 35), 1, 0.3, 2e5); 41: const backdrop = createBackdrop(); 42: const pipe = new Pipeline(canvas, scene, camera, backdrop); 43: // ?tier=low: the software and weak GPU tier, no bloom 44: const tier = q.get('tier'); 45: if (tier === 'low' || tier === 'medium') pipe.setQuality({ tier }); 46: const sun = addSpaceLight(scene); 47: scene.environment = spaceEnvironment(pipe.renderer, backdrop); 48: scene.environmentIntensity = Number(q.get('env') ?? 0.8); 49: 50: const name = (q.get('frame') ?? 'striker') as ModelName; 51: const root = await model(name, (q.get('palette') ?? 'merc') as PaletteName); 52: if (name === 'striker') applyDecals(root, STRIKER_DECALS); 53: treatEyes(root, 'spill'); 54: scene.add(root); 55: const rig = new MechRig(root); 56: rig.apply(POSES.flight); 57: root.updateMatrixWorld(true); 58: 59: const box = new THREE.Box3().setFromObject(root); 60: const height = box.getSize(new THREE.Vector3()).y; 61: const target = new THREE.Vector3(); 62: /** Aim the camera at the frame, or close on its first nozzle of a kind. */ 63: const aim = (close: string | null, yawAt?: string, pitchAt?: string) => { 64: box.getCenter(target); 65: const nozzle = close ? rig.nozzles.find((n) => n.kind === close) : undefined; 66: if (nozzle) nozzle.node.getWorldPosition(target); 67: const dist = Number(q.get('dist') ?? (nozzle ? height * 0.6 : height * 2.6)); 68: const yaw = THREE.MathUtils.degToRad(Number(yawAt || q.get('yaw') || (nozzle ? 125 : 132))); 69: const pitch = THREE.MathUtils.degToRad(Number(pitchAt || q.get('pitch') || 10)); 70: if (q.has('ty')) target.y += Number(q.get('ty')); 71: if (q.has('tz')) target.z += Number(q.get('tz')); 72: camera.position.set(Math.sin(yaw) * Math.cos(pitch), Math.sin(pitch), Math.cos(yaw) * Math.cos(pitch)).multiplyScalar(dist).add(target); 73: camera.lookAt(target); 74: followSun(sun, target); 75: }; 76: 77: const light = new THREE.PointLight('#ffffff', 0, 0, 2); 78: scene.add(light); 79: const lit = q.get('light') !== '0'; 80: const reading: ThrustReading = { x: 0, y: 0, z: 0, boosting: false }; 81: const DT = 1 / 120; 82: const feed = (state: BenchState, t: number, dt: number) => { 83: const f = benchInput(state, t); 84: reading.x = f.thrust.x; 85: reading.y = f.thrust.y; 86: reading.z = f.thrust.z; 87: reading.boosting = f.boosting; 88: reading.assault = f.assault; 89: reading.quick = f.quick; 90: rig.thrust(reading, t, dt); 91: if (lit) rig.lightExhaust(light); 92: }; 93: /** A still: a second of idle, then the state from its start to `t` in 120 Hz steps, as a game would. */ 94: const still = (state: BenchState, t: number) => { 95: for (let i = 0; i < 120; i++) feed('idle', 1 + i * DT, DT); 96: for (let s = 0; s < t - 1e-9; s += DT) feed(state, s, Math.min(DT, t - s)); 97: feed(state, t, 0); 98: }; 99: const ready = () => ((window as unknown as { __ready: boolean }).__ready = true); 100: const tag = (state: string, t: number, close: string | null) => `${state.toUpperCase()} t=${t.toFixed(2)}s${close ? ' close' : ''}`; 101: 102: // ?cells=quick:0,quick:0.05,boost:0.5:main,boost:0.5:main:178:4&cols=4&cw=480&ch=300 renders every 103: // cell (state:t[:close kind[:yaw[:pitch]]]) in one page 104: // and shows them as one sheet: one model load and one shader compile for the lot 105: const cells = q.get('cells'); 106: if (cells) { 107: const list = cells.split(',').map((c) => c.split(':')); 108: const cols = Number(q.get('cols') ?? 4), cw = Number(q.get('cw') ?? 480), ch = Number(q.get('ch') ?? 300); 109: const sheet = document.createElement('canvas'); 110: sheet.width = cols * cw; 111: sheet.height = Math.ceil(list.length / cols) * ch; 112: const ctx = sheet.getContext('2d')!; 113: ctx.fillStyle = '#111'; 114: ctx.fillRect(0, 0, sheet.width, sheet.height); 115: pipe.resize(cw, ch); 116: list.forEach(([state, t, close, yaw, pitch], i) => { 117: aim(close || null, yaw, pitch); 118: still(state as BenchState, Number(t)); 119: pipe.render(); 120: const x = (i % cols) * cw, y = Math.floor(i / cols) * ch; 121: ctx.drawImage(canvas, x, y, cw, ch); 122: ctx.strokeStyle = '#111'; 123: ctx.strokeRect(x + 0.5, y + 0.5, cw - 1, ch - 1); 124: ctx.font = '600 13px "Chakra Petch", sans-serif'; 125: ctx.fillStyle = '#cfe3ff'; 126: ctx.fillText(tag(state, Number(t), close || null) + (yaw ? ` yaw ${yaw}` : ''), x + 10, y + 18); 127: }); 128: canvas.style.display = 'none'; 129: sheet.style.cssText = 'position:fixed;left:0;top:0'; 130: document.body.appendChild(sheet); 131: ready(); 132: return; 133: } 134: 135: const label = document.createElement('div'); 136: label.style.cssText = 'position:fixed;left:14px;top:10px;font:600 15px "Chakra Petch",sans-serif;color:#cfe3ff;letter-spacing:.06em;text-shadow:0 1px 2px #000'; 137: if (!q.has('nolabel')) document.body.appendChild(label); 138: const fixed = (q.get('state') ?? 'boost') as BenchState | 'cycle'; 139: const t0 = Number(q.get('t') ?? 0.5); 140: const close = q.get('close');manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67" }result, 9 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-67.log
Log output:
striker_a_kit 5525ms
striker_a_sketch 11359ms
light_knight 8801ms

Last progress: 4s ago
agent
+3:42reasoning
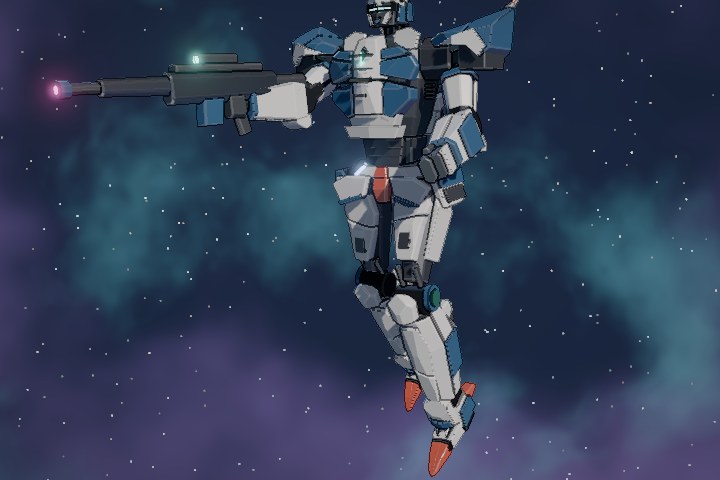
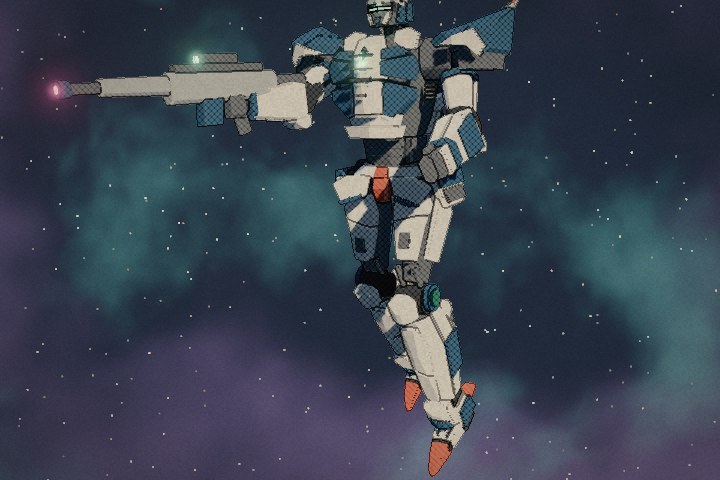
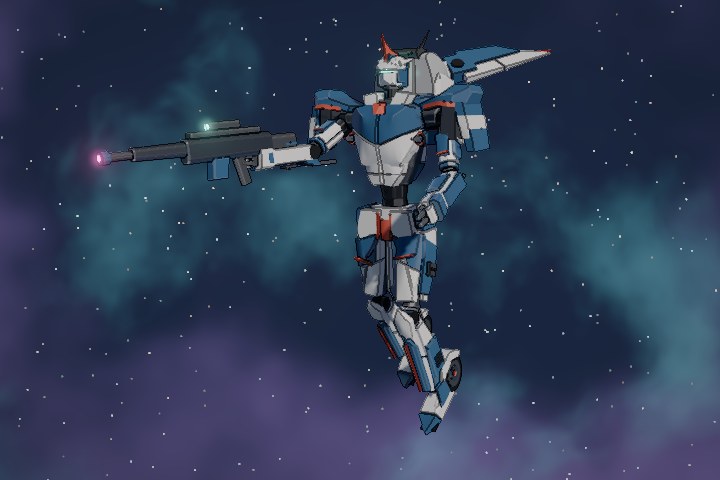
Examining the available images, focusing on the rendered striker and light knight depictions. Awaiting the completion of the remaining image generation tasks. I'll read the outlines-test file to inform the next steps.
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/striker_a_kit.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/striker_a_kit.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_76_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/striker_a_sketch.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/striker_a_sketch.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_77_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/light_knight.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/light_knight.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_78_media_0.jpg read_file{"Path":"~/work/sortie/tools/fixtures/outlines-test.json"}
input
{ "Path": "~/work/sortie/tools/fixtures/outlines-test.json" }result, 376 lines
Showing lines 1-374 of 374 1: { 2: "title": "Outline sheet test fixture: plain posts, not a design", 3: "outlines": [ 4: { 5: "parts": [ 6: { 7: "pts": [ 8: [ 9: 0, 10: 0 11: ], 12: [ 13: 1.0, 14: 0 15: ], 16: [ 17: 1.0, 18: 10 19: ], 20: [ 21: 0, 22: 10 23: ] 24: ], 25: "mirror": true 26: } 27: ], 28: "note": "test post" 29: }, 30: { 31: "parts": [ 32: { 33: "pts": [ 34: [ 35: 0, 36: 0 37: ], 38: [ 39: 1.3, 40: 0 41: ], 42: [ 43: 1.3, 44: 11 45: ], 46: [ 47: 0, 48: 11 49: ] 50: ], 51: "mirror": true 52: }, 53: { 54: "circle": [ 55: 0, 56: 12.2, 57: 1.2 58: ] 59: } 60: ], 61: "note": "test post" 62: }, 63: { 64: "parts": [ 65: { 66: "pts": [ 67: [ 68: 0, 69: 0 70: ], 71: [ 72: 1.6, 73: 0 74: ], 75: [ 76: 1.6, 77: 12 78: ], 79: [ 80: 0, 81: 12 82: ] 83: ], 84: "mirror": true 85: } 86: ], 87: "note": "test post" 88: }, 89: { 90: "parts": [ 91: { 92: "pts": [ 93: [ 94: 0, 95: 0 96: ], 97: [ 98: 1.9, 99: 0 100: ], 101: [ 102: 1.9, 103: 13 104: ], 105: [ 106: 0, 107: 13 108: ] 109: ], 110: "mirror": true 111: }, 112: { 113: "circle": [ 114: 0, 115: 14.2, 116: 1.2 117: ] 118: } 119: ], 120: "note": "test post" 121: }, 122: { 123: "parts": [ 124: { 125: "pts": [ 126: [ 127: 0, 128: 0 129: ], 130: [ 131: 2.2, 132: 0 133: ], 134: [ 135: 2.2, 136: 14 137: ], 138: [ 139: 0, 140: 14 141: ] 142: ], 143: "mirror": true 144: } 145: ], 146: "note": "test post" 147: }, 148: { 149: "parts": [ 150: { 151: "pts": [ 152: [ 153: 0, 154: 0 155: ], 156: [ 157: 2.5, 158: 0 159: ], 160: [ 161: 2.5, 162: 15 163: ], 164: [ 165: 0, 166: 15 167: ] 168: ], 169: "mirror": true 170: }, 171: { 172: "circle": [ 173: 0, 174: 16.2, 175: 1.2 176: ] 177: } 178: ], 179: "note": "test post" 180: }, 181: { 182: "parts": [ 183: { 184: "pts": [ 185: [ 186: 0, 187: 0 188: ], 189: [ 190: 2.8, 191: 0 192: ], 193: [ 194: 2.8, 195: 16 196: ], 197: [ 198: 0, 199: 16 200: ] 201: ], 202: "mirror": true 203: } 204: ], 205: "note": "test post" 206: }, 207: { 208: "parts": [ 209: { 210: "pts": [ 211: [ 212: 0, 213: 0 214: ], 215: [ 216: 3.1, 217: 0 218: ], 219: [ 220: 3.1, 221: 17 222: ], 223: [ 224: 0, 225: 17 226: ] 227: ], 228: "mirror": true 229: }, 230: { 231: "circle": [ 232: 0, 233: 18.2, 234: 1.2 235: ] 236: } 237: ], 238: "note": "test post" 239: }, 240: { 241: "parts": [ 242: { 243: "pts": [ 244: [ 245: 0, 246: 0 247: ], 248: [ 249: 3.4, 250: 0 251: ], 252: [ 253: 3.4, 254: 18 255: ], 256: [ 257: 0, 258: 18 259: ] 260: ], 261: "mirror": true 262: } 263: ], 264: "note": "test post" 265: }, 266: { 267: "parts": [ 268: { 269: "pts": [ 270: [ 271: 0, 272: 0 273: ], 274: [ 275: 3.6999999999999997, 276: 0 277: ], 278: [ 279: 3.6999999999999997, 280: 19 281: ], 282: [ 283: 0, 284: 19 285: ] 286: ], 287: "mirror": true 288: }, 289: { 290: "circle": [ 291: 0, 292: 20.2, 293: 1.2 294: ] 295: } 296: ], 297: "note": "test post" 298: }, 299: { 300: "parts": [ 301: { 302: "pts": [ 303: [ 304: 0, 305: 0 306: ], 307: [ 308: 4.0, 309: 0 310: ], 311: [ 312: 4.0, 313: 20 314: ], 315: [ 316: 0, 317: 20 318: ] 319: ], 320: "mirror": true 321: } 322: ], 323: "note": "test post" 324: }, 325: { 326: "parts": [ 327: { 328: "pts": [ 329: [ 330: 0, 331: 0 332: ], 333: [ 334: 2, 335: 0 336: ], 337: [ 338: 2, 339: 14 340: ], 341: [ 342: 0, 343: 14 344: ] 345: ], 346: "mirror": true 347: } 348: ], 349: "side": [ 350: { 351: "pts": [ 352: [ 353: -1, 354: 0 355: ], 356: [ 357: 1, 358: 0 359: ], 360: [ 361: 1, 362: 14 363: ], 364: [ 365: -1, 366: 14 367: ] 368: ] 369: } 370: ], 371: "note": "with side" 372: } 373: ] 374: } (no newline at end of file)read_file{"EndLine":120,"Path":"~/work/sortie/docs/factions.md","StartLine":1}
input
{ "EndLine": 120, "Path": "~/work/sortie/docs/factions.md", "StartLine": 1 }result, 121 lines
Showing lines 1-120 of 170
1: # Factions: visual grammar
2:
3: > **Status 2026-11-08: reference.** Applied to the shipped PvE models. Its look rules were never chosen by the owner one by one. See [handbook.md](handbook.md).
4:
5: Reference study for the three PvE factions. Boards: `review/out/refs/factions-automatons.jpg`,
6: `factions-raiders.jpg`, `factions-aliens.jpg` (gitignored, 24 to 28 tiles each, tiles under
7: `review/out/refs/factions/<faction>/`). Sources: official line art and design sheets from the
8: Gundam, Armored Core, Titanfall, Nier, Evangelion, Destiny, Halo, Xenoblade and Mad Max wikis.
9:
10: We take traits, not designs. Each section ends with take, adapt and avoid lines so no faction
11: turns into a lookalike of its sources. Naming schemes are proposals, the lead picks.
12:
13: ## Automatons
14:
15: Pilotless, mass-produced, black and red. References: Mobile Dolls (Virgo, Taurus), GN-X and
16: GN-XIII ranks, Gadessa, Hashmal and its Plumas, GX-Bits, Armored Core 6 PCA units (Light and
17: Heavy Cavalry, Enforcer, Ekdromoi, Cataphract, Balteus), Titanfall Spectre, Stalker and Reaper,
18: Nier machines.
19:
20: ### Grammar
21:
22: 1. **No face.** One lens, or a lens bar behind a visor slit, red. No eyes, mouth or crest. The
23:    light carries state: dim while searching, bright on lock, strobing when calling others. The
24:    GN-X and Virgo do it with a visor helmet, the AC6 PCA units with a sensor pod on the hull and
25:    no head at all. Both work.
26: 2. **Hull, not armour.** Continuous shell surfaces with panel seams, not plates layered over a
27:    visible frame. No cockpit means no hatch: the chest can be thin or carry a weapon or sensor
28:    where a pilot would sit. The GN-X lineart and the AC6 Enforcer sketch show the torso as one
29:    sculpted volume.
30: 3. **Clones in ranks.** Grunts are identical, same pose, numbered. The Virgo production line and
31:    the GX-Bit racks are the image: units stored upright in rows, lit by their lenses.
32: 4. **Leader = scale and modules, never a new face.** Reaper is a big Stalker, Heavy Cavalry a big
33:    Light Cavalry, Virgo III adds shoulders. A leader is the same hull language with more mass
34:    and more mounts.
35: 5. **Non-human joints allowed.** Reverse knees, tetrapods, a ring body (Balteus), a wing of bits
36:    (Plumas). The grunt stays roughly humanoid for the rig, the leader may break it.
37: 6. **Colour.** Matte black or gunmetal shell. Red only for lenses, thin light lines along the
38:    joint seams and a dull stencil number on the shoulder. Nothing else.
39: 7. **Surfaces.** Pristine, no wear, no decals beyond the number. Symmetric, fewer and larger
40:    plates than the striker, sharp chamfers.
41:
42: ### Behaviour the look telegraphs
43:
44: Lens state as above. Line formations with fixed spacing. Bits that leave a carrier and return.
45: Braking packs on drops. No ejection: a dying unit's lens goes dark, nothing flies off. They do
46: not retreat and they do not talk.
47:
48: ### Naming
49:
50: Foundry mark plus a tool word. Grunts take hand tools (Awl, Rasp, Froe, Burin, Gouge), leaders
51: shop tools (Anvil, Kiln, Bellows, Lathe), bits small tools (Tack, Pin). Printed as mark, batch,
52: type: K7 Awl. Alternative: loom terms (Shuttle, Heddle, Treadle, Warp, Bobbin) for a faction
53: that weaves swarms.
54:
55: ### Take, adapt, avoid
56:
57: - Take: the faceless lens bar, hull as one shell, clones in racks, leader by scale.
58: - Adapt: the Virgo rack and GX-Bit numbering into spawn and hangar presentation. Red light lines
59:   on seams as the faction's only ornament.
60: - Avoid: the GN-X visor shape, Virgo's round shoulders with defensor discs, the Balteus ring,
61:   Titanfall's orange hazard stripes, the Zeon mono-eye on a rail.
62:
63: ## Raiders
64:
65: Scrappy bandits in patched, mismatched salvage. References: Iron-Blooded Orphans Rodi line (Man
66: Rodi, Landman Rodi, Garm Rodi, Spinner Rodi, Monkey Rodi), Hugo and the Hexa frame, Gusion and
67: Gusion Rebake, Hyakuren, Zaku Tank and Zaku I Sniper (field conversions), Armored Core 6 BAWS
68: and RLF machines (Toybox, tetrapod, pulse MT), Mad Max Fury Road vehicles (War Rig, Gigahorse,
69: Buzzards, Cranky Frank, BigFoot, Peacemaker).
70:
71: ### Grammar
72:
73: 1. **Frame first, armour bolted on.** The IBO Rodi sheets show it: a skeletal inner frame with
74:    armour hung on it in pieces, and gaps where plates are missing. Raider machines show their
75:    frame at the waist, elbows and knees.
76: 2. **Parts from different machines.** Gusion is a lead frame buried under Rodi armour. Hugo is a
77:    Hexa frame with a new chest. The Gigahorse is two cars stacked. A raider frame mixes parts
78:    from two or three donors with visibly different plate families and colours.
79: 3. **Welded extras.** Plates stacked over plates with bolt heads, a rear rack for weapons (Garm
80:    Rodi), a blower sticking out of a hood, missile tubes strapped to a roof. Mass is added on
81:    the outside, never integrated.
82: 4. **Improvised weapons.** Hooks on cables, hammers, choppers, grenades in a bag, a long rifle
83:    on a bipod, a disc shield. Ballistic and melee, nothing that needs a clean power source.
84: 5. **Totems and hand paint.** Flags, hand-painted names and numbers, a mascot on the hood, war
85:    paint stripes. Identity is painted on, not built in.
86: 6. **Wear.** Rust, scorch, patched panels in primer, mismatched replacement parts in the wrong
87:    colour. The only faction with real dirt.
88: 7. **Leader = louder, not sleeker.** The Garm Rodi commander adds antennae and a horn, the
89:    Monkey Rodi commander a crest, the Gigahorse a flag. A boss has more and bigger things
90:    bolted on and the most paint.
91:
92: ### Behaviour the look telegraphs
93:
94: Hooks and cables mean boarding and grapples. Racks mean they pick weapons up and drop them. A
95: long rifle on a bipod means a sniper covering the gang. They come in packs with one loud boss,
96: they loot, and they run when the loot is not worth it. Raiders wear merc parts, so a player who
97: lost a part may see it again on a raider.
98:
99: ### Naming
100:
101: No model numbers. Gangs take a totem animal (Gulls, Lampreys, Magpies, Hornets) and paint it on.
102: Frames are named by their crew like boats, painted on the hull: Pig Iron, Kettle, Long Shot,
103: Second Wind. A boss frame carries the gang's totem as a figurehead.
104:
105: ### Take, adapt, avoid
106:
107: - Take: exposed frame with hung armour, mixed donor parts, stacked plates with bolts, racks,
108:   hooks, hand-painted names, rust.
109: - Adapt: raider grunts are kitbashes of the player part library with a raider material role
110:   (primer, rust, hand paint), so they stay in the game's plate language while reading as junk.
111:   Spikes and skulls do not belong on a space frame: use antenna clusters, cable bundles and hull
112:   hooks for the same bristle.
113: - Avoid: the Rodi round helmet with the visor slit, the Zaku mono-eye, Mad Max skull totems and
114:   spiked cars taken literally, IBO's pink and green Rodi colours.
115:
116: ## Silver aliens
117:
118: Unpredictable, silver, not quite machines. References: Gundam 00's ELS, Halo Forerunner
119: Guardians, Sentinels, Promethean Knights and Watchers, Evangelion Angels (Sachiel, Ramiel,
120: Zeruel, Sahaquiel, Israfel), Destiny's Vex, Xenoblade's Telethia.
manage_task{"Action":"status","TaskId":"cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67"}
input
{ "Action": "status", "TaskId": "cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67" }result, 11 lines
Task: cea9ec26-a0ce-4401-a5d2-36df51bb07b3/task-67
Status: RUNNING
Log: file://~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/.system_generated/tasks/task-67.log
Log output:
striker_a_kit 5525ms
striker_a_sketch 11359ms
light_knight 8801ms
light_back 10381ms
heavy_a 8292ms

Last progress: 14s ago
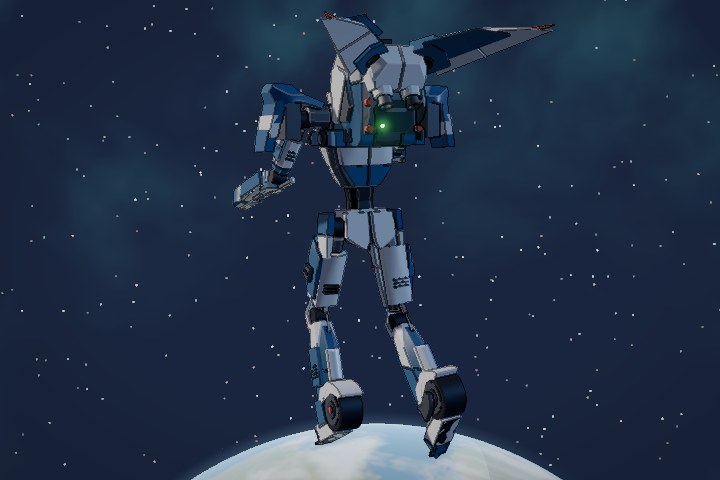
read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/light_back.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/light_back.jpg" }result, 1 line
Showing binary file of type image/jpeg
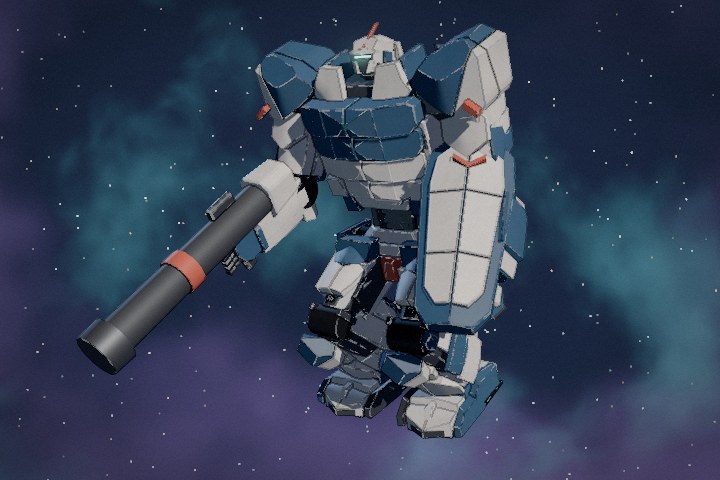
step_83_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/heavy_a.jpg"}
input
{ "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/heavy_a.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_84_media_0.jpg read_file{"Path":"~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/ship_hangar.jpg"}error
input
{
  "Path": "~/.gemini/antigravity-cli/brain/cea9ec26-a0ce-4401-a5d2-36df51bb07b3/scratch/survey/ship_hangar.jpg"
}
result, error, 1 line
Encountered error in step execution: file does not exist