A mech game prototype, pushed by GPT-6.2-Astra
agent (cont.)
+4:39exec_command, view_imagepython - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python - <<'PY' from pathlib import Path p=Path('tools/studies/core.py') s=p.read_text().replace('2.15, .10','2.38, .10').replace('outer.location.y += 4.2','outer.location.y += 5.15').replace('pose("forearm.L", -32)','pose("forearm.L", -44, 5, -16)').replace('pose("upperarm.L", -12, -5)','pose("upperarm.L", 9, -13, -5)').replace('pose("forearm.R", -24)','pose("forearm.R", -68)').replace('pose("upperarm.R", 13, 5)','pose("upperarm.R", -24, 11, -5)').replace('pose("head", -3, 2, 20)','pose("head", 4, 2, 48)').replace('pose("thigh.L", -10)','pose("thigh.L", -46, -12)').replace('pose("shin.L", 19)','pose("shin.L", 74)\\npose("foot.L", -8)').replace('pose("thigh.R", 13)','pose("thigh.R", -9, 11)\\npose("shin.R", 43)\\npose("foot.R", 14)').replace('0, 2.76, 4.87','0, 2.80, 3.90').replace('10, -4.1, 2.8','9.4, -6.0, 2.1').replace('"ORTHO", 9.0','"ORTHO", 10.0').replace('2000, 1080','2000, 1320') p.write_text(s) PY ~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/preview.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/preview.png -background '#edece6' -alpha remove review/out/core-study/on-paper.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/on-paper.jpg"})).image_url)result, 4 lines
Script completed
Wall time 5.0 seconds
Output:
{"chunk_id":"cf4fd0","wall_time_seconds":4.854200426,"exit_code":0,"original_token_count":0,"output":""}
on-paper_3.jpg exec_commandrg -A100 'export const POSES' src/render/mech.ts | head -90 && cat ~/context/brief-sortie-full.md | tail -15 && git status -sb && ls ~/out
command
rg -A100 'export const POSES' src/render/mech.ts | head -90 && cat ~/context/brief-sortie-full.md | tail -15 && git status -sb && ls ~/out
result, 111 lines
Script completed
Wall time 0.1 seconds
Output:
export const POSES = {
  stand: {
    'upperarm.L': [0, 0, 6], 'upperarm.R': [0, 0, -6], 'forearm.L': [-12, 0, 0], 'forearm.R': [-12, 0, 0],
  },
  /** Standing on the catapult: knees bent, leaning into the launch. */
  launch: {
    pelvis: [8, 0, 0], torso: [10, 0, 0], head: [-14, 0, 0],
    'thigh.L': [-38, 0, 2], 'thigh.R': [-38, 0, -2], 'shin.L': [58, 0, 0], 'shin.R': [58, 0, 0],
    'foot.L': [-20, 0, 0], 'foot.R': [-20, 0, 0],
    'upperarm.L': [-18, 0, 14], 'forearm.L': [-40, 0, 0], 'upperarm.R': [-30, 0, -8], 'forearm.R': [-50, 0, 0],
    'binder.L': [18, 0, 0], 'binder.R': [18, 0, 0],
  },
  /** The launch crouch for a heavy: 24 m in a 26 m tube, so knees deep, head down and binders folded,
   *  which brings it under the tube's signal box. */
  launch_heavy: {
    pelvis: [12, 0, 0], torso: [12, 0, 0], head: [-20, 0, 0],
    'thigh.L': [-58, 0, 3], 'thigh.R': [-58, 0, -3], 'shin.L': [106, 0, 0], 'shin.R': [106, 0, 0],
    'foot.L': [-48, 0, 0], 'foot.R': [-48, 0, 0],
    'upperarm.L': [-18, 0, 14], 'forearm.L': [-40, 0, 0], 'upperarm.R': [-30, 0, -8], 'forearm.R': [-50, 0, 0],
    'binder.L': [40, 0, 0], 'binder.R': [40, 0, 0],
  },
  /** Free flight, rifle up. */
  flight: {
    pelvis: [6, 0, 0], torso: [-4, 0, 0], head: [-2, 0, 0],
    'thigh.L': [-22, 0, 4], 'thigh.R': [6, 0, -3], 'shin.L': [42, 0, 0], 'shin.R': [30, 0, 0],
    'foot.L': [8, 0, 0], 'foot.R': [18, 0, 0],
    'upperarm.L': [-22, 0, 16], 'forearm.L': [-46, 0, 0],
    'upperarm.R': [-62, -8, -6], 'forearm.R': [-26, 0, 0], 'hand.R': [0, 0, 0],
    'binder.L': [-6, 0, 0], 'binder.R': [-6, 0, 0],
  },
} satisfies Record<string, Pose>;
export type PoseName = keyof typeof POSES;

/** The catapult pose for a size class: the striker's, with a deeper crouch for heavies. */
export const launchPose = (cls: string): Pose => (cls === 'heavy' ? POSES.launch_heavy : POSES.launch);

export interface Nozzle {
  node: THREE.Object3D;
  dir: THREE.Vector3; // exhaust direction in the node's parent space
  radius: number;
  kind: NozzleKind;
  plume: THREE.Mesh;
}

const tmpQ = new THREE.Quaternion();
const _sum = new THREE.Vector3();
const _at = new THREE.Vector3();
const _white = new THREE.Color(1, 1, 1);
const tmpE = new THREE.Euler();
const D = THREE.MathUtils.DEG2RAD;

/** A frame model's joints, posed by rotation, with weapons held at grip.R and thruster plumes. */
export class MechRig {
  readonly joints = new Map<Joint, THREE.Object3D>();
  readonly nozzles: Nozzle[] = [];
  readonly cockpit: THREE.Object3D;
  readonly grip: THREE.Object3D;
  held: THREE.Object3D | null = null;
  /** Plume state, stepped by thrust(). */
  readonly exhaust = new Exhaust();
  /** One plume material per nozzle kind: a kind fires together. */
  private plumeMats: Record<NozzleKind, THREE.ShaderMaterial>;
  private exhaustColor: THREE.Color;
  private targets = new Map<Joint, THREE.Quaternion>();

  constructor(readonly root: THREE.Object3D) {
    const map = nodes(root);
    for (const j of JOINTS) {
      const n = find(map, j);
      if (n) this.joints.set(j, n);
    }
    this.cockpit = find(map, 'cockpit') ?? root;
    this.grip = find(map, 'grip.R') ?? root;
    const paint = PALETTES[(root.userData.palette as PaletteName | undefined) ?? 'merc'].glow_exhaust;
    this.exhaustColor = new THREE.Color(paint.color);
    this.plumeMats = {
      main: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 0),
      binder: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 17.3),
      calf: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 41.7),
    };
    root.traverse((o) => {
      const dir = o.userData.dir as number[] | undefined;
      if (!dir || !/^nozzle/.test(o.name)) return;
      const kind: NozzleKind = /main/.test(o.name) ? 'main' : /binder/.test(o.name) ? 'binder' : 'calf';
      const radius = (o.userData.radius as number) ?? 0.5;
      // the plume's own space is in nozzle radii (render/plume.ts)
      const plume = new THREE.Mesh(PLUME_HULL, this.plumeMats[kind]);
      const d = new THREE.Vector3(...(dir as [number, number, number]));
      plume.quaternion.setFromUnitVectors(new THREE.Vector3(0, 0, 1), d);
      plume.scale.setScalar(radius);

## Rules
- Headless only: no windows on the owner's desktop. Never run anything that drives Windows programs (no tools/winvroid, no powershell.exe, cmd.exe or anything under /mnt/c). Browser rendering via headless Chromium only (Playwright is at `~/work/sortie/node_modules/playwright`; page-side code compiled by tsx can throw "__name is not defined", so keep page-side code as plain .js evaluated as text). Blender only with `-b`.
- Don't install packages. Don't run the full test suite (a test run once ate 36 GB); targeted checks only.
- Nothing runs on the C1 machine; no ssh. No network uploads, no publishing anywhere. Never push.
- Edit files only in your worktree and your output folder. Never push.

## Deliverable
One self-contained HTML page, `index.html` in your output folder, with its images (or a short clip) beside it. The owner finds wordy interfaces tiring: organise, don't narrate; short labelled sections, plain words, no em dashes. At the top: "GPT-6.2-Astra (gpt-6.2-astra), effort high" and the date.
1. **Your read of this line of work:** what's working, what isn't, what you'd keep and drop, and what you would do differently in the restart. Give opinions plainly; disagree with the reflection page where you do.
2. **What you'd do next** if you ran the restart's first session: a short, concrete sequence.
3. **The one visual:** a single visual artifact made with what the project already has (its tools, kits, renderers, models, data). Your choice of what it is; pick the thing that best shows what you'd do with this work. Show it large, then say in a few lines how it was made (the commands, wall time) and what you'd change next.
Keep it to one visual; don't build a gallery. Aim to be done in roughly 90 minutes of work.

When done, end your turn with: the page path, a 5-line summary, and any commits on your branch. If something only the owner can decide blocks you, say so and stop rather than guessing.
## astra62
?? tools/studies/
exec_command, view_imagepython - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python - <<'PY' from pathlib import Path p=Path('tools/studies/core.py') s=p.read_text().replace('2.38, .10','2.75, -.65').replace('outer.location.y += 5.15','outer.location.y += 5.10').replace('outer.location.z += .20','outer.location.z -= 1.20').replace('0, 2.80, 3.90','0, 2.77, 3.13').replace('9.4, -6.0, 2.1','9.4, -6.0, 3.10').replace('pose("forearm.R", -68)','pose("forearm.R", -32)').replace('pose("upperarm.R", -24, 11, -5)','pose("upperarm.R", -25, 14, -5)').replace('pose("thigh.L", -46, -12)','pose("thigh.L", -47, -16, -5)').replace('pose("shin.L", 74)','pose("shin.L", 62)').replace('pose("thigh.R", -9, 11)','pose("thigh.R", 22, 19)').replace('pose("shin.R", 43)','pose("shin.R", 26)').replace('default_value = .48','default_value = .32').replace('1150, 6','1150, 4').replace('bpy.ops.render.render(write_still=True)','''scene.render.use_freestyle = True style = bpy.context.view_layer.freestyle_settings.linesets[0].linestyle style.color = (.035, .071, .078) style.alpha = .7 style.thickness = .78 * scene.render.resolution_percentage / 100 bpy.ops.render.render(write_still=True)''') p.write_text(s) PY ~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/preview.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/preview.png -background '#edece6' -alpha remove review/out/core-study/on-paper.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/on-paper.jpg"})).image_url)result, 4 lines
Script completed
Wall time 2.4 seconds
Output:
{"chunk_id":"ccddcd","wall_time_seconds":2.259155686,"exit_code":1,"original_token_count":0,"output":""}
on-paper_3.jpg exec_commandtail -16 review/out/core-study/render.log
command
tail -16 review/out/core-study/render.log
result, 20 lines
Script completed
Wall time 0.0 seconds
Output:
22:50:34 | INFO: Blender create Mesh node wall.R.001
22:50:34 | INFO: Blender create Mesh node wall_rail.L.001
22:50:34 | INFO: Blender create Mesh node wall_rail.R.001
22:50:34 | INFO: glTF import finished in 0.28s
~/work/sortie/tools/studies/core.py:136: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0
  scene.world.use_nodes = True
Traceback (most recent call last):
  File "~/work/sortie/tools/studies/core.py", line 161, in <module>
    style.color = (.035, .071, .078)
    ^^^^^^^^^^^
AttributeError: 'NoneType' object has no attribute 'color' and no __dict__ for setting new attributes

Error: script failed, file: 'tools/studies/core.py', exiting.
Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)

Blender quit
exec_command, view_imagesed -i 's/style = bpy.context.view_layer.freestyle_settings.linesets\[0\].linestyle/style = bpy.data.linestyles.new("Graphite")\nbpy.context.view_layer.freestyle_settings.linesets[0].linestyle = style/' tools/studies/core.py (+1 more)
input
text(await tools.exec_command({cmd:`sed -i 's/style = bpy.context.view_layer.freestyle_settings.linesets\\[0\\].linestyle/style = bpy.data.linestyles.new("Graphite")\\nbpy.context.view_layer.freestyle_settings.linesets[0].linestyle = style/' tools/studies/core.py ~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/preview.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/preview.png -background '#edece6' -alpha remove review/out/core-study/on-paper.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/on-paper.jpg"})).image_url)result, 4 lines
Script completed
Wall time 8.1 seconds
Output:
{"chunk_id":"360f96","wall_time_seconds":7.882295093,"exit_code":0,"original_token_count":0,"output":""}
on-paper_4.jpg exec_command, view_imageconvert review/out/core-study/preview.png -background '#263238' -alpha remove review/out/core-study/dark.jpg (+1 more)
input
text(await tools.exec_command({cmd:`convert review/out/core-study/preview.png -background '#263238' -alpha remove review/out/core-study/dark.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/dark.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"f639f4","wall_time_seconds":0.00000406,"exit_code":0,"original_token_count":0,"output":""}
dark.jpg exec_command, view_imagecp tools/studies/core.py review/out/core-study/front.py (+1 more)error
input
text(await tools.exec_command({cmd:`cp tools/studies/core.py review/out/core-study/front.py
python - <<'PY'
from pathlib import Path
p=Path('tools/studies/core.py')
s=p.read_text().replace('9.4, -6.0, 3.10','9.4, 4.8, 2.8').replace('2.75, -.65','2.8, .45').replace('outer.location.z -= 1.20','outer.location.z += .92').replace('pose("head", 4, 2, 48)','pose("head", -5, 2, 45)').replace('0, 2.77, 3.13','0, 2.86, 3.12').replace('"ORTHO", 10.0','"ORTHO", 10.8')
p.write_text(s)
PY
~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/rear.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/rear.png -background '#edece6' -alpha remove review/out/core-study/rear.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/rear.jpg"})).image_url)
result, error, 5 lines
Script failed
Wall time 10.3 seconds
Output:
{"chunk_id":"728bb3","wall_time_seconds":10.001064818,"session_id":70009,"original_token_count":0,"output":""}Script error:
unable to locate image at `~/work/sortie/review/out/core-study/rear.jpg`: No such file or directory (os error 2)
write_stdin, view_imagepoll session 70009 (+1 more)
input
text(await tools.write_stdin({session_id:70009,chars:""}));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/rear.jpg"})).image_url)result, 4 lines
Script completed
Wall time 4.0 seconds
Output:
{"chunk_id":"bf3985","wall_time_seconds":4.006493575,"exit_code":0,"original_token_count":0,"output":""}
rear.jpg exec_commandrg -n '^def wing' kit/light.py -A37 && rg -n 'def octo' kit/lib.py -A11 && git diff --stat
command
rg -n '^def wing' kit/light.py -A37 && rg -n 'def octo' kit/lib.py -A11 && git diff --stat
result, 54 lines
Script completed Wall time 0.1 seconds Output: 698:def wing(J, n, v): 699- """Float blades on the binder joints. Each is built along +Z from its pivot (span z, chord y, 700- thickness x), thick at an armoured root and thinning to the tip, split once across, then posed.""" 701- for s, sx in (("L", 1), ("R", -1)): 702- B = J["binder", s] 703- pv = Vector(B.matrix_world.translation) 704- # yaw swings the blade out, pitch sweeps it back, roll turns its face toward the rear camera 705- yaw, pitch, roll, L = {"knight": (68, -46, 60, 1.62), "line": (72, -24, 50, 1.25), "lancer": (76, -62, 40, 1.75)}[v] 706- m = Matrix.Translation(pv) @ rot("Y", yaw * sx) @ rot("X", pitch) @ rot("Z", roll * sx) 707- if v == "line": 708- chord = [(-.2, .05), (.2, .05), (.2, L * .8), (-.04, L)] 709- elif v == "knight": 710- chord = [(-.3, .05), (.24, .05), (.24, L * .45), (.04, L * .9), (-.08, L)] 711- else: 712- chord = [(-.14, .05), (.3, .05), (.42, L * .62), (-.02, L)] 713- thick = [(-.06, .05), (.06, .05), (.035, L * .5), (.01, L), (-.01, L), (-.035, L * .5)] 714- blade = sc(thick, chord, sharp=28, levels=1) 715- for i, p in enumerate(split(blade, [((0, 0, L * .42), (0, .35, 1))], gap=.03)): 716- put(f"{n}_wing{i}.{s}", transform(p, m), "main" if centre(p).z < L * .42 else ("accent" if v == "line" else "main"), B) 717- if v != "line": 718- under = sc([(-.1, .1), (-.055, .1), (-.045, L * .7), (-.07, L * .7)], 719- [(-.06, .1), (.34, .1), (.3, L * .5), (.06, L * .72)], sharp=28, levels=1) 720- put(f"{n}_wing_b.{s}", transform(under, m), "accent", B) 721- root = sc([(-.11, -.14), (.11, -.14), (.1, .32), (-.1, .32)], [(-.2, -.14), (.24, -.14), (.26, .2), (.1, .32), (-.16, .28)], sharp=36) 722- put(f"{n}_wing_root.{s}", transform(root, m), "accent" if v != "line" else "main", B) 723- put(f"{n}_wing_hinge.{s}", transform(cylinder(.1, -.13, .13, 12, axis="x", at=(.02, .02)), m), "joint", B) 724- put(f"{n}_wing_tip.{s}", transform(loft([(L * .86, octo(.03, .1, .01)), (L * 1.03, octo(.008, .02, .003))]), m), "trim", B, 725- smooth=False) 726- bell, glow = nozzle(.07, .12) 727- d = m.to_3x3() @ Vector((0, 0, -1)) 728- at = m @ Vector((0, .02, -.14)) 729- put(f"{n}_wing_nozzle.{s}", place(bell, at, d), "frame", B) 730- put(f"{n}_wing_nozzle.{s}.glow", place(glow, at, d), "glow_thruster", B, smooth=False, outline=False) 731- empty(f"nozzle.binder.{s}", at + d * .12, B, dir=gltf_dir(d), radius=.07) 732- 733- 734-def float_pack(J, n, v): 735- """The float unit: a thruster core hung on the upper rear face of the core block, over the hatch, 84:def octo(w, d, c=0.2, cf=None, cb=None, x=0.0, y=0.0): 85- """A chamfered rectangle, w along X and d along Y, CCW seen from above. The front (-Y) and back 86- chamfers can differ: cf, cb. Returns 8 points.""" 87- cf = c if cf is None else cf 88- cb = c if cb is None else cb 89- hw, hd = w / 2, d / 2 90- cf, cb = min(cf, hw * 0.95, hd * 0.95), min(cb, hw * 0.95, hd * 0.95) 91- return [(x - hw + cf, y - hd), (x + hw - cf, y - hd), (x + hw, y - hd + cf), (x + hw, y + hd - cb), 92- (x + hw - cb, y + hd), (x - hw + cb, y + hd), (x - hw, y + hd - cb), (x - hw, y - hd + cf)] 93- 94- 95-def circle(r, n=12, x=0.0, y=0.0, phase=0.5):exec_commandpython - <<'PY'
command
python - <<'PY' from pathlib import Path p=Path('tools/studies/core.py') s=p.read_text().replace('cabin.rotation_euler.z = math.pi','cabin.rotation_euler.z = math.radians(207)').replace('2.8, .45','2.45, -.38').replace('outer.location.y += 5.10','outer.location.y += 5.95\nouter.rotation_mode = "XYZ"\nouter.rotation_euler.z = math.radians(-47)').replace('outer.location.z += .92','outer.location.z -= .90').replace('0, 2.86, 3.12','0, 3.16, 3.56').replace('2000, 1320','2000, 1240') p.write_text(s) PY ~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/spread.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/spread.png -background '#eeeee7' -alpha remove review/out/core-study/spread.jpgresult, 4 lines
Script completed Wall time 0.4 seconds Output: {"chunk_id":"ae1282","wall_time_seconds":0.250553739,"session_id":12635,"original_token_count":0,"output":""}exec_commandpython - <<'PY'
command
python - <<'PY'
import importlib.util
for m in ['PIL','numpy','cairosvg','reportlab','fontTools','cv2']:
 print(m, bool(importlib.util.find_spec(m)))
PY
which fc-match && fc-list | head -11 && ls ~/out -la
result, 25 lines
Script completed
Wall time 0.9 seconds
Output:
PIL True
numpy True
cairosvg False
reportlab False
fontTools True
cv2 False
/usr/bin/fc-match
/usr/share/fonts/truetype/dejavu/DejaVuSerif-Bold.ttf: DejaVu Serif:style=Bold
/usr/share/fonts/opentype/urw-base35/URWBookman-LightItalic.otf: URW Bookman:style=Light Italic
/usr/share/fonts/opentype/urw-base35/URWBookman-Light.otf: URW Bookman:style=Light
/usr/share/fonts/truetype/dejavu/DejaVuSansMono.ttf: DejaVu Sans Mono:style=Book
/usr/share/fonts/truetype/ubuntu/UbuntuMono-RI.ttf: Ubuntu Mono:style=Italic
/usr/share/fonts/opentype/urw-base35/NimbusMonoPS-Italic.otf: Nimbus Mono PS:style=Italic
/usr/share/fonts/truetype/noto/NotoSansMono-Regular.ttf: Noto Sans Mono:style=Regular
/usr/share/fonts/opentype/urw-base35/P052-Italic.otf: P052:style=Italic
/usr/share/fonts/type1/urw-base35/URWGothic-BookOblique.t1: URW Gothic:style=Book Oblique
/usr/share/fonts/type1/gsfonts/n021024l.pfb: Nimbus Roman No9 L:style=Medium Italic
/usr/share/fonts/truetype/dejavu/DejaVuSans.ttf: DejaVu Sans:style=Book
total 8
drwx------ 2 runner runner 4096 Nov 17 22:43 .
drwx------ 8 runner runner 4096 Nov 17 22:47 ..
write_stdin, view_imagepoll session 12635 (+1 more)
input
text(await tools.write_stdin({session_id:12635,chars:""}));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/spread.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
{"chunk_id":"14b50d","wall_time_seconds":0.00000302,"exit_code":0,"original_token_count":0,"output":""}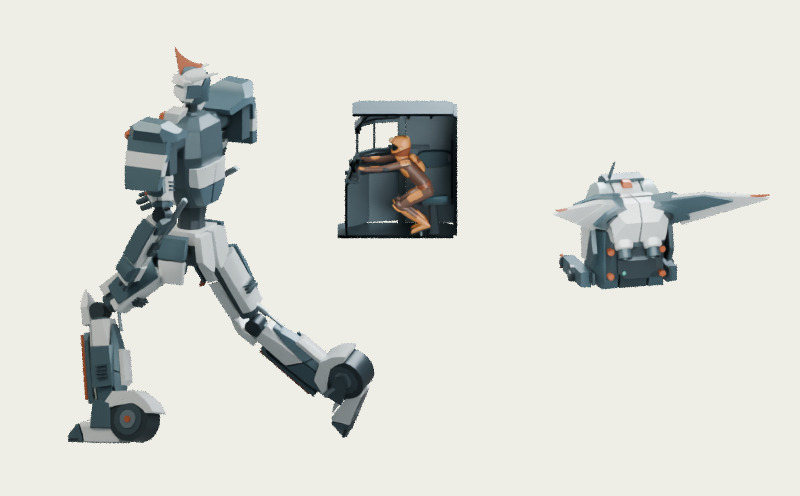
spread.jpg exec_command, view_imagecp tools/studies/core.py review/out/core-study/stride.py (+1 more)
input
text(await tools.exec_command({cmd:`cp tools/studies/core.py review/out/core-study/stride.py python - <<'PY' from pathlib import Path p=Path('tools/studies/core.py') s=p.read_text().replace('pose("thigh.L", -47, -16, -5)','pose("thigh.L", -88, -9)').replace('pose("shin.L", 62)','pose("shin.L", 86)').replace('pose("foot.L", -8)','pose("foot.L", 2)').replace('pose("thigh.R", 22, 19)','pose("thigh.R", 14, 9)').replace('pose("shin.R", 26)','pose("shin.R", 85)').replace('pose("foot.R", 14)','pose("foot.R", -30)').replace('scene.render.use_freestyle = True','scene.render.use_freestyle = not args.preview').replace('math.radians(-47)','math.radians(-31)').replace('2.45, -.38','2.65, -.48').replace('math.radians(207)','math.radians(220)').replace('0, 3.16, 3.56','0, 2.80, 3.95').replace('"ORTHO", 10.8','"ORTHO", 11.0').replace('2000, 1240','2200, 1200') p.write_text(s) PY ~/.local/bin/blender -b -t 8 --python-exit-code 1 -P tools/studies/core.py -- review/out/core-study/kneel.png --preview > review/out/core-study/render.log 2>&1 && convert review/out/core-study/kneel.png -background '#eeeee7' -alpha remove review/out/core-study/kneel.jpg` }));image((await tools.view_image({path:"~/work/sortie/review/out/core-study/kneel.jpg"})).image_url)result, 4 lines
Script completed
Wall time 5.0 seconds
Output:
{"chunk_id":"2e066b","wall_time_seconds":4.785117588,"exit_code":0,"original_token_count":0,"output":""}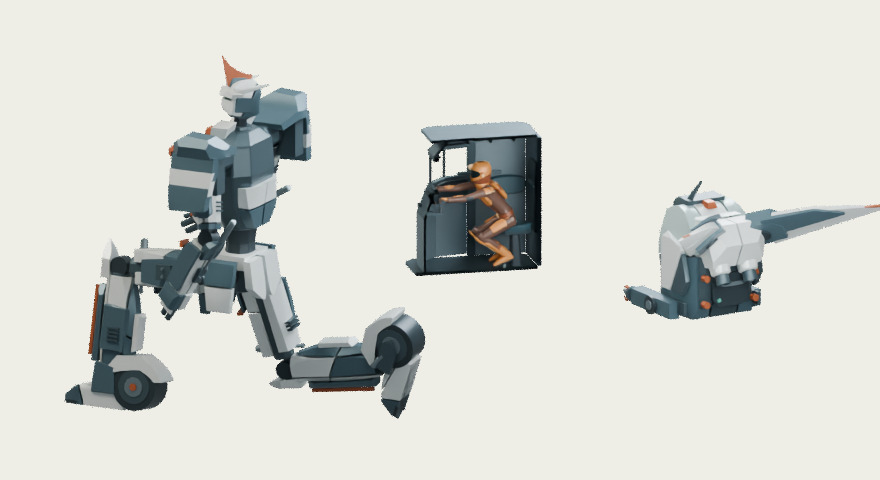
kneel.jpg exec_commandpython - <<'PY'
command
python - <<'PY' import re,json,struct from pathlib import Path def widths(asset,patt): with open(Path('public/assets',asset+'.glb'),'rb') as f: f.seek(12);length,_=struct.unpack('II',f.read(8)); g=json.loads(f.read(length)) acc=g['accessors'] def walk(i,px=0): n=g['nodes'][i]; px+=n.get('translation',[0])[0] if 'mesh' in n and re.fullmatch(patt,n['name']): for part in g['meshes'][n['mesh']]['primitives']: a=acc[part['attributes']['POSITION']] yield a['min'][0]+px,a['max'][0]+px for j in n.get('children',[]):yield from walk(j,px) limits=[pair for i in g['scenes'][0]['nodes'] for pair in walk(i)] print(asset, patt, min(x for x,_ in limits),max(x for _,x in limits)) widths('light',r'k_core\d+') widths('cockpit_light',r'wall\.[LR]') PY ls -la /opt/ms-playwright/chromium_headless_shell-1208 | head && node -e "console.log(require('playwright/package.json').version)"result, 13 lines
Script completed
Wall time 0.4 seconds
Output:
light k_core\d+ -0.5300000309944153 0.5300000309944153
cockpit_light wall\.[LR] -0.6200000047683716 0.6200000047683716
total 8
drwxr-xr-x  3 runner runner 4096 Sep  8 17:12 .
drwx------ 12 runner runner  240 Nov 17 22:44 ..
-rw-r--r--  1 runner runner    0 Oct 21 21:05 DEPENDENCIES_VALIDATED
-rw-r--r--  1 runner runner    0 Sep  8 17:12 INSTALLATION_COMPLETE
drwxr-xr-x  4 runner runner 4096 Sep  8 17:12 chrome-headless-shell-linux64
1.64.1
exec_commandrg -n 'PlaneGeometry|rotation|\.add\(' src/hud/screens.ts | head -40 && sed -n '27,80p' kit/cockpit_light.py && rg -n 'function attach|PlaneGeometry|screen\.main' src/render src/hud/screens.ts | head -30 && ls /opt/ms-playwright/chromium_headless_shell-1248
command
rg -n 'PlaneGeometry|rotation|\.add\(' src/hud/screens.ts | head -40 && sed -n '27,80p' kit/cockpit_light.py && rg -n 'function attach|PlaneGeometry|screen\.main' src/render src/hud/screens.ts | head -30 && ls /opt/ms-playwright/chromium_headless_shell-1248result, 72 lines
Script completed Wall time 0.1 seconds Output: 82: const mesh = new THREE.Mesh(new THREE.PlaneGeometry(mw, mh), new THREE.MeshBasicMaterial({ 86: main.add(mesh); 91: const c = new THREE.Mesh(new THREE.PlaneGeometry(w, h), mat); 94: node.add(c); 114: const plane = new THREE.Mesh(new THREE.PlaneGeometry(w, h), mat); 115: n.add(plane); RAIL = .045 # bezel rail height above and below the band # The block's inside: half width, back wall, floor and roof, all from the eye. HW, BACK, FLOOR, ROOF = .58, -.8, -1.22, .44 def chord(a0, a1): """The flat panel between two azimuths on the band circle: its Frame and half width.""" a, h = math.radians((a0 + a1) / 2), math.radians((a1 - a0) / 2) d = RHO * math.cos(h) c = Vector((d * math.sin(a), d * math.cos(a), (BAND[0] + BAND[1]) / 2)) return Frame(c, (math.cos(a), -math.sin(a), 0), (0, 0, 1)), RHO * math.sin(h) def edge(az, r=RHO): a = math.radians(az) return Vector((r * math.sin(a), r * math.cos(a), 0)) def band(root): """Screens, rails and mullions round the eye; the hood above and the console below.""" hh = (BAND[1] - BAND[0]) / 2 zc = (BAND[0] + BAND[1]) / 2 names = ["feed.L2", "feed.L1", "screen.main", "feed.R1", "feed.R2"] rails, mull, lips = [], [], [] for i, name in enumerate(names): fr, hw = chord(EDGES[i], EDGES[i + 1]) e = facing(fr.at(0, 0, .001), 2 * hw, 2 * hh, name, root, normal=fr.w) if name.startswith("feed"): e["feed"] = True # rails above and below this panel, a lip stepping toward the eye rails.append(slab(fr, [(-hw - .01, hh), (hw + .01, hh), (hw + .01, hh + RAIL), (-hw - .01, hh + RAIL)], -.02, .03)) rails.append(slab(fr, [(-hw - .01, -hh - RAIL), (hw + .01, -hh - RAIL), (hw + .01, -hh), (-hw - .01, -hh)], -.02, .03)) lips.append(slab(fr, [(-hw - .01, hh + RAIL), (hw + .01, hh + RAIL), (hw + .01, hh + RAIL + .012), (-hw - .01, hh + RAIL + .012)], .0, .06)) lips.append(slab(fr, [(-hw - .01, -hh - RAIL - .012), (hw + .01, -hh - RAIL - .012), (hw + .01, -hh - RAIL), (-hw - .01, -hh - RAIL)], .0, .06)) # mullions on the panel edges, thin and dark so the band reads as one wraparound picture for az in EDGES[1:-1]: a = math.radians(az) p = edge(az, RHO - .004) fr = Frame((p.x, p.y, zc), (math.cos(a), -math.sin(a), 0), (0, 0, 1)) mull.append(slab(fr, [(-.008, -hh - .01), (.008, -hh - .01), (.008, hh + .01), (-.008, hh + .01)], -.01, .016)) solid("band_rails", merge(*rails), "frame", root, .004) solid("band_lips", merge(*lips), "joint", root, .003) solid("band_mullions", merge(*mull), "joint", root, .003) # the band ends: a pillar each side where the screens meet the side walls for sx in (1, -1): p = edge(96 * sx, RHO) q = Vector((HW * sx, p.y - .1, 0)) solid(f"band_end.{'R' if sx > 0 else 'L'}", quad_panel((p.x, p.y, FLOOR), (p.x, p.y, ROOF), (q.x, q.y, ROOF), (q.x, q.y, FLOOR), .04), "frame", root, .005) def hood(root): """Above the band: a sloped liner from the top rail up to the roof, a status strip in its middle, src/hud/screens.ts:76: const main = find(map, 'screen.main')!; src/hud/screens.ts:82: const mesh = new THREE.Mesh(new THREE.PlaneGeometry(mw, mh), new THREE.MeshBasicMaterial({ src/hud/screens.ts:91: const c = new THREE.Mesh(new THREE.PlaneGeometry(w, h), mat); src/hud/screens.ts:114: const plane = new THREE.Mesh(new THREE.PlaneGeometry(w, h), mat); src/render/effects.ts:10: const g = new THREE.PlaneGeometry(1, 1); DEPENDENCIES_VALIDATED INSTALLATION_COMPLETE chrome-headless-shell-linux64exec_commandrg 'def facing' kit -A19 && rg -n '^def quad_panel' kit/cockpit.py -A13 && cat tools/studies/core.py | tail -66
command
rg 'def facing' kit -A19 && rg -n '^def quad_panel' kit/cockpit.py -A13 && cat tools/studies/core.py | tail -66
result, 100 lines
Script completed
Wall time 0.1 seconds
Output:
Warning: truncated output (original token count: 1131)
Total output lines: 100

kit/cockpit.py:def facing(at, w, h, name, parent, tilt_target=Vector((0, 0, 0)), normal=None):
kit/cockpit.py-    """A screen marker at `at` turned to face the eye (local -Y toward the target), or along `normal`."""
kit/cockpit.py-    n = normal.normalized() if normal is not None else (tilt_target - Vector(at)).normalized()
kit/cockpit.py-    q = Vector((0, -1, 0)).rotation_difference(n)
kit/cockpit.py-    # keep the screen's up roughly world up
kit/cockpit.py-    e = empty(name, at, parent, w=w, h=h)
kit/cockpit.py-    e.rotation_mode = "QUATERNION"
kit/cockpit.py-    up = q @ Vector((0, 0, 1))
kit/cockpit.py-    want = (Vector((0, 0, 1)) - n * n.dot(Vector((0, 0, 1)))).normalized()
kit/cockpit.py-    roll = up.rotation_difference(want)
kit/cockpit.py-    e.rotation_quaternion = roll @ q
kit/cockpit.py-    return e
kit/cockpit.py-
kit/cockpit.py-
kit/cockpit.py-def panel(at, w, h, depth, role, name, parent, bevel=.006):
kit/cockpit.py-    """A slab facing the eye, w by h, depth thick, behind the point `at`."""
kit/cockpit.py-    n = (-Vector(at)).normalized()
kit/cockpit.py-    q = Vector((0, -1, 0)).rotation_difference(n)
kit/cockpit.py-    up = q @ Vector((0, 0, 1))
kit/cockpit.py-    want = (Vector((0, 0, 1)) - n * n.dot(Vector((0, 0, 1)))).normalized()
116:def quad_panel(a, b, c, d, thick=.04):
117-    """A flat slab through four corner points, thickened away from the eye."""
118-    pts = [Vector(p) for p in (a, b, c, d)]
119-    n = (pts[1] - pts[0]).cross(pts[3] - pts[0]).normalized()
120-    if n.dot(sum(pts, Vector()) / 4) < 0:
121-        n = -n
122-    bm = bmesh.new()
123-    vs = [bm.verts.new(p) for p in pts] + [bm.verts.new(p + n * thick) for p in pts]
124-    bmesh.ops.convex_hull(bm, input=vs)
125-    return bm
126-
127-
128-def keys(fr, u0, v0, v1, n, size=.034, gap=.012, w=.0):
129-    out = []
    obj = bpy.data.objects[name]
    obj.rotation_mode = "XYZ"
    obj.rotation_euler = [math.radians(a) for a in (pitch, roll, yaw)]

pose("forearm.L", -44, 5, -16)
pose("upperarm.L", 9, -13, -5)
pose("forearm.R", -32)
pose("upperarm.R", -25, 14, -5)
pose("head", -5, 2, 45)
pose("thigh.L", -88, -9)
pose("shin.L", 86)
pose("foot.L", 2)
pose…37 tokens truncated…j.material_slots:
        role = slot.material.name.split(".")[0]
        palette = pilot_colors if obj.name.startswith("pilot_") else {}
        slot.material = palette.get(role) or colors.get(role, colors["frame"])

def area(name, location, target, power, size, tint):
    light = bpy.data.lights.new(name, "AREA")
    light.energy, light.shape, light.size, light.color = power, "DISK", size, tint
    lamp = bpy.data.objects.new(name, light)
    scene.collection.objects.link(lamp)
    lamp.location = location
    lamp.rotation_euler = (Vector(target) - lamp.location).to_track_quat("-Z", "Y").to_euler()

area("Softbox", (4, -4, 11), (0, 1, 4), 1150, 4, (1, .94, .84))
area("Edge", (-4, 4, 9), (0, 2, 4), 1900, 5, (.81, .91, 1))
area("Fill", (3, 8, 6), (0, 4, 4), 480, 5, (.92, .97, 1))
scene.world = bpy.data.worlds.new("Studio")
scene.world.use_nodes = True
scene.world.node_tree.nodes["Background"].inputs["Color"].default_value = (.65, .73, .77, 1)
scene.world.node_tree.nodes["Background"].inputs["Strength"].default_value = .32

camera = bpy.data.objects.new("Study camera", bpy.data.cameras.new("Study"))
scene.collection.objects.link(camera)
target = Vector((0, 2.80, 3.95))
direction = Vector((9.4, 4.8, 2.8))
camera.location = target + direction
camera.rotation_euler = (-direction).to_track_quat("-Z", "Y").to_euler()
camera.data.type, camera.data.ortho_scale = "ORTHO", 11.0
scene.camera = camera

scene.render.engine = "CYCLES"
scene.cycles.samples = 4 if args.preview else 48
scene.cycles.use_denoising = True
scene.render.resolution_x, scene.render.resolution_y = 2200, 1200
scene.render.resolution_percentage = 40 if args.preview else 100
scene.render.film_transparent = True
scene.render.image_settings.color_mode = "RGBA"
scene.view_settings.view_transform = "AgX"
scene.render.filepath = str(args.output.resolve())
bpy.context.view_layer.update()
scene.render.use_freestyle = not args.preview
style = bpy.data.linestyles.new("Graphite")
bpy.context.view_layer.freestyle_settings.linesets[0].linestyle = style
style.color = (.035, .071, .078)
style.alpha = .7
style.thickness = .78 * scene.render.resolution_percentage / 100
bpy.ops.render.render(write_still=True)