A mech game prototype, pushed by GPT-6.2-Astra
agent (cont.)
+1:01:19exec_commandcat > review/form-zero/assemble.py <<'PY'
command
cat > review/form-zero/assemble.py <<'PY' """Join game flight and orbit footage to the studio hatch study.""" import argparse import io import shutil import subprocess from pathlib import Path from PIL import Image, ImageDraw def assemble(work, output): game = work / 'game' studio = work / 'finish-frames' output.mkdir(parents=True, exist_ok=True) target = output / 'zero-and-striker.mp4' temporary = target.with_suffix('.part.mp4') command = [ 'ffmpeg', '-v', 'error', '-y', '-f', 'image2pipe', '-c:v', 'mjpeg', '-framerate', '24', '-i', '-', '-c:v', 'libx264', '-threads', '4', '-preset', 'medium', '-crf', '17', '-pix_fmt', 'yuv420p', '-movflags', '+faststart', str(temporary), ] with Image.open(game / 'close-label.jpg') as reference: label = reference.crop((0, 806, 1600, 900)) try: with subprocess.Popen(command, stdin=subprocess.PIPE) as encoder: for i in range(300): encoder.stdin.write((game / f'{i:04d}.jpg').read_bytes()) previous = None for i in range(204, 288): # Hold the closed and open positions without rerendering identical pixels. frame = max(216, min(i, 259)) if frame != previous: with Image.open(studio / f'{frame:04d}.jpg') as close: if close.size != (1600, 806): raise ValueError(f'Unexpected studio resolution {close.size}') canvas = Image.new('RGB', (1600, 900)) canvas.paste(close) ImageDraw.Draw(canvas).rectangle((799, 0, 800, 805), fill='#697d7d') canvas.paste(label, (0, 806)) data = io.BytesIO() canvas.save(data, format='JPEG', quality=96, subsampling=0) still = data.getvalue() previous = frame encoder.stdin.write(still) encoder.stdin.close() if encoder.wait(): raise RuntimeError('ffmpeg could not encode the film') temporary.replace(target) finally: temporary.unlink(missing_ok=True) shutil.copyfile(game / '0032.jpg', output / 'zero-flight.jpg') shutil.copyfile('public/assets/block_zero.glb', output / 'frame-zero.glb') if __name__ == '__main__': parser = argparse.ArgumentParser(description=__doc__) parser.add_argument('work', type=Path) parser.add_argument('output', type=Path) args = parser.parse_args() assemble(args.work, args.output) PY cat > review/form-zero/make-film.sh <<'SH' #!/usr/bin/env bash # From the repo root. Keep intermediates in the ignored review output directory. set -euo pipefail scratch=review/out/form-zero destination=\${1:-review/rear-cockpit/frame-zero} blender=\${BLENDER:-"$HOME/.local/bin/blender"} mkdir -p "$scratch/tmp" export TMPDIR="$PWD/$scratch/tmp" "$blender" -b -t 7 --python-exit-code 1 -P kit/build.py -- block_zero node review/form-zero/capture.mjs "$scratch/studio" --export node review/form-zero/capture.mjs "$scratch/game" --game "$blender" -b -t 7 --python-exit-code 1 -P review/form-zero/studio.py -- "$scratch/studio" "$scratch/finish-frames" --start 216 --end 259 --samples 8 python3 review/form-zero/assemble.py "$scratch" "$destination" SH chmod +x review/form-zero/make-film.sh cat review/out/form-zero/clearance-final.log | tail -5 head -25 src/render/mech.ts ls -al public/assets | head -25 ls -l review/out/form-zero/game | tail -3 date -uresult, 4 lines
Script completed
Wall time 0.2 seconds
Output:
{"chunk_id":"9d26cd","wall_time_seconds":0.000095215,"exit_code":0,"original_token_count":785,"output":"23:45:25 | INFO: glTF import finished in 4.43s\nCLEARANCE 47 24 27 samples. [] 0 intersections\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\nimport * as THREE from 'three';\nimport { find, nodes } from './assets';\nimport { Exhaust, KINDS, type NozzleKind, type ThrustReading } from './exhaust';\nimport { PALETTES, type PaletteName } from './palette';\nimport { PLUME_HULL, plumeMaterial, plumeVisible, setPlume } from './plume';\n\n/** Joint rotations in degrees, glTF axes: X pitches a limb (negative swings it forward), Z swings it\n *  sideways (positive moves a left limb outward), Y twists. */\nexport type Pose = Partial<Record<Joint, [number, number, number]>>;\n\nexport const JOINTS = [\n  'pelvis', 'waist', 'torso', 'neck', 'head', 'backpack',\n  'shoulder.L', 'upperarm.L', 'forearm.L', 'hand.L', 'shoulder.R', 'upperarm.R', 'forearm.R', 'hand.R',\n  'thigh.L', 'shin.L', 'foot.L', 'thigh.R', 'shin.R', 'foot.R', 'binder.L', 'binder.R',\n] as const;\nexport type Joint = (typeof JOINTS)[number];\n\nexport const POSES = {\n  stand: {\n    'upperarm.L': [0, 0, 6], 'upperarm.R': [0, 0, -6], 'forearm.L': [-12, 0, 0], 'forearm.R': [-12, 0, 0],\n  },\n  /** Standing on the catapult: knees bent, leaning into the launch. */\n  launch: {\n    pelvis: [8, 0, 0], torso: [10, 0, 0], head: [-14, 0, 0],\n    'thigh.L': [-38, 0, 2], 'thigh.R': [-38, 0, -2], 'shin.L': [58, 0, 0], 'shin.R': [58, 0, 0],\ntotal 177440\ndrwx------ 2 runner runner     4096 Nov 17 23:45 .\ndrwx------ 3 runner runner     4096 Nov 17 22:43 ..\n-rw------- 1 runner runner    97212 Nov 17 22:43 alien_acicular.glb\n-rw------- 1 runner runner   120312 Nov 17 22:43 alien_druse.glb\n-rw------- 1 runner runner   282936 Nov 17 22:43 alien_druse_mimic.glb\n-rw------- 1 runner runner   710368 Nov 17 22:43 alien_geode.glb\n-rw------- 1 runner runner  1484272 Nov 17 22:43 auto_ledger.glb\n-rw------- 1 runner runner  1179792 Nov 17 22:43 auto_tally.glb\n-rw------- 1 runner runner   852852 Nov 17 22:43 auto_tick.glb\n-rw------- 1 runner runner    94972 Nov 17 23:45 block_dummy.glb\n-rw------- 1 runner runner  4199196 Nov 17 23:41 block_zero.glb\n-rw------- 1 runner runner    25452 Nov 17 22:43 cannon.glb\n-rw------- 1 runner runner   245152 Nov 17 22:43 cockpit.glb\n-rw------- 1 runner runner  1438116 Nov 17 22:43 cockpit_light.glb\n-rw------- 1 runner runner    69016 Nov 17 22:43 drone.glb\n-rw------- 1 runner runner    55596 Nov 17 22:43 escape_pod.glb\n-rw------- 1 runner runner  1532780 Nov 17 22:43 heavy.glb\n-rw------- 1 runner runner  1596768 Nov 17 22:43 heavy_B.glb\n-rw------- 1 runner runner  1512944 Nov 17 22:43 heavy_C.glb\n-rw------- 1 runner runner  6729808 Nov 17 22:43 lab_alien.glb\n-rw------- 1 runner runner  6134544 Nov 17 22:43 lab_atelier.glb\n-rw------- 1 runner runner 14187700 Nov 17 22:43 lab_atelier_a.glb\n-rw------- 1 runner runner 10801072 Nov 17 22:43 lab_atelier_b.glb\n-rw------- 1 runner runner 11706000 Nov 17 22:43 lab_atelier_c.glb\n-rw------- 1 runner runner 248801 Nov 17 23:45 0004.jpg\n-rw------- 1 runner runner 247613 Nov 17 23:45 0005.jpg\n-rw------- 1 runner runner 247450 Nov 17 23:45 0006.jpg\nTue Nov 17 23:45:40 UTC 2026\n"}
exec_command, view_imagepython3 - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python3 - <<'PY' from PIL import Image from pathlib import Path p=Path('review/out/form-zero') out=Image.new('RGB',(760,426)) ims=[p/'game/0000.jpg',p/'final-proof/proof-04.jpg'] for i,file in enumerate(ims): im=Image.open(file);im.thumbnail((380,300));out.paste(im,(i*380,0)) for i,name in enumerate(('0216','0259')): im=Image.open(p/f'lit-proof/{name}.jpg');im.thumbnail((380,190));out.paste(im,(i*380,215)) out.save(p/'check.jpg') PY python3 - <<'PY' import struct,json,re from pathlib import Path j=re.findall("'([a-z]+(?:\\\\.[LR])?)'",Path('src/render/mech.ts').read_text().split('export const JOINTS = [')[1].split('] as const')[0]) def rig(name): b=Path('public/assets/'+name+'.glb').read_bytes() doc=json.loads(b[20:20+struct.unpack_from('<I',b,12)[0]]) parents={i:n['name'] for n in doc['nodes'] for i in n.get('children',[])} return {n['name']:(parents.get(i), n.get('translation'), n.get('rotation'), n.get('scale'),n.get('matrix')) for i,n in enumerate(doc['nodes']) if n['name'] in j} z,d,s=map(rig,('block_zero','block_dummy','striker')) assert len(j)==len(z)==len(d)==22 print('0 ↔ dummy', [n for n in j if z[n]!=d[n]]) print('0 ↔ S', [n for n in j if z[n]!=s[n]]) PY`})) image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/check.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.6 seconds
Output:
{"chunk_id":"6fbac7","wall_time_seconds":0.317769629,"exit_code":0,"original_token_count":8,"output":"0 ↔ dummy []\n0 ↔ S ['neck']\n"}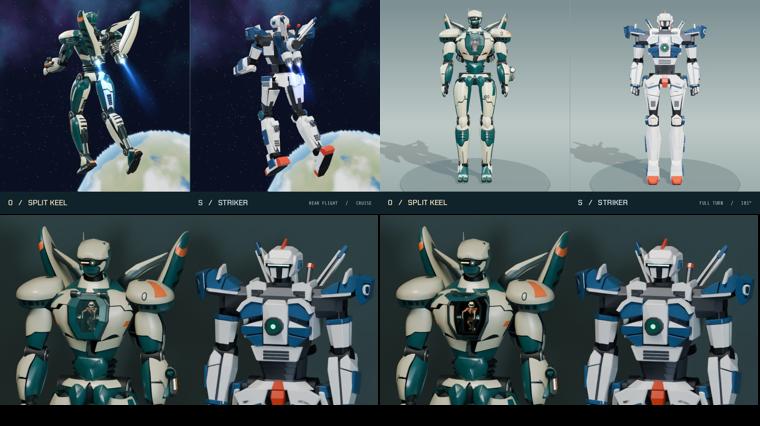
check.jpg exec_commandffmpeg -loglevel error -y -loop 1 -i review/out/form-zero/game/0000.jpg -t 0.5 -threads 2 -c:v libx264 -pix_fmt yuv420p review/out/form-zero/test.mp4 && node --input-type=module <<'NODE' (+1 more)
command
ffmpeg -loglevel error -y -loop 1 -i review/out/form-zero/game/0000.jpg -t 0.5 -threads 2 -c:v libx264 -pix_fmt yuv420p review/out/form-zero/test.mp4 && node --input-type=module <<'NODE' import {chromium} from 'playwright'; import {resolve} from 'node:path'; import {pathToFileURL} from 'node:url'; const b=await chromium.launch({headless:true}); const p=await b.newPage(); await p.goto(pathToFileURL(resolve('review/out/form-zero/test.mp4')).href); console.log(await p.locator('video').evaluate(async v=>{v.muted=true;await v.play();return [v.duration,v.videoWidth,v.canPlayType('video/mp4; codecs="avc1.42E01E"')]})); await b.close(); NODE cat review/out/form-zero/stages && cat review/out/form-zero/build*-time && env TZ=UTC date && ls review/out/form-zero/finish-frames | tail && tail -4 review/out/form-zero/finish.log && head -80 kit/build.py && rg -n 'frame|striker' docs/sizes.md | head -12result, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"4d06ce","wall_time_seconds":0.251446399,"session_id":90605,"original_token_count":0,"output":""}{"chunk_id":"177105","wall_time_seconds":0.000008251,"exit_code":0,"original_token_count":1739,"output":"Warning: truncated output (original token count: 1739)\nTotal output lines: 106\n\n1794956820 brief and source review\n1794956904 armour and cockpit design\n1794957372 comparison camera and first proof\n1794957495 reshape drive cowls, break up limb armour and inspect glazing\n1794958338 pressure hatch, surface cuts, service markings and motion\n1794959075 production capture and render\n17.99\n36.87\n25.12\n26.91\n32.86\n24.67\n32.59\nTue Nov 17 23:46:06 UTC 2026\n0216.jpg\n0217.jpg\n0218.jpg\n wall_mat.use_nodes=True\n00:23.052 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0216.jpg'\n00:49.599 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0217.jpg'\n01:15.806 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0218.jpg'\n\"\"\"Build every model into public/assets/*.glb.\n\n npm run kit # everything\n npm run kit -- striker ship # just these\n npm run kit -- block_dummy # a block model, kit/blocks/dummy.py\n\"\"\"\nimport os\nimport sys\nimport time\n\nsys.path.insert(0, os.path.dirname(os.path.abspath(__file__)))\n\nimport lib # noqa: E402\nfrom block import build_block # noqa: E402\nfrom cockpit import build_cockpit # noqa: E402\nfrom cockpit_light import build_cockpit_light # noqa: E402\nfrom mech import build_striker # noqa: E402\nfrom heavy import build_heavy, build_heavy_lab # noqa: E402\nfrom props import build_cannon, build_drone, build_rifle # noqa: E402\nfrom ship import build_ship # noqa: E402\nfrom station import build_station # noqa: E402\nfrom salvage import build_salvage_pod, build_wreck_field # noqa: E402\nfrom escape_pod import build_escape_pod # noqa: E402\nfrom light import build_light, build_light_lab # noqa: E402\nfrom automaton import build_automaton, build_automaton_lab # noqa: E402\nfrom alien import build_alien, build_alien_lab # noqa: E402\nsys.path.insert(0, os.path.join(os.path.dirname(os.path.abspath(__file__)), \"lab\"))\nfrom heads import build_head_lab, build_head_lab2 # noqa: E402\nfrom headkit import build_head_lab3, build_head_lab4, build_head_lab5, build_head_lab6, build_head_lab7, build_head_lab8 # noqa: E402\nfrom sizes import build_sizes # noqa: E402\nfrom pilotlab import build_pilot_lab # noqa: E402\nfrom assembly import build_assembly_lab, build_back_lab, build_chest_frames, build_show, game_frame # noqa: E402\nfrom raider import build_raider, build_raider_lab # noqa: E402\nfrom pattern_lab …539 tokens truncated…eode\": lambda: build_alien(\"geode\"),\n \"raider_grunt\": lambda: build_raider(\"grunt\"), \"raider_brawler\": lambda: build_raider(\"brawler\"),\n \"raider_boss\": lambda: build_raider(\"boss\"),\n \"pattern_m\": build_pattern_m, \"lab_pattern\": build_pattern_lab, \"lab_atelier\": build_atelier_lab, \"lab_atelier_a\": lambda: build_atelier_line(\"a\"), \"lab_atelier_b\": lambda: build_atelier_line(\"b\"),\n \"lab_atelier_c\": lambda: build_atelier_line(\"c\"), \"lab_atelier_d\": lambda: build_atelier_line(\"d\"),\n \"lab_auto\": build_automaton_lab, \"lab_alien\": build_alien_lab, \"lab_raider\": build_raider_lab}\n\n\ndef main(names):\n os.makedirs(OUT, exist_ok=True)\n for name in names or [n for n in ASSETS if not n.startswith(\"lab\")]:\n t = time.time()\n lib.reset()\n if name.startswith(\"block_\"): # scratch models, kit/blocks/<name>.py\n build_block(name)\n else:\n ASSETS[name]()\n path = os.path.normpath(os.path.join(OUT, f\"{name}.glb\"))\n lib.export(path)\n print(f\"kit: {name} -> {path} ({os.path.getsize(path) // 1024} KB, {time.time() - t:.1f}s)\")\n\n\nmain(sys.argv[sys.argv.index(\"--\") + 1:] if \"--\" in sys.argv else [])\n4:swapping and the rig work on all of them. A frame may add joints of its own (harkens, spinners) but\n10:| standard | 17.6 m | 60% | Gundam 00 mobile suit (the striker) | one bay | all round |\n16:A bay is 12 m by 14 m: two light frames fit side by side. A heavy frame fills a bay edge to edge and\n23:sled on the striker clamps and a heavy gets wider clamps on outriggers. A heavy crouches deeper than\n24:the striker to pass under the tube's signal box, and every frame sinks onto its clamps. Try a hangar\n32:- **Standard.** The striker: hip at 60%, Gundam 00 slim and angular.\n36:Detail density stays the same in real size, so a light frame has fewer, larger plates and a heavy\n37:frame has more of them. A shrunk striker is not a light frame and a grown one is not a heavy frame.\n42:knightmare names and no lookalikes of a specific frame.\n47: wrists. In space they anchor to hulls, rock and other frames: swing round an anchor without fuel,\n54:- **Float pack.** A winged thruster pack. A light frame needs one to fight in space.\n56:Harkens and factspheres are not light-only: a standard or heavy frame can mount them as equipment.\n"}write_stdinpoll session 90605
input
text(await tools.write_stdin({session_id:90605,chars:'',yield_time_ms:100,max_output_tokens:500}))result, 4 lines
Script completed Wall time 0.0 seconds Output: {"chunk_id":"cb22d4","wall_time_seconds":0.00000376,"exit_code":0,"original_token_count":7,"output":"[ 0.52, 1600, 'probably' ]\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path p=Path('review/rear-cockpit/index.html') s=p.read_text().replace('<title>Sortie · Room for the pilot</title>','<title>Sortie · Room for the pilot / Split Keel</title>') css=''' .study-nav { display: flex; flex-wrap: wrap; gap: .4rem 1.5rem; margin-top: .75rem; font-size: .87rem } .second { margin-top: clamp(3rem, 7vw, 6rem); padding-top: 0; scroll-margin-top: 1rem } .second .intro h2 { margin: 0; font: 400 clamp(2.65rem, 5.05vw, 4.6rem)/.99 var(--serif); letter-spacing: -.055em } .film { width: 100%; height: auto; display: block; aspect-ratio: 16/9; background: #11232a } .film-tools, .chapters, .files { display: flex; flex-wrap: wrap; align-items: center; gap: .6rem 1.1rem } .film-tools { justify-content: space-between; margin-top: .95rem; padding-bottom: .8rem; border-bottom: 1px solid var(--line) } button { border: 0; border-bottom: 1px solid currentColor; background: none; padding: .25rem 0; color: var(--ink); cursor: pointer; font: inherit } button:focus-visible { outline: 3px solid var(--rust); outline-offset: 3px } .files, .chapters { font-size: .89rem } .chapters button span { margin-right: .3em; color: var(--rust); font: .79rem var(--mono) } .second .making { border: 0; margin-top: .25rem } .second .making p + p { margin-top: .65rem } .timings { display: grid; grid-template-columns: minmax(0,1fr) auto; gap: .3rem .9rem; margin: .6rem 0; font-size: .91rem } .timings dt { color: var(--muted); font-weight: 400 } .timings dd { text-align: right; font-variant-numeric: tabular-nums; white-space: nowrap } .timings .total { padding-top: .4rem; font-weight: 650; color: var(--ink); border-top: 1px solid var(--line) } details { margin-top: .9rem; color: var(--muted); font-size: .91rem } summary { cursor: pointer; color: var(--ink) } ''' s=s.replace(' @media (max-width: 48rem)',css+' @media (max-width: 48rem)') s=s.replace('<div class="intro">','''<nav class="study-nav" aria-label="Studies"><a href="#pilot">Room for the pilot</a><a href="#frame-zero">Split Keel / film</a></nav> <div class="intro" id="pilot">''',1) new=''' <section class="second" id="frame-zero" aria-labelledby="zero-title"> <div class="intro"> <div> <p class="topic">Sortie / Standard frame 0</p> <h2 id="zero-title">Split Keel</h2> </div> <p>Two swept drives frame the rear hatch. Each cowl leaves a triangle of open sky, so the back reads even when the jets are burning.</p> </div> <figure> <video class="film" id="comparison" controls playsinline preload="metadata" width="1600" height="900" poster="frame-zero/zero-flight.jpg" aria-label="Split Keel and Striker in flight, in a full turn, and in a close view of the opening cockpit" aria-describedby="film-caption"> <source src="frame-zero/zero-and-striker.mp4" type="video/mp4"> <a href="frame-zero/zero-and-striker.mp4">Open the comparison film</a> </video> <figcaption class="caption" id="film-caption">0 on the left, Striker S on the right. Both at native scale, with matched cameras, poses and lighting. Silent, 16 seconds.</figcaption> </figure> <div class="film-tools"> <div class="chapters" role="group" aria-label="Play a chapter"> <button type="button" data-time="0"><span>0:00</span> Rear flight</button> <button type="button" data-time="4"><span>0:04</span> Full turn</button> <button type="button" data-time="12.5"><span>0:12.5</span> Open canopy</button> </div> <div class="files"><a href="frame-zero/zero-and-striker.mp4">Open film</a><a href="frame-zero/frame-zero.glb" download>Download frame 0 (.glb)</a></div> </div> <div class="making"> <div> <h2>From outline to body</h2> <p>I kept all 22 joints of <i>block_dummy</i> in place. I tried round rims on the drives. In the first chase shot they looked like grab handles, so I swept the cowls back and braced each with a diagonal spar.</p> <p>I cut the plates from curved shells, opened the chest around a seated pilot and folded a three-lens inspection camera against the left forearm. The canopy clears the pilot and head at every 3° step through its 78° swing.</p> <p>I’d change the feet next. From the front the pale shins lead into two small dark toes. A broader toe plate would give the frame a firmer stance.</p> </div> <div> <h2>Time on this study</h2> <dl class="timings"> <dt>Read the rig and build the first shell</dt><dd>9 min</dd> <dt>Match the camera and shoot the first comparison</dt><dd>2 min</dd> <dt>Redraw the cowls, limbs and glazing</dt><dd>14 min</dd> <dt>Fit the hatch, detail the plates and proof the motion</dt><dd>12 min</dd> <dt>Capture, render, assemble and check the page</dt><dd>TIME_FINISH</dd> <dt class="total">Total elapsed</dt><dd class="total">TIME_TOTAL</dd> </dl> <details><summary>Rendering and rebuild command</summary> <p>The flight and full turn use the game renderer. The four nozzles on 0 and six on S use the game’s exhaust code. For the close shot I exported both painted machines to Blender and rendered the hatch in Cycles.</p> <p>TIME_COMPUTE</p> <code>bash review/form-zero/make-film.sh ~/out/frame-zero</code> </details> </div> </div> </section> ''' s=s.replace('\n\n</main>',new+'\n</main>') s=s.replace('</body>','''<script> const comparison = document.getElementById('comparison'); for (const button of document.querySelectorAll('[data-time]')) { button.addEventListener('click', () => { const start = () => { comparison.currentTime = Number(button.dataset.time); comparison.play().catch(() => comparison.focus()); }; if (comparison.readyState >= 1) start(); else { comparison.addEventListener('loadedmetadata', start, { once: true }); comparison.load(); } }); } </script> </body>''') p.write_text(s) PY rg -n 'second|TIME_|Split Keel' review/rear-cockpit/index.htmlresult, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"2919cd","wall_time_seconds":0.081420458,"exit_code":0,"original_token_count":377,"output":"7: <title>Sortie · Room for the pilot / Split Keel</title>\n51: .second { margin-top: clamp(3rem, 7vw, 6rem); padding-top: 0; scroll-margin-top: 1rem }\n52: .second .intro h2 { margin: 0; font: 400 clamp(2.65rem, 5.05vw, 4.6rem)/.99 var(--serif); letter-spacing: -.055em }\n60: .second .making { border: 0; margin-top: .25rem }\n61: .second .making p + p { margin-top: .65rem }\n90: <nav class=\"study-nav\" aria-label=\"Studies\"><a href=\"#pilot\">Room for the pilot</a><a href=\"#frame-zero\">Split Keel / film</a></nav>\n113: <p>I posed the light frame, cut open the cockpit and restored the kit helmet. The widths come from the uncut meshes. Blender and Pillow took 47.3 seconds.</p>\n141: <section class=\"second\" id=\"frame-zero\" aria-labelledby=\"zero-title\">\n145: <h2 id=\"zero-title\">Split Keel</h2>\n150: <video class=\"film\" id=\"comparison\" controls playsinline preload=\"metadata\" width=\"1600\" height=\"900\" poster=\"frame-zero/zero-flight.jpg\" aria-label=\"Split Keel and Striker in flight, in a full turn, and in a close view of the opening cockpit\" aria-describedby=\"film-caption\">\n154: <figcaption class=\"caption\" id=\"film-caption\">0 on the left, Striker S on the right. Both at native scale, with matched cameras, poses and lighting. Silent, 16 seconds.</figcaption>\n178: <dt>Capture, render, assemble and check the page</dt><dd>TIME_FINISH</dd>\n179: <dt class=\"total\">Total elapsed</dt><dd class=\"total\">TIME_TOTAL</dd>\n183: <p>TIME_COMPUTE</p>\n"}exec_commandcommand -v black; command -v ruff; ls node_modules/.bin | rg 'prettier|biome'; cat review/out/form-zero/game.log; ls review/out/form-zero/game | tail -1; tail -2 review/out/form-zero/finish.log; date -u; git check-ignore -v review/rear-cockpit/frame-zero/frame-zero.glb review/rear-cockpit/frame-zero/zero-and-striker.mp4; ls -lah review/form-zero (+1 more)
command
command -v black; command -v ruff; ls node_modules/.bin | rg 'prettier|biome'; cat review/out/form-zero/game.log; ls review/out/form-zero/game | tail -1; tail -2 review/out/form-zero/finish.log; date -u; git check-ignore -v review/rear-cockpit/frame-zero/frame-zero.glb review/rear-cockpit/frame-zero/zero-and-striker.mp4; ls -lah review/form-zero

rg -n 'crew_floor|crew\(|survey_equipment|cockpit|pilot|knee|shin|toe' kit/blocks/zero.py | tail -62 && ls -l ~/context && ls -la | rg 'AGENT'
result, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"084e5e","wall_time_seconds":0.000286035,"exit_code":0,"original_token_count":197,"output":"{\n fps: 24,\n rigs: [ { joints: 22, nozzles: 4 }, { joints: 22, nozzles: 6 } ]\n}\nframe 0\n0030.jpg\n01:49.167 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0219.jpg'\n02:13.937 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0220.jpg'\nTue Nov 17 23:47:06 UTC 2026\ntotal 44K\ndrwx------ 2 runner runner 4.0K Nov 17 23:45 .\ndrwx------ 5 runner runner 4.0K Nov 17 23:08 ..\n-rw------- 1 runner runner 2.6K Nov 17 23:45 assemble.py\n-rw------- 1 runner runner 2.4K Nov 17 23:45 capture.mjs\n-rwx------ 1 runner runner 703 Nov 17 23:45 make-film.sh\n-rw------- 1 runner runner 278 Nov 17 23:16 screen.html\n-rw------- 1 runner runner 8.5K Nov 17 23:45 screen.js\n-rw------- 1 runner runner 6.5K Nov 17 23:41 studio.py\n"}{"chunk_id":"7112ec","wall_time_seconds":0.00000534,"exit_code":1,"original_token_count":725,"output":"227: # Open at the rear between the cargo rails; the cockpit's pressure shell occupies that gap.\n433: f.axle('knee_bearing','shin',1.20,0,6.11,.61,1.19)\n434: shin=Skin([(1.61,1.20,.12,.33,.44,.44),(2.10,1.21,.04,.44,.61,.55),\n437: f.hull('tibial_spar','shin',shin)\n439: f.skin('greave_lower','shin',shin,.025,.46,-61,47,'main',skew=7,hem=.025,upper=scarf,lift=.075)\n440: f.skin('greave_mid','shin',shin,.482,.742,-54,54,'accent',skew=5,lower=scarf,cap=-.047,lift=.105)\n441: f.skin('greave_upper','shin',shin,.765,.90,-49,59,'main',skew=3,hem=-.05,cap=.055,lift=.108)\n443: f.skin('greave_slot'+str(i),'shin',shin,.53+i*.053,.546+i*.053,-28,30,'joint',\n445: f.skin('tibia_friction_strip','shin',shin,.07,.34,-9,1,'metal',skew=5,lift=.088,depth=.02)\n446: f.skin('greave_outer_keel','shin',shin,.13,.93,52,132,'accent',skew=12,hem=.07,lift=.065)\n447: f.skin('greave_inner_lame','shin',shin,.20,.93,-120,-66,'main',skew=13,hem=.085,lift=.04)\n448: f.skin('calf_dorsal_shell','shin',shin,.43,.97,142,227,'main',skew=-5,hem=.09,cap=-.04,lift=.13)\n449: f.skin('greave_outer_trim','shin',shin,.53,.75,75,84,'trim',skew=11,lift=.086,depth=.022)\n450: f.plate('floating_patella','shin',[(.65,-.41,6.24),(.85,-.43,6.70),(1.32,-.49,6.84),(1.75,-.36,6.35),\n453: f.skin('calf_extractor'+str(i),'shin',shin,.55+i*.092,.584+i*.092,156,210,'joint',skew=-4,lift=.15,depth=.035)\n457: f.tube('achilles_body'+str(i),'shin',[(x,.52,2.82),(x,.85,3.46),(x,.98,4.24)],\n459: f.rail('achilles_rod'+str(i),'shin',(x,.38,1.63),(x,.59,2.94),.080,'metal')\n461: # Split sole, toe rocker, heel brake. Their contact faces share a plane.\n466: f.plate('toe_sole'+str(s),'foot',outline,(x,-.55,.46),(0,0,-.15),'joint')\n467: f.plate('toe_fairing'+str(s),'foot',[(x-.21,-1.54,.32),(x-.13,-1.81,.36),(x+.12,-1.84,.37),\n478: nozzle_pair('calf',(1.22,.88,4.26),(0,.61,-.82),.29,.43,f.j['shin.L'],f.j['shin.R'],housing=False)\n498: ('shin','shin',1.48,-.87,4.14)]:\n515: # The boots have an outboard heel tag and two replaceable toe scuff caps.\n518: f.plate('toe_cap'+str(i),'foot',[(x-.21,-1.55,.42),(x-.15,-1.90,.37),(x+.13,-1.94,.38),\n525:def survey_equipment(f):\n541:def crew(f):\n548: pts=figure.pilot(f.j['torso'],at=loc,z=origin.z,n='crew',pose='bike',role='trim')\n574: # Bolt the seat and controls to a continuous cockpit floor; each grip has a\n575: # fixed support forward of the pilot and the footboards flank the centre console.\n576: f.put('crew_floor','torso',loft([(12.96,octo(1.43,1.70,.20,y=-.23)),(13.11,octo(1.43,1.70,.20,y=-.23))]),'frame',.04)\n670: survey_equipment(f)\n671: crew(f)\ntotal 24\n-rw------- 1 runner runner 3877 Nov 17 22:43 brief-sortie-full.md\n-rw------- 1 runner runner 14308 Nov 17 22:43 project_sortie_mech_game.md\ndrwx------ 2 runner runner 4096 Nov 17 22:43 reflect\n"}exec_commandls review/out/form-zero/game | tail -1 && cat review/out/form-zero/studio-seconds && cat review/out/form-zero/game-seconds && sed -n '155,248p' kit/blocks/zero.py
command
ls review/out/form-zero/game | tail -1 && cat review/out/form-zero/studio-seconds && cat review/out/form-zero/game-seconds && sed -n '155,248p' kit/blocks/zero.py
result, 4 lines
Script completed Wall time 0.3 seconds Output: {"chunk_id":"abb096","wall_time_seconds":0.00000521,"exit_code":0,"original_token_count":1373,"output":"Warning: truncated output (original token count: 1373)\nTotal output lines: 95\n\n0032.jpg\n for row in range(3):\n for i in range(n):\n j=(i+1)%n\n fs.append([row*n+i,row*n+j,(row+1)*n+j,(row+1)*n+i])\n fs.extend([[3*n+i,3*n+(i+1)%n,4*n] for i in range(n)])\n return self.put(name,joint,mesh(vs,fs),role,.024)\n\n def rail(self,name,joint,a,b,r,role):\n self.tube(name,joint,[a,b],[r,r],role)\n\n def hull(self,name,joint,s,role='frame'):\n rings=[]\n for i in range(21):\n t=i/20\n pts=[s.point(t,ang,-.095) for ang in range(-180,180,10)]\n rings.append((pts[0].z,[(p.x,p.y) for p in pts]))\n self.put(name,joint,loft(rings),role)\n\n\n\ndef drives(f):\n # A swept outer bow loops back onto the nozzle collar. The intake is open all the\n # way through: the inner graphite spar is visible against space from the chase view.\n # The outer shell is a cambered, tapered blade. A separate diagonal strut\n # closes the load path at the high tip, leaving a triangular sightline through it.\n blade = Skin([(12.76,1.43,3.22,.37,.43,.50),(13.22,1.68,3.47,.48,.54,.61),\n (14.12,2.05,3.60,.47,.58,.66),(15.03,2.52,3.65,.42,.68,.63),\n (15.91,2.90,3.62,.34,.75,.53),(16.65,3.15,3.56,.23,.66,.43),\n (17.20,3.34,3.76,.085,.38,.16),(17.32,3.38,3.96,.024,.07,.065)],.67)\n f.hull('drive_arch_spar','binder',blade)\n f.skin('drive_outboard_chine','binder',blade,.015,.97,3,151,'accent',skew=-8,lift=.06)\n f.skin('drive_inboard_chine','binder',blade,.14,.99,-115,-3,'main',skew=-7,lift=.055,hem=.04)\n f.skin('jet_spine','binder',blade,.02,.98,155,236,'main',skew=-8,lift=.052)\n f.skin('drive_id_flash','binder',blade,.68,.75,1,145,'trim',skew=-5,hem=-.045,cap=-.04,lift=.072,depth=.02)\n for i in range(4):\n f.skin('drive_cooling_slot'+str(i),'binder',blade,.22+i*.085,.256+i*.085,66,139,'joint',\n hem=.017,cap=.015,skew=-15,lift=.073,depth=.023)\n bow=[(.79,1.92,14.36),(.92,1.99,15.18),(1.25,2.12,15.59),\n (1.82,2.49,15.91),(2.48,2.91,16.16),(3.05,3.51,16.72)]\n f.tube('diagonal_load_bridge','binder',bow,[.28,.34,.29,.22,.17,.10],'frame',12,.53)\n f.plate('intake_bridge_fairing','binder',[(.68,1.88,14.97),(.96,2.02,15.64),(1.42,2.22,15.98),\n (2.95,3.40,16.57),(2.85,3.38,16.28),(1.72,2.69,15.59),(1.21,2.34,15.22),(.98,2.04,14.82)],\n (1.64,2.16,15.87),(0,.17,-.04),'main')\n for i in range(3):\n z=13.62+i*.27\n f.tube('intake_vane'+str(i),'binder',[(1.27,2.62,z),(1.46+i*.08,2.99,z+.17),(1.77+i*.16,3.36,z+.31)],\n [.042,.066,.045],'metal',8,1.7)\n for side in (-1,1):\n f.tube('drive_trunnion_yoke'+str(side),'backpack',[(side*.45,1.27,14.13),(side*.8,1.77,14.4…3 tokens truncated…,2.34,14.6)],\n [.39,.42,.36],'frame')\n f.axle('gimbal','binder',.95,2.24,14.72,.48,.68)\n f.tube('motor_barrel','binder',[(1.13,2.32,14.28),(1.20,2.62,13.67),(1.39,3.2,12.89)],\n [.42,.57,.60],'joint',24)\n for i in range(5):\n t=i/5\n a=Vector((1.19+.16*t,2.55+.55*t,13.8-.76*t))\n b=a+Vector((.012,.06,-.075))\n f.tube('compressor_ring'+str(i),'binder',[a,b],[.55+.08*t]*2,'metal',24)\n nozzle_pair('main',(1.4,3.17,13.01),(.12,.72,-.78),.62,.76,f.j['binder.L'],f.j['binder.R'],housing=False)\n # A single central spine on the fixed backpack, with a recessed boarding collar.\n f.tube('dorsal_spine','backpack',[(0,1.08,12.05),(0,1.60,12.62),(0,1.72,13.51)],\n [.44,.61,.54],'frame',16,.64)\n for i in range(6):\n z=12.12+i*.17\n f.plate('rear_heat_louver'+str(i),'backpack',[(-.53,1.47,z),(-.45,2.03,z-.07),(.45,2.03,z-.07),(.53,1.47,z)],\n (0,1.75,z+.10),(0,0,-.038),'metal' if i in (0,5) else 'accent')\n\n\ndef torso(f):\n body=Skin([(11.54,0,0,.62,.57,.53),(12.04,0,0,.88,.76,.67),\n (12.80,0,0,1.26,1.03,.94),(13.7,0,.02,1.73,1.31,1.12),\n (14.42,0,.04,1.95,1.20,1.17),(14.90,0,.05,1.56,.90,1.02),(15.21,0,0,.72,.60,.66)],.78)\n # Open at the rear between the cargo rails; the cockpit's pressure shell occupies that gap.\n for sign in (-1,1):\n def p(name,lo,hi,a,b,role,**kw):\n f.skin(name+str(sign),'torso',body,lo,hi,sign*a,sign*b,role,**kw)\n p('chest_casting',.02,.99,19,138,'frame',lift=-.09)\n seam=((0,.018),(.32,.025),(.45,-.036),(.72,-.040),(1,-.083))\n p('breast_undershield',.34,.655,19,77,'main',skew=5,hem=.06,upper=seam,lift=.05)\n p('breast_fairing',.67,.91,24,82,'main',skew=5,lower=seam,cap=.045,lift=.095)\n p('breast_livery_blade',.69,.84,57,69,'accent',skew=12,lift=.114,depth=.021)\n p('collar_blade',.88,.993,7,102,'accent',skew=-5,lift=.085)\n p('flank_housing',.35,.88,85,140,'accent',hem=.13,lift=.045)\n p('service_release',.46,.51,61,74,'trim',skew=3,lift=.078,depth=.025)\n for i in range(3):\n p('costal_lame'+str(i),.015+i*.107,.119+i*.107,8,140,'main' if i==2 else 'accent',\n skew=5,hem=.04,cap=.04,lift=.035)\n\n for i in range(4):\n p('side_slot'+str(i),.53+i*.065,.553+i*.065,91,123,'joint',skew=-3,lift=.058,depth=.022)\n # Mill the actual pocket in the breast and collar. The pressure tub sits behind\n # the lip and the hinged glazing nests in its rebate without overlapping armour.\n outer=[(-.66,-1.02,14.96),(.57,-1.04,14.96),(.88,-1.21,14.53),(.86,-1.43,13.79),\n (.48,-1.46,12.98),(-.43,-1.46,12.98),(-.83,-1.44,13.67),(-.89,-1.26,14.46)]\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path p=Path('review/form-zero/studio.py') s=p.read_text().replace('"""Matched orthographic turn of 0 and S. Inputs are the game-painted rest meshes."""','"""Render the opening canopy beside S, using their game-painted rest meshes."""') s=s.replace("parser.add_argument('--start',type=int,default=0)","parser.add_argument('--start',type=int,default=216)").replace("parser.add_argument('--end',type=int,default=287)","parser.add_argument('--end',type=int,default=259)") s=s[:s.index('bpy.ops.mesh.primitive_plane_add(size=900')] + s[s.index("world=bpy.data.worlds.new"):] s=s[:s.index('def arrange(i):')]+'''# Each frame occupies exactly half of this orthographic sensor. Native scale and # root orientation are identical. The camera stays still throughout the hatch test. width = 17.3 aim = 14.12 for root, sign in zip(roots, (-1, 1)): root.location.x = sign * width / 4 root.rotation_euler.z = math.radians(-14) cam.data.ortho_scale = width cam.location = (0, -70, aim + 70 * math.tan(math.radians(8))) cam.rotation_euler = (Vector((0, 0, aim)) - cam.location).to_track_quat('-Z', 'Y').to_euler() frames = (216, 238, 259) if args.proof else range(args.start, args.end + 1) for i in frames: travel = max(0, min(1, (i - 216) / 43)) hinge.rotation_euler.x = math.radians(-78 * travel * travel * (3 - 2 * travel)) scene.render.filepath = str((args.output / f'{i:04d}.jpg').resolve()) bpy.ops.render.render(write_still=True) ''' p.write_text(s) PY head -20 review/form-zero/studio.py && tail -2 review/out/form-zero/finish.logresult, 4 lines
Script completed
Wall time 0.3 seconds
Output:
{"chunk_id":"04d5b5","wall_time_seconds":0.013558097,"exit_code":0,"original_token_count":225,"output":"\"\"\"Render the opening canopy beside S, using their game-painted rest meshes.\"\"\"\nimport argparse\nimport math\nimport sys\nfrom pathlib import Path\n\nimport bpy\nfrom mathutils import Vector\n\nparser=argparse.ArgumentParser()\nparser.add_argument('assets',type=Path)\nparser.add_argument('output',type=Path)\nparser.add_argument('--proof',action='store_true')\nparser.add_argument('--start',type=int,default=216)\nparser.add_argument('--end',type=int,default=259)\nparser.add_argument('--samples',type=int,default=10)\nargs=parser.parse_args(sys.argv[sys.argv.index('--')+1:])\nargs.output.mkdir(parents=True,exist_ok=True)\nbpy.ops.wm.read_factory_settings(use_empty=True)\nscene=bpy.context.scene\n02:13.937  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0220.jpg'\n02:43.805  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0221.jpg'\n"}
exec_command, view_imagepython3 - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python3 - <<'PY' from PIL import Image im=Image.open('review/out/form-zero/game/0032.jpg');im.thumbnail((800,450));im.save('review/out/form-zero/poster-qc.jpg') PY date -u; tail -2 review/out/form-zero/finish.log; ls review/out/form-zero/game | tail -1`})) image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/poster-qc.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.6 seconds
Output:
{"chunk_id":"cf341f","wall_time_seconds":0.27245878,"exit_code":0,"original_token_count":64,"output":"Tue Nov 17 23:47:45 UTC 2026\n02:13.937  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0220.jpg'\n02:43.805  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0221.jpg'\n0041.jpg\n"}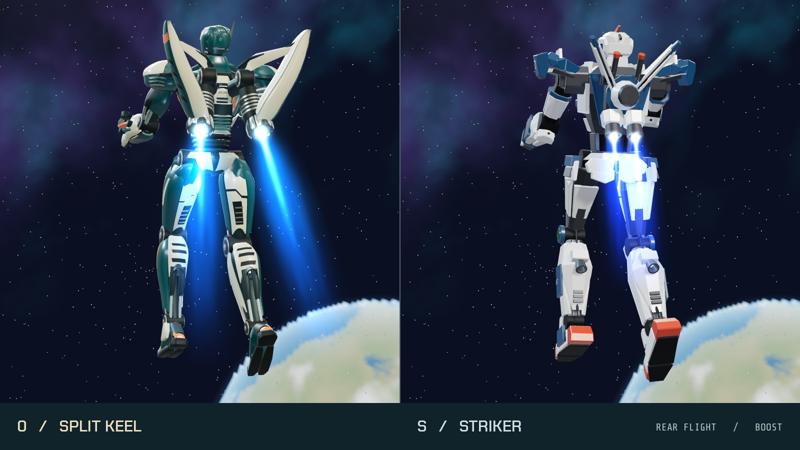
poster-qc.jpg exec_commandmkdir -p ~/out/frame-zero
command
mkdir -p ~/out/frame-zero
cp review/out/form-zero/game/0032.jpg ~/out/frame-zero/zero-flight.jpg
sha256sum ~/out/frame-zero/zero-flight.jpg review/out/form-zero/game/0032.jpg
result, 4 lines
Script completed
Wall time 0.2 seconds
Output:
{"chunk_id":"878179","wall_time_seconds":0.000005821,"exit_code":0,"original_token_count":53,"output":"6e97feabe98e1ebfb39a44a14454eb508a38c2969a7773b74599992c70f0edb3  ~/out/frame-zero/zero-flight.jpg\n6e97feabe98e1ebfb39a44a14454eb508a38c2969a7773b74599992c70f0edb3  review/out/form-zero/game/0032.jpg\n"}