A mech game prototype, pushed by GPT-6.2-Astra
agent (cont.)
+45:06view_image~/work/sortie/review/out/form-zero/studio-proof/
input
const r=await Promise.allSettled(["0020","0106","0241"].map(i=>tools.view_image({path:"~/work/sortie/review/out/form-zero/studio-proof/"+i+".jpg"}))); for(const x of r)image(x.value.image_url)result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
image_12.jpg 
image_13.jpg 
image_14.jpg exec_commandsed -n '230,263p' kit/lib.py && cat review/out/form-zero/stages && date -u
command
sed -n '230,263p' kit/lib.py && cat review/out/form-zero/stages && date -u
result, 38 lines
Script completed Wall time 0.1 seconds Output: Warning: truncated output (original token count: 373) Total output lines: 39 def boolean(target, cutter_bm, op="DIFFERENCE", role=None): """Cut (or intersect/union) a solid object with a bmesh volume. With a role, the faces the cutter leaves behind (the inside of a cavity) take that material.""" me = bpy.data.meshes.new("_cut") cutter_bm.to_mesh(me) cutter_bm.free() if role is not None: me.materials.append(material(role)) cutter = link(bpy.data.objects.new("_cut", me)) bpy.context.view_layer.update() cutter.matrix_world = target.matrix_world.copy() mod = target.modifiers.new("bool", "BOOLEAN") mod.operation = op mod.object = cutter mod.solver = "EXACT" if r…46 tokens truncated…o_view(front, side, top=None, span=60.0): """Intersect a front outline (x, z) with a side outline (y, z), and optionally a top outline (x, y). Returns a bmesh. The classic way to block out armour and heads.""" a = prism(front, -span, span, "xz") me = bpy.data.meshes.new("_tv") a.to_mesh(me) a.free() o = link(bpy.data.objects.new("_tv", me)) boolean(o, prism(side, -span, span, "yz"), "INTERSECT") 1794956820 brief and source review 1794956904 armour and cockpit design 1794957372 comparison camera and first proof 1794957495 reshape drive cowls, break up limb armour and inspect glazing Tue Nov 17 23:30:10 UTC 2026exec_commanddate -u +'%s pressure hatch, surface cuts, service markings and motion' >> review/out/form-zero/stages
command
date -u +'%s pressure hatch, surface cuts, service markings and motion' >> review/out/form-zero/stages cat > review/out/form-zero/finish.py <<'PY' from pathlib import Path p=Path('kit/blocks/zero.py');s=p.read_text().replace('from lib import cylinder, loft, octo, solid','from lib import attach, boolean, cylinder, empty, loft, octo, prism, solid') s=s.replace('def __init__(self, rows, exponent=.85):','def __init__(self, rows, exponent=.85, chine=0):').replace('self.exponent = exponent','self.exponent = exponent\n self.chine = chine') a=s.index(' return Vector((x+(w+lift)');b=s.index('\n\n def panel',a) s=s[:a]+''' sx=signed_power(si,self.exponent) sy=-signed_power(co,self.exponent) if self.chine: # Blend a pressed, seven-chine section into the softer joint transitions. pts=[(0,-1.13),(.52,-.94),(.91,-.49),(1.04,.06),(.87,.63),(.40,.97), (0,1.0),(-.49,.87),(-.86,.50),(-.96,-.02),(-.79,-.59),(-.39,-.95)] pos=angle%360/30 i=int(pos) u=pos-i a,b=pts[i],pts[(i+1)%12] mix=self.chine*(.7+.3*math.sin(t*math.pi)) sx=sx*(1-mix)+(a[0]*(1-u)+b[0]*u)*mix sy=sy*(1-mix)+(a[1]*(1-u)+b[1]*u)*mix return Vector((x+max(.009,w+lift)*sx, y+max(.009,(front if co>0 else back)+lift)*sy, z)) '''+s[b:] s=s.replace("1.15,.02,.53,.65,.66)],.79)","1.15,.02,.53,.65,.66)],.70,.85)").replace("1.20,0,.38,.42,.45)],.76)","1.20,0,.38,.42,.45)],.70,.90)").replace("2.51,.13,.32,.36,.40)],.72)","2.51,.13,.32,.36,.40)],.67,.85)").replace("2.17,.26,.18,.28,.25)],.59)","2.17,.26,.18,.28,.25)],.59,.72)") a=s.index(" # Crew capsule:");b=s.index(" f.plate('rear_pressure_vessel'",a) s=s[:a]+''' # Mill the actual pocket in the breast and collar. The pressure tub sits behind # the lip and the hinged glazing nests in its rebate without overlapping armour. outer=[(-.66,-1.02,14.96),(.57,-1.04,14.96),(.88,-1.21,14.53),(.86,-1.43,13.79), (.48,-1.46,12.98),(-.43,-1.46,12.98),(-.83,-1.44,13.67),(-.89,-1.26,14.46)] rim=[(-.39,-1.21,14.76),(.34,-1.21,14.76),(.55,-1.34,14.45),(.57,-1.48,13.85), (.32,-1.52,13.26),(-.26,-1.52,13.26),(-.52,-1.48,13.77),(-.55,-1.36,14.39)] cut=[(x*1.03,14+(z-14)*1.022) for x,y,z in outer] for obj in list(f.j['torso'].children): if obj.type=='MESH' and obj.name.startswith(('chest_casting','breast_fairing','collar_blade','costal_lame','pectoralis','chest_inlay')): boolean(obj,prism(cut,-2.3,-.7,'xz')) # Closed annular solids give the pressed perimeter a return lip on both sides. def ring(name,loops,role): n=len(loops[0]) faces=[[j*n+i,j*n+(i+1)%n,((j+1)%len(loops))*n+(i+1)%n,((j+1)%len(loops))*n+i] for j in range(len(loops)) for i in range(n)] return f.put(name,'torso',mesh([v for seq in loops for v in seq],faces),role,.014,False) ring('fixed_escape_coaming', [[(x*1.14,y+.32,14+(z-14)*1.08) for x,y,z in outer], [(x*1.12,y+.038,14+(z-14)*1.064) for x,y,z in outer],outer,[(x,y+.25,z) for x,y,z in outer]],'frame') recessed=[(x,y+.06,z) for x,y,z in rim] tubback=[(x*1.22,.59,14+(z-14)*1.17) for x,y,z in rim] ring('pressure_tub', [recessed,tubback,[(x*1.08,y+.1,14+(z-14)*1.04) for x,y,z in tubback], [(x*1.12,y+.07,14+(z-14)*1.08) for x,y,z in recessed]],'joint') hinge=empty('canopy.hinge',(0,-1.03,14.98),f.j['torso'],travel_degrees=78) bezel=ring('hinged_canopy_bezel',[outer,rim,recessed,[(x,y+.045,z) for x,y,z in outer]],'accent') attach(bezel,hinge) window=f.put('forward_pressure_glass','torso',mesh(recessed+[(0,-1.47,14.03)], [[i,(i+1)%len(rim),len(rim)] for i in range(len(rim))]),'canopy.glass') attach(window,hinge) for side in (-1,1): f.put('rotary_hinge'+str(side),'torso',cylinder(.155,side*.70-.16,side*.70+.16,24, axis='x',at=(-1.03,14.98)),'frame',.018) lug=f.put('hinge_leaf'+str(side),'torso',cylinder(.123,side*.50-.12,side*.50+.12,24, axis='x',at=(-1.03,14.98)),'metal',.012) attach(lug,hinge) for z,y in [(13.67,-1.43),(14.48,-1.24)]: pin=f.put('canopy_flush_lock'+str(side)+str(z),'torso',cylinder(.055,y-.018,y+.025,12, axis='y',at=(side*(.70 if z<14 else .68),z)),'metal') attach(pin,hinge) # Pressure bulkhead behind the crew, with a removable dorsal service panel. f.put('cabin_bulkhead','torso',loft([(13.03,octo(1.19,.41,.15,y=.65)),(13.44,octo(1.55,.44,.18,y=.74)), (14.54,octo(1.56,.45,.19,y=.75)),(15.03,octo(1.20,.39,.13,y=.72))]),'frame',.045) '''+s[b:] # close the pressure hood with an angular sagittal crown whose trailing fairing tapers into the nape a=s.index(" f.skin('one_piece_survey_hood'");b=s.index(" f.plate('optical_bench'",a) s=s[:a]+''' def section(y,w,bottom,top): return (y,[(-w*.88,bottom+.055),(-w,bottom+.14),(-w*.92,top-.13),(-w*.56,top-.015), (-w*.12,top+.055),(w*.56,top-.045),(w*.90,top-.13),(w,bottom+.13), (w*.88,bottom+.025),(w*.44,bottom+.065),(-w*.38,bottom+.09)]) f.put('rangefinder_hood','head',loft([section(-1.04,.34,16.57,16.79),section(-.89,.59,16.54,16.93), section(-.42,.729,16.52,17.17),section(.16,.73,16.46,17.34),section(.47,.63,16.40,17.28)], axis='y'),'main',.035) f.put('rear_skull_cap','head',loft([section(.49,.625,16.40,17.27),section(.68,.56,16.26,17.15), section(.89,.33,16.20,16.90)],axis='y'),'accent',.032) f.rail('brow_glare_seal','head',(-.40,-.966,16.58),(.38,-.97,16.58),.037,'frame') '''+s[b:] s=s.replace(" f.hull('scanner_recess','head',h,'visor')"," f.skin('scanner_recess','head',h,.02,.54,-180,180,'visor',lift=-.065)") # strengthen the ankle shroud and house the rear hip. a=s.index(' # The boots have') s=s[:a]+''' f.plate('hip_dorsal_guard','thigh',[(.66,.49,10.48),(1.13,.79,10.64),(1.66,.70,10.46), (1.92,.57,10.03),(1.86,.71,9.69),(1.49,.98,9.42),(.95,.93,9.61),(.70,.72,9.94)], (1.30,1.05,10.12),(0,-.18,.03),'accent') f.plate('ankle_outer_guard','foot',[(1.47,-.53,.73),(1.76,-.44,.62),(1.78,.56,.55), (1.72,.70,.89),(1.66,.41,1.46),(1.62,.18,1.82),(1.50,-.26,1.81)], (1.80,.02,1.24),(-.14,0,0),'main') '''+s[a:] # Identifying livery is part of the mesh and follows the joint in any viewer. a=s.index('\ndef build(Blocks):') s=s[:a]+''' def identification(f): from mathutils.bvhtree import BVHTree bpy.context.view_layer.update() graph=bpy.context.evaluated_depsgraph_get() def print_on(target, words, at, normal, size, role): obj=bpy.data.objects[target] tree=BVHTree.FromObject(obj,graph) inv=obj.matrix_world.inverted() n=Vector(normal).normalized() right=Vector((0,0,1)).cross(n).normalized() up=n.cross(right).normalized() text=bpy.data.curves.new('Cut stencil','FONT') text.body=words text.align_x='CENTER' text.align_y='CENTER' text.size=size text.resolution_u=5 source=bpy.data.objects.new('Stencil master',text) bpy.context.scene.collection.objects.link(source) baked=bpy.data.meshes.new_from_object(source.evaluated_get(graph)) baked.calc_loop_triangles() vs=[] for v in baked.vertices: p=Vector(at)+right*v.co.x+up*v.co.y+n*3 hit=tree.ray_cast(inv@p,inv.to_3x3()@-n)[0] vs.append(None if hit is None else obj.matrix_world@hit+n*.009) faces=[list(tri.vertices) for tri in baked.loop_triangles if all(vs[i] is not None for i in tri.vertices)] if faces: m=mesh([v if v is not None else (0,0,0) for v in vs],faces) for face in m.faces: if face.normal.dot(n)<0: face.normal_flip() solid('mark_'+words,m,role,obj.parent,panels=False) bpy.data.objects.remove(source,do_unlink=True) bpy.data.curves.remove(text) bpy.data.meshes.remove(baked) print_on('scapular_roof.L','0',(2.64,-1.10,14.96),(0,-1,.20),.57,'zero.ink') print_on('scapular_roof.R','0',(-2.66,1.21,14.99),(0,1,.25),.53,'zero.ink') print_on('drive_outboard_chine.L','LIFT',(2.82,3.62,15.40),(.93,.36,0),.16,'stencil') print_on('quadriceps_upper.L','00',(1.22,-1.0,8.72),(0,-1,.03),.47,'zero.ink') print_on('forearm_outboard.R','SVC',(-3.06,.02,10.82),(-1,0,.05),.20,'zero.ink') print_on('boarding_hatch','ACCESS',(0,1.79,14.03),(0,1,.05),.115,'zero.ink') print_on('rear_skull_cap','0',(0,.91,16.66),(0,1,0),.21,'stencil') def exhaust_details(f): origin=Vector((1.4,3.17,13.01)) axis=Vector((.12,.72,-.78)).normalized() u=axis.cross(Vector((0,0,1))).normalized() v=axis.cross(u).normalized() def at(t,angle,r): a=angle*RAD return origin+axis*t+r*(u*math.cos(a)+v*math.sin(a)) # Floating refractory petals surround the standard plume emitter. Slots between # petals remain open to the underlying dark bell even when the motor is cold. for i in range(12): a=i*30 pts=[at(.16,a-11,.56),at(.16,a+11,.56),at(.58,a+13,.638),at(.83,a+9,.657), at(.87,a-8,.65),at(.55,a-13,.63)] f.plate('nozzle_petal_'+str(i),'binder',pts,at(.51,a,.671), -(u*math.cos(a*RAD)+v*math.sin(a*RAD))*.035,'metal' if i%3 else 'frame') for s in (-1,1): x=1.27+s*.30 f.tube('gimbal_actuator'+str(s),'binder',[(x,2.20,14.48),(x+.09,2.74,14.16),(x+.10,2.96,13.90)], [.12,.145,.12],'frame') f.rail('gimbal_piston'+str(s),'binder',(x+.10,2.92,13.96),(x+.16,3.30,13.50),.073,'metal') '''+s[a:] s=s.replace(' crew(f)\n',' crew(f)\n exhaust_details(f)\n identification(f)\n') p.write_text(s) p=Path('kit/blocks/zero-paint.json');s=p.read_text().replace(' "main":',' "zero.ink": {"color":"#233b39","rough":0.58},\n "sensor": {"color":"#357a75","rough":0.19,"metal":0.39},\n "main":') p.write_text(s) PY python review/out/form-zero/finish.py /usr/bin/time -f '%e' -o review/out/form-zero/build4-time ~/.local/bin/blender -b -t 7 --python-exit-code 1 -P kit/build.py -- block_zero > review/out/form-zero/build4.log 2>&1result, 4 lines
Script completed Wall time 0.4 seconds Output: {"chunk_id":"f65256","wall_time_seconds":0.250799398,"session_id":59899,"original_token_count":0,"output":""}exec_commandrg -n 'export function find' src/render/assets.ts -A5 && sed -n '68,124p' src/render/materials.ts && tail -10 review/out/form-zero/build4.log && head -90 review/rear-cockpit/index.html && date -u
command
rg -n 'export function find' src/render/assets.ts -A5 && sed -n '68,124p' src/render/materials.ts && tail -10 review/out/form-zero/build4.log && head -90 review/rear-cockpit/index.html && date -u
result, 87 lines
Script completed Wall time 0.1 seconds Output: Warning: truncated output (original token count: 2160) Total output lines: 155 114:export function find(map: Map<string, THREE.Object3D>, name: string): THREE.Object3D | undefined { 115- return map.get(name) ?? map.get(name.replace(/\./g, '_')) ?? map.get(name.replace(/\./g, '')); 116-} 117- 118-/** 119- * Rigid parts that share a joint and a material become one mesh: a frame is ~150 parts but only a } if (l.toon) { const t = new THREE.MeshToonMaterial({ color, gradientMap: toonBands() }); t.name = role; if (role === 'hazard') addStripes(t as unknown as THREE.MeshStandardMaterial); cache.set(id, t); return t; } const s = coat >= 0.5 ? new THREE.MeshPhysicalMaterial({ color, roughness, metalness: p.metal ?? 0, clearcoat: coat, clearcoatRoughness: 0.25 }) : new THREE.MeshStandardMaterial({ color, roughness, metalness: p.metal ?? 0 }); if (p.emit) s.emissive.copy(color).multiplyScalar(p.emit); if (role === 'hazard') addStripes(s); else if (painted || role === 'frame' || role === 'joint' || role === 'rust') addPaintVariation(s, l.grime * (painted ? 1 : 0.6)); if (p.rust) addRust(s, p.rust); m = s; } m.name = role; cache.set(id, m); return m; } /** Rust from world position, so no UVs are needed: blotches that grow with `amount`, streaks running down * from them, rougher and duller where the paint has gone. */ function addRust(m: THREE.MeshStandardMaterial, amount: number) { const prev = m.onBeforeCompile; m.onBeforeCompile = (shader, r) => { prev?.call(m, shader, r); shader.vertexShader = shader.vertexShader .replace('#include <common>', '#include <common>\nvarying vec3 vRustPos;') .replace('#include <worldpos_vertex>', '#include <worldpos_vertex>\nvRustPos = (modelMatrix * vec4(transformed, 1.0)).xyz;'); shader.fragmentShader = sha…1262 tokens truncated… .8rem; background: #eeeee6; font: .8rem/1.55 var(--mono); overflow-wrap: anywhere } @media (max-width: 48rem) { .intro, .notes, .making { grid-template-columns: 1fr } .intro { gap: .85rem; padding: 1.25rem 0 } .notes { margin-top: 1.8rem; gap: 1.7rem } .making { margin-top: 1.7rem } .byline { flex-wrap: wrap; gap: .2rem 1rem; padding-top: .8rem } .caption { flex-wrap: wrap; gap: .2rem 1rem } } @media print { main { max-width: none; padding: 0 } .caption a { display: none } figure, section, .making { break-inside: avoid } } </style> </head> <body> <main> <header> <div class="byline"> <span>GPT-6.2-Astra (gpt-6.2-astra), effort high</span> <time datetime="2026-11-17">17 November 2026</time> </div> <div class="intro"> <div> <p class="topic">Sortie / Light frame study</p> <h1>Room for the pilot</h1> </div> <p>The pilot rides behind the shoulders. On the existing light frame, the cockpit liner is <strong>18 cm wider</strong> than the armoured shell that carries it.</p> </div> </header> <figure> <a class="plate" href="rear-cockpit.webp" aria-label="Open the full-size cockpit drawing"> <img src="rear-cockpit.webp" width="2200" height="1200" alt="Exploded rear view of a kneeling light frame. An amber-suited pilot leans over the controls. The liner measures 1.24 m across its outer walls. The separate winged core measures 1.06 m across its shell."> </a> <figcaption class="caption"> <span>The game draws the cockpit separately. Here the parts share one scale, with the near wall traced in outline.</span> <a href="rear-cockpit.webp">Open full size</a> </figcaption> </figure> Tue Nov 17 23:32:24 UTC 2026exec_commandtail -11 review/out/form-zero/build4.log && rg -n 'Traceback|Error' review/out/form-zero/build4.log | tail -4 && python - <<'PY'
command
tail -11 review/out/form-zero/build4.log && rg -n 'Traceback|Error' review/out/form-zero/build4.log | tail -4 && python - <<'PY' import json,struct f=open('public/assets/block_zero.glb','rb');f.seek(12);n,_=struct.unpack('II',f.read(8));g=json.loads(f.read(n)) print([x['name'] for x in g['nodes'] if x['name'].startswith(('canopy.hinge','mark_', 'crew.eye'))]) PY date -uresult, 17 lines
Script completed
Wall time 0.1 seconds
Output:
23:32:44 | INFO: Primitives created: 1
23:32:44 | INFO: Extracting primitive: side_slot21
23:32:44 | INFO: Primitives created: 1
23:32:44 | INFO: Extracting primitive: side_slot31
23:32:44 | INFO: Primitives created: 1
23:32:44 | INFO: Finished glTF 2.0 export in 1.0208346843719482 s

kit: block_zero -> ~/work/sortie/public/assets/block_zero.glb (3930 KB, 25.6s)
Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)

Blender quit
['mark_00', 'mark_LIFT', 'canopy.hinge', 'crew.eye', 'mark_ACCESS', 'mark_0.001', 'mark_0', 'mark_SVC']
Tue Nov 17 23:33:46 UTC 2026
exec_commandpython - <<'PY'
command
python - <<'PY' from pathlib import Path p=Path('kit/blocks/zero.py');s=p.read_text().replace(" f.skin('pauldron_rear_saddle'"," f.skin('recovery_stripe','shoulder.L',roof,.52,.92,33,53,'trim',skew=20,lift=.115,depth=.019)\n f.skin('pauldron_rear_saddle'") a=s.index(" empty('crew.eye'") s=s[:a]+''' for side in (-1,1): x=side*.46 f.plate('console_well'+str(side),'torso',[(x-.13,-1.14,13.81),(x+.13,-1.14,13.81), (x+.13,-1.01,14.04),(x-.13,-1.01,14.04)],(x,-1.07,13.94),(0,.08,-.04),'frame') f.plate('console_display'+str(side),'torso',[(x-.099,-1.145,13.86),(x+.099,-1.145,13.86), (x+.10,-1.04,14.00),(x-.10,-1.04,14.00)],(x,-1.10,13.94),(0,.022,0),'sensor') for j in range(3): cx=x-.078+j*.078 f.rail('screen_readout'+str(side)+str(j),'torso',(cx,-1.13,13.905),(cx,-1.10,13.945+j*.012),.008,'glow_eye') f.rail('tub_grab_handle'+str(side),'torso',(side*.53,-.96,13.62),(side*.54,-.88,13.92),.036,'trim') '''+s[a:] p.write_text(s) p=Path('review/form-zero/screen.js');s=p.read_text();a=s.index('applyDecals(zero, [');b=s.index('// Carry the actual',a);s=s[:a]+s[b:] s=s.replace("const dur=16","const hatch=rigs[0].node('canopy.hinge');\nif(!hatch)throw Error('Missing canopy pivot');\nconst dur=16") s=s.replace("rig.apply(flight?POSES.flight:POSES.stand);","rig.apply(flight?POSES.flight:POSES.stand);\n if(i===0)hatch.rotation.x=toRadians(-78*ease(Math.min(1,Math.max(0,(detail-.1)/.62))));") s=s.replace("160+12*Math.sin(t*1.15)","147+22*Math.sin(t*.76)").replace("const key=new","const key=new").replace("key.shadow.normalBias=.035;","key.shadow.radius=3.5;key.shadow.normalBias=.035;") s=s.replace("const floor=new THREE.Mesh(new THREE.PlaneGeometry(120,120),new THREE.ShadowMaterial({opacity:.22}));\nfloor.rotation.x=-Math.PI/2;floor.receiveShadow=true;scene.add(floor);","""// The marked inspection pad sets the feet against a known horizontal surface. const floor=new THREE.Group(); const pad=new THREE.Mesh(new THREE.CylinderGeometry(7.75,7.82,.14,96),new THREE.MeshStandardMaterial({color:0x6b797a,metalness:.28,roughness:.72})); pad.position.y=-.13;pad.receiveShadow=true;floor.add(pad); const markings=new THREE.Group(); for(let i=0;i<64;i++) { const a=i*Math.PI/32,r=7.49; const tick=new THREE.Mesh(new THREE.PlaneGeometry(i%8===0?.055:.032,i%8===0?.43:.19),new THREE.MeshBasicMaterial({color:i%8===0?0xc0b897:0x94a2a0})); tick.rotation.order='YXZ';tick.rotation.x=-Math.PI/2;tick.rotation.y=a; tick.position.set(Math.sin(a)*r,-.055,Math.cos(a)*r);markings.add(tick); } floor.add(markings); const deck=new THREE.Mesh(new THREE.PlaneGeometry(220,220),new THREE.ShadowMaterial({opacity:.16})); deck.rotation.x=-Math.PI/2;deck.position.y=-.205;deck.receiveShadow=true;floor.add(deck); scene.add(floor);""") s=s.replace("grad.addColorStop(0,'#b9c6c5');grad.addColorStop(.65,'#d4d8cf');grad.addColorStop(1,'#aab8b5');","grad.addColorStop(0,'#7d9093');grad.addColorStop(.62,'#bdc9c7');grad.addColorStop(1,'#99abaa');") p.write_text(s) PY /usr/bin/time -f '%e' -o review/out/form-zero/build5-time ~/.local/bin/blender -b -t 6 --python-exit-code 1 -P kit/build.py -- block_zero > review/out/form-zero/build5.log 2>&1 && node review/form-zero/capture.mjs review/out/form-zero/rev5 --proof > review/out/form-zero/proof5.log 2>&1result, 4 lines
Script completed Wall time 0.4 seconds Output: {"chunk_id":"d71e30","wall_time_seconds":0.251032195,"session_id":44372,"original_token_count":0,"output":""}exec_commandtail -5 review/out/form-zero/build5.log && cat review/out/form-zero/proof5.log 2>/dev/null && date -u && rg -n 'Boolean|CANNOT' review/out/form-zero/build5.log | head
command
tail -5 review/out/form-zero/build5.log && cat review/out/form-zero/proof5.log 2>/dev/null && date -u && rg -n 'Boolean|CANNOT' review/out/form-zero/build5.log | head
result, 15 lines
Script completed Wall time 0.1 seconds Output: kit: block_zero -> ~/work/sortie/public/assets/block_zero.glb (3964 KB, 31.6s) Blender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05) Blender quit { fps: 24, frames: 384, rigs: [ { joints: 22, nozzles: 4 }, { joints: 22, nozzles: 6 } ] } Tue Nov 17 23:35:29 UTC 2026view_image~/work/sortie/review/out/form-zero/rev5/proof-
input
const r=await Promise.allSettled(["00","04","08"].map(i=>tools.view_image({path:"~/work/sortie/review/out/form-zero/rev5/proof-"+i+".jpg"})));for(const x of r)if(x.value)image(x.value.image_url)result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
image_15.jpg 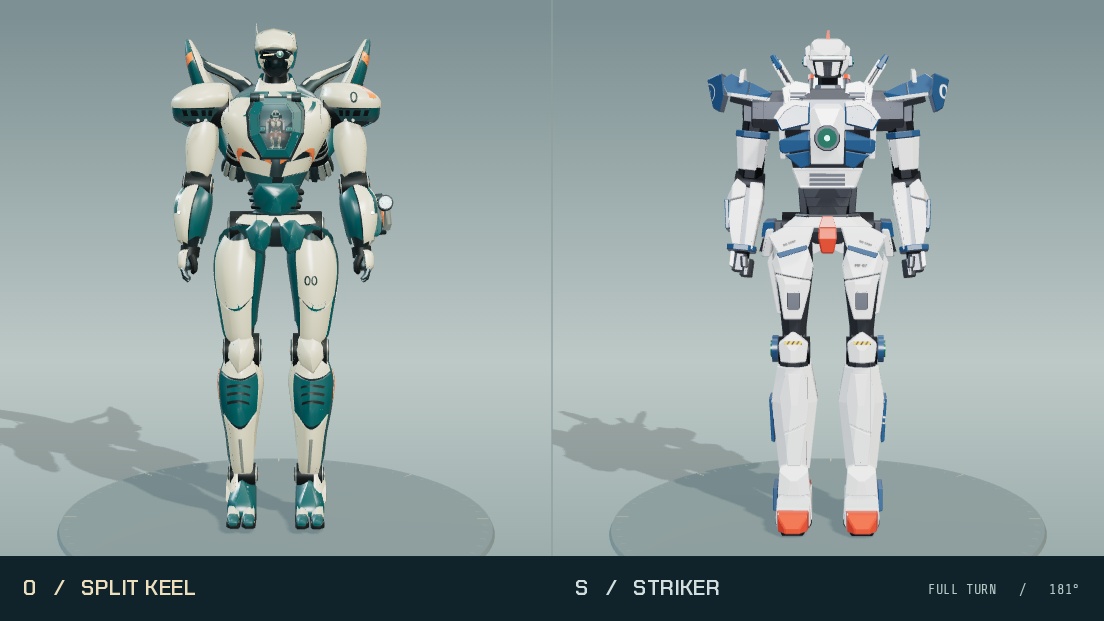
image_16.jpg view_image~/work/sortie/review/out/form-zero/rev5/proof-08.jpg
input
image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/rev5/proof-08.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
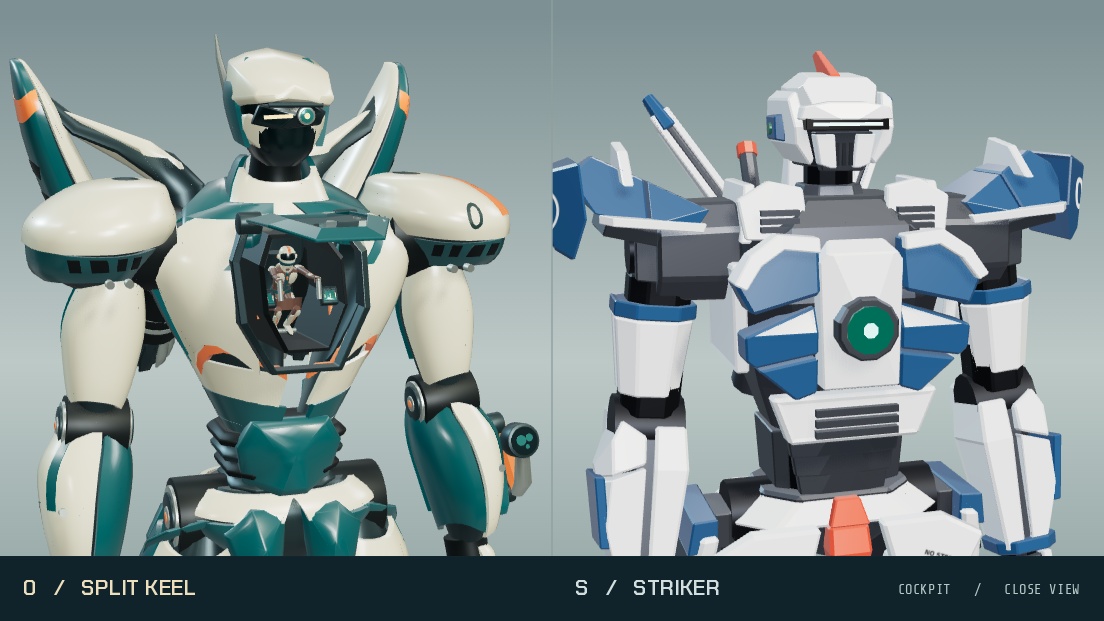
proof-08.jpg exec_commandcat > review/out/form-zero/plates.py <<'PY'
command
cat > review/out/form-zero/plates.py <<'PY' from pathlib import Path p=Path('kit/blocks/zero.py');s=p.read_text() s=s.replace('def panel(self, lo, hi, start, end, lift=0, skew=0, hem=0, cap=0, depth=.085):','def panel(self, lo, hi, start, end, lift=0, skew=0, hem=0, cap=0, depth=.085, lower=(), upper=()):') s=s.replace(' vs, fs = [], []\n for k in range(2):',''' def edge_value(contour,u): if not contour: return 0 for (a,h0),(b,h1) in zip(contour,contour[1:]): if u<=b: return h0+(h1-h0)*(u-a)/(b-a) return contour[-1][1] us=sorted({i/n for i in range(n+1)}|{u for u,h in (*lower,*upper)}) n=len(us)-1 vs, fs = [], [] for k in range(2):''') s=s.replace(' for i in range(n+1):\n u=i/n',' for u in us:').replace(' vs.append(self.point(t,start',' t+=(1-v)*edge_value(lower,u)+v*edge_value(upper,u)\n vs.append(self.point(t,start') s=s.replace(" p('breast_fairing',.34,.91,19,77,'main',skew=10,hem=.085,cap=.055,lift=.06)",""" seam=((0,.018),(.32,.025),(.45,-.036),(.72,-.040),(1,-.083)) p('breast_undershield',.34,.655,19,77,'main',skew=5,hem=.06,upper=seam,lift=.05) p('breast_fairing',.67,.91,24,82,'main',skew=5,lower=seam,cap=.045,lift=.095) p('breast_livery_blade',.69,.84,57,69,'accent',skew=12,lift=.114,depth=.021)""") s=s.replace(" p('chest_inlay',.65,.815,21,27,'accent',skew=22,lift=.077,depth=.015)","") s=s.replace(" f.skin('biceps_leaf','upperarm',upper,.07,.90,-67,99,'main',skew=-20,hem=.09,cap=.03)",""" seam=((0,.06),(.44,.045),(.55,-.01),(1,-.095)) f.skin('biceps_leaf','upperarm',upper,.35,.93,-67,89,'main',skew=-15,lower=seam,cap=.03,lift=.055) f.skin('brachial_cuff','upperarm',upper,.055,.33,-47,84,'accent',skew=-4,hem=.07,upper=seam,lift=.028) f.skin('biceps_actuator_cradle','upperarm',upper,.20,.77,80,132,'joint',skew=2,lift=.06) f.tube('elbow_extensor','upperarm',[(2.86,.24,12.14),(2.99,.24,12.59),(3.03,.24,13.19),(2.92,.24,13.62)], [.074,.093,.134,.103],'metal',12) f.tube('extensor_sleeve','upperarm',[(3.023,.245,12.99),(3.027,.24,13.26),(2.94,.24,13.55)], [.15,.17,.14],'frame',12) """) s=s.replace(" f.skin('forearm_outboard','forearm',vambrace,.075,.93,8,147,'main',skew=-15,cap=.04,hem=.075,lift=.06)",""" seam=((0,.07),(.32,.07),(.46,-.017),(.69,-.017),(1,-.065)) f.skin('bracer_cuff','forearm',vambrace,.055,.36,8,147,'main',skew=-4,upper=seam,hem=.03,lift=.052) f.skin('forearm_outboard','forearm',vambrace,.385,.93,4,143,'main',skew=-11,lower=seam,cap=.04,lift=.08)""") s=s.replace(" f.skin('quadriceps_lower'"," seam=((0,.062),(.23,.062),(.36,.008),(.64,.008),(.82,-.07),(1,-.07))\n f.skin('quadriceps_lower'").replace("hem=.055,cap=-.078,lift=.059","hem=.035,upper=seam,lift=.059").replace("hem=-.080,cap=-.048,lift=.096","lower=seam,cap=-.035,lift=.096") s=s.replace(" f.skin('thigh_ceramic_tip','thigh',thigh,.43,.469,-11,32,'accent',skew=3,cap=-.025,hem=-.025,lift=.083,depth=.025)",""" f.skin('thigh_lineage_flash','thigh.L',thigh,.62,.92,30,52,'accent',skew=13,lift=.119,depth=.02) for i in range(3): f.skin('thigh_register'+str(i),'thigh',thigh,.55+i*.028,.561+i*.028,-25,-12,'frame',lift=.119,depth=.02)""") s=s.replace(" f.skin('hamstring_guard','thigh',thigh,.20,.92,154,227,'main',skew=7,hem=.08,lift=.06)",""" f.skin('hamstring_upper','thigh',thigh,.608,.92,158,231,'main',skew=3, lower=((0,-.02),(.30,-.015),(.54,.058),(1,.060)),lift=.07) f.skin('hamstring_guard','thigh',thigh,.20,.585,154,227,'main',skew=4,hem=.08, upper=((0,-.02),(.30,-.015),(.54,.058),(1,.060)),lift=.052)""") s=s.replace(" for i in range(3):\n f.skin('thigh_vent'+str(i),'thigh',thigh,.39+i*.106,.42+i*.106,177,212,'frame',skew=4,lift=.078,depth=.029)",""" f.skin('hamstring_recess','thigh',thigh,.32,.54,174,205,'joint',skew=8,lift=.075,depth=.04) for i in range(4): f.skin('thigh_cooling_lip'+str(i),'thigh',thigh,.34+i*.046,.354+i*.046,177,204,'metal',skew=2,lift=.096,depth=.035)""") s=s.replace(" f.skin('greave_lower'"," scarf=((0,.036),(.29,.036),(.54,-.045),(.78,-.045),(1,-.008))\n f.skin('greave_lower'").replace("hem=.025,cap=-.068,lift=.075","hem=.025,upper=scarf,lift=.075").replace("hem=-.070,cap=-.047,lift=.105","lower=scarf,cap=-.047,lift=.105") s=s.replace("('shoulder','shoulder',2.50,-1.03,14.22),","") s=s.replace("roof,.52,.92,33,53,'trim',skew=20","roof,.51,.965,28,63,'trim',skew=24") a=s.index(" for i in range(3):\n f.rail('nape_grille") s=s[:a]+''' chin=[(-.36,16.17),(-.25,16.27),(.28,16.29),(.39,16.17),(.32,15.97), (.12,15.88),(-.19,15.89),(-.31,16.00)] f.put('scanner_lower_casting','head',prism(chin,-.79,-.30,'xz'),'accent',.055) for i in range(2): z=16.025+i*.075 f.put('scanner_drain'+str(i),'head',prism([(-.16,z),(.17,z+.02),(.15,z+.04),(-.16,z+.028)],-.803,-.78,'xz'),'joint') '''+s[a:] a=s.index(" empty('crew.eye'") s=s[:a]+''' # Bolt the seat and controls to a continuous cockpit floor; each grip has a # fixed support forward of the pilot and the footboards flank the centre console. f.put('crew_floor','torso',loft([(12.96,octo(1.43,1.70,.20,y=-.23)),(13.11,octo(1.43,1.70,.20,y=-.23))]),'frame',.04) f.tube('seat_suspension','torso',[(0,seat.y,13.06),seat+Vector((0,.02,-.16))],[.19,.15],'metal',12) for side in (-1,1): k='L' if side>0 else 'R' g=pts['grip.'+k] boot=g+Vector((0,-.06,-.28)) f.tube('console_pedestal'+k,'torso',[(side*.42,-.67,13.06),boot], [.11,.09],'frame',8) peg=pts['peg.'+k] f.tube('footboard_mount'+k,'torso',[(peg.x,peg.y+.06,13.06),peg+Vector((0,0,-.04))],[.08,.08],'joint',10) f.put('seat_armoured_back','torso',loft([(13.12,octo(.60,.16,.055,y=.32)), (14.03,octo(.66,.19,.07,y=.32)),(14.48,octo(.52,.18,.065,y=.22))]),'suit',.045) '''+s[a:] p.write_text(s) PY python review/out/form-zero/plates.py /usr/bin/time -f '%e' -o review/out/form-zero/build6-time ~/.local/bin/blender -b -t 7 --python-exit-code 1 -P kit/build.py -- block_zero > review/out/form-zero/build6.log 2>&1 && node review/form-zero/capture.mjs review/out/form-zero/studio --export > review/out/form-zero/export6.log 2>&1result, 4 lines
Script completed
Wall time 0.4 seconds
Output:
{"chunk_id":"2348de","wall_time_seconds":0.250555359,"session_id":20474,"original_token_count":0,"output":""}
agent
+54:110 now has a seated pilot, a working canopy hinge and a folded inspection camera on its left forearm. The full turn is in the game renderer. I’m adding a close shot of the canopy opening and checking its sweep against the pilot and head so the cockpit can be judged in motion.
exec_commandpython - <<'PY'
command
python - <<'PY' from pathlib import Path p=Path('review/form-zero/studio.py');s=p.read_text() s=s.replace("parser.add_argument('--samples',type=int,default=10)","parser.add_argument('--samples',type=int,default=10)") a=s.index('cam=bpy.data.objects.new') s=s[:a]+'''# A large, dim wall behind both models keeps the attention on the moving hatch. bpy.ops.mesh.primitive_plane_add(size=180,location=(0,10,12),rotation=(math.pi/2,0,0)) wall=bpy.context.object wall.name='Studio wall' wall_mat=bpy.data.materials.new('Deep petrol') wall_mat.diffuse_color=(.024,.046,.050,1) wall.data.materials.append(wall_mat) hinge=next(o for o in roots[0].children_recursive if o.name.startswith('canopyhinge')) hinge.rotation_mode='XYZ' '''+s[a:] s=s.replace(" turn=i<204"," turn=i<204\n wall.hide_render=turn\n deck.hide_render=not turn") s=s.replace(" yaw=35-60*smooth\n aim=14.24\n width=17.9\n pitch=10",""" yaw=27-42*smooth aim=14.12 width=17.3 pitch=8 travel=max(0,min(1,(u-.12)/.59)) hinge.rotation_euler.x=math.radians(-78*travel*travel*(3-2*travel))""") s=s.replace("frames=(20,106,241) if args.proof","frames=(206,246,283) if args.proof") p.write_text(s) PY ls -l review/out/form-zero/studio && tail -4 review/out/form-zero/build6.log && date -uresult, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"383d67","wall_time_seconds":0.000006751,"exit_code":0,"original_token_count":85,"output":"total 4772\n-rw------- 1 runner runner 1067124 Nov 17 23:27 striker-paint.glb\n-rw------- 1 runner runner 3816584 Nov 17 23:27 zero-paint.glb\nkit: block_zero -> ~/work/sortie/public/assets/block_zero.glb (4103 KB, 23.7s)\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\nTue Nov 17 23:38:40 UTC 2026\n"}exec_commandpython - <<'PY'
command
python - <<'PY' import struct,json from pathlib import Path for f in Path('review/out/form-zero/studio').glob('*.glb'): with f.open('rb') as fp: fp.seek(12);n,t=struct.unpack('II',fp.read(8));g=json.loads(fp.read(n)) print(f.name,[x.get('name') for x in g['materials']][:26],len(g.get('images',[])),[o['name'] for o in g['nodes'] if 'canopyhinge' in o.get('name','')]) PY cat review/out/form-zero/export6.log && date -uresult, 12 lines
Script completed Wall time 0.1 seconds Output: zero-paint.glb ['frame', 'trim', 'zero.ink', 'glow_thruster', 'joint', 'metal', 'main', 'accent', 'stencil', 'canopy.glass', 'sensor', 'glow_eye', 'visor', 'suit'] 0 ['canopyhinge', 'canopyhinge:metal'] striker-paint.glb ['joint', 'glow_thruster', 'accent', 'main', 'trim', 'sensor', 'frame', None, None, None, None, None, 'glow_core', None, 'glow_eye', 'visor', None, None, None, None] 8 [] { fps: 24, frames: 384, rigs: [ { joints: 22, nozzles: 4 }, { joints: 22, nozzles: 6 } ] } Tue Nov 17 23:38:52 UTC 2026exec_command~/.local/bin/blender -b -t 5 --python-exit-code 1 -P review/form-zero/studio.py -- review/out/form-zero/studio review/out/form-zero/final-close-proof --proof --samples 7 > review/out/form-zero/close-proof.log 2>&1 (+1 more)
command
~/.local/bin/blender -b -t 5 --python-exit-code 1 -P review/form-zero/studio.py -- review/out/form-zero/studio review/out/form-zero/final-close-proof --proof --samples 7 > review/out/form-zero/close-proof.log 2>&1

node review/form-zero/capture.mjs review/out/form-zero/final-proof --proof > review/out/form-zero/final-proof.log 2>&1
result, 4 lines
Script completed Wall time 0.4 seconds Output: {"chunk_id":"21201b","wall_time_seconds":0.250436358,"session_id":42627,"original_token_count":0,"output":""}{"chunk_id":"989ca1","wall_time_seconds":0.251594779,"session_id":91201,"original_token_count":0,"output":""}exec_commandcat > review/out/form-zero/clearance.py <<'PY'
command
cat > review/out/form-zero/clearance.py <<'PY' from pathlib import Path import math import bpy from mathutils import Vector from mathutils.bvhtree import BVHTree bpy.ops.wm.read_factory_settings(use_empty=True) bpy.ops.import_scene.gltf(filepath=str(Path('public/assets/block_zero.glb').resolve())) obj=bpy.data.objects hinge=obj['canopy.hinge'] hinge.rotation_mode='XYZ' def bvh(o): me=o.data return BVHTree.FromPolygons([[redacted: email] for v in me.vertices],[p.vertices[:] for p in me.polygons]) crew=[o for o in obj if o.type=='MESH' and o.name.startswith('crew_') and o.name!='crew_floor'] head=[o for o in obj['head'].children_recursive if o.type=='MESH'] fixed=[(o.name,bvh(o)) for o in crew+head] collisions=[] for angle in range(0,79,3): hinge.rotation_euler.x=-math.radians(angle) bpy.context.view_layer.update() for o in hinge.children_recursive: if o.type!='MESH':continue m=bvh(o) for name,volume in fixed: if m.overlap(volume):collisions.append((angle,o.name,name)) print('CLEARANCE',len(crew),len(head),27,'samples.',collisions[:20],len(collisions),'intersections') PY ~/.local/bin/blender -b -t 2 --python-exit-code 1 -P review/out/form-zero/clearance.py > review/out/form-zero/clearance.log 2>&1 && rg CLEARANCE review/out/form-zero/clearance.log python - <<'PY' import json,struct,math from pathlib import Path def get(name): with Path('public/assets',name+'.glb').open('rb') as f: f.seek(12);n,t=struct.unpack('II',f.read(8)); doc=json.loads(f.read(n)) o={i['name']:i for i in doc['nodes']};return o a,b=get('block_zero'),get('striker') names=['pelvis','waist','torso','neck','head','backpack']+[x+'.'+s for x in ['shoulder','upperarm','forearm','hand','thigh','shin','foot','binder'] for s in ['L','R']] print('Max joint translation difference (metres)',max(math.dist(a[k]['translation'],b[k]['translation']) for k in names)) PYresult, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"6b9334","wall_time_seconds":0.259725793,"session_id":7567,"original_token_count":0,"output":""}exec_commandrg 'CLEARANCE|Traceback' review/out/form-zero/clearance.log && ls -l review/out/form-zero/final-close-proof && cat review/out/form-zero/final-proof.log && tail -4 review/out/form-zero/close-proof.log && date -u
command
rg 'CLEARANCE|Traceback' review/out/form-zero/clearance.log && ls -l review/out/form-zero/final-close-proof && cat review/out/form-zero/final-proof.log && tail -4 review/out/form-zero/close-proof.log && date -u
result, 18 lines
Script completed Wall time 0.1 seconds Output: CLEARANCE 47 24 27 samples. [] 0 intersections total 236 -rw------- 1 runner runner 118568 Nov 17 23:39 0206.jpg -rw------- 1 runner runner 120962 Nov 17 23:39 0246.jpg { fps: 24, frames: 384, rigs: [ { joints: 22, nozzles: 4 }, { joints: 22, nozzles: 6 } ] } ~/work/sortie/review/form-zero/studio.py:75: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0 world.use_nodes=True 00:15.126 render | Saved: '~/work/sortie/review/out/form-zero/final-close-proof/0206.jpg' 00:30.275 render | Saved: '~/work/sortie/review/out/form-zero/final-close-proof/0246.jpg' Tue Nov 17 23:39:38 UTC 2026view_image~/work/sortie/review/out/form-zero/final-close-proof/0246.jpg (+1 more)
input
const r=await Promise.allSettled([tools.view_image({path:"~/work/sortie/review/out/form-zero/final-close-proof/0246.jpg"}),tools.view_image({path:"~/work/sortie/review/out/form-zero/final-proof/proof-07.jpg"})]);for(const x of r)if(x.value)image(x.value.image_url)result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
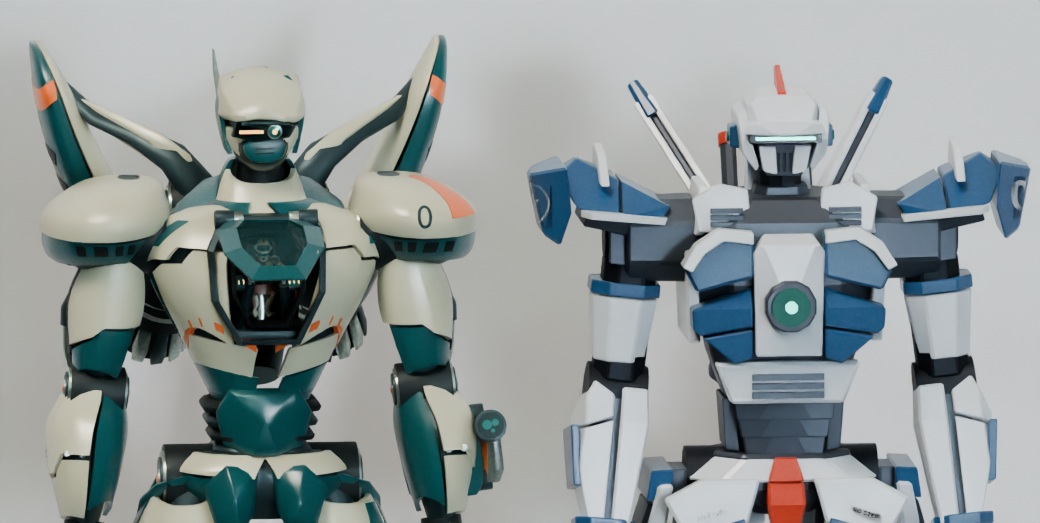
0246.jpg 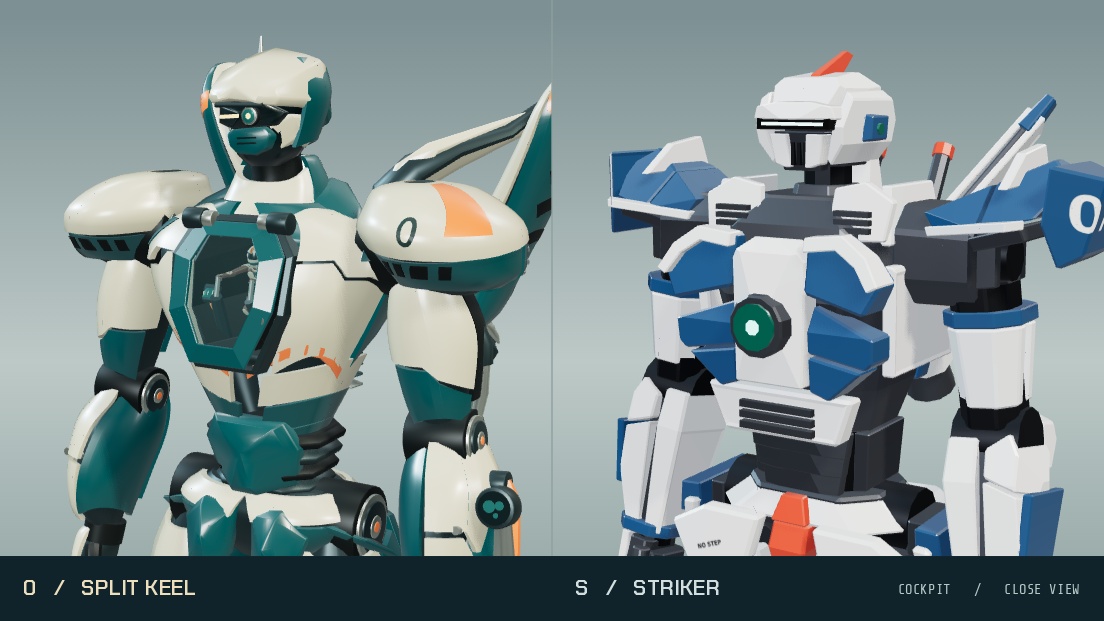
proof-07.jpg view_image~/work/sortie/review/out/form-zero/final-close-proof/0283.jpg
input
image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/final-close-proof/0283.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
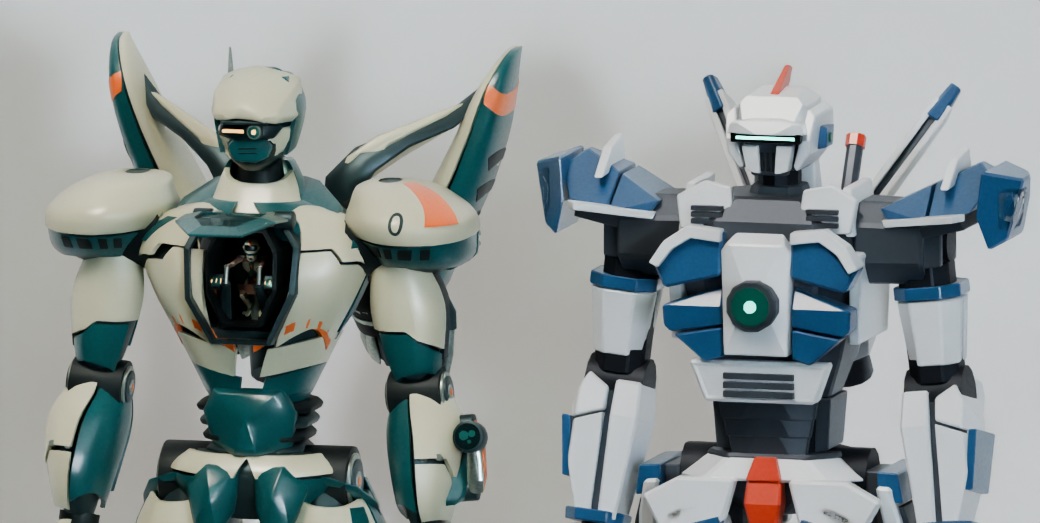
0283.jpg exec_commandpython - <<'PY'
command
python - <<'PY' from pathlib import Path p=Path('kit/blocks/zero.py');s=p.read_text() s=s.replace(" p('pectoralis_border',.32,.35,4,75,'trim',hem=.083,cap=.081,lift=.05)"," p('service_release',.46,.51,61,74,'trim',skew=3,lift=.078,depth=.025)") s=s.replace(" seat=pts['seat']",""" from lib import material for part in f.j['torso'].children: if part.name.startswith('crew_') and part.type=='MESH': original=part.data.materials[0].name if original in ('suit','accent','trim','main'): part.data.materials[0]=material('crew.'+original) seat=pts['seat']""") s=s.replace(" empty('crew.eye',eye_target,f.j['torso'],seat='reclined')",""" f.rail('cabin_light_bar','torso',(-.24,-.84,14.81),(.24,-.84,14.81),.026,'glow_eye') empty('crew.lamp',(0,-.93,14.66),f.j['torso']) empty('crew.eye',eye_target,f.j['torso'],seat='reclined')""") p.write_text(s) p=Path('kit/blocks/zero-paint.json');s=p.read_text().replace(' "zero.ink"',''' "crew.main": {"color":"#eee3c8","rough":0.45}, "crew.suit": {"color":"#b55f32","rough":0.64}, "crew.accent": {"color":"#4b4540","rough":0.54}, "crew.trim": {"color":"#ea9355","rough":0.53}, "zero.ink"''');p.write_text(s) p=Path('review/form-zero/screen.js');s=p.read_text().replace("const rigs=[new MechRig(zero),new MechRig(striker)];","""const rigs=[new MechRig(zero),new MechRig(striker)]; const cabinLamp=new THREE.PointLight(0xffecce,2.1,2,2); rigs[0].node('crew.lamp').add(cabinLamp);""") p.write_text(s) p=Path('review/form-zero/studio.py');s=p.read_text().replace("wall_mat.diffuse_color=(.024,.046,.050,1)","""wall_mat.use_nodes=True back_shader=wall_mat.node_tree.nodes.get('Principled BSDF') back_shader.inputs['Base Color'].default_value=(.033,.058,.061,1) back_shader.inputs['Roughness'].default_value=.94""") s=s.replace("deck.data.materials.append(floor)","""floor.use_nodes=True floor.node_tree.nodes.get('Principled BSDF').inputs['Base Color'].default_value=(.14,.18,.19,1) deck.data.materials.append(floor)""") s=s.replace("hinge.rotation_mode='XYZ'","""hinge.rotation_mode='XYZ' marker=next(o for o in roots[0].children_recursive if o.name.startswith('crewlamp')) lamp=bpy.data.lights.new('Cockpit practical','POINT') lamp.energy=10 lamp.color=(1,.83,.62) lamp.shadow_soft_size=.095 light=bpy.data.objects.new('Cockpit practical',lamp) scene.collection.objects.link(light) light.parent=marker""") s=s.replace(' yaw=27-42*smooth',' yaw=-14').replace(' travel=max(0,min(1,(u-.12)/.59))',' travel=max(0,min(1,(i-216)/43))') s=s.replace("frames=(206,246,283) if args.proof else range(args.start,args.end+1)","frames=(216,238,259) if args.proof else range(args.start,args.end+1)") p.write_text(s) PY /usr/bin/time -f '%e' -o review/out/form-zero/build7-time ~/.local/bin/blender -b -t 7 --python-exit-code 1 -P kit/build.py -- block_zero > review/out/form-zero/build7.log 2>&1 && node review/form-zero/capture.mjs review/out/form-zero/studio --export > review/out/form-zero/export7.log 2>&1 && ~/.local/bin/blender -b -t 7 --python-exit-code 1 -P review/form-zero/studio.py -- review/out/form-zero/studio review/out/form-zero/lit-proof --proof --samples 7 > review/out/form-zero/lit-proof.log 2>&1result, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"b4fabc","wall_time_seconds":0.250910477,"session_id":8441,"original_token_count":0,"output":""}exec_commandls review/out/form-zero/lit-proof 2>/dev/null && tail -8 review/out/form-zero/lit-proof.log && cat review/out/form-zero/export7.log && date -u
command
ls review/out/form-zero/lit-proof 2>/dev/null && tail -8 review/out/form-zero/lit-proof.log && cat review/out/form-zero/export7.log && date -u
result, 19 lines
Script completed
Wall time 0.2 seconds
Output:
0216.jpg
23:41:44 | INFO: glTF import finished in 0.49s
~/work/sortie/review/form-zero/studio.py:72: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0
  floor.use_nodes=True
~/work/sortie/review/form-zero/studio.py:77: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0
  world.use_nodes=True
~/work/sortie/review/form-zero/studio.py:102: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0
  wall_mat.use_nodes=True
00:20.595  render           | Saved: '~/work/sortie/review/out/form-zero/lit-proof/0216.jpg'
{
  fps: 24,
  frames: 384,
  rigs: [ { joints: 22, nozzles: 4 }, { joints: 22, nozzles: 6 } ]
}
Tue Nov 17 23:42:04 UTC 2026