A mech game prototype, pushed by GPT-6.2-Astra
agent
+1:03:44You can judge the rear silhouette now. In boost, the two openings still show sky and the jets spread far enough apart to leave the rear hatch visible. The motion check also found clearance between the opening canopy, the pilot and the head at every 3° step. Open the matched boost frame
exec_commandcat > review/form-zero/make-film.sh <<'SH'
command
cat > review/form-zero/make-film.sh <<'SH' #!/usr/bin/env bash # Run from the repo root. All intermediates stay in the ignored review directory. set -euo pipefail scratch=review/out/form-zero destination=\${1:-review/rear-cockpit/frame-zero} blender=\${BLENDER:-"$HOME/.local/bin/blender"} mkdir -p "$scratch/tmp" export TMPDIR="$PWD/$scratch/tmp" timing_file="$scratch/rebuild-times.txt" : > "$timing_file" timed() { local stage="$1" shift /usr/bin/time --append --output="$timing_file" --format="$stage %e s" "$@" } timed model "$blender" -b -t 7 --python-exit-code 1 -P kit/build.py -- block_zero timed paint node review/form-zero/capture.mjs "$scratch/studio" --export timed game node review/form-zero/capture.mjs "$scratch/game" --game timed studio "$blender" -b -t 7 --python-exit-code 1 -P review/form-zero/studio.py -- "$scratch/studio" "$scratch/finish-frames" --start 216 --end 259 --samples 8 timed film python3 review/form-zero/assemble.py "$scratch" "$destination" cat "$timing_file" SH bash -n review/form-zero/make-film.sh node --check review/form-zero/capture.mjs && node --check review/form-zero/screen.js python3 - <<'PY' import ast from pathlib import Path for p in ('kit/blocks/zero.py','review/form-zero/assemble.py','review/form-zero/studio.py'): ast.parse(Path(p).read_text()) PY ls -1 review/out/form-zero/game | tail -1; tail -1 review/out/form-zero/finish.log; date -uresult, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"44fdc4","wall_time_seconds":0.258668128,"exit_code":0,"original_token_count":37,"output":"0051.jpg\n03:36.059 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0223.jpg'\nTue Nov 17 23:48:13 UTC 2026\n"}exec_commandcat > review/out/form-zero/check-page.mjs <<'NODE'
command
cat > review/out/form-zero/check-page.mjs <<'NODE' import { chromium } from 'playwright'; import assert from 'node:assert/strict'; import path from 'node:path'; import { pathToFileURL } from 'node:url'; import { readFile } from 'node:fs/promises'; const file=path.resolve(process.argv[2]); const scratch=path.resolve('review/out/form-zero'); const browser=await chromium.launch({headless:true, downloadsPath:path.join(scratch,'tmp')}); try { for (const [name,width,height] of [['desktop',1440,960],['phone',390,844]]) { const p=await browser.newPage({viewport:{width,height},acceptDownloads:true}); const errors=[]; p.on('pageerror',e=>errors.push(e.message)); p.on('console',m=>{ if(m.type()==='error')errors.push(m.text()); }); await p.goto(pathToFileURL(file).href+'#frame-zero'); await p.waitForFunction('document.querySelector("video").readyState >= 1'); assert.deepEqual(await p.locator('h1').allTextContents(),['Room for the pilot']); assert.equal(await p.locator('img').evaluate(el=>el.complete && el.naturalWidth===2200),true); assert.equal(await p.evaluate('document.documentElement.scrollWidth <= innerWidth'),true); assert.equal(await p.locator('video').evaluate(v=>v.duration),16); assert.equal(await p.locator('video').evaluate(v=>v.videoWidth),1600); await p.screenshot({path:path.join(scratch,'page-'+name+'.jpg'),quality:90}); for (const time of [4,12.5,0]) { await p.locator('button[data-time="'+time+'"]').click(); await p.waitForFunction(t=>{ const v=document.querySelector('video'); return !v.paused && !v.seeking && v.currentTime>=t && v.currentTime<t+1.8; },time,{timeout:8000}); await p.locator('video').evaluate(v=>v.pause()); } const [download]=await Promise.all([p.waitForEvent('download'),p.locator('a[download]').click()]); assert.equal(download.suggestedFilename(),'frame-zero.glb'); const raw=await readFile(await download.path()); assert.equal(raw.readUInt32LE(8),raw.byteLength); assert.equal(raw.toString('ascii',0,4),'glTF'); assert.deepEqual(raw,await readFile('public/assets/block_zero.glb')); assert.deepEqual(errors,[]); console.log(name,width,height,'offline playback, three chapter seeks, download, original drawing, no overflow'); await p.close(); } } finally { await browser.close(); } NODE date -u; tail -1 review/out/form-zero/finish.log; du -sh review/out/form-zero/gameresult, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"263120","wall_time_seconds":0.000007131,"exit_code":0,"original_token_count":42,"output":"Tue Nov 17 23:48:37 UTC 2026\n03:36.059 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0223.jpg'\n15M\treview/out/form-zero/game\n"}exec_commandsed -n '1,180p' kit/block.py && sed -n '1,165p' kit/blocks/dummy.py && rg -n 'def rig|def node|J_POS|SKELETON|JOINTS' kit/mech.py && rg -n 'def build|class Blocks' kit/block.py
command
sed -n '1,180p' kit/block.py && sed -n '1,165p' kit/blocks/dummy.py && rg -n 'def rig|def node|J_POS|SKELETON|JOINTS' kit/mech.py && rg -n 'def build|class Blocks' kit/block.py
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"97fa21","wall_time_seconds":0.0000052,"exit_code":1,"original_token_count":1525,"output":"Warning: truncated output (original token count: 1525)\nTotal output lines: 121\n\n\"\"\"Block models: plain boxes on the 22 joint rig, for judging mass and motion before any plate exists.\n\nA block model is one file, kit/blocks/<name>.py, with a build() that takes this module's Blocks class.\nIt builds in seconds, into a gitignored public/assets/block_<name>.glb:\n\n npm run kit -- block_dummy\n npm run clip -- block_dummy\n\nGeometry is authored in world rest pose coordinates in metres, models facing -Y, Z up, left is +X, as\nin the rest of the kit. Roles are the usual ones (main, accent, frame, joint). Nothing here is a design\nrule: no maker, frame or grade carries over unless a block file asks for it.\n\"\"\"\nimport importlib\n\nimport bpy\nfrom mathutils import Vector\n\nfrom lib import loft, merge, mirror_x, octo, solid\nfrom mech import joints as striker_joints, nozzle_pair, pair\n\nSIDED = {\"shoulder\", \"upperarm\", \"forearm\", \"hand\", \"grip\", \"thigh\", \"shin\", \"foot\", \"binder\"}\nBEVEL = .03\n\n\nclass Blocks:\n \"\"\"The rig plus block primitives. `joints` overrides rest positions: {\"thigh\": (1.1, 0, 9.5)} moves\n both thighs (give the left, +X, the right mirrors), {\"pelvis\": (0, 0, 9.8)} moves one node. Other\n joints stay where the striker has them, in world coordinates, so moving one moves nothing else.\"\"\"\n\n def __init__(self, joints=None, height=17.6):\n J = striker_joints()\n self.nodes = {o.name: o for o in J.values()}\n self.n = 0\n J[\"frame\"][\"frame\"] = \"block\"\n J[\"frame\"][\"height\"] = height\n place = {name: o.matrix_world.translation.copy() for name, o in self.nodes.items()}\n for key, at in (joints or {}).items():\n if key in SIDED:\n place[f\"{key}.L\"] = Vector(at)\n place[f\"{key}.R\"] = Vector((-at[0], at[1], at[2]))\n elif key in place:\n place[key] = Vector(at)\n else:\n raise KeyError(f\"block: no joint {key}\")\n for name, o in self.nodes.items(): # striker_joints() makes parents first\n if o.parent is not None:\n o.location = o.parent.matrix_world.inverted() @ place[name]\n bpy.context.view_layer.update()\n\n def at(self, name):\n return self.nodes[name].matrix_world.translation.copy()\n\n def _put(self, joint, bm, role, mirror):\n self.n += 1\n name = f\"block{self.n}_{joint}\"\n if joint in SIDED:\n pair(name, bm, role, self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"], bevel=BEVEL, panels=False)\n elif mirror:\n solid(name, merge(bm, mirror_x(bm)), role, self.nodes[joint], bevel=BEVEL, panels=False)\n else:\n solid(name, bm, role, self.nodes[joint], bevel=BEVEL, panels=False)\n\n def box(self, joint, x, y, z, role=\"main\", mirror=False):\n \"\"\"A box from x, y, z ranges (lo, hi). A sided joint (thigh, shin, ...) takes the left's numbers\n and mirrors to the right. `mirror` does the same for a box on a centre joint.\"\"\"\n r = [(x[0], y[0]), (x[1], y[0]), (x[1], y[1]), (x[0], …25 tokens truncated…joint, rings, role=\"main\", mirror=False, chamfer=.15):\n \"\"\"A lofted block through rings (z, width, depth, x, y), bottom to top.\"\"\"\n self._put(joint, loft([(z, octo(w, d, chamfer, x=x, y=y)) for z, w, d, x, y in rings]), role, mirror)\n\n def bone(self, joint, a, b, w, d, role=\"main\", chamfer=.1):\n \"\"\"A block from joint a to joint b, both named for the left side: bone(\"thigh\", \"thigh.L\", \"shin.L\", 1, 1).\"\"\"\n pa, pb = self.at(a), self.at(b)\n lo, hi = (pa, pb) if pa.z < pb.z else (pb, pa)\n self.taper(joint, [(lo.z, w, d, lo.x, lo.y), (hi.z, w, d, hi.x, hi.y)], role, chamfer=chamfer)\n\n def nozzles(self, joint, at, direction, r=.45, length=.9, kind=\"main\"):\n \"\"\"A nozzle pair that fires plumes in the game. `kind`: main, binder or calf.\"\"\"\n if joint in SIDED:\n jl, jr = self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"]\n else:\n jl = jr = self.nodes[joint]\n nozzle_pair(kind, at, direction, r, length, jl, jr, housing=False)\n\n def mannequin(self):\n \"\"\"A neutral box on every bone, sized from the joints alone. For testing tools, not a design.\"\"\"\n for joint, a, b, w, d in ((\"thigh\", \"thigh.L\", \"shin.L\", 1.0, 1.0), (\"shin\", \"shin.L\", \"foot.L\", 1.0, 1.0),\n (\"upperarm\", \"upperarm.L\", \"forearm.L\", .7, .7), (\"forearm\", \"forearm.L\", \"hand.L\", .7, .7)):\n self.bone(joint, a, b, w, d)\n foot = self.at(\"foot.L\")\n self.box(\"foot\", (foot.x - .5, foot.x + .5), (foot.y - 1.2, foot.y + .6), (0, foot.z))\n hand = self.at(\"hand.L\")\n self.box(\"hand\", (hand.x - .3, hand.x + .3), (hand.y - .3, hand.y + .3), (hand.z - .8, hand.z))\n pelvis, torso, neck, head = self.at(\"pelvis\"), self.at(\"torso\"), self.at(\"neck\"), self.at(\"head\")\n self.box(\"pelvis\", (-1.3, 1.3), (-.8, .8), (pelvis.z - .8, pelvis.z + .4))\n self.box(\"waist\", (-.8, .8), (-.6, .6), (pelvis.z + .4, torso.z))\n shoulder = self.at(\"shoulder.L\")\n self.box(\"torso\", (-shoulder.x, shoulder.x), (-1, 1), (torso.z, neck.z))\n self.box(\"shoulder\", (shoulder.x, shoulder.x + .9), (-.6, .6), (shoulder.z - .6, shoulder.z + .4))\n self.box(\"neck\", (-.3, .3), (-.3, .3), (neck.z, head.z))\n self.box(\"head\", (-.5, .5), (-.6, .6), (head.z, head.z + 1.1))\n pack = self.at(\"backpack\")\n self.box(\"backpack\", (-.9, .9), (pack.y - .5, pack.y + .5), (pack.z - 1, pack.z + 1))\n\n\ndef build_block(name):\n \"\"\"block_<name> from kit/blocks/<name>.py.\"\"\"\n module = importlib.import_module(f\"blocks.{name.removeprefix('block_')}\")\n importlib.reload(module)\n module.build(Blocks)\n\"\"\"Test fixture for the block tools: an automatic box on every bone, sized from the default joints.\nNot a design. Delete nothing here, copy it to start a real block file.\"\"\"\n\n\ndef build(Blocks):\n b = Blocks()\n b.mannequin()\n pack = b.at(\"backpack\")\n b.nozzles(\"backpack\", (.5, pack.y + .4, pack.z - .9), (0, .45, -.9))\n"}exec_commandcat > review/form-zero/check-hatch.py <<'PY'
command
cat > review/form-zero/check-hatch.py <<'PY' """Check the exported hatch against the posed pilot and the head throughout its travel.""" import math from pathlib import Path import bpy from mathutils.bvhtree import BVHTree def surface(obj): vertices = [obj.matrix_world @ vertex.co for vertex in obj.data.vertices] faces = [face.vertices[:] for face in obj.data.polygons] return BVHTree.FromPolygons(vertices, faces) bpy.ops.wm.read_factory_settings(use_empty=True) bpy.ops.import_scene.gltf(filepath=str(Path('public/assets/block_zero.glb').resolve())) objects = bpy.data.objects hatch = objects['canopy.hinge'] hatch.rotation_mode = 'XYZ' moving = [obj for obj in hatch.children_recursive if obj.type == 'MESH'] crew = [obj for obj in objects if obj.type == 'MESH' and obj.name.startswith('crew_') and obj.name != 'crew_floor'] head = [obj for obj in objects['head'].children_recursive if obj.type == 'MESH'] if not all((moving, crew, head)): raise ValueError('Missing hatch, pilot or head geometry') fixed = [(obj.name, surface(obj)) for obj in crew + head] for angle in range(0, 79, 3): hatch.rotation_euler.x = -math.radians(angle) bpy.context.view_layer.update() for obj in moving: shell = surface(obj) for name, other in fixed: if shell.overlap(other): raise ValueError(f'{angle} degrees: {obj.name} intersects {name}') print(f'Hatch clears {len(crew)} pilot meshes and {len(head)} head meshes in all 27 sampled positions.') PY sed -i '/^timed model /a timed clearance "$blender" -b -t 2 --python-exit-code 1 -P review/form-zero/check-hatch.py' review/form-zero/make-film.sh ~/.local/bin/blender -b -t 1 --python-exit-code 1 -P review/form-zero/check-hatch.py > review/out/form-zero/verified-hatch.log 2>&1result, 4 lines
Script completed Wall time 0.5 seconds Output: {"chunk_id":"f18097","wall_time_seconds":0.252601503,"session_id":8719,"original_token_count":0,"output":""}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path from shutil import copyfile from PIL import Image w=Path('review/out/form-zero') mock=w/'layout' mock.mkdir(exist_ok=True) (mock/'frame-zero').mkdir(exist_ok=True) for src,dest in [(Path('review/rear-cockpit/index.html'),'index.html'),(Path('review/rear-cockpit/rear-cockpit.webp'),'rear-cockpit.webp'),(w/'game/0032.jpg','frame-zero/zero-flight.jpg'),(w/'test.mp4','frame-zero/zero-and-striker.mp4')]: copyfile(src,mock/dest) PY node --input-type=module <<'NODE' import {chromium} from 'playwright'; import {pathToFileURL} from 'node:url'; import {resolve} from 'node:path'; const b=await chromium.launch({headless:true}); try { for(const [name,w,h] of [['desktop',1440,960],['phone',390,844]]) { const p=await b.newPage({viewport:{width:w,height:h}}); await p.goto(pathToFileURL(resolve('review/out/form-zero/layout/index.html')).href+'#frame-zero'); await p.screenshot({path:'review/out/form-zero/layout/'+name+'.jpg',quality:90}); console.log(await p.evaluate(()=>[innerWidth,document.documentElement.scrollWidth,document.querySelector('.film').getBoundingClientRect().width])); } } finally {await b.close();} NODE python3 - <<'PY' from PIL import Image im=Image.open('review/out/form-zero/layout/desktop.jpg');im.thumbnail((750,550));im.save('review/out/form-zero/layout/small-desktop.jpg') PYresult, 4 lines
Script completed
Wall time 0.5 seconds
Output:
{"chunk_id":"84c310","wall_time_seconds":0.255554452,"session_id":95033,"original_token_count":0,"output":""}
write_stdin, exec_commandpoll session 95033 (+1 more)
input
await Promise.allSettled([tools.write_stdin({session_id:95033,chars:"",yield_time_ms:100,max_output_tokens:250}),tools.exec_command({cmd:"tail -2 review/out/form-zero/verified-hatch.log; tail -1 review/out/form-zero/finish.log; ls review/out/form-zero/game | tail -1; date -u; git diff --stat; ls -a review/form-zero"})]).then(r=>r.forEach(x=>text(x.value)))result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"48f1a2","wall_time_seconds":0.000003031,"exit_code":0,"original_token_count":11,"output":"[ 1440, 1440, 1292.8125 ]\n[ 390, 390, 358 ]\n"}{"chunk_id":"24c5ef","wall_time_seconds":0.00000764,"exit_code":0,"original_token_count":95,"output":"\nBlender quit\n04:59.386 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0226.jpg'\n0077.jpg\nTue Nov 17 23:49:35 UTC 2026\n review/rear-cockpit/index.html | 88 ++++++++++++++++++++++++++++++++++++++++--\n 1 file changed, 85 insertions(+), 3 deletions(-)\n.\n..\nassemble.py\ncapture.mjs\ncheck-hatch.py\nmake-film.sh\nscreen.html\nscreen.js\nstudio.py\n"}view_image~/work/sortie/review/out/form-zero/layout/
input
const rs=await Promise.allSettled(["small-desktop","phone"].map(n=>tools.view_image({path:"~/work/sortie/review/out/form-zero/layout/"+n+".jpg"})));rs.forEach(r=>image(r.value.image_url))result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
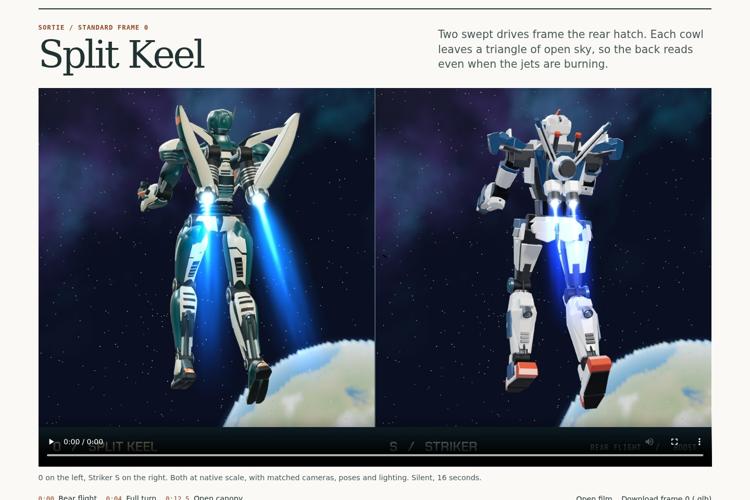
image_17.jpg 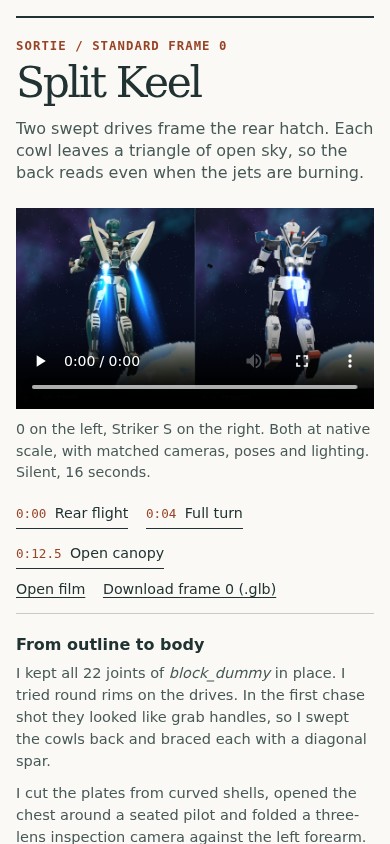
image_18.jpg exec_commandsed -n '247,341p' kit/blocks/zero.py && sed -n '541,627p' kit/blocks/zero.py
command
sed -n '247,341p' kit/blocks/zero.py && sed -n '541,627p' kit/blocks/zero.py
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"1424a9","wall_time_seconds":0.00000554,"exit_code":0,"original_token_count":2833,"output":"Warning: truncated output (original token count: 2833)\nTotal output lines: 182\n\n outer=[(-.66,-1.02,14.96),(.57,-1.04,14.96),(.88,-1.21,14.53),(.86,-1.43,13.79),\n (.48,-1.46,12.98),(-.43,-1.46,12.98),(-.83,-1.44,13.67),(-.89,-1.26,14.46)]\n rim=[(-.39,-1.21,14.76),(.34,-1.21,14.76),(.55,-1.34,14.45),(.57,-1.48,13.85),\n (.32,-1.52,13.26),(-.26,-1.52,13.26),(-.52,-1.48,13.77),(-.55,-1.36,14.39)]\n cut=[(x*1.03,14+(z-14)*1.022) for x,y,z in outer]\n for obj in list(f.j['torso'].children):\n if obj.type=='MESH' and obj.name.startswith(('chest_casting','breast_fairing','collar_blade','costal_lame','pectoralis','chest_inlay')):\n boolean(obj,prism(cut,-2.3,-.7,'xz'))\n # Closed annular solids give the pressed perimeter a return lip on both sides.\n def ring(name,loops,role):\n n=len(loops[0])\n faces=[[j*n+i,j*n+(i+1)%n,((j+1)%len(loops))*n+(i+1)%n,((j+1)%len(loops))*n+i]\n for j in range(len(loops)) for i in range(n)]\n return f.put(name,'torso',mesh([v for seq in loops for v in seq],faces),role,.014,False)\n ring('fixed_escape_coaming', [[(x*1.14,y+.32,14+(z-14)*1.08) for x,y,z in outer],\n [(x*1.12,y+.038,14+(z-14)*1.064) for x,y,z in outer],outer,[(x,y+.25,z) for x,y,z in outer]],'frame')\n recessed=[(x,y+.06,z) for x,y,z in rim]\n tubback=[(x*1.22,.59,14+(z-14)*1.17) for x,y,z in rim]\n ring('pressure_tub', [recessed,tubback,[(x*1.08,y+.1,14+(z-14)*1.04) for x,y,z in tubback],\n [(x*1.12,y+.07,14+(z-14)*1.08) for x,y,z in recessed]],'joint')\n hinge=empty('canopy.hinge',(0,-1.03,14.98),f.j['torso'],travel_degrees=78)\n bezel=ring('hinged_canopy_bezel',[outer,rim,recessed,[(x,y+.045,z) for x,y,z in outer]],'accent')\n attach(bezel,hinge)\n window=f.put('forward_pressure_glass','torso',mesh(recessed+[(0,-1.47,14.03)],\n [[i,(i+1)%len(rim),len(rim)] for i in range(len(rim))]),'canopy.glass')\n attach(window,hinge)\n for side in (-1,1):\n f.put('rotary_hinge'+str(side),'torso',cylinder(.155,side*.70-.16,side*.70+.16,24,\n axis='x',at=(-1.03,14.98)),'frame',.018)\n lug=f.put('hinge_leaf'+str(side),'torso',cylinder(.123,side*.50-.12,side*.50+.12,24,\n axis='x',at=(-1.03,14.98)),'metal',.012)\n attach(lug,hinge)\n for z,y in [(13.67,-1.43),(14.48,-1.24)]:\n pin=f.put('canopy_flush_lock'+str(side)+str(z),'torso',cylinder(.055,y-.018,y+.025,12,\n axis='y',at=(side*(.70 if z<14 else .68),z)),'metal')\n attach(pin,hinge)\n # Pressure bulkhead behind the crew, with a removable dorsal service panel.\n f.put('cabin_bulkhead','torso',loft([(13.03,octo(1.19,.41,.15,y=.65)),(13.44,octo(1.55,.44,.18,y=.74)),\n (14.54,octo(1.56,.45,.19,y=.75)),(15.03,octo(1.20,.39,.13,y=.72))]),'frame',.045)\n f.plate('rear_pressure_vessel','torso',[(-.67,.69,13.03),(-.79,1.09,14.30),(-.62,1.00,15.03),(.62,1.00,15.03),\n (.79,1.09,14.30),(.67,.69,13.03)],(0,1.65,14.14),(0,-.36,0),'joint')\n f.plate('boarding_hatch','torso',[(-.53,1.44,13.41),(-.64,1.43,14.33),(-.37,1.29,14.86),\n (.37,1.29,14.86),(.64,1.43,14.33),(.53,1.44,13.41)],(0,1.82,14.1),(0,-.14,0),'main')\n for s in (-1,1):\n f.rail('boarding_rail'+str(s),'torso',(s*.71,1.48,13.26),(s*.69,1.51,14.58),.058,'trim')\n f.plate('rear_hatch_viewport','torso',[(-.40,1.69,14.20),(-.28,1.58,14.5),(.28,1.58,14.5),(.40,1.69,14.2)],(0,1.78,14.36),(0,-.04,0),'visor')\n f.rail('rear_hatch_light','torso',(-.21,1.786,14.34),(.21,1.786,14.34),.025,'glow_eye')\n for i in range(3):\n z=13.40+i*.17\n f.rail('hatch_tread'+str(i),'torso',(-.28,1.73,z),(.28,1.73,z),.047,'frame')\n for i in range(4):\n z=10.93+i*.24\n w=.79+.055*i\n f.put('abdominal_seal'+str(i),'waist',loft([(z,octo(w*2,1.37,.30)),(z+.09,octo(w*2+.08,1.43,.30)),\n (z+.2,octo(w*2-.12,1.25,.27))]),'joint' if i%2 else 'frame',.025)\n pelvis=Skin([(9.87,0,0,.65,.68,.6),(10.24,0,0,1.20,.94,.88),(10.68,0,0,1.47,.99,.92),\n (10.99,0,0,1.12,.78,.76)],.78)\n f.hull('pelvic_frame','pelvis',pelvis)\n for s in (-1,1):\n for name,lo,hi,a,b,r in [('belt',.61,.98,4,149,'main'),('hip_shield',.05,.61,32,142,'accent'),('sacral_leaf',…733 tokens truncated…dren:\n if part.name.startswith('crew_') and part.type=='MESH':\n original=part.data.materials[0].name\n if original in ('suit','accent','trim','main'):\n part.data.materials[0]=material('crew.'+original)\n seat=pts['seat']\n f.tube('seat_bucket','torso',[seat+Vector((0,0,-.18)),seat+Vector((0,.025,-.02))],[.32,.34],'suit',16,1.27)\n f.tube('seat_back','torso',[seat+Vector((0,.19,-.05)),seat+Vector((0,.21,.30)),seat+Vector((0,.10,.66))],\n [.28,.26,.20],'frame',12,.39)\n for s in ('L','R'):\n grip=pts['grip.'+s]\n peg=pts['peg.'+s]\n f.rail('control_stick'+s,'torso',grip+Vector((0,-.06,-.28)),grip,.037,'metal')\n f.rail('footrest'+s,'torso',peg-Vector((.11,0,0)),peg+Vector((.11,0,0)),.033,'metal')\n for side in (-1,1):\n x=side*.46\n f.plate('console_well'+str(side),'torso',[(x-.13,-1.14,13.81),(x+.13,-1.14,13.81),\n (x+.13,-1.01,14.04),(x-.13,-1.01,14.04)],(x,-1.07,13.94),(0,.08,-.04),'frame')\n f.plate('console_display'+str(side),'torso',[(x-.099,-1.145,13.86),(x+.099,-1.145,13.86),\n (x+.10,-1.04,14.00),(x-.10,-1.04,14.00)],(x,-1.10,13.94),(0,.022,0),'sensor')\n for j in range(3):\n cx=x-.078+j*.078\n f.rail('screen_readout'+str(side)+str(j),'torso',(cx,-1.13,13.905),(cx,-1.10,13.945+j*.012),.008,'glow_eye')\n f.rail('tub_grab_handle'+str(side),'torso',(side*.53,-.96,13.62),(side*.54,-.88,13.92),.036,'trim')\n # Bolt the seat and controls to a continuous cockpit floor; each grip has a\n # fixed support forward of the pilot and the footboards flank the centre console.\n f.put('crew_floor','torso',loft([(12.96,octo(1.43,1.70,.20,y=-.23)),(13.11,octo(1.43,1.70,.20,y=-.23))]),'frame',.04)\n f.tube('seat_suspension','torso',[(0,seat.y,13.06),seat+Vector((0,.02,-.16))],[.19,.15],'metal',12)\n for side in (-1,1):\n k='L' if side>0 else 'R'\n g=pts['grip.'+k]\n boot=g+Vector((0,-.06,-.28))\n f.tube('console_pedestal'+k,'torso',[(side*.42,-.67,13.06),boot], [.11,.09],'frame',8)\n peg=pts['peg.'+k]\n f.tube('footboard_mount'+k,'torso',[(peg.x,peg.y+.06,13.06),peg+Vector((0,0,-.04))],[.08,.08],'joint',10)\n f.put('seat_armoured_back','torso',loft([(13.12,octo(.60,.16,.055,y=.32)),\n (14.03,octo(.66,.19,.07,y=.32)),(14.48,octo(.52,.18,.065,y=.22))]),'suit',.045)\n f.rail('cabin_light_bar','torso',(-.24,-.84,14.81),(.24,-.84,14.81),.026,'glow_eye')\n empty('crew.lamp',(0,-.93,14.66),f.j['torso'])\n empty('crew.eye',eye_target,f.j['torso'],seat='reclined')\n\n\ndef identification(f):\n from mathutils.bvhtree import BVHTree\n bpy.context.view_layer.update()\n graph=bpy.context.evaluated_depsgraph_get()\n\n def print_on(target, words, at, normal, size, role):\n obj=bpy.data.objects[target]\n tree=BVHTree.FromObject(obj,graph)\n inv=obj.matrix_world.inverted()\n n=Vector(normal).normalized()\n right=Vector((0,0,1)).cross(n).normalized()\n up=n.cross(right).normalized()\n text=bpy.data.curves.new('Cut stencil','FONT')\n text.body=words\n text.align_x='CENTER'\n text.align_y='CENTER'\n text.size=size\n text.resolution_u=5\n source=bpy.data.objects.new('Stencil master',text)\n bpy.context.scene.collection.objects.link(source)\n baked=bpy.data.meshes.new_from_object(source.evaluated_get(graph))\n baked.calc_loop_triangles()\n vs=[]\n for v in baked.vertices:\n p=Vector(at)+right*v.co.x+up*v.co.y+n*3\n hit=tree.ray_cast(inv@p,inv.to_3x3()@-n)[0]\n vs.append(None if hit is None else obj.matrix_world@hit+n*.009)\n faces=[list(tri.vertices) for tri in baked.loop_triangles if all(vs[i] is not None for i in tri.vertices)]\n if faces:\n m=mesh([v if v is not None else (0,0,0) for v in vs],faces)\n for face in m.faces:\n if face.normal.dot(n)<0: face.normal_flip()\n solid('mark_'+words,m,role,obj.parent,panels=False)\n bpy.data.objects.remove(source,do_unlink=True)\n bpy.data.curves.remove(text)\n bpy.data.meshes.remove(baked)\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' import json,struct from pathlib import Path b=Path('public/assets/block_zero.glb').read_bytes() data=json.loads(b[20:20+struct.unpack_from('<I',b,12)[0]]) print('mesh objects',len(data['meshes']),'nodes',len(data['nodes'])) for m in data['materials']: if m['name'] in ('canopy.glass','main','accent','crew.main','glow_thruster'): print(m['name'],m.get('alphaMode'),m.get('pbrMetallicRoughness',{}).get('baseColorFactor')) print('no external images',all('uri' not in i for i in data.get('images',[]))) print('unbaked sockets',[n['name'] for n in data['nodes'] if 'nozzle' in n.get('extras',{})]) PY tail -1 review/out/form-zero/finish.log && tail -2 review/out/form-zero/game.log && rg 'Hatch clears' review/out/form-zero/verified-hatch.log && date -uresult, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"24a1e2","wall_time_seconds":0.00000336,"exit_code":0,"original_token_count":176,"output":"mesh objects 526 nodes 559\nmain None [0.5972017645835876, 0.577580451965332, 0.4125426113605499, 1]\naccent None [0.009134058840572834, 0.09084171056747437, 0.09758734703063965, 1]\nglow_thruster None [0.4564110338687897, 0.9130986332893372, 1, 1]\ncanopy.glass BLEND [0.05448027700185776, 0.14995978772640228, 0.16202937066555023, 0.3199999928474426]\ncrew.main None [0.8549926280975342, 0.7681511640548706, 0.577580451965332, 1]\nno external images True\nunbaked sockets []\n05:22.767 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0227.jpg'\nframe 0\nframe 48\nHatch clears 47 pilot meshes and 24 head meshes in all 27 sampled positions.\nTue Nov 17 23:50:02 UTC 2026\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path import struct,json for name in ['block_zero','striker']: b=Path('public/assets/'+name+'.glb').read_bytes() doc=json.loads(b[20:20+struct.unpack_from('<I',b,12)[0]]) print(name,len(doc['meshes']),sum(doc['accessors'][p['indices']]['count']//3 for m in doc['meshes'] for p in m['primitives']),len(doc['materials'])) print([(n['name'],n.get('extras',{})) for n in doc['nodes'] if n.get('name','').startswith('nozzle.')][:8]) PYresult, 4 lines
Script completed Wall time 0.3 seconds Output: {"chunk_id":"9e6340","wall_time_seconds":0.074680993,"exit_code":0,"original_token_count":187,"output":"block_zero 526 180472 18\n[('nozzle.calf.L', {'dir': [0.0, -0.8023, -0.5969], 'radius': 0.29}), ('nozzle.calf.R', {'dir': [0.0, -0.8023, -0.5969], 'radius': 0.29}), ('nozzle.main.L', {'dir': [0.1123, -0.7302, -0.674], 'radius': 0.62}), ('nozzle.main.R', {'dir': [-0.1123, -0.7302, -0.674], 'radius': 0.62})]\nstriker 232 16798 10\n[('nozzle.calf.L', {'dir': [0.0, -0.8619, -0.507], 'radius': 0.3}), ('nozzle.calf.R', {'dir': [0.0, -0.8619, -0.507], 'radius': 0.3}), ('nozzle.binder.L', {'dir': [-0.4679, -0.7488, 0.4695], 'radius': 0.3}), ('nozzle.binder.R', {'dir': [0.4679, -0.7488, 0.4695], 'radius': 0.3}), ('nozzle.main.L', {'dir': [0.0, -0.8944, -0.4472], 'radius': 0.42}), ('nozzle.main.R', {'dir': [0.0, -0.8944, -0.4472], 'radius': 0.42})]\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' import json,struct,collections from pathlib import Path b=Path('public/assets/block_zero.glb').read_bytes(); d=json.loads(b[20:20+struct.unpack_from('<I',b,12)[0]]) tri={i:sum(d['accessors'][p['indices']]['count']//3 for p in m['primitives']) for i,m in enumerate(d['meshes'])} entries=[(n['name'],tri[n['mesh']]) for n in d['nodes'] if 'mesh' in n] print(sorted(entries,key=lambda t:-t[1])[:24]) PYresult, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"21462e","wall_time_seconds":0.00000602,"exit_code":0,"original_token_count":168,"output":"[('crew_head_main', 3662), ('crew_chest_suit', 3264), ('crew_hand_L_suit', 3200), ('crew_hand_R_suit', 3200), ('crew_shin_L_main', 3178), ('crew_shin_R_main', 3178), ('crew_shin_L_suit', 3072), ('crew_shin_R_suit', 3072), ('crew_chest_main', 2996), ('crew_foot_L_main', 2112), ('crew_foot_R_main', 2112), ('crew_forearm_L_suit', 1920), ('crew_forearm_R_suit', 1920), ('crew_pelvis_suit', 1728), ('crew_thigh_L_suit', 1728), ('crew_thigh_R_suit', 1728), ('crew_upperarm_L_suit', 1728), ('crew_upperarm_R_suit', 1728), ('pelvic_frame', 1508), ('femoral_spar.L', 1508), ('tibial_spar.L', 1508), ('femoral_spar.R', 1508), ('tibial_spar.R', 1508), ('drive_arch_spar.L', 1508)]\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path p=Path('review/rear-cockpit/index.html') s=p.read_text().replace('<p>TIME_COMPUTE</p>','<p>The downloadable 0 has 180,472 triangles, including its pilot. S has 16,798. For gameplay I’d give the pilot a simpler mesh at chase distance.</p>\n <p>TIME_COMPUTE</p>') p.write_text(s) PY date -u; tail -1 review/out/form-zero/finish.log; ls review/out/form-zero/game | tail -1; ls -ld public/assets public/assets/striker.glbresult, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"59c4aa","wall_time_seconds":0.00000551,"exit_code":0,"original_token_count":71,"output":"Tue Nov 17 23:50:31 UTC 2026\n05:47.120 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0228.jpg'\n0096.jpg\ndrwx------ 2 runner runner 4096 Nov 17 23:45 public/assets\n-rw------- 1 runner runner 1008336 Nov 17 22:43 public/assets/striker.glb\n"}exec_commandpython3 - <<'PY'
command
python3 - <<'PY' from pathlib import Path lines=Path('review/out/form-zero/stages').read_text().splitlines() t=[int(x.split()[0]) for x in lines] d=[t[2]-t[0],t[3]-t[2],t[4]-t[3],t[5]-t[4]] p=Path('review/rear-cockpit/index.html') s=p.read_text() for old,sec in zip(('9 min','2 min','14 min','12 min'), d): s=s.replace('<dd>'+old+'</dd>',f'<dd>{sec//60}m {sec%60:02d}s</dd>') p.write_text(s) print(d) PY ls review/out/form-zero/game | tail -1 tail -1 review/out/form-zero/finish.logresult, 4 lines
Script completed
Wall time 0.2 seconds
Output:
{"chunk_id":"36390a","wall_time_seconds":0.014712227,"exit_code":0,"original_token_count":35,"output":"[552, 123, 843, 737]\n0105.jpg\n06:13.274  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0229.jpg'\n"}
exec_command, view_imagepython3 - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python3 - <<'PY' from pathlib import Path from PIL import Image p=Path('review/out/form-zero') out=Image.new('RGB',(720,404)) for i,name in enumerate(('0000','0032','0061','0096')): im=Image.open(p/f'game/{name}.jpg'); im=im.resize((360,202),Image.Resampling.LANCZOS);out.paste(im,(360*(i%2),202*(i//2))) out.save(p/'four-frames.jpg') PY`})) image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/four-frames.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.6 seconds
Output:
{"chunk_id":"77e445","wall_time_seconds":0.285296323,"exit_code":0,"original_token_count":0,"output":""}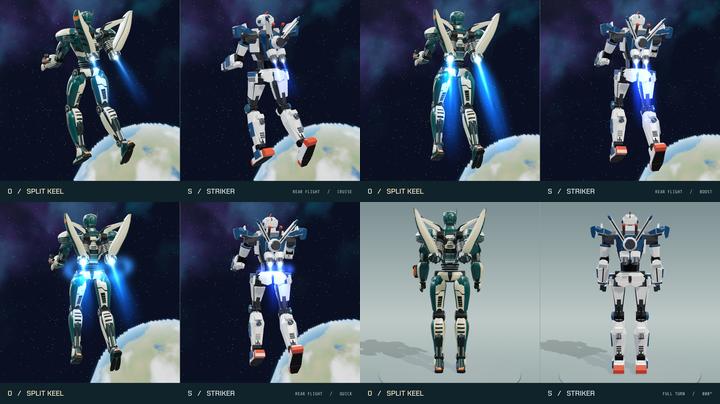
four-frames.jpg write_stdin, exec_commandpoll session undefined (+1 more)
input
// @exec: {"yield_time_ms": 1000} const jobs=await Promise.allSettled([['game',31071],['studio',76254]].map(async ([name,session_id])=>{let r;do {r=await tools.write_stdin({session_id,chars:'',yield_time_ms:45000,max_output_tokens:150})}while(r.session_id && r.exit_code==null);return {name,exit:r.exit_code,output:r.output}}));for(const j of jobs)text(j);if(jobs.some(j=>j.status!=='fulfilled'||j.value.exit!==0))exit();text(await tools.exec_command({cmd:`date -u +'%s film assembly and offline checks' >> review/out/form-zero/stages /usr/bin/time -f '%e' -o review/out/form-zero/assembly-seconds python3 review/form-zero/assemble.py review/out/form-zero review/rear-cockpit/frame-zero > review/out/form-zero/assembly.log 2>&1`,yield_time_ms:100}))result, 4 lines
Script running with cell ID 79
Wall time 1.0 seconds
Output:
waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commanddate -u && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -1 && du -sh review/out/form-zero/game && git status --short --branch
command
date -u && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -1 && du -sh review/out/form-zero/game && git status --short --branch
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"fc47c4","wall_time_seconds":0.00000443,"exit_code":0,"original_token_count":74,"output":"Tue Nov 17 23:52:29 UTC 2026\n07:38.655 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0232.jpg'\n0133.jpg\n31M\treview/out/form-zero/game\n## astra62\n M review/rear-cockpit/index.html\n?? kit/blocks/zero-paint.json\n?? kit/blocks/zero.py\n?? review/form-zero/\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commanddate -u && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -1 && ps -eo pid,pcpu,pmem,comm --sort=-pcpu | head -8
command
date -u && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -1 && ps -eo pid,pcpu,pmem,comm --sort=-pcpu | head -8
result, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"2f4705","wall_time_seconds":0.000005951,"exit_code":0,"original_token_count":93,"output":"Tue Nov 17 23:53:48 UTC 2026\n08:50.976 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0235.jpg'\n0161.jpg\n PID %CPU %MEM COMMAND\n 1819 376 3.4 blender\n 1912 169 0.4 chrome-headless\n 1927 2.3 0.3 chrome-headless\n 1867 1.6 0.3 node\n 2 0.3 0.3 codex\n 1885 0.1 0.1 chrome-headless\n 1 0.0 0.0 bwrap\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_command, view_imagepython3 - <<'PY' (+1 more)
input
text(await tools.exec_command({cmd:`python3 - <<'PY' from PIL import Image from pathlib import Path d=Path('review/out/form-zero/game') n=sorted(d.glob('*.jpg'))[-1] im=Image.open(n); im.thumbnail((760,430));im.save('review/out/form-zero/turn-progress.jpg') print(n) PY date -u && tail -1 review/out/form-zero/finish.log`})) image((await tools.view_image({path:"~/work/sortie/review/out/form-zero/turn-progress.jpg"})).image_url)result, 4 lines
Script completed
Wall time 0.4 seconds
Output:
{"chunk_id":"e846c6","wall_time_seconds":0.158841689,"exit_code":0,"original_token_count":43,"output":"review/out/form-zero/game/0184.jpg\nTue Nov 17 23:55:01 UTC 2026\n10:08.079  render           | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0238.jpg'\n"}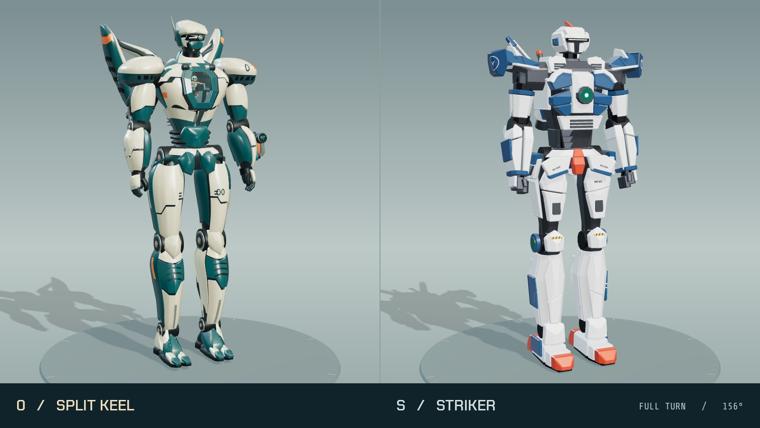
turn-progress.jpg waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commanddate -u; tail -1 review/out/form-zero/finish.log; ls review/out/form-zero/game | tail -1; git status --short --branch; du -sh review/out/form-zero/finish-frames
command
date -u; tail -1 review/out/form-zero/finish.log; ls review/out/form-zero/game | tail -1; git status --short --branch; du -sh review/out/form-zero/finish-frames
result, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"930eb3","wall_time_seconds":0.00000419,"exit_code":0,"original_token_count":76,"output":"Tue Nov 17 23:56:14 UTC 2026\n11:25.673 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0241.jpg'\n0204.jpg\n## astra62\n M review/rear-cockpit/index.html\n?? kit/blocks/zero-paint.json\n?? kit/blocks/zero.py\n?? review/form-zero/\n5.7M\treview/out/form-zero/finish-frames\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
agent
+1:13:03All 22 joint transforms match block_dummy in the exported model. The detail has a measurable cost: 0 has 180,472 triangles, including the seated pilot, and S has 16,798. I’ve included those figures with the downloadable model so you can judge both the shape and its cost in game.
waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commandtail -1 review/out/form-zero/finish.log; tail -2 review/out/form-zero/game.log; ls review/out/form-zero/game | tail -1; date -u
command
tail -1 review/out/form-zero/finish.log; tail -2 review/out/form-zero/game.log; ls review/out/form-zero/game | tail -1; date -u
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"075f28","wall_time_seconds":0.000005891,"exit_code":0,"original_token_count":42,"output":"13:43.686 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0246.jpg'\nframe 192\nframe 240\n0241.jpg\nTue Nov 17 23:58:25 UTC 2026\n"}exec_commandgit add kit/blocks/zero-paint.json kit/blocks/zero.py review/form-zero
command
git add kit/blocks/zero-paint.json kit/blocks/zero.py review/form-zero
git diff --cached --check && git diff --cached --stat && git branch --show-current
result, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"0bdb2e","wall_time_seconds":0.0000056,"exit_code":0,"original_token_count":120,"output":" kit/blocks/zero-paint.json | 20 ++\n kit/blocks/zero.py | 696 ++++++++++++++++++++++++++++++++++++++++\n review/form-zero/assemble.py | 61 ++++\n review/form-zero/capture.mjs | 55 ++++\n review/form-zero/check-hatch.py | 35 ++\n review/form-zero/make-film.sh | 24 ++\n review/form-zero/screen.html | 1 +\n review/form-zero/screen.js | 174 ++++++++++\n review/form-zero/studio.py | 143 +++++++++\n 9 files changed, 1209 insertions(+)\nastra62\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commandls review/out/form-zero/game | tail -1; tail -1 review/out/form-zero/finish.log; date -u
command
ls review/out/form-zero/game | tail -1; tail -1 review/out/form-zero/finish.log; date -u
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"7f2073","wall_time_seconds":0.00000387,"exit_code":0,"original_token_count":37,"output":"0262.jpg\n14:32.171 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0248.jpg'\nTue Nov 17 23:59:35 UTC 2026\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commandls review/out/form-zero/game | tail -1 && tail -1 review/out/form-zero/finish.log && date -u && df -h . | tail -1
command
ls review/out/form-zero/game | tail -1 && tail -1 review/out/form-zero/finish.log && date -u && df -h . | tail -1
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"97e62f","wall_time_seconds":0.000200191,"exit_code":0,"original_token_count":50,"output":"0280.jpg\n15:59.950 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0251.jpg'\nWed Nov 18 00:00:45 UTC 2026\n/dev/sdd 1007G 542G 415G 57% ~\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commandls review/out/form-zero/game | tail -2 && tail -2 review/out/form-zero/finish.log && cat review/out/form-zero/game-seconds && date -u
command
ls review/out/form-zero/game | tail -2 && tail -2 review/out/form-zero/finish.log && cat review/out/form-zero/game-seconds && date -u
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"1f60a1","wall_time_seconds":0.00000487,"exit_code":0,"original_token_count":66,"output":"0295.jpg\n0296.jpg\n16:28.253 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0252.jpg'\n16:58.747 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0253.jpg'\nWed Nov 18 00:01:51 UTC 2026\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script running with cell ID 79
Wall time 56.0 seconds
Output:
exec_commandcat review/out/form-zero/game-seconds && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -3 && date -u
command
cat review/out/form-zero/game-seconds && tail -1 review/out/form-zero/finish.log && ls review/out/form-zero/game | tail -3 && date -u
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"73a2db","wall_time_seconds":0.0000048,"exit_code":0,"original_token_count":45,"output":"1027.31\n18:20.053 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0256.jpg'\n0298.jpg\n0299.jpg\nclose-label.jpg\nWed Nov 18 00:03:00 UTC 2026\n"}exec_commandcat > review/out/form-zero/film-proof.py <<'PY'
command
cat > review/out/form-zero/film-proof.py <<'PY' import subprocess from pathlib import Path from PIL import Image from io import BytesIO import json film='review/rear-cockpit/frame-zero/zero-and-striker.mp4' info=json.loads(subprocess.check_output(['ffprobe','-v','error','-show_streams','-of','json',film]))['streams'][0] assert (info['width'],info['height'],info['r_frame_rate'],info['nb_frames'],float(info['duration']))==(1600,900,'24/1','384',16.0),info print({k:info[k] for k in ('codec_name','width','height','r_frame_rate','nb_frames','duration')}) canvas=Image.new('RGB',(1080,609)) for i,t in enumerate([.45,1.33,2.58,4.0,6.1,8.25,10.35,12.46,15.5]): b=subprocess.check_output(['ffmpeg','-loglevel','error','-threads','2','-ss',str(t),'-i',film,'-frames:v','1','-vf','scale=360:203','-threads','1','-f','image2pipe','-c:v','png','-']) tile=Image.open(BytesIO(b));canvas.paste(tile,(360*(i%3),203*(i//3))) canvas.save('review/out/form-zero/release-proof.jpg',quality=94) PY date -u && tail -1 review/out/form-zero/finish.logresult, 4 lines
Script completed Wall time 0.2 seconds Output: {"chunk_id":"517d1b","wall_time_seconds":0.00000799,"exit_code":0,"original_token_count":35,"output":"Wed Nov 18 00:03:10 UTC 2026\n18:20.053 render | Saved: '~/work/sortie/review/out/form-zero/finish-frames/0256.jpg'\n"}waitcell 79
input
{ "cell_id": "79", "yield_time_ms": 55000 }result, 4 lines
Script completed Wall time 42.9 seconds Output: {"status":"fulfilled","value":{"name":"game","exit":0,"output":""}}{"status":"fulfilled","value":{"name":"studio","exit":0,"output":""}}{"chunk_id":"4dad49","wall_time_seconds":0.252932539,"session_id":98528,"original_token_count":0,"output":""}exec_commandcat review/out/form-zero/{game,studio}-seconds && tail -3 review/out/form-zero/stages && cat review/out/form-zero/assembly.log && ls -lh review/rear-cockpit/frame-zero && date -u
command
cat review/out/form-zero/{game,studio}-seconds && tail -3 review/out/form-zero/stages && cat review/out/form-zero/assembly.log && ls -lh review/rear-cockpit/frame-zero && date -uresult, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"61e73c","wall_time_seconds":0.00000881,"exit_code":0,"original_token_count":71,"output":"1027.31\n1165.34\n1794958338  pressure hatch, surface cuts, service markings and motion\n1794959075  production capture and render\n1794960240  film assembly and offline checks\ntotal 2.8M\n-rw------- 1 runner runner 2.8M Nov 18 00:04 zero-and-striker.part.mp4\nWed Nov 18 00:04:07 UTC 2026\n"}