A 3D model pipeline, pushed by Gemini 4 Carbon
agent
+6:21reasoning
The analysis of the code revealed key files related to game elements. It appears that tools/cage.py plays a crucial role. This suggests a core game mechanic is already in place.
The codebase contains pre-built VRoid bodies and implements outfits, plates, and gear. Additionally, there are rigging and clip functionalities defined. There is also terrain generation with a Three.js renderer.
read_file{"EndLine":230,"Path":"~/work/lowmarch/review/vroid-02/build.py","StartLine":130}
input
{ "EndLine": 230, "Path": "~/work/lowmarch/review/vroid-02/build.py", "StartLine": 130 }result, 102 lines
Showing lines 130-230 of 391 130: import makehuman 131: p = makehuman.path_for(name, c["mh"]) 132: if not os.path.exists(p): 133: raise SystemExit(f"{name}: no converted MakeHuman body; run python3 -I tools/makehuman.py first") 134: return p 135: 136: 137: def arm_room(name, c, need=0.006, most=16): 138: """The smallest outward arm angle (degrees, shape["arm_out"]) at which the hanging arms clear the 139: body by `need` in the reference pose and the idle: broad bodies otherwise sink their arms into 140: their sides. MakeHuman bodies only for now (the VRoid cast was posed by hand).""" 141: import checks 142: from vrm import VRM 143: v = VRM(model_path(name, c)) 144: limbs = [f"{s}_{a}" for s in "LR" for a in ("UpperArm", "LowerArm")] 145: for deg in range(0, most + 1, 2): 146: b = checks.Body(v, dict(c["shape"], arm_out=float(deg))) 147: if min(b.worst(pose, limbs) for pose in (P.BUST, P.BATTLE_IDLE)) >= need: 148: return float(deg) 149: return float(most) 150: 151: 152: ARMORY = bool(WORKSHOPS.get(SITE, {}).get("armory")) # T-posed and bare: the reference pose is the T-pose 153: 154: 155: def portrait(name, view): 156: c = CAST[name] 157: if (c.get("mh") or c.get("qt") or c.get("mass") or c.get("cage")) and "arm_out" not in c["shape"] and not ARMORY: 158: c["shape"]["arm_out"] = arm_room(name, c) 159: return vp.Portrait(model_path(name, c), shape=c["shape"], 160: hair_from=os.path.join(VROID, c["hair"]) if c.get("hair") else None, 161: costume=costume_of(c), pose={} if ARMORY else vp.BUST_POSE, hair_trim=c.get("hair_trim"), 162: world=terrain.plains() if view == "battle" else None), c 163: 164: 165: def springs(v): 166: """The model's spring bones (VRM 0.x secondaryAnimation: VRoid's women's base has its breasts', a hairstyle its 167: hair's, tools/heads.py): each group's root bones, settings and collision spheres (on a bone, offset in its own 168: frame, before the export's turn), for the viewer's physics.""" 169: sa = v.j.get("extensions", {}).get("VRM", {}).get("secondaryAnimation", {}) 170: nodes = v.j["nodes"] 171: spheres = [[dict(bone=nodes[cg["node"]]["name"], offset=[c["offset"]["x"], c["offset"]["y"], c["offset"]["z"]], 172: radius=c["radius"]) for c in cg.get("colliders", [])] for cg in sa.get("colliderGroups", [])] 173: out = [] 174: for g in sa.get("boneGroups", []): 175: gd = g.get("gravityDir", {"x": 0, "y": -1, "z": 0}) 176: out.append(dict(bones=[nodes[b]["name"] for b in g["bones"]], stiffness=g.get("stiffiness", 1.0), 177: gravity=g.get("gravityPower", 0.0), gravity_dir=[gd["x"], gd["y"], gd["z"]], 178: drag=g.get("dragForce", 0.4), radius=g.get("hitRadius", 0.02), comment=g.get("comment", ""), 179: colliders=[c for k in g.get("colliderGroups", []) if k < len(spheres) for c in spheres[k]])) 180: return out 181: 182: 183: def wrap_json(path): 184: json.dump({"glb": base64.b64encode(open(path, "rb").read()).decode()}, open(path + ".json", "w")) 185: os.remove(path) 186: 187: 188: def character(args): 189: """The rigged character (reference pose) with its clips, its cameras, the live renderer's data and 190: its checks.""" 191: name, clash = args 192: p, c = portrait(name, "bust") 193: p.paint = c.get("paint") 194: pal = dict(vp.PALETTE, **c["colors"]) 195: cam_bust, cam_battle = p.frame("bust"), p.frame("battle") 196: if ARMORY: # nothing moves: every clip holds the T-pose 197: cl = {k: [(0.0, {}), (1.0, {})] for k in ("idle", "attack", "apose")} 198: else: 199: cl = clips.clips(p.v, c["shape"], c.get("stance", "sword")) 200: if clash: 201: cl["clash"] = clash 202: cl["apose"] = [(0.0, APOSE), (1.0, APOSE)] 203: path = f"{OUT}/{name}.glb" 204: size = export_glb.export_skinned(p, pal, path, clips=cl) 205: wrap_json(path) 206: save_geometry(name, p) 207: if ARMORY: # the armory's checks are proportions (tools/proportions.py) 208: return dict(name=name, size=size, cams=dict(bust=cam_bust, battle=cam_battle), 209: info=dict(export_glb.scene_info(p, pal), springs=springs(p.v)), checks=proportion_checks(name, c)) 210: body = checks.Body(p.v, c["shape"]) 211: keyed = {k: v for k, v in cl.items() if k != "apose"} 212: head, bad, touch = checks.report(name, keyed, body) 213: layers = checks.layer_report(name, keyed, checks.Layers(p, body)) 214: return dict(name=name, size=size, cams=dict(bust=cam_bust, battle=cam_battle), info=export_glb.scene_info(p, pal), 215: checks=dict(summary=head, through=bad, touching=touch, layers=layers)) 216: 217: 218: def save_geometry(name, p): 219: """Every piece's vertices as built (reference pose), for tools/regress.py to compare builds.""" 220: os.makedirs(GEOM, exist_ok=True) 221: arrays, seen = {}, {} 222: for q in p.prims: 223: key = q["material"] 224: seen[key] = seen.get(key, 0) + 1 225: if seen[key] > 1: 226: key = f"{key}#{seen[key]}" 227: arrays[key] = q["pos"][np.unique(q["tri"])].astype(np.float32) if len(q["tri"]) else q["pos"].astype(np.float32) 228: np.savez_compressed(os.path.join(GEOM, f"{name}.npz"), **arrays) 229: 230:read_file{"EndLine":550,"Path":"~/work/lowmarch/tools/outfit.py","StartLine":250}
input
{ "EndLine": 550, "Path": "~/work/lowmarch/tools/outfit.py", "StartLine": 250 }result, 302 lines
Showing lines 250-550 of 1272
250: # ---- garments ------------------------------------------------------------------------
251: def wrap(fit, name, role, bones, offset, min_w=0.5, exclude=(), y_min=None, y_max=None, subdiv=0,
252:          base=None, hems=(), smooth=15, cut=None, refloor=False, clamp=False):
253:     """A garment shrink-wrapped onto the body region that follows `bones`. cut: (normal, d), keep only
254:     the skin below that plane (n.p < d, give or take a centimetre; pair it with a hem on the same plane).
255:     refloor: after the hems, push out whatever a hem pulled into the skin (a hem moves its edge straight
256:     along the plane's normal, which sinks it into a sloping hip; off by default so finished costumes
257:     don't drift). clamp: every vertex past a hem's plane goes onto it, not just the edge's (pass y_min
258:     and y_max a few centimetres past the hems: large skin triangles crossing a hem line otherwise leave
259:     notches as deep as a triangle)."""
260:     T = fit.tris_for(bones, min_w, exclude, y_min, y_max)
261:     if cut is not None:
262:         n_ = np.asarray(cut[0], float) / np.linalg.norm(cut[0])
263:         T = T[(fit.pos[T] @ n_).max(1) < cut[1] + 0.01]
264:     if not len(T):
265:         return None
266:     pos, tri, used = compact(fit.pos, T)
267:     levels = []
268:     for _ in range(subdiv):
269:         pos, tri, par = subdivide(pos, tri, with_parents=True)
270:         levels.append(par)
271:     out = shrink_wrap(pos, tri, base or fit.surf, offset, smooth=smooth)
272:     for n, d in hems:
273:         out = flatten_hem(out, tri, n, d)
274:         if clamp:
275:             n_ = np.asarray(n, float) / np.linalg.norm(n)
276:             over = out @ n_ - d
277:             out = out - np.outer(np.maximum(over, 0.0), n_)
278:     if refloor and hems:
279:         surf = base or fit.surf
280:         d2, cp2, ti2 = surf.query(out)
281:         low = d2 < offset * 0.75
282:         out[low] = cp2[low] + surf.fn[ti2[low]] * offset * 0.75
283:     pc = piece(name, role, out, tri)
284:     # weights come from the exact skin each vertex grew from: copying from the nearest skin instead
285:     # let the inside of one boot pick up the other leg's bones
286:     pc["J"], pc["W"] = blend_weights(fit.J[used], fit.W[used], int(fit.J.max()) + 1, levels)
287:     pc["jnames"] = fit.jnames
288:     if getattr(fit, "cloth_hull", False):             # a body with muscle relief: sleeves span the hollows
289:         hw = lambda b: (np.array([b == n for n in fit.jnames])[pc["J"]] * pc["W"]).sum(1)
290:         axes = []
291:         for sd in ("L", "R"):
292:             for b0, b1 in (("UpperArm", "LowerArm"), ("LowerArm", "Hand"), ("UpperLeg", "LowerLeg"), ("LowerLeg", "Foot"),
293:                            ("Foot", "ToeBase")):                  # (boots over the foot: no toes showing)
294:                 n0, n1 = f"J_Bip_{sd}_{b0}", f"J_Bip_{sd}_{b1}"
295:                 if n0 in fit.bone and n1 in fit.bone:
296:                     m = hw(n0) + (hw(n1) if b0 == "Foot" else 0.0)    # the foot's segment takes the toes too
297:                     axes.append((m >= 0.6, fit.bone[n0], fit.bone[n1], b0 == "Foot"))
298:         pc["pos"] = limb_hull(pc["pos"], tri, axes)
299:         pc["nrm"] = vertex_normals(pc["pos"], tri)
300:     pc["loops"] = boundary_loops(tri)
301:     return pc
302:
303:
304: def loop_trim(name, role, garment, pick, width=0.008, lift=0.0015):
305:     """Trim along one of a garment's open edges: the loop that scores highest under `pick`."""
306:     loops = garment.get("loops") or []
307:     if not loops:
308:         return None
309:     best = max(loops, key=lambda L: pick(garment["pos"][L]))
310:     return inherit(ribbon(name, role, garment["pos"][best], width, lift, normals=garment["nrm"][best], closed=True), garment)
311:
312:
313: def slice_line(pc, axis=0, value=0.0, keep=lambda p: True):
314:     """Points where a plane (coordinate `axis` == value) cuts a piece, sorted top to bottom."""
315:     P = pc["pos"][pc["tri"]]
316:     s = P[:, :, axis] - value
317:     out = []
318:     for i, j in ((0, 1), (1, 2), (2, 0)):
319:         a, b = s[:, i], s[:, j]
320:         x = (a > 0) != (b > 0)
321:         t = a[x] / (a[x] - b[x])
322:         out.append(P[x, i] + (P[x, j] - P[x, i]) * t[:, None])
323:     pts = np.concatenate(out)
324:     pts = np.array([p for p in pts if keep(p)])
325:     return pts[np.argsort(-pts[:, 1])] if len(pts) else pts
326:
327:
328: def collar(fit, name, role, height_back=0.044, height_front=0.028, gap_deg=50, clear=(0.009, 0.015),
329:            thickness=0.0035, seg=40, rows=6):
330:     """A standing collar fitted to the neck: radius from ray casts to the neck skin plus clearance
331:     (flaring toward the top), taller at the back, base lower at the front (the jugular notch)."""
332:     nk = fit.bone["J_Bip_C_Neck"]
333:     half = math.radians(180 - gap_deg / 2)
334:     ang = np.linspace(-half, half, seg)                     # 0 = back (+z), +-pi = front (-z)
335:     neck = Surface(fit.pos, fit.tris_for(("Neck", "UpperChest", "Head", "Shoulder"), min_w=0.3))
336:     P = np.zeros((seg, rows, 3))
337:     for i, a in enumerate(ang):
338:         d = np.array([math.sin(a), 0, math.cos(a)])
339:         front = (1 - math.cos(a)) / 2                       # 0 back .. 1 front
340:         base_y = nk[1] - 0.010 - 0.012 * front
341:         h = height_back + (height_front - height_back) * front
342:         for j, t in enumerate(np.linspace(0, 1, rows)):
343:             o = np.array([nk[0], base_y + h * t, nk[2]])
344:             r = neck.cast(o, d, rmax=0.2, far=False)
345:             r = 0.05 if np.isnan(r) else r
346:             P[i, j] = o + d * (r + clear[0] + (clear[1] - clear[0]) * t)
347:     pos, tri, outer = thick_grid(P, thickness, outward_from=nk, axis=[0, 1, 0])
348:     pc = piece(name, role, pos, tri)
349:     t = np.clip((pos[:, 1] - (nk[1] - 0.022)) / height_back, 0, 1)
350:     fit.bind(pc, blend={"J_Bip_C_UpperChest": 0.5, "J_Bip_C_Neck": 0.5})
351:     pc["W"][:, 0], pc["W"][:, 1] = 1 - 0.7 * t, 0.7 * t     # base on the chest, top mostly on the neck
352:     return pc, outer[:, -1], (outer[0], outer[-1])
353:
354:
355: def pauldron(fit, name, role, over, side="L", lames=((0, 62, 0.012, 0.016), (55, 78, 0.010, 0.013),
356:              (72, 92, 0.008, 0.011)), spread=135, thickness=0.004, seg=30, rows=7):
357:     """Overlapping lames over the shoulder. Each lame's shape comes from ray casts out of the
358:     deltoid to the surface it covers (`over`: the tunic, plus the cape if it runs under), plus an
359:     offset that grows toward the rim. Lower lames tuck under the one above. Open on the neck side."""
360:     sh = fit.bone[f"J_Bip_{side}_UpperArm"]
361:     el = fit.bone[f"J_Bip_{side}_LowerArm"]
362:     down = (el - sh) / np.linalg.norm(el - sh)
363:     up = -down
364:     sx = -1 if side == "L" else 1
365:     outw = np.array([sx, 0, 0.0]) - down * (np.array([sx, 0, 0.0]) @ down)
366:     outw /= np.linalg.norm(outw)
367:     fwd = np.cross(down, outw)
368:     fwd = -fwd if fwd[2] > 0 else fwd
369:     C = sh + down * 0.015
370:     pole = up * math.cos(math.radians(28)) + outw * math.sin(math.radians(28))
371:     pole /= np.linalg.norm(pole)
372:     e1 = fwd - pole * (fwd @ pole)
373:     e1 /= np.linalg.norm(e1)
374:     e2 = np.cross(pole, e1)
375:     e2 = -e2 if e2 @ outw < 0 else e2
376:     ph = np.linspace(-math.radians(spread), math.radians(spread), seg)
377:     pieces, rims = [], []
378:     for k, (t0, t1, o0, o1) in enumerate(lames):
379:         G = np.zeros((seg, rows, 3))
380:         for j, th in enumerate(np.radians(np.linspace(t0, t1, rows))):
381:             for i, p in enumerate(ph):
382:                 d = pole * math.cos(th) + math.sin(th) * (e2 * math.cos(p) + e1 * math.sin(p))
383:                 r = over.cast(C, d, rmax=0.25, far=True)
384:                 r = 0.06 if np.isnan(r) else r
385:                 G[i, j] = C + d * (r + o0 + (o1 - o0) * j / (rows - 1))
386:         pos, tri, outer = thick_grid(G, thickness, outward_from=C)
387:         pc = piece(f"{name}{k}", role, pos, tri)
388:         if k == 0:
389:             fit.bind(pc, blend={f"J_Bip_{side}_UpperArm": 0.7, f"J_Bip_{side}_Shoulder": 0.3})
390:         else:
391:             fit.bind(pc, rigid=f"J_Bip_{side}_UpperArm")
392:         pieces.append(pc)
393:         rims.append(outer[:, -1])
394:     return pieces, rims
395:
396:
397: def drape(P0, collide, clearance, pinned, steps=90, iters=10, gravity=0.0025, bend=0.25, closed=False):
398:     """A small position-based cloth solve on a (U, V, 3) grid: gravity, stretch and bend
399:     constraints taken from the starting shape, pinned points, and collision that keeps every
400:     point `clearance` (per row) outside the `collide` surface. closed: the U direction wraps
401:     around (a skirt), so the last column is linked to the first."""
402:     U, V = P0.shape[:2]
403:     P = P0.reshape(-1, 3).copy()
404:     idx = np.arange(U * V).reshape(U, V)
405:     nxt = np.roll(idx, -1, 0) if closed else idx[1:, :]
406:     nx2 = np.roll(idx, -2, 0) if closed else idx[2:, :]
407:     links = np.concatenate([np.stack([(idx if closed else idx[:-1, :]).ravel(), nxt.ravel()], 1),
408:                             np.stack([idx[:, :-1].ravel(), idx[:, 1:].ravel()], 1)])
409:     blinks = np.concatenate([np.stack([(idx if closed else idx[:-2, :]).ravel(), nx2.ravel()], 1),
410:                              np.stack([idx[:, :-2].ravel(), idx[:, 2:].ravel()], 1)])
411:     rest = np.linalg.norm(P[links[:, 0]] - P[links[:, 1]], axis=1)
412:     brest = np.linalg.norm(P[blinks[:, 0]] - P[blinks[:, 1]], axis=1)
413:     fixed = pinned.reshape(-1)
414:     pin = P[fixed].copy()
415:     clr = np.broadcast_to(np.asarray(clearance, float)[None, :], (U, V)).reshape(-1)
416:
417:     def solve(L, R0, k):
418:         """Jacobi step: every constraint proposes a correction, each point moves by the average
419:         of its proposals (stable with many constraints per point)."""
420:         a, b = P[L[:, 0]], P[L[:, 1]]
421:         d = b - a
422:         ln = np.maximum(np.linalg.norm(d, axis=1), 1e-9)
423:         corr = (d * ((ln - R0) / ln)[:, None]) * 0.5 * k
424:         acc = np.zeros_like(P)
425:         cnt = np.zeros(len(P))
426:         np.add.at(acc, L[:, 0], corr)
427:         np.add.at(acc, L[:, 1], -corr)
428:         np.add.at(cnt, L[:, 0], 1)
429:         np.add.at(cnt, L[:, 1], 1)
430:         P[:] += acc / np.maximum(cnt, 1)[:, None] * 1.6
431:
432:     for _ in range(steps):
433:         P[:, 1] -= gravity
434:         for _ in range(iters):
435:             solve(links, rest, 1.0)
436:             solve(blinks, brest, bend)
437:             P[fixed] = pin
438:         d, cp, ti = collide.query(P)
439:         low = d < clr
440:         P[low] = cp[low] + collide.fn[ti[low]] * clr[low][:, None]
441:         P[fixed] = pin
442:     return P.reshape(U, V, 3)
443:
444:
445: def cape(fit, name, role, under, length=1.0, phi=0.55, seg=44, rows=18, top_clear=0.003,
446:          clear=(0.010, 0.045), folds=7, fold_depth=0.010):
447:     """A cape whose top edge lies on the tunic around the base of the neck, clasped at the
448:     collarbones, then settled by the cloth solve so it rests on the shoulders and falls clear."""
449:     nk = fit.bone["J_Bip_C_Neck"]
450:     ph = np.linspace(-phi, phi, seg) * math.pi              # 0 = straight back
451:     rad = np.stack([np.sin(ph), np.zeros_like(ph), np.cos(ph)], 1)
452:     top = []
453:     for a, d in zip(ph, rad):
454:         front = (1 - math.cos(a)) / 2
455:         o = np.array([nk[0], nk[1] - 0.013 - 0.032 * front, nk[2]])   # under the collar, down to the clasps
456:         r = under.cast(o, d, rmax=0.3, far=True)
457:         top.append(o + d * ((0.08 if np.isnan(r) else r) + top_clear))
458:     top = np.array(top)
459:     P = np.zeros((seg, rows, 3))
460:     for j, t in enumerate(np.linspace(0, 1, rows)):
461:         P[:, j] = top + rad * (0.10 * min(1.0, t * 4)) + np.array([0, -length * t, 0])
462:     pinned = np.zeros((seg, rows), bool)
463:     pinned[:, 0] = True
464:     P = drape(P, under, clear[0] + (clear[1] - clear[0]) * np.linspace(0, 1, rows), pinned)
465:     for j, t in enumerate(np.linspace(0, 1, rows)):
466:         P[:, j] += rad * (fold_depth * t * np.sin(ph * folds * 2 + 0.5))[:, None]
467:     pos, tri = grid_mesh(P)
468:     pc = piece(name, role, pos, tri, outward_from=nk + [0, -0.3, 0], axis=[0, 1, 0])
469:     fit.bind(pc, allow=("Spine", "Chest", "UpperChest", "Neck", "Shoulder"), fallback="J_Bip_C_UpperChest")
470:     pc["grid"] = (seg, rows)                    # the viewer simulates it as cloth: top row pinned
471:     return pc, P
472:
473:
474: def tails(fit, name, role, under, y_top, length=0.36, front_gap=60, seg=40, rows=12, clear=(0.012, 0.030)):
475:     """Tunic tails from under the belt, open at the front, settled against the legs."""
476:     ang = np.radians(np.linspace(-(180 - front_gap / 2), 180 - front_gap / 2, seg))
477:     cz = fit.bone["J_Bip_C_Hips"][2]
478:     rad = np.stack([np.sin(ang), np.zeros_like(ang), np.cos(ang)], 1)
479:     top = []
480:     for d in rad:
481:         o = np.array([0.0, y_top, cz])
482:         r = under.cast(o, d, rmax=0.25, far=True)
483:         top.append(o + d * ((0.14 if np.isnan(r) else r) + clear[0]))
484:     top = np.array(top)
485:     P = np.zeros((seg, rows, 3))
486:     for j, t in enumerate(np.linspace(0, 1, rows)):
487:         P[:, j] = top + rad * (0.01 * t) + np.array([0, -length * t, 0])
488:     pinned = np.zeros((seg, rows), bool)
489:     pinned[:, 0] = True
490:     P = drape(P, under, clear[0] + (clear[1] - clear[0]) * np.linspace(0, 1, rows), pinned, steps=60)
491:     pos, tri = grid_mesh(P)
492:     pc = piece(name, role, pos, tri, outward_from=[0, y_top, cz], axis=[0, 1, 0])
493:     fit.bind(pc, allow=("Hips", "UpperLeg"), fallback="J_Bip_C_Hips")
494:     pc["grid"] = (seg, rows)
495:     return pc, P
496:
497:
498: def belt(fit, name, role, over, y, height=0.034, offset=0.006, thickness=0.005, seg=56, tilt=0.0):
499:     """A band around the waist cast onto `over`. tilt: metres higher on the character's right hip
500:     than the left (a slung second belt)."""
501:     cz = fit.bone["J_Bip_C_Hips"][2]
502:     ang = np.linspace(-math.pi, math.pi, seg)
503:     P = np.zeros((seg, 2, 3))
504:     for i, a in enumerate(ang):
505:         d = np.array([math.sin(a), 0, math.cos(a)])
506:         for j, dy in enumerate((height / 2, -height / 2)):
507:             o = np.array([0.0, y + dy + tilt * math.sin(a), cz])
508:             r = over.cast(o, d, rmax=0.4, far=True)
509:             P[i, j] = o + d * ((0.15 if np.isnan(r) else r) + offset)
510:     pos, tri, outer = thick_grid(P, thickness, outward_from=[0, y, cz], axis=[0, 1, 0])
511:     pc = fit.bind(piece(name, role, pos, tri), rigid="J_Bip_C_Hips")
512:     front = outer[np.argmin(np.abs(np.abs(ang) - math.pi))].mean(0)
513:     pc["group"] = "belt"
514:     return pc, front
515:
516:
517: def sword(fit, hand="R", blade_len=0.80, blade_w=0.042, grip_len=0.15, hilt="gold", grip="leather"):
518:     """A one-handed sword held in the fist. In the hand's frame the fingers run along +x (right
519:     hand), the palm faces -y and the fist's hole runs front-back (z): the blade leaves the thumb
520:     side, pointing forward. Rigid on the hand bone."""
521:     M = fit.world[f"J_Bip_{hand}_Hand"]
522:     R, o = M[:3, :3], M[:3, 3]
523:     R = R / np.linalg.norm(R, axis=0)               # the hand bone may be scaled (body proportions)
524:     sx = 1 if hand == "R" else -1
525:     fist = o + R @ np.array([sx * 0.045, -0.018, 0.0])
526:     fwd = R @ np.array([0, 0, -1.0])
527:     side = R @ np.array([sx * 1.0, 0, 0])
528:     flat = np.cross(fwd, side)
529:     out = [tube("grip", grip, fist - fwd * grip_len * 0.55, fwd, grip_len, 0.0135),
530:            ball("pommel", hilt, fist - fwd * (grip_len * 0.55 + 0.012), 0.02)]
531:     guard_c = fist + fwd * (grip_len * 0.45 + 0.008)
532:     out.append(box("guard", hilt, guard_c, (side, flat, fwd), (0.095, 0.014, 0.012)))
533:     base = guard_c + fwd * 0.012
534:     rows = 12
535:     P = np.zeros((5, rows, 3))
536:     for j, t in enumerate(np.linspace(0, 1, rows)):
537:         taper = 1.0 if t < 0.82 else max(0.0, (1 - t) / 0.18)
538:         w = blade_w / 2 * (1 - 0.15 * t) * taper
539:         th = 0.0045 * taper
540:         c = base + fwd * blade_len * t
541:         P[:, j] = [c + side * w, c + flat * th, c - side * w, c - flat * th, c + side * w]
542:     pos, tri = grid_mesh(P)
543:     out.append(piece("blade", "steel", pos, tri, outward_from=base + fwd * blade_len / 2, axis=fwd))
544:     out.append(ribbon("fuller", "metal", [base + fwd * blade_len * t + flat * 0.0047 for t in np.linspace(0.04, 0.7, 10)],
545:                       width=blade_w * 0.18, lift=0.0005, normals=np.tile(flat, (10, 1))))
546:     for pc in out:
547:         fit.bind(pc, rigid=f"J_Bip_{hand}_Hand")
548:     return out
549:
550:
agent
+6:36reasoning
The code checks for certain keys within a configuration object (c) and adds an "arm_out" entry to the "shape" dictionary under specific conditions. Specifically, if keys "mh", "qt", "mass", or "cage" are present and "arm_out" is not already in the "shape" dictionary, and if a condition ARMORY is false, it proceeds to add "arm_out". This is conditionally adding a field based on config keys and another boolean condition.
read_file{"EndLine":120,"Path":"~/work/lowmarch/tools/poses.py","StartLine":1}
input
{ "EndLine": 120, "Path": "~/work/lowmarch/tools/poses.py", "StartLine": 1 }result, 116 lines
Showing lines 1-115 of 115
1: """Poses for VRoid skeletons: bone name -> 3x3 rotation applied in the bone's own (rest) frame.
2:
3: Rest pose is a T-pose with identity bone rotations, so local axes start aligned with the model:
4: x = character's left is -x, y up, the character faces -z. For the RIGHT arm the bones run along
5: +x and the palm faces -y; for the LEFT arm along -x.
6: """
7: import math
8:
9: import numpy as np
10:
11:
12: def rot(axis, deg):
13:     a = math.radians(deg)
14:     c, s = math.cos(a), math.sin(a)
15:     x, y, z = np.asarray(axis, float) / np.linalg.norm(axis)
16:     return np.array([[c + x * x * (1 - c), x * y * (1 - c) - z * s, x * z * (1 - c) + y * s],
17:                      [y * x * (1 - c) + z * s, c + y * y * (1 - c), y * z * (1 - c) - x * s],
18:                      [z * x * (1 - c) - y * s, z * y * (1 - c) + x * s, c + z * z * (1 - c)]])
19:
20:
21: def as4(r):
22:     r = np.asarray(r, float)
23:     if r.shape == (4, 4):
24:         return r
25:     m = np.eye(4)
26:     m[:3, :3] = r
27:     return m
28:
29:
30: def move(dx=0.0, dy=0.0, dz=0.0, r=None):
31:     """A 4x4 adjustment: translate (in the bone's parent frame units, metres) and optionally rotate."""
32:     m = as4(np.eye(3) if r is None else r)
33:     m[:3, 3] = (dx, dy, dz)
34:     return m
35:
36:
37: def merge(*poses):
38:     out = {}
39:     for p in poses:
40:         for k, r in p.items():
41:             out[k] = as4(out[k]) @ as4(r) if k in out else r
42:     return out
43:
44:
45: def fist(side, curl=(70, 85, 55), thumb=35):
46:     """Curl the fingers of one hand toward the palm (a grip)."""
47:     sz = -1 if side == "R" else 1               # rotation about local z that bends toward -y
48:     out = {}
49:     for f in ("Index", "Middle", "Ring", "Little"):
50:         for i, a in enumerate(curl, 1):
51:             out[f"J_Bip_{side}_{f}{i}"] = rot((0, 0, 1), sz * a)
52:     out[f"J_Bip_{side}_Thumb2"] = rot((0, 1, 0), (1 if side == "R" else -1) * thumb)
53:     out[f"J_Bip_{side}_Thumb3"] = rot((0, 0, 1), sz * 30)
54:     return out
55:
56:
57: # Bust: arms down from the T-pose, shoulders relaxed.
58: BUST = {"J_Bip_L_UpperArm": rot((0, 0, 1), 72), "J_Bip_R_UpperArm": rot((0, 0, 1), -72),
59:         "J_Bip_L_Shoulder": rot((0, 0, 1), 6), "J_Bip_R_Shoulder": rot((0, 0, 1), -6)}
60:
61: # Battle idle: sword in the right hand held forward, left arm loose, feet apart.
62: BATTLE_IDLE = merge(BUST, {
63:     "J_Bip_R_UpperArm": rot((0, 1, 0), 18),       # swing the right arm a little forward
64:     "J_Bip_R_LowerArm": rot((0, 1, 0), 55),       # bend the elbow, forearm forward
65:     "J_Bip_R_Hand": rot((1, 0, 0), -20),          # tip the blade up a little
66:     "J_Bip_L_LowerArm": rot((0, 1, 0), -20),
67:     "J_Bip_L_UpperLeg": rot((0, 0, 1), -5) @ rot((1, 0, 0), 8),
68:     "J_Bip_R_UpperLeg": rot((0, 0, 1), 5) @ rot((1, 0, 0), -10),
69:     "J_Bip_R_LowerLeg": rot((1, 0, 0), 12),
70: }, fist("R"), fist("L", curl=(25, 35, 20), thumb=10))
71:
72:
73: # ---- battle clips: (time in seconds, pose) keyframes ------------------------------------------------------------
74: # Signs (VRoid rest frame): the character faces -z. For the right arm, rot_z(+) raises it,
75: # rot_y(+) swings it forward. For legs, rot_x(+) swings the leg forward, rot_x(-) on a lower leg
76: # bends the knee. For the spine, rot_y(+) turns the shoulders toward the left (the attack side),
77: # rot_x(-) leans forward.
78: WIND_UP = merge(BATTLE_IDLE, {
79:     "J_Bip_C_Hips": move(0, -0.02, 0.05),
80:     "J_Bip_C_Spine": rot((0, 1, 0), -22),
81:     "J_Bip_C_Chest": rot((1, 0, 0), 4),
82:     "J_Bip_R_UpperArm": rot((0, 0, 1), 95) @ rot((0, 1, 0), -40),
83:     "J_Bip_R_LowerArm": rot((0, 1, 0), 45),
84:     "J_Bip_R_Hand": rot((1, 0, 0), 25),
85:     "J_Bip_L_UpperArm": rot((0, 1, 0), -25),
86:     "J_Bip_L_UpperLeg": rot((1, 0, 0), 12),
87:     "J_Bip_R_LowerLeg": rot((1, 0, 0), -14),
88: })
89: SLASH = merge(BATTLE_IDLE, {
90:     "J_Bip_C_Hips": move(0, -0.07, -0.30),
91:     "J_Bip_C_Spine": rot((0, 1, 0), 26),
92:     "J_Bip_C_Chest": rot((1, 0, 0), -12),
93:     "J_Bip_R_UpperArm": rot((0, 0, 1), 30) @ rot((0, 1, 0), 70),
94:     "J_Bip_R_LowerArm": rot((0, 1, 0), -50),
95:     "J_Bip_R_Hand": rot((1, 0, 0), 15),
96:     "J_Bip_L_UpperArm": rot((0, 1, 0), -35) @ rot((0, 0, 1), -10),
97:     "J_Bip_L_UpperLeg": rot((1, 0, 0), 38),
98:     "J_Bip_L_LowerLeg": rot((1, 0, 0), -40),
99:     "J_Bip_R_UpperLeg": rot((1, 0, 0), -30),
100:     "J_Bip_R_LowerLeg": rot((1, 0, 0), -12),
101: })
102: FOLLOW = merge(SLASH, {
103:     "J_Bip_C_Spine": rot((0, 1, 0), 14),
104:     "J_Bip_R_UpperArm": rot((0, 0, 1), -40) @ rot((0, 1, 0), 15),
105:     "J_Bip_R_LowerArm": rot((0, 1, 0), -10),
106:     "J_Bip_R_Hand": rot((1, 0, 0), 25),
107: })
108: IDLE_BREATH = merge(BATTLE_IDLE, {"J_Bip_C_Chest": rot((1, 0, 0), -2.5), "J_Bip_R_UpperArm": rot((0, 0, 1), 3),
109:                                   "J_Bip_C_Hips": move(0, -0.008, 0)})
110:
111: CLIPS = {
112:     "idle": [(0.0, BATTLE_IDLE), (0.9, IDLE_BREATH), (1.8, BATTLE_IDLE)],
113:     "attack": [(0.0, BATTLE_IDLE), (0.32, WIND_UP), (0.44, WIND_UP), (0.56, SLASH), (0.68, FOLLOW), (1.05, FOLLOW),
114:                (1.5, BATTLE_IDLE)],
115: }
agent
+6:47reasoning
The code defines the rest pose with specific axis orientations: character's left aligns with -x, up is y, and the character faces -z. This implies a particular coordinate system convention is used within the model. This orientation explains why the character's facing direction appears inverted along the z-axis.
The arm bone orientations appear to be key: right arm along +x, palm facing -y; left arm along -x. The VRM files represent a VRoid 2 T-pose with identity bone rotations, matching the expected skeleton convention. There's a coordinate flip happening: the +x direction in the original VRoid model becomes -x after processing, impacting the arm bone directions.
The BUST_POSE aligns with arm positions and garment fitting, which suggests a direct method for generating animations with specific poses. A key question arises: has this configuration, combining BUST_POSE, costume application, and animation generation, ever been tested on caged VRoid 2 models? The existing codebase shows that while this combination was theoretically possible, it has never actually been implemented with real costumes, weapons, combat stances, or battle stages. This suggests a significant gap in the current implementation.
run_command{"CommandLine":"python3 -c '\nimport sys\nsys.path[:0] = [\"tools\", \"art/cast\"]\nimport cage, vroid_portrait as vp\nfrom cast import CAST\nfor name in (\"arm_f_strong\", \"arm_f_slender\", \"arm_f_average\", \"arm_m_heroic\"):\n p = cage.path_for(name, CAST[name][\"cage\"])\n v = vp.VRM(p)\n mats = [m[\"name\"] for m in v.j[\"materials\"]]\n print(name, \"mats:\", [(m, vp.role_of(m)) for m in mats])\n'","WaitMsBeforeAsync":5000,"toolSummary":"Inspect materials and roles on cached cage VRMs"}
input
{ "CommandLine": "python3 -c '\nimport sys\nsys.path[:0] = [\"tools\", \"art/cast\"]\nimport cage, vroid_portrait as vp\nfrom cast import CAST\nfor name in (\"arm_f_strong\", \"arm_f_slender\", \"arm_f_average\", \"arm_m_heroic\"):\n p = cage.path_for(name, CAST[name][\"cage\"])\n v = vp.VRM(p)\n mats = [m[\"name\"] for m in v.j[\"materials\"]]\n print(name, \"mats:\", [(m, vp.role_of(m)) for m in mats])\n'", "WaitMsBeforeAsync": 5000, "toolSummary": "Inspect materials and roles on cached cage VRMs" }result, 7 lines
Command exited with code 0.

Command output:
arm_f_strong mats: [('N00_000_00_FaceMouth_00_FACE (Instance)', 'mouth'), ('N00_000_00_EyeIris_00_EYE (Instance)', 'iris'), ('N00_000_00_EyeHighlight_00_EYE (Instance)', 'highlight'), ('N00_000_00_Face_00_SKIN (Instance)', 'face'), ('N00_000_00_EyeWhite_00_EYE (Instance)', 'white'), ('N00_000_00_FaceBrow_00_FACE (Instance)', 'brow'), ('N00_000_00_FaceEyeline_00_FACE (Instance)', 'line'), ('N00_000_00_Body_00_SKIN (Instance)', 'body'), ('N00_000_00_HairBack_00_HAIR (Instance)', 'hair'), ('N00_000_Hair_00_HAIR lm', 'hair'), ('N00_000_00_HairBack_00_HAIR lm', 'hair'), ('N00_000_00_FaceEyelash_00_FACE (Instance)', 'line')]
arm_f_slender mats: [('N00_000_00_FaceMouth_00_FACE (Instance)', 'mouth'), ('N00_000_00_EyeIris_00_EYE (Instance)', 'iris'), ('N00_000_00_EyeHighlight_00_EYE (Instance)', 'highlight'), ('N00_000_00_Face_00_SKIN (Instance)', 'face'), ('N00_000_00_EyeWhite_00_EYE (Instance)', 'white'), ('N00_000_00_FaceBrow_00_FACE (Instance)', 'brow'), ('N00_000_00_FaceEyeline_00_FACE (Instance)', 'line'), ('N00_000_00_Body_00_SKIN (Instance)', 'body'), ('N00_000_00_HairBack_00_HAIR (Instance)', 'hair'), ('N00_000_Hair_00_HAIR lm', 'hair'), ('N00_000_00_HairBack_00_HAIR lm', 'hair'), ('N00_000_00_FaceEyelash_00_FACE (Instance)', 'line')]
arm_f_average mats: [('N00_000_00_FaceMouth_00_FACE (Instance)', 'mouth'), ('N00_000_00_EyeIris_00_EYE (Instance)', 'iris'), ('N00_000_00_EyeHighlight_00_EYE (Instance)', 'highlight'), ('N00_000_00_Face_00_SKIN (Instance)', 'face'), ('N00_000_00_EyeWhite_00_EYE (Instance)', 'white'), ('N00_000_00_FaceBrow_00_FACE (Instance)', 'brow'), ('N00_000_00_FaceEyeline_00_FACE (Instance)', 'line'), ('N00_000_00_Body_00_SKIN (Instance)', 'body'), ('N00_000_00_HairBack_00_HAIR (Instance)', 'hair'), ('N00_000_Hair_00_HAIR_01 lm', 'hair'), ('N00_000_Hair_00_HAIR_02 lm', 'hair'), ('N00_000_Hair_00_HAIR_03 lm', 'hair'), ('N00_000_Hair_00_HAIR_04 lm', 'hair')]
arm_m_heroic mats: [('N00_000_00_FaceMouth_00_FACE (Instance)', 'mouth'), ('N00_000_00_EyeIris_00_EYE (Instance)', 'iris'), ('N00_000_00_EyeHighlight_00_EYE (Instance)', 'highlight'), ('N00_000_00_Face_00_SKIN (Instance)', 'face'), ('N00_000_00_EyeWhite_00_EYE (Instance)', 'white'), ('N00_000_00_FaceBrow_00_FACE (Instance)', 'brow'), ('N00_000_00_FaceEyeline_00_FACE (Instance)', 'line'), ('N00_000_00_Body_00_SKIN (Instance)', 'body'), ('N00_000_00_HairBack_00_HAIR (Instance)', 'hair'), ('N00_000_Hair_00_HAIR_01 lm', 'hair'), ('N00_000_Hair_00_HAIR_02 lm', 'hair'), ('N00_000_00_HairBack_00_HAIR lm', 'hair')]
agent
+7:11reasoning
All material roles match as expected, confirming the identification of surface components. The presence of "HairBack_00_HAIR lm" in VRoid 2 samples suggests a potential discrepancy in the existing setup. This needs further investigation as to why this particular feature is missing, even though it should already be present.
The hair_case_render.png images continue to show the problematic pale scalp and ears on the test avatar. Examining the hair components, the sample avatar specifically lacks the expected "HairBack" element, which is present in other examples, leading to the observed visual discrepancy; the other samples have HairBack_00_HAIR lm or equivalent. To better understand this visual issue, existing renders from previous character configurations will be compared to identify best practice.
run_command{"CommandLine":"ls -la ~/.local/share/lowmarch/trials/ && ls -la ~/.local/share/lowmarch/trials/reflect-2026-11-08/","WaitMsBeforeAsync":5000,"toolSummary":"List trial directories for reference renders"}
input
{ "CommandLine": "ls -la ~/.local/share/lowmarch/trials/ && ls -la ~/.local/share/lowmarch/trials/reflect-2026-11-08/", "WaitMsBeforeAsync": 5000, "toolSummary": "List trial directories for reference renders" }result, 46 lines
Command exited with code 0.

Command output:
total 36
drwx------  9 runner runner 4096 Nov  8 04:48 .
drwxr-xr-x 13 runner runner 4096 Oct 29 22:09 ..
drwx------  5 runner runner 4096 Oct 30 21:50 combined-2026-10-31
drwx------  3 runner runner 4096 Oct 30 04:22 expressions-2026-10-30
drwx------  4 runner runner 4096 Oct 30 02:31 face-shading-2026-10-30
drwx------  3 runner runner 4096 Oct 29 23:10 flattice-2026-10-30
drwx------  2 runner runner 4096 Oct 31 02:21 hair-research-2026-10-31
drwx------  7 runner runner 4096 Nov  7 19:17 reflect-2026-11-08
drwx------  3 runner runner 4096 Oct 30 02:50 yin-yang-review-2026-10-30
total 9992
drwx------ 7 runner runner    4096 Nov  7 19:17 .
drwx------ 9 runner runner    4096 Nov  8 04:48 ..
-rw------- 1 runner runner    3564 Nov  7 18:54 add_box.py
-rw------- 1 runner runner    4511 Nov  7 18:39 apply.py
-rw------- 1 runner runner  275983 Nov  7 18:54 box_d.png
-rw------- 1 runner runner  200437 Nov  7 18:54 box_p.png
-rw------- 1 runner runner   19916 Nov  7 18:16 clean_16fadb50.txt
-rw------- 1 runner runner   13249 Nov  7 18:16 clean_d2fdcea1.txt
-rw------- 1 runner runner    1004 Nov  7 19:08 closure.py
-rw------- 1 runner runner   88592 Nov  7 18:33 cmp.jpg
-rw------- 1 runner runner    1455 Nov  7 19:05 depgraph.py
drwx------ 3 runner runner    4096 Nov  7 19:10 frame_test
-rw------- 1 runner runner     264 Nov  7 18:32 list_dyn.py
-rw------- 1 runner runner   61062 Nov  7 18:15 owner_16fadb50.txt
-rw------- 1 runner runner   64496 Nov  7 18:15 owner_d2fdcea1.txt
-rw------- 1 runner runner 1654198 Nov  7 18:39 part0.png
-rw------- 1 runner runner  955259 Nov  7 18:39 part1.png
-rw------- 1 runner runner  777952 Nov  7 18:39 part2.png
drwx------ 2 runner runner    4096 Nov  7 18:18 reader
drwx------ 3 runner runner    4096 Nov  7 18:25 research-faces
drwx------ 3 runner runner    4096 Nov  7 18:21 research-hair-cloth
drwx------ 2 runner runner    4096 Nov  7 18:20 research-pipelines
-rw------- 1 runner runner     113 Nov  7 19:13 run_cage.txt
-rw------- 1 runner runner     534 Nov  7 19:13 run_lash.txt
-rw------- 1 runner runner 1858665 Nov  7 18:39 shot_d1.png
-rw------- 1 runner runner 3280923 Nov  7 18:39 shot_full.png
-rw------- 1 runner runner  408602 Nov  7 18:39 shot_phone.png
-rw------- 1 runner runner  135703 Nov  7 18:33 state.jpg
-rw------- 1 runner runner  257789 Nov  7 18:18 state_sheet.jpg
-rw------- 1 runner runner   44671 Nov  7 18:39 template.final.html
-rw------- 1 runner runner   44325 Nov  7 18:38 template.html
-rw------- 1 runner runner    1163 Nov  7 18:15 usermsgs.py
agent
+8:01reasoning
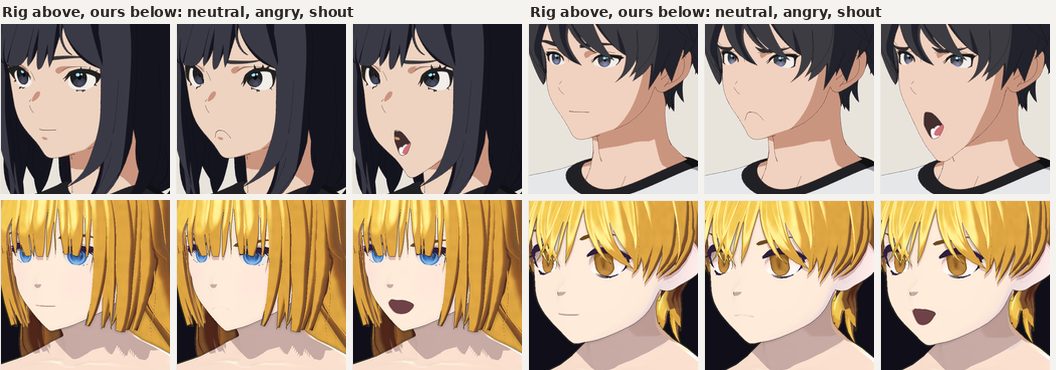
The reflection page contains an image for comparison. Analyzing the image should reveal relevant differences. The comparison likely focuses on whole-character versus bare armory details.
read_file{"Path":"~/.local/share/lowmarch/trials/reflect-2026-11-08/cmp.jpg"}
input
{ "Path": "~/.local/share/lowmarch/trials/reflect-2026-11-08/cmp.jpg" }result, 1 line
Showing binary file of type image/jpeg
step_91_media_0.jpg