A mech game prototype, pushed by GPT-6-Astra
agent
+24:24The page layout needs no further changes. The render is still computing, so I’m waiting for the full-resolution image before completing the final checks.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0036 seconds
Sleep completed.
exec_commandtail -8 review/out/astra/render-64.log && ls -lh ~/out
command
tail -8 review/out/astra/render-64.log && ls -lh ~/out
result, 4 lines
Script completed Wall time 0.0 seconds Output: {"chunk_id":"50d18b","wall_time_seconds":0.00000403,"exit_code":0,"original_token_count":166,"output":"~/work/sortie/tools/astra/render_study.py:64: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:147: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:164: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:197: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n scene.world.use_nodes = True\ntotal 0\n"}sleep{"duration_ms":15000}
input
{ "duration_ms": 15000 }result, 2 lines
Wall time: 15.0046 seconds
Sleep completed.
exec_command, clock__curr_timeps -C blender -o pid,etime,pcpu,rss && tail -4 review/out/astra/render-64.log (+1 more)
input
text(await tools.exec_command({cmd:"ps -C blender -o pid,etime,pcpu,rss && tail -4 review/out/astra/render-64.log","max_output_tokens":1000})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"2bcc96","wall_time_seconds":0.00000456,"exit_code":0,"original_token_count":99,"output":"    PID     ELAPSED %CPU   RSS\n    719       06:17  723 896880\n~/work/sortie/tools/astra/render_study.py:164: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n  air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:197: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n  scene.world.use_nodes = True\n"}{"current_time":"2026-11-15 03:39:50 UTC"}
agent
+26:37The render is still active and has reported no error. I’m keeping the remaining work to visual inspection, offline page checks and the final commit.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0056 seconds
Sleep completed.
exec_commandtail -9 review/out/astra/render-64.log && ls -lh ~/out
command
tail -9 review/out/astra/render-64.log && ls -lh ~/out
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"3c3072","wall_time_seconds":0.00000411,"exit_code":0,"original_token_count":178,"output":"03:33:36 | INFO: glTF import finished in 0.52s\n~/work/sortie/tools/astra/render_study.py:64: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:147: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:164: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:197: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n scene.world.use_nodes = True\ntotal 0\n"}sleep{"duration_ms":15000}
input
{ "duration_ms": 15000 }result, 2 lines
Wall time: 15.0034 seconds
Sleep completed.
agent
+28:37The full-resolution pass is taking longer than the previews suggested. The page and source files are ready, and I’m waiting for a completed image before calling the result finished.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0038 seconds
Sleep completed.
exec_command, clock__curr_timetail -10 review/out/astra/render-64.log && ps -C blender -o etime,pcpu,rss (+1 more)
input
text(await tools.exec_command({cmd:"tail -10 review/out/astra/render-64.log && ps -C blender -o etime,pcpu,rss","max_output_tokens":1000})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"6bc769","wall_time_seconds":0.00000376,"exit_code":1,"original_token_count":214,"output":"~/work/sortie/tools/astra/render_study.py:164: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n  air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:197: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n  scene.world.use_nodes = True\n07:38.585  render           | Saved: '~/out/sortie.png'\nSTUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.20000000298023224], \"pilot_root\": [8.5, -3.0, 0.20000000298023224], \"camera\": [-4.0, -17.0, 2.799999952316284]}\nSTUDY_RESULT {\"elapsed_seconds\": 458.14, \"preview\": false, \"resolution\": [2400, 1800], \"samples\": 64, \"assets\": [\"striker_a.glb\", \"ship.glb\", \"lab_pilot.glb\"], \"output\": \"~/out/sortie.png\"}\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n    ELAPSED %CPU   RSS\n"}{"current_time":"2026-11-15 03:42:47 UTC"}
view_image, exec_command~/out/sortie.png (+1 more)
input
image((await tools.view_image({path:"~/out/sortie.png",detail:"original"})).image_url,"original"); text(await tools.exec_command({cmd:"python tools/astra/build_page.py --work-minutes 32 && node tools/astra/check_page.mjs","yield_time_ms":1000,"max_output_tokens":3000}));result, 4 lines
Script completed
Wall time 1.3 seconds
Output:
{"chunk_id":"14d4db","wall_time_seconds":1.001050939,"session_id":78374,"original_token_count":13,"output":"Page: ~/out/index.html (22,309 bytes)\n"}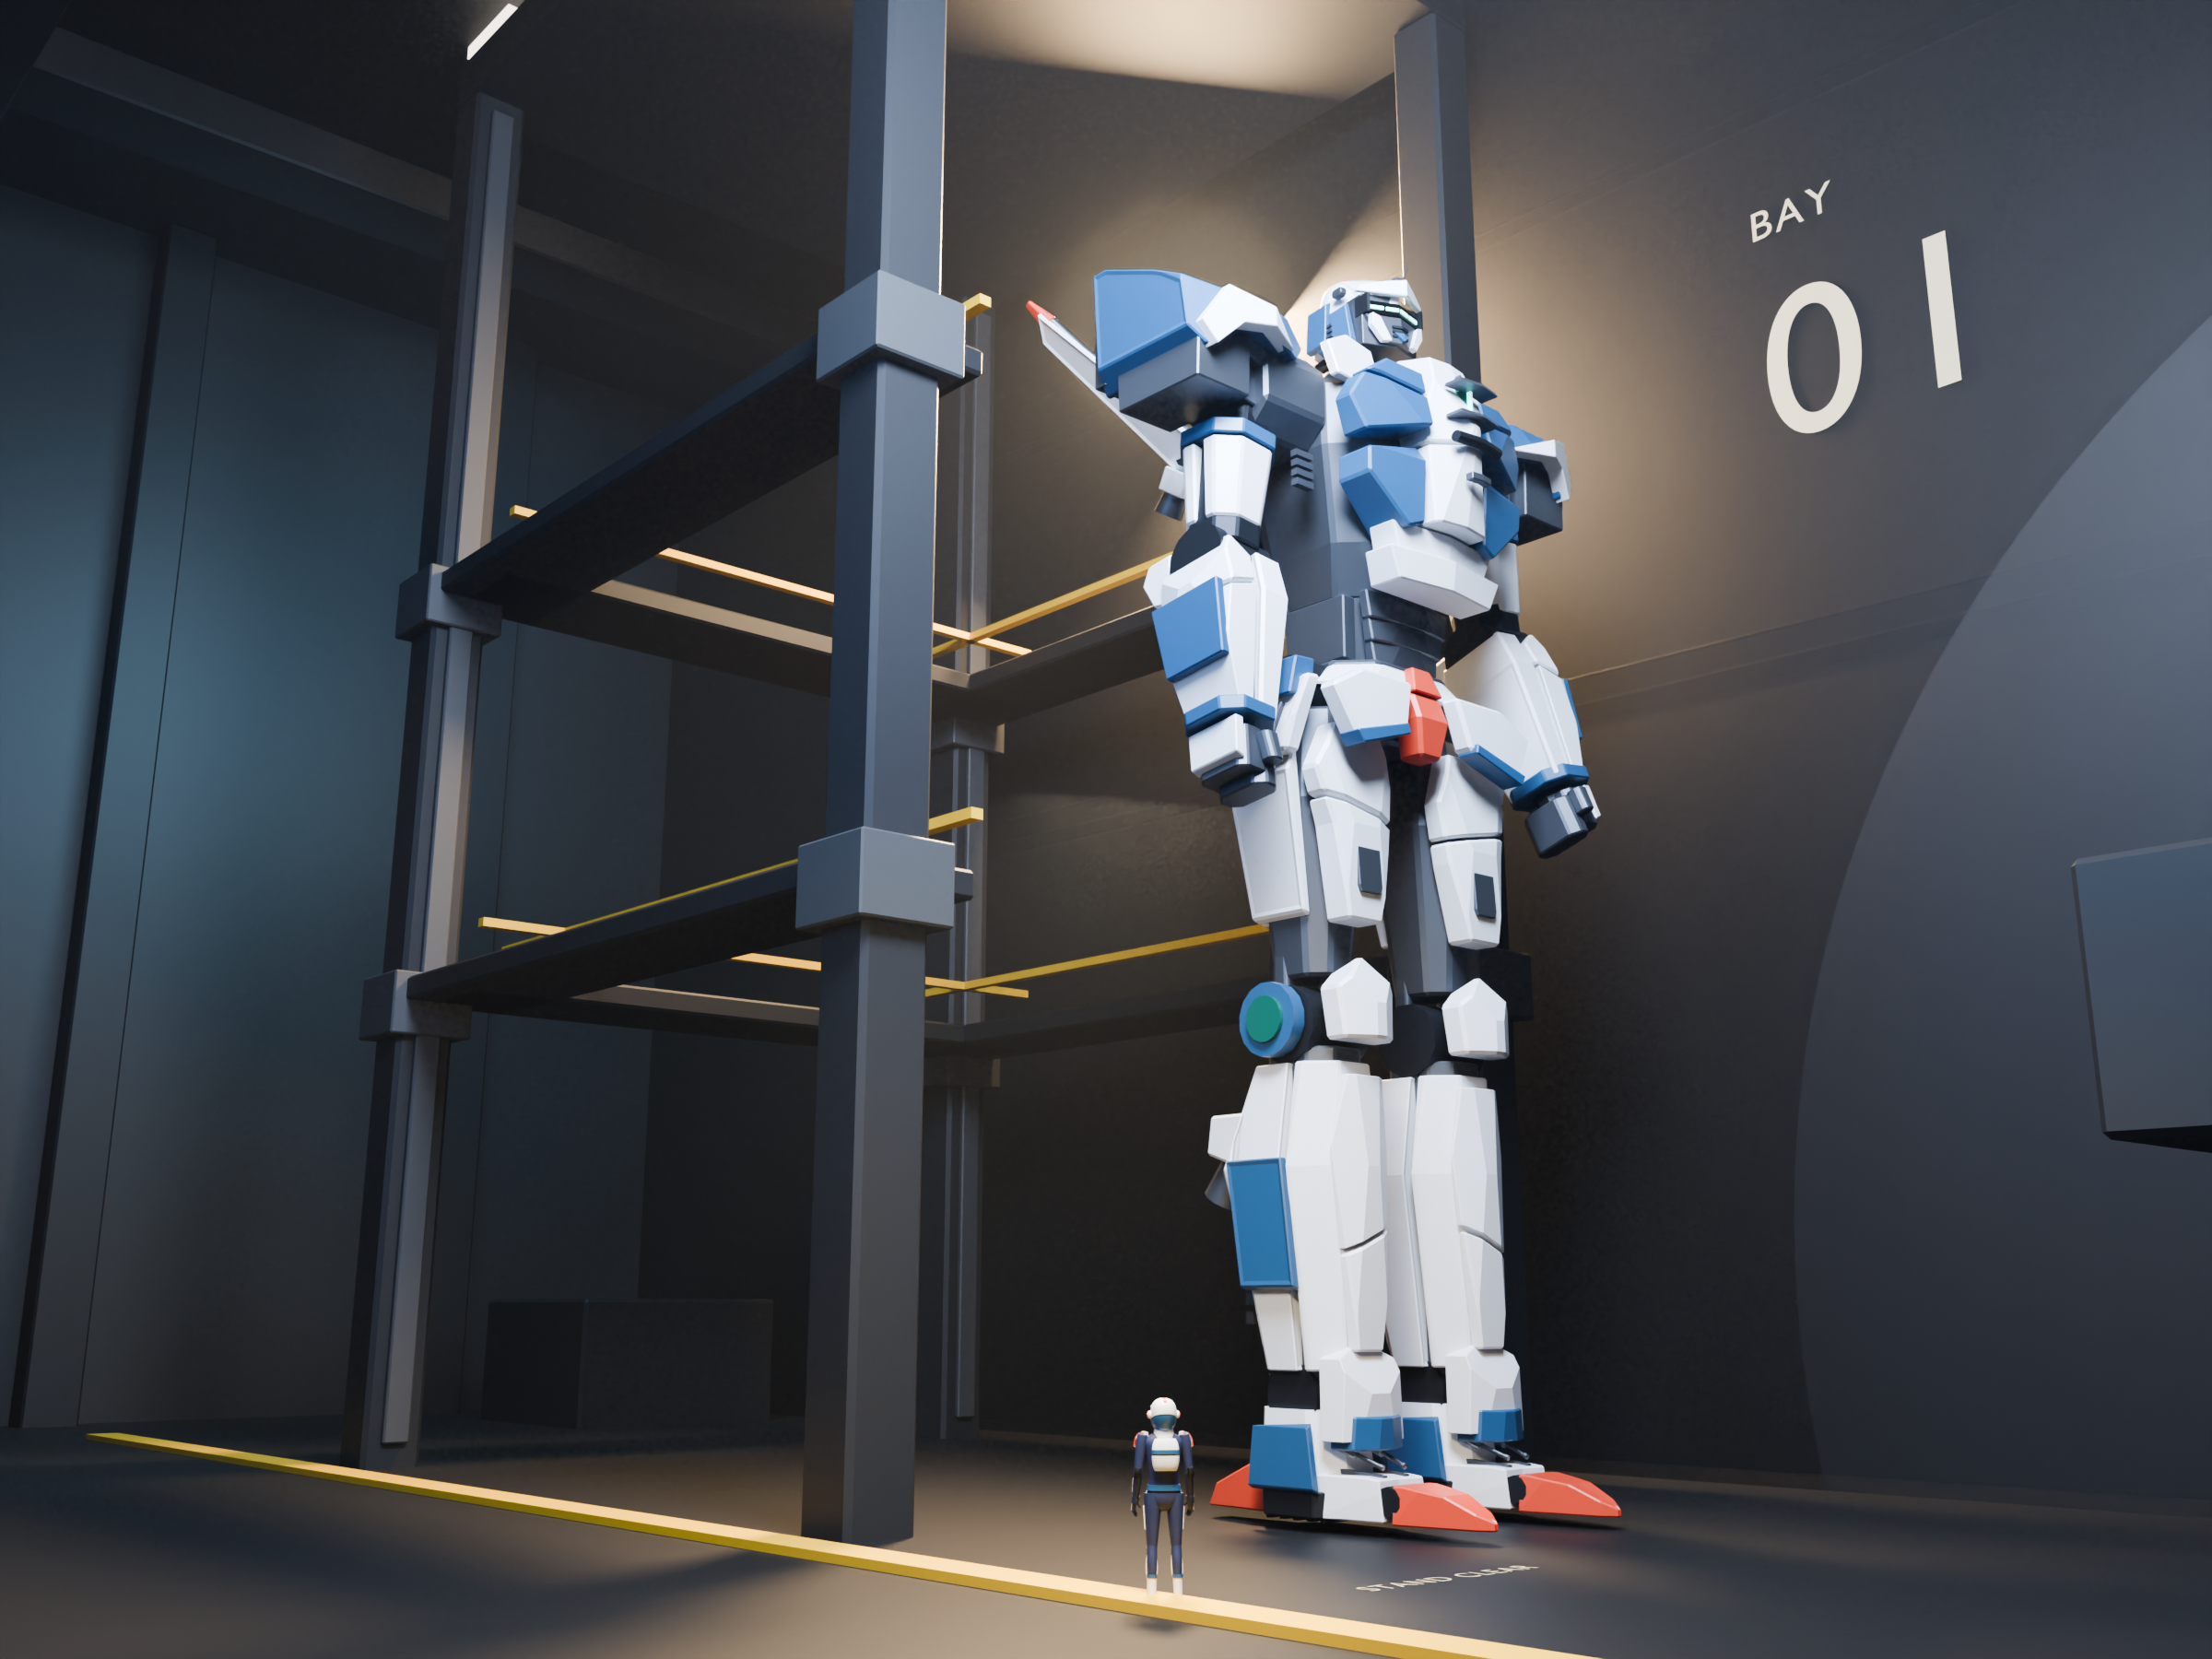
sortie.png write_stdin, exec_commandpoll session 78374 (+1 more)
input
text(await tools.write_stdin({session_id:78374,chars:"","yield_time_ms":1000,"max_output_tokens":3000})); text(await tools.exec_command({cmd:"~/.local/bin/blender -b --factory-startup -t 2 --python-expr \"from pathlib import Path; p=Path('tools/astra/render_study.py').resolve(); scope={'__file__':str(p)}; exec(compile(p.read_text().split('bpy.ops.render.render(write_still=True)')[0],str(p),'exec'),scope); import json; from mathutils import Vector; print('CONTACTS', json.dumps({label:min((o.matrix_world @ Vector(c)).z for o in objects.values() if o.type=='MESH' and not o.hide_render for c in o.bound_box) for label,objects in [('pilot',scope['pilot']),('mech',scope['mech'])]}))\" > review/out/astra/contacts.log 2>&1","yield_time_ms":1000,"max_output_tokens":1000}));result, 4 lines
Script completed
Wall time 1.2 seconds
Output:
{"chunk_id":"d56c0b","wall_time_seconds":0.00000262,"exit_code":1,"original_token_count":190,"output":"{\n  \"results\": [\n    {\n      \"label\": \"desktop\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    },\n    {\n      \"label\": \"phone\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    }\n  ],\n  \"failures\": [\n    \"desktop: details did not open\",\n    \"phone: details did not open\"\n  ]\n}\n"}{"chunk_id":"30e3e7","wall_time_seconds":1.001435054,"session_id":41830,"original_token_count":0,"output":""}
agent
+30:43The image is complete. The offline checks confirm the image, font and responsive layout, but the methods check needs a correction in my test code. I’m also checking the pilot’s contact with the deck after spotting an ambiguous foot shadow at full size.
exec_command, apply_patchtail -10 review/out/astra/contacts.log (+2 more)
input
text(await tools.exec_command({cmd:"tail -10 review/out/astra/contacts.log","max_output_tokens":1500})); text(await tools.apply_patch("*** Begin Patch\n*** Update File: ~/work/sortie/tools/astra/check_page.mjs\n@@\n- if (!await page.locator('details').evaluate('el => el.open')) failures.push(`${label}: details did not open`);\n+ if (!await page.evaluate('document.querySelector(\"details\").open')) failures.push(`${label}: details did not open`);\n*** End Patch")); text(await tools.exec_command({cmd:"node tools/astra/check_page.mjs","yield_time_ms":1000,"max_output_tokens":2000}));result, 4 lines
Script completed
Wall time 1.2 seconds
Output:
{"chunk_id":"171425","wall_time_seconds":0.00000385,"exit_code":0,"original_token_count":151,"output":"03:43:43 | INFO: Blender create Mesh node pilot_upperarm_R_main.001\n03:43:43 | INFO: Blender create Mesh node pilot_upperarm_R_suit.001\n03:43:43 | INFO: Blender create Mesh node pilot_upperarm_R_trim.001\n03:43:43 | INFO: Blender create Mesh node plinth.001\n03:43:43 | INFO: glTF import finished in 0.40s\nSTUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.20000000298023224], \"pilot_root\": [8.5, -3.0, 0.20000000298023224], \"camera\": [-4.0, -17.0, 2.799999952316284]}\nCONTACTS {\"pilot\": 0.2015957534313202, \"mech\": 0.3199997842311859}\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n"}{}{"chunk_id":"8a0759","wall_time_seconds":1.001701186,"session_id":60526,"original_token_count":0,"output":""}
apply_patch, exec_command, write_stdinapply_patch (+2 more)
input
text(await tools.apply_patch("*** Begin Patch\n*** Update File: ~/work/sortie/tools/astra/render_study.py\n@@\n-pilot['lab'].location = (8.5, -3, .2)\n+pilot['lab'].location = (7.6, -3, .2)\n pilot['lab'].rotation_mode = 'XYZ'\n pilot['lab'].rotation_euler.z = math.radians(145)\n+\n+\n+def ground(objects, root, deck_z=.2):\n+ \"\"\"Place actual sole vertices on the deck, independent of an asset's origin.\"\"\"\n+ bpy.context.view_layer.update()\n+ lowest = min((o.matrix_world @ v.co).z for o in objects.values()\n+ if o.type == 'MESH' and not o.hide_render for v in o.data.vertices)\n+ root.location.z += deck_z - lowest\n+ bpy.context.view_layer.update()\n+\n+\n+ground(mech, root)\n+ground(pilot, pilot['lab'])\n recolor()\n*** End Patch")); text(await tools.exec_command({cmd:"~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py > review/out/astra/render-final.log 2>&1","yield_time_ms":1000,"max_output_tokens":1000})); text(await tools.write_stdin({session_id:60526,chars:"","yield_time_ms":1000,"max_output_tokens":2500}));result, 4 lines
Script completed
Wall time 1.2 seconds
Output:
{}{"chunk_id":"41f310","wall_time_seconds":1.001267007,"session_id":24146,"original_token_count":0,"output":""}{"chunk_id":"8e2e6f","wall_time_seconds":0.000002,"exit_code":0,"original_token_count":171,"output":"{\n  \"results\": [\n    {\n      \"label\": \"desktop\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    },\n    {\n      \"label\": \"phone\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    }\n  ],\n  \"failures\": []\n}\n"}
agent
+31:47The deck check found a 12 cm gap beneath the mech’s soles. I’ve corrected its placement and moved the pilot off the raised yellow strip, then started the corrected render. The offline page checks now all pass, including the expandable methods.
exec_command~/.local/bin/blender -b --factory-startup -t 2 --python-expr "from pathlib import Path; p=Path('tools/astra/render_study.py').resolve(); scope={'__file__':str(p)}; exec(compile(p.read_text().split('bpy.ops.render.render(write_still=True)')[0],str(p),'exec'),scope); import json; points={label:[o.matrix_world @ v.co for o in objects.values() if o.type=='MESH' and not o.hide_render for v in o.data.vertices] for label,objects in [('pilot',scope['pilot']),('mech',scope['mech'])]}; contacts={label:min(v.z for v in vs) for label,vs in points.items()}; assert all(abs(z-.2)<.00001 for z in contacts.values()),contacts; print('CONTACTS_OK',json.dumps(contacts)); foot=[o.matrix_world @ v.co for o in scope['pilot'].values() if 'foot' in o.name and o.type=='MESH' and not o.hide_render for v in o.data.vertices]; assert max(v.x for v in foot)<8.4; print('PILOT_FEET_CLEAR_OF_STRIP',min(v.x for v in foot),max(v.x for v in foot))" > review/out/astra/contacts-final.log 2>&1 (+1 more)
command
~/.local/bin/blender -b --factory-startup -t 2 --python-expr "from pathlib import Path; p=Path('tools/astra/render_study.py').resolve(); scope={'__file__':str(p)}; exec(compile(p.read_text().split('bpy.ops.render.render(write_still=True)')[0],str(p),'exec'),scope); import json; points={label:[o.matrix_world @ v.co for o in objects.values() if o.type=='MESH' and not o.hide_render for v in o.data.vertices] for label,objects in [('pilot',scope['pilot']),('mech',scope['mech'])]}; contacts={label:min(v.z for v in vs) for label,vs in points.items()}; assert all(abs(z-.2)<.00001 for z in contacts.values()),contacts; print('CONTACTS_OK',json.dumps(contacts)); foot=[o.matrix_world @ v.co for o in scope['pilot'].values() if 'foot' in o.name and o.type=='MESH' and not o.hide_render for v in o.data.vertices]; assert max(v.x for v in foot)<8.4; print('PILOT_FEET_CLEAR_OF_STRIP',min(v.x for v in foot),max(v.x for v in foot))" > review/out/astra/contacts-final.log 2>&1 node --check tools/astra/check_page.mjs && python - <<'PY' import ast from pathlib import Path for p in Path('tools/astra').glob('*.py'): ast.parse(p.read_text()) print('Study source syntax passes.') PYresult, 4 lines
Script completed
Wall time 1.4 seconds
Output:
{"chunk_id":"425f1f","wall_time_seconds":1.004705391,"session_id":93332,"original_token_count":0,"output":""}{"chunk_id":"e5486a","wall_time_seconds":0.000679143,"exit_code":0,"original_token_count":7,"output":"Study source syntax passes.\n"}
exec_command, clock__curr_timetail -6 review/out/astra/contacts-final.log && cat review/out/astra/page-checks.json (+1 more)
input
text(await tools.exec_command({cmd:"tail -6 review/out/astra/contacts-final.log && cat review/out/astra/page-checks.json","max_output_tokens":1500})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"4b91fb","wall_time_seconds":0.0000038,"exit_code":0,"original_token_count":266,"output":"STUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.08000022172927856], \"pilot_root\": [7.599999904632568, -3.0, 0.1984042525291443], \"camera\": [-4.0, -17.0, 2.799999952316284]}\nCONTACTS_OK {\"pilot\": 0.20000000298023224, \"mech\": 0.19999989867210388}\nPILOT_FEET_CLEAR_OF_STRIP 7.865583896636963 8.273837089538574\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n{\n  \"results\": [\n    {\n      \"label\": \"desktop\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    },\n    {\n      \"label\": \"phone\",\n      \"title\": \"Sortie · Before boarding · Astra study\",\n      \"overflow\": false,\n      \"images\": [\n        {\n          \"loaded\": true,\n          \"alt\": true\n        }\n      ],\n      \"font\": true,\n      \"identity\": true,\n      \"emDash\": false,\n      \"pending\": false,\n      \"h1\": 1\n    }\n  ],\n  \"failures\": []\n}\n"}{"current_time":"2026-11-15 03:45:58 UTC"}
agent
+32:48The geometry check now confirms both figures touch the deck and the pilot’s feet clear the raised strip. The corrected image is rendering. The page’s offline checks have no remaining failures.
apply_patch, exec_commandapply_patch (+1 more)
input
text(await tools.apply_patch("*** Begin Patch\n*** Update File: ~/work/sortie/tools/astra/README.md\n@@\n-python tools/astra/build_page.py --work-minutes 20\n+python tools/astra/build_page.py --work-minutes 42\n@@\n - `public/assets/lab_pilot.glb`: standing pilot only, at the authored scale, turned toward the mech.\n+- Both figures are placed from their lowest visible mesh vertex onto the 0.2 m deck surface.\n+ The pilot stands clear of the raised yellow strip.\n@@\n-The source syntax and page are checked directly. No full test suite is needed for this isolated\n+The source syntax, deck contacts and page are checked directly. No full test suite is needed for this isolated\n*** End Patch")); text(await tools.exec_command({cmd:"git add tools/astra && git diff --cached --check && git diff --cached --stat","max_output_tokens":1500}));result, 4 lines
Script completed Wall time 0.1 seconds Output: {}{"chunk_id":"d3d7f1","wall_time_seconds":0.00000504,"exit_code":0,"original_token_count":76,"output":" tools/astra/README.md | 53 +++++++++\n tools/astra/build_page.py | 24 +++++\n tools/astra/check_page.mjs | 47 ++++++++\n tools/astra/page.html | 113 +++++++++++++++++++\n tools/astra/render_study.py | 256 ++++++++++++++++++++++++++++++++++++++++++++\n 5 files changed, 493 insertions(+)\n"}sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0054 seconds
Sleep completed.
exec_command, clock__curr_timeps -C blender -o etime,pcpu,rss && tail -3 review/out/astra/render-final.log (+1 more)
input
text(await tools.exec_command({cmd:"ps -C blender -o etime,pcpu,rss && tail -3 review/out/astra/render-final.log","max_output_tokens":1000})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"c716b5","wall_time_seconds":0.00000381,"exit_code":0,"original_token_count":60,"output":"    ELAPSED %CPU   RSS\n      02:53  722 864944\n  air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:210: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n  scene.world.use_nodes = True\n"}{"current_time":"2026-11-15 03:47:28 UTC"}
agent
+34:13The reproduction scripts are staged, with syntax and whitespace checks passing. Once the corrected image finishes, I’ll inspect it, refresh the recorded wall time and commit the study.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0027 seconds
Sleep completed.
agent
+35:37The corrected render is still computing. The previous completed pass took 7 minutes 38 seconds, so I expect a few more minutes before the final inspection.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0099 seconds
Sleep completed.
exec_commandtail -4 review/out/astra/render-final.log && ps -C blender -o etime,pcpu,rss
command
tail -4 review/out/astra/render-final.log && ps -C blender -o etime,pcpu,rss
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"abdd0b","wall_time_seconds":0.00000381,"exit_code":0,"original_token_count":95,"output":"~/work/sortie/tools/astra/render_study.py:177: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:210: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n scene.world.use_nodes = True\n ELAPSED %CPU RSS\n 05:12 709 864948\n"}sleep{"duration_ms":15000}
input
{ "duration_ms": 15000 }result, 2 lines
Wall time: 15.0065 seconds
Sleep completed.
agent
+37:38The corrected render is still active. The geometry and page checks are complete; the remaining check is whether the finished image reads cleanly at full resolution.
sleep{"duration_ms":45000}
input
{ "duration_ms": 45000 }result, 2 lines
Wall time: 45.0038 seconds
Sleep completed.
exec_command, clock__curr_timetail -9 review/out/astra/render-final.log && ps -C blender -o etime,pcpu,rss (+1 more)
input
text(await tools.exec_command({cmd:"tail -9 review/out/astra/render-final.log && ps -C blender -o etime,pcpu,rss","max_output_tokens":1000})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"c8ed94","wall_time_seconds":0.00000451,"exit_code":0,"original_token_count":188,"output":"03:44:37 | INFO: glTF import finished in 0.35s\n~/work/sortie/tools/astra/render_study.py:64: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:160: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:177: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n air.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:210: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n scene.world.use_nodes = True\n ELAPSED %CPU RSS\n 07:12 698 900540\n"}{"current_time":"2026-11-15 03:51:47 UTC"}sleep{"duration_ms":30000}
input
{ "duration_ms": 30000 }result, 2 lines
Wall time: 30.0028 seconds
Sleep completed.
exec_commandtail -8 review/out/astra/render-final.log && cat review/out/astra/render.json
command
tail -8 review/out/astra/render-final.log && cat review/out/astra/render.json
result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
{"chunk_id":"7b99c8","wall_time_seconds":0.000005,"exit_code":0,"original_token_count":228,"output":"~/work/sortie/tools/astra/render_study.py:210: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n  scene.world.use_nodes = True\n07:47.836  render           | Saved: '~/out/sortie.png'\nSTUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.08000022172927856], \"pilot_root\": [7.599999904632568, -3.0, 0.1984042525291443], \"camera\": [-4.0, -17.0, 2.799999952316284]}\nSTUDY_RESULT {\"elapsed_seconds\": 467.52, \"preview\": false, \"resolution\": [2400, 1800], \"samples\": 64, \"assets\": [\"striker_a.glb\", \"ship.glb\", \"lab_pilot.glb\"], \"output\": \"~/out/sortie.png\"}\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n{\n  \"elapsed_seconds\": 467.52,\n  \"preview\": false,\n  \"resolution\": [\n    2400,\n    1800\n  ],\n  \"samples\": 64,\n  \"assets\": [\n    \"striker_a.glb\",\n    \"ship.glb\",\n    \"lab_pilot.glb\"\n  ],\n  \"output\": \"~/out/sortie.png\"\n}\n"}
view_image, exec_command~/out/sortie.png (+1 more)
input
image((await tools.view_image({path:"~/out/sortie.png"})).image_url); text(await tools.exec_command({cmd:"python tools/astra/build_page.py --work-minutes 42 && node tools/astra/check_page.mjs","yield_time_ms":1000,"max_output_tokens":3000}));result, 4 lines
Script completed
Wall time 1.3 seconds
Output:
{"chunk_id":"482d30","wall_time_seconds":1.001089566,"session_id":80460,"original_token_count":13,"output":"Page: ~/out/index.html (22,309 bytes)\n"}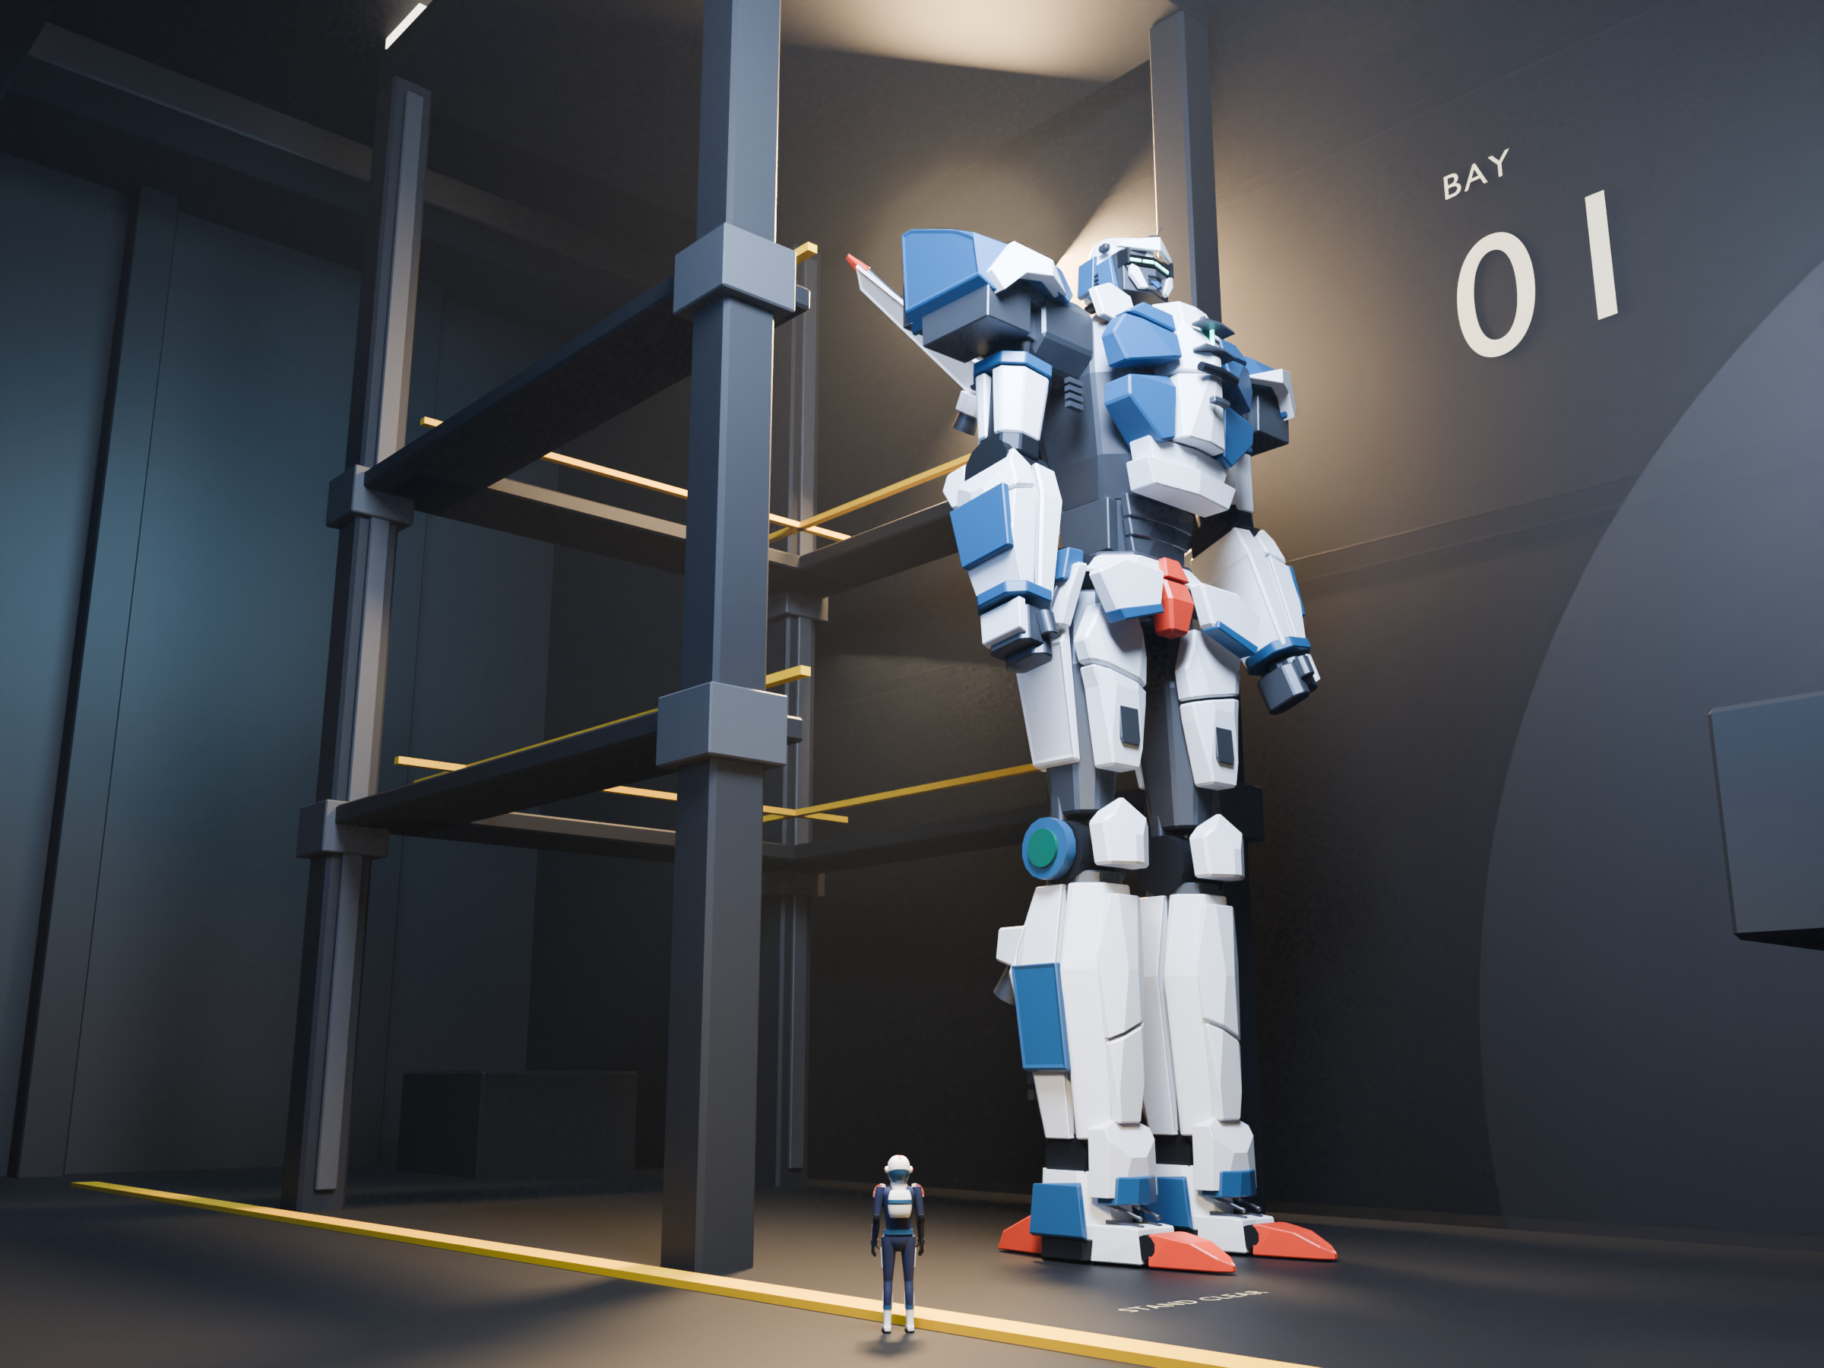
sortie_2.png
agent
+39:29The corrected image is finished and inspected. Both figures now read as grounded on the deck. The final render took 7 minutes 48 seconds, and I’m completing the handoff checks and commit.
write_stdin, exec_commandpoll session 80460 (+1 more)
input
text(await tools.write_stdin({session_id:80460,chars:"","yield_time_ms":1000,"max_output_tokens":2500})); text(await tools.exec_command({cmd:"git diff --cached --check && git diff --exit-code -- public/assets src kit docs package.json package-lock.json && git status --short && ls -lh ~/out/index.html ~/out/sortie.png","max_output_tokens":1500}));result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"c29de8","wall_time_seconds":0.000003,"exit_code":0,"original_token_count":171,"output":"{\n \"results\": [\n {\n \"label\": \"desktop\",\n \"title\": \"Sortie · Before boarding · Astra study\",\n \"overflow\": false,\n \"images\": [\n {\n \"loaded\": true,\n \"alt\": true\n }\n ],\n \"font\": true,\n \"identity\": true,\n \"emDash\": false,\n \"pending\": false,\n \"h1\": 1\n },\n {\n \"label\": \"phone\",\n \"title\": \"Sortie · Before boarding · Astra study\",\n \"overflow\": false,\n \"images\": [\n {\n \"loaded\": true,\n \"alt\": true\n }\n ],\n \"font\": true,\n \"identity\": true,\n \"emDash\": false,\n \"pending\": false,\n \"h1\": 1\n }\n ],\n \"failures\": []\n}\n"}{"chunk_id":"7bf5af","wall_time_seconds":0.000004121,"exit_code":0,"original_token_count":72,"output":"A tools/astra/README.md\nA tools/astra/build_page.py\nA tools/astra/check_page.mjs\nA tools/astra/page.html\nA tools/astra/render_study.py\n-rw------- 1 runner runner 22K Nov 15 03:52 ~/out/index.html\n-rw------- 1 runner runner 4.1M Nov 15 03:52 ~/out/sortie.png\n"}exec_commandgit commit -m "Add Astra Sortie review and hangar study" && git status --short --branch && git log -1 --format='%h %s'
command
git commit -m "Add Astra Sortie review and hangar study" && git status --short --branch && git log -1 --format='%h %s'
result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"b6a103","wall_time_seconds":0.00000352,"exit_code":0,"original_token_count":94,"output":"[astra 399ee46] Add Astra Sortie review and hangar study\n 5 files changed, 493 insertions(+)\n create mode 100644 tools/astra/README.md\n create mode 100644 tools/astra/build_page.py\n create mode 100644 tools/astra/check_page.mjs\n create mode 100644 tools/astra/page.html\n create mode 100644 tools/astra/render_study.py\n## astra\n399ee46 Add Astra Sortie review and hangar study\n"}
agent
+39:56~/out/index.html
- One large hangar render using existing assets.
- Shape first, surface polish second.
- Keep the tools, reset inherited proportions.
- A concrete five-step restart plan.
- Offline desktop and phone checks passed.
Commit: 399ee46 on astra. Nothing pushed.
user
+39:59[the lead] New ask from the owner (verbatim): "ask sortie astra to try and take one of its outlines to a level of refinement like the control one. maybe we let it take its own spin on the control mech's same outline, so 0 is closest?"
So: take block_dummy (the shared skeleton, the outline closest to the striker) and make your own design on it, refined to the striker's (S) level: plates, panel lines, joints, colour blocking, cockpit, thrusters, the works, your own spin rather than a copy. Present it: from behind in flight, the game's plumes, then a full turn, with S beside it as the yardstick. Same rules as before (your worktree and branch only, headless, nothing pushed, no Gundam lookalikes). Add it to your page as a second section (keep the first), say how it was made and how long it took, and time the steps so we can see where the hours go. End your turn with the page path and a short summary.
[the owner, 9 minutes later] just providing more steering information here. you're here as an adversarial agent intending to prove that you can do much, much better than the prior model who was working on this project. pull all the stops out and do whatever's necessary to break free of what plagues the current project, show me your best work. not just using the tools and following that project's footsteps, the point is a radical improvement that only you could do, compared to where this project has already tread.
[the owner, 16 minutes later] mind telling me how you're deviating now? just so I can tell early if you're just going by the usual route
[the owner, 21 minutes later] if you need to use blender go for it, I need your absolute best
agent
+40:10I’m changing the route at the design level: one coherent machine with a clear job, designed in three dimensions, with the rear and flight pose treated as primary views. I’ll use the shared skeleton for compatibility, but build new armour forms and mechanisms instead of dressing the dummy in the old kit’s shapes.
I’ll make the comparison unforgiving: the same camera, lighting, scale and game plumes for my design and S. I’ll also log design, modelling, rendering and revision time separately, and keep the original page intact.
exec_command, clock__curr_timegit status --short --branch && cat kit/blocks/dummy.py && cat kit/block.py && cat tools/clip.mjs (+2 more)
input
text(await tools.exec_command({cmd:"git status --short --branch && cat kit/blocks/dummy.py && cat kit/block.py && cat tools/clip.mjs","max_output_tokens":11000})); text(await tools.exec_command({cmd:"rg --files -g 'AGENTS.md' -g '*astra*' -g '*outline*' -g '*control*' . && cat tools/astra/README.md && cat src/view/clip-plan.ts","max_output_tokens":7500})); text(await tools.clock__curr_time({}));result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"62605b","wall_time_seconds":0.000004161,"exit_code":0,"original_token_count":2539,"output":"## astra\n\"\"\"Test fixture for the block tools: an automatic box on every bone, sized from the default joints.\nNot a design. Delete nothing here, copy it to start a real block file.\"\"\"\n\n\ndef build(Blocks):\n    b = Blocks()\n    b.mannequin()\n    pack = b.at(\"backpack\")\n    b.nozzles(\"backpack\", (.5, pack.y + .4, pack.z - .9), (0, .45, -.9))\n\"\"\"Block models: plain boxes on the 22 joint rig, for judging mass and motion before any plate exists.\n\nA block model is one file, kit/blocks/<name>.py, with a build() that takes this module's Blocks class.\nIt builds in seconds, into a gitignored public/assets/block_<name>.glb:\n\n    npm run kit -- block_dummy\n    npm run clip -- block_dummy\n\nGeometry is authored in world rest pose coordinates in metres, models facing -Y, Z up, left is +X, as\nin the rest of the kit. Roles are the usual ones (main, accent, frame, joint). Nothing here is a design\nrule: no maker, frame or grade carries over unless a block file asks for it.\n\"\"\"\nimport importlib\n\nimport bpy\nfrom mathutils import Vector\n\nfrom lib import loft, merge, mirror_x, octo, solid\nfrom mech import joints as striker_joints, nozzle_pair, pair\n\nSIDED = {\"shoulder\", \"upperarm\", \"forearm\", \"hand\", \"grip\", \"thigh\", \"shin\", \"foot\", \"binder\"}\nBEVEL = .03\n\n\nclass Blocks:\n    \"\"\"The rig plus block primitives. `joints` overrides rest positions: {\"thigh\": (1.1, 0, 9.5)} moves\n    both thighs (give the left, +X, the right mirrors), {\"pelvis\": (0, 0, 9.8)} moves one node. Other\n    joints stay where the striker has them, in world coordinates, so moving one moves nothing else.\"\"\"\n\n    def __init__(self, joints=None, height=17.6):\n        J = striker_joints()\n        self.nodes = {o.name: o for o in J.values()}\n        self.n = 0\n        J[\"frame\"][\"frame\"] = \"block\"\n        J[\"frame\"][\"height\"] = height\n        place = {name: o.matrix_world.translation.copy() for name, o in self.nodes.items()}\n        for key, at in (joints or {}).items():\n            if key in SIDED:\n                place[f\"{key}.L\"] = Vector(at)\n                place[f\"{key}.R\"] = Vector((-at[0], at[1], at[2]))\n            elif key in place:\n                place[key] = Vector(at)\n            else:\n                raise KeyError(f\"block: no joint {key}\")\n        for name, o in self.nodes.items():  # striker_joints() makes parents first\n            if o.parent is not None:\n                o.location = o.parent.matrix_world.inverted() @ place[name]\n            bpy.context.view_layer.update()\n\n    def at(self, name):\n        return self.nodes[name].matrix_world.translation.copy()\n\n    def _put(self, joint, bm, role, mirror):\n        self.n += 1\n        name = f\"block{self.n}_{joint}\"\n        if joint in SIDED:\n            pair(name, bm, role, self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"], bevel=BEVEL, panels=False)\n        elif mirror:\n            solid(name, merge(bm, mirror_x(bm)), role, self.nodes[joint], bevel=BEVEL, panels=False)\n        else:\n            solid(name, bm, role, self.nodes[joint], bevel=BEVEL, panels=False)\n\n    def box(self, joint, x, y, z, role=\"main\", mirror=False):\n        \"\"\"A box from x, y, z ranges (lo, hi). A sided joint (thigh, shin, ...) takes the left's numbers\n        and mirrors to the right. `mirror` does the same for a box on a centre joint.\"\"\"\n        r = [(x[0], y[0]), (x[1], y[0]), (x[1], y[1]), (x[0], y[1])]\n        self._put(joint, loft([(z[0], r), (z[1], r)]), role, mirror)\n\n    def taper(self, joint, rings, role=\"main\", mirror=False, chamfer=.15):\n        \"\"\"A lofted block through rings (z, width, depth, x, y), bottom to top.\"\"\"\n        self._put(joint, loft([(z, octo(w, d, chamfer, x=x, y=y)) for z, w, d, x, y in rings]), role, mirror)\n\n    def bone(self, joint, a, b, w, d, role=\"main\", chamfer=.1):\n        \"\"\"A block from joint a to joint b, both named for the left side: bone(\"thigh\", \"thigh.L\", \"shin.L\", 1, 1).\"\"\"\n        pa, pb = self.at(a), self.at(b)\n        lo, hi = (pa, pb) if pa.z < pb.z else (pb, pa)\n        self.taper(joint, [(lo.z, w, d, lo.x, lo.y), (hi.z, w, d, hi.x, hi.y)], role, chamfer=chamfer)\n\n    def nozzles(self, joint, at, direction, r=.45, length=.9, kind=\"main\"):\n        \"\"\"A nozzle pair that fires plumes in the game. `kind`: main, binder or calf.\"\"\"\n        if joint in SIDED:\n            jl, jr = self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"]\n        else:\n            jl = jr = self.nodes[joint]\n        nozzle_pair(kind, at, direction, r, length, jl, jr, housing=False)\n\n    def mannequin(self):\n        \"\"\"A neutral box on every bone, sized from the joints alone. For testing tools, not a design.\"\"\"\n        for joint, a, b, w, d in ((\"thigh\", \"thigh.L\", \"shin.L\", 1.0, 1.0), (\"shin\", \"shin.L\", \"foot.L\", 1.0, 1.0),\n                                  (\"upperarm\", \"upperarm.L\", \"forearm.L\", .7, .7), (\"forearm\", \"forearm.L\", \"hand.L\", .7, .7)):\n            self.bone(joint, a, b, w, d)\n        foot = self.at(\"foot.L\")\n        self.box(\"foot\", (foot.x - .5, foot.x + .5), (foot.y - 1.2, foot.y + .6), (0, foot.z))\n        hand = self.at(\"hand.L\")\n        self.box(\"hand\", (hand.x - .3, hand.x + .3), (hand.y - .3, hand.y + .3), (hand.z - .8, hand.z))\n        pelvis, torso, neck, head = self.at(\"pelvis\"), self.at(\"torso\"), self.at(\"neck\"), self.at(\"head\")\n        self.box(\"pelvis\", (-1.3, 1.3), (-.8, .8), (pelvis.z - .8, pelvis.z + .4))\n        self.box(\"waist\", (-.8, .8), (-.6, .6), (pelvis.z + .4, torso.z))\n        shoulder = self.at(\"shoulder.L\")\n        self.box(\"torso\", (-shoulder.x, shoulder.x), (-1, 1), (torso.z, neck.z))\n        self.box(\"shoulder\", (shoulder.x, shoulder.x + .9), (-.6, .6), (shoulder.z - .6, shoulder.z + .4))\n        self.box(\"neck\", (-.3, .3), (-.3, .3), (neck.z, head.z))\n        self.box(\"head\", (-.5, .5), (-.6, .6), (head.z, head.z + 1.1))\n        pack = self.at(\"backpack\")\n        self.box(\"backpack\", (-.9, .9), (pack.y - .5, pack.y + .5), (pack.z - 1, pack.z + 1))\n\n\ndef build_block(name):\n    \"\"\"block_<name> from kit/blocks/<name>.py.\"\"\"\n    module = importlib.import_module(f\"blocks.{name.removeprefix('block_')}\")\n    importlib.reload(module)\n    module.build(Blocks)\n// A review clip of one model: chase camera, orbit, turntable, range of motion, next to a pilot.\n//   node tools/clip.mjs <model> [--quick] [--shots chase,turn] [--fps 24] [--size 854x480] [--palette merc] [--look kit] [--out file.mp4]\n// --quick is for the loop: chase and turntable only, 12 fps, 640x360.\n// Starts its own dev server on a free port and always stops it. Frames are rendered one at a time, so\n// the clip is smooth however slow the machine (src/view/clip.ts). Writes the mp4 and, because a reader\n// that can't watch video still has to judge it, a contact sheet of frames beside it. Headless only.\nimport { spawn, spawnSync } from 'node:child_process';\nimport { mkdirSync } from 'node:fs';\nimport { dirname, resolve } from 'node:path';\nimport { chromium } from 'playwright';\nimport { createServer } from 'vite';\n\nconst args = process.argv.slice(2);\nconst flag = (name, fallback) => {\n  const i = args.indexOf(`--${name}`);\n  return i >= 0 ? args[i + 1] : fallback;\n};\nconst name = args[0];\nif (!name || name.startsWith('--')) {\n  console.error('usage: node tools/clip.mjs <model> [--quick] [--shots chase,orbit,turn,bend,scale] [--fps 24] [--size 854x480] [--palette merc] [--look kit] [--out file.mp4]');\n  process.exit(2);\n}\nconst quick = args.includes('--quick');\nconst [w, h] = flag('size', quick ? '640x360' : '854x480').split('x').map(Number);\nconst fps = Number(flag('fps', quick ? 12 : 24));\nconst out = resolve(flag('out', `review/out/one-mech/clips/${name}.mp4`));\nconst params = new URLSearchParams({ view: 'clip', model: name, w, h, fps, palette: flag('palette', 'merc') });\nfor (const k of ['shots', 'look']) if (flag(k)) params.set(k, flag(k));\nif (quick && !flag('shots')) params.set('shots', 'chase,turn');\nmkdirSync(dirname(out), { recursive: true });\n\nconst started = Date.now();\nconst server = await createServer({ server: { host: '127.0.0.1', port: 5230, strictPort: false }, logLevel: 'error' });\nawait server.listen();\nconst browser = await chromium.launch({ args: ['--use-angle=swiftshader', '--enable-unsafe-swiftshader', '--ignore-gpu-blocklist'] });\nlet failed = false;\ntry {\n  const page = await browser.newPage({ viewport: { width: w, height: h } });\n  page.setDefaultTimeout(300000);\n  page.on('pageerror', (e) => { failed = true; console.error('[pageerror]', e.message); });\n  page.on('console', (m) => { if (m.type() === 'error') console.error('[console]', m.text().slice(0, 300)); });\n  await page.goto(`${server.resolvedUrls.local[0]}?${params}`);\n  await page.waitForFunction(() => window.__ready === true);\n  const frames = await page.evaluate(() => window.__clip.frames);\n  const loaded = Date.now();\n  const ffmpeg = spawn('ffmpeg', ['-loglevel', 'error', '-y', '-f', 'image2pipe', '-c:v', 'mjpeg', '-framerate', String(fps), '-i', '-',\n    '-c:v', 'libx264', '-crf', '20', '-pix_fmt', 'yuv420p', '-movflags', '+faststart', out], { stdio: ['pipe', 'inherit', 'inherit'] });\n  const ended = new Promise((ok) => ffmpeg.on('close', ok));\n  for (let i = 0; i < frames; i++) {\n    const url = await page.evaluate((n) => window.__clip.render(n), i);\n    const jpeg = Buffer.from(url.slice(url.indexOf(',') + 1), 'base64');\n    if (!ffmpeg.stdin.write(jpeg)) await new Promise((ok) => ffmpeg.stdin.once('drain', ok));\n  }\n  ffmpeg.stdin.end();\n  const code = await ended;\n  if (code !== 0) throw new Error(`ffmpeg exited ${code}`);\n  const every = Math.max(1, Math.floor(frames / 12));\n  const sheet = out.replace(/\\.mp4$/, '.sheet.jpg');\n  spawnSync('ffmpeg', ['-loglevel', 'error', '-y', '-i', out, '-vf', `select=not(mod(n\\\\,${every})),scale=480:-1,tile=4x3`, '-frames:v', '1', '-q:v', '4', sheet], { stdio: 'inherit' });\n  const secs = (Date.now() - started) / 1000;\n  console.log(`clip: ${out}`);\n  console.log(`clip: ${sheet}`);\n  console.log(`clip: ${frames} frames, ${(frames / fps).toFixed(1)} s of video, ${secs.toFixed(0)} s to make (${((Date.now() - loaded) / frames).toFixed(0)} ms a frame)`);\n} finally {\n  await browser.close();\n  await server.close();\n}\nprocess.exit(failed ? 1 : 0);\n"}{"chunk_id":"6ef1c7","wall_time_seconds":0.000004661,"exit_code":0,"original_token_count":1839,"output":"./tools/outlines.mjs\n./tools/fixtures/outlines-test.json\n./tools/outlines-lib.test.mjs\n./tools/outlines-lib.mjs\n./src/game/controls.ts\n./src/game/controls.test.ts\n# Before boarding\n\nIndependent Sortie review, 15 November 2026. The deliverable is `~/out/index.html` with\n`~/out/sortie.png` beside it. It opens without a server or network connection.\n\nThe image stages the existing `striker_a`, ship and pilot in a service bay. It tests scale and\npresence, while leaving the unresolved shape visible. This is a Cycles lighting study. It does\nnot represent the game's renderer or start the owner's new mech.\n\n## Reproduce\n\nFrom the repository root, with the existing dependencies:\n\n```sh\nmkdir -p review/out/astra\n~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py\npython tools/astra/build_page.py --work-minutes 42\nnode tools/astra/check_page.mjs\n```\n\n`--work-minutes` is the author's approximate total working time, not a render setting. Set it\nto the actual time if making another study. The measured render time comes from\n`review/out/astra/render.json`. Add `-- --preview` to the Blender command for a 1000 × 750,\n24-sample preview. The final is 2400 × 1800 at up to 64 samples with adaptive sampling, on 8 CPU\nthreads with denoising. An initial 160-sample attempt ended on SIGTERM before writing an image.\n\n## Inputs and changes\n\n- `public/assets/striker_a.glb`: existing Mantle V, Hatch IV, wing pack and claw-foot assembly.\n  Small arm and head rotations only. No changed proportions or meshes.\n- `public/assets/ship.glb`: standard bay fittings. One foreground red crate hidden. Darker\n  hangar materials and slight procedural floor roughness in the render scene.\n- `public/assets/lab_pilot.glb`: standing pilot only, at the authored scale, turned toward the mech.\n- Both figures are placed from their lowest visible mesh vertex onto the 0.2 m deck surface.\n  The pilot stands clear of the raised yellow strip.\n- `src/render/palette.ts`: merc role colours translated to Blender materials. This is not a\n  reproduction of the game's shader, postprocessing or decals.\n- New scene elements: five area lights, faint volume scatter, bay and floor lettering, camera.\n- Existing Chakra Petch font from `node_modules`, embedded into the page. No remote resources.\n\nThe source GLBs, kit, game code and project documents are untouched. The script only imports\nthe models and renders a new scene. Preview files and validation screenshots stay under\n`review/out/astra`, outside the deliverable. The HTML shows one image.\n\n## Checks\n\n`check_page.mjs` uses headless Chromium at desktop and phone widths. It checks the single image,\nembedded font, identity label, heading, horizontal overflow, expandable methods and absence of\nHTTP requests. Screenshots and a JSON report go to `review/out/astra`. It checks the page through\n`file://`, so the deliverable does not rely on a dev server.\n\nThe source syntax, deck contacts and page are checked directly. No full test suite is needed for this isolated\nrender and static page. Nothing is installed, uploaded or pushed.\nimport type { Pose } from '../render/mech';\nimport type { BenchState } from './thrusters';\n\n/**\n * The timeline of a review clip (src/view/clip.ts), as a pure function of frame number, so a clip is the\n * same every run whatever the machine's speed. Shots frame the model and nothing here is a design choice:\n * the chase shot sits where the game's camera sits, the rest show it from all round, bending and to scale.\n */\nexport const SHOTS = { chase: 3.5, orbit: 3, turn: 4, bend: 3, scale: 2.5 } as const;\nexport type ShotName = keyof typeof SHOTS;\nexport const SHOT_NAMES = Object.keys(SHOTS) as ShotName[];\n\n/** Thruster states through a shot: [start second, state]. */\nconst SCHEDULE: Partial<Record<ShotName, [number, BenchState][]>> = {\n  chase: [[0, 'cruise'], [1, 'boost'], [2.4, 'quick'], [3, 'cruise']],\n  orbit: [[0, 'boost'], [1.4, 'brake'], [2.2, 'idle']],\n};\n\nexport interface ClipFrame {\n  shot: ShotName;\n  /** Seconds into the shot, and the same as a 0..1 fraction. */\n  t: number;\n  u: number;\n  state: BenchState;\n  /** Seconds since this thruster state began. */\n  stateT: number;\n  /** First frame of a shot: everything snaps. */\n  cut: boolean;\n}\n\nexport function clipFrames(shots: readonly ShotName[], fps: number): ClipFrame[] {\n  const out: ClipFrame[] = [];\n  for (const shot of shots) {\n    const n = Math.max(1, Math.round(SHOTS[shot] * fps));\n    const plan = SCHEDULE[shot] ?? [[0, 'idle'] as [number, BenchState]];\n    for (let i = 0; i < n; i++) {\n      const t = i / fps;\n      let at = plan[0];\n      for (const p of plan) if (p[0] <= t + 1e-9) at = p;\n      out.push({ shot, t, u: n > 1 ? i / (n - 1) : 0, state: at[1], stateT: t - at[0], cut: i === 0 });\n    }\n  }\n  return out;\n}\n\n/** Where things are in a shot. Lengths are in frame heights, angles in degrees. Yaw 0 looks at the\n *  frame's front, 180 at its back. `chase` means the game's chase camera, turned by mechYaw. */\nexport interface ShotView {\n  chase: boolean;\n  mechYaw: number;\n  camYaw: number;\n  pitch: number;\n  dist: number;\n  /** Look point height as a fraction of the frame's height. */\n  lookAt: number;\n  pose: 'flight' | 'stand';\n  /** How far toward BEND_POSE, 0..1. */\n  bend: number;\n  /** The pilot and the deck are in shot. */\n  ground: boolean;\n}\n\nconst ease = (x: number) => x * x * (3 - 2 * x);\n\nexport function shotView(f: ClipFrame): ShotView {\n  const base = { chase: false, mechYaw: 0, camYaw: 0, pitch: 8, dist: 2.4, lookAt: 0.5, pose: 'stand', bend: 0, ground: false } as ShotView;\n  switch (f.shot) {\n    case 'chase': {\n      // a gentle turn and back: the camera trails the frame, so the stars pan and the frame leans in shot\n      const turn = Math.sin(f.u * Math.PI * 2) * 22;\n      return { ...base, chase: true, mechYaw: turn, camYaw: turn * 0.75, pose: 'flight' };\n    }\n    case 'orbit':\n      return { ...base, camYaw: 165 - 75 * ease(f.u), pitch: 12, dist: 2.2, pose: 'flight' };\n    case 'turn':\n      return { ...base, camYaw: 180 + 360 * f.u };\n    case 'bend':\n      return { ...base, camYaw: 35, pitch: 6, bend: Math.sin(f.u * Math.PI) ** 2 };\n    case 'scale':\n      // from the deck beside the pilot, looking up at the frame, pushing in slowly\n      return { ...base, camYaw: 28, pitch: -6 + 2 * f.u, dist: 2.25 - 0.15 * ease(f.u), lookAt: 0.42, ground: true };\n  }\n}\n\n/** A deliberately large range of motion, to find plates that collide or joints that show. Glances at\n *  every limb: one arm up and forward, the other out, one knee high, a twist. */\nexport const BEND_POSE: Pose = {\n  torso: [12, 18, 0], head: [-8, -24, 0],\n  'upperarm.L': [-115, 0, 22], 'forearm.L': [-80, 0, 0],\n  'upperarm.R': [-20, 0, -72], 'forearm.R': [-100, 0, 0],\n  'thigh.L': [-85, 0, 10], 'shin.L': [100, 0, 0], 'foot.L': [-22, 0, 0],\n  'thigh.R': [-8, 0, -14], 'shin.R': [22, 0, 0], 'foot.R': [8, 0, 0],\n  'binder.L': [-20, 0, 0], 'binder.R': [20, 0, 0],\n};\n\n/** A blend of two poses, joint by joint. */\nexport function mixPose(a: Pose, b: Pose, w: number): Pose {\n  const out: Pose = {};\n  for (const j of new Set([...Object.keys(a), ...Object.keys(b)]) as Set<keyof Pose>) {\n    const p = a[j] ?? [0, 0, 0], q = b[j] ?? [0, 0, 0];\n    out[j] = [p[0] + (q[0] - p[0]) * w, p[1] + (q[1] - p[1]) * w, p[2] + (q[2] - p[2]) * w];\n  }\n  return out;\n}\n"}{"current_time":"2026-11-15 03:53:31 UTC"}