A mech game prototype, pushed by GPT-6-Astra
agent (cont.)
+1:30exec_commandpython - <<'PY' (+1 more)
command
python - <<'PY' import json,struct for name in ['striker_a','ship','lab_pilot']: b=open('public/assets/'+name+'.glb','rb').read(); n=struct.unpack_from('<I',b,12)[0]; j=json.loads(b[20:20+n]); print('\n'+name) print('materials',[(m['name'],m.get('pbrMetallicRoughness')) for m in j.get('materials',[])]) print('nodes',[(v.get('name'),v.get('translation'),v.get('extras')) for v in j['nodes'] if 'mesh' not in v]) PY cat kit/figure.py | head -115 && rg -n 'def material|MATERIAL|main.*#|nodes.new|def reset' kit/lib.py && sed -n '78,125p' src/render/mech.tsresult, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"692de6","wall_time_seconds":0.00000468,"exit_code":0,"original_token_count":2509,"output":"\nstriker_a\nmaterials [('main', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('trim', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('frame', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('accent', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('joint', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('glow_thruster', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('metal', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('sensor', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('glow_eye', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('visor', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('glow_hot', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5})]\nnodes [('foot.L', [0, -4.550000190734863, -0.10000000149011612], None), ('nozzle.calf.L', [0, -2.130966901779175, -1.6335101127624512], {'dir': [0.0, -0.8619, -0.507], 'radius': 0.3}), ('shin.L', [0.05000007152557373, -4.450000286102295, 0], None), ('thigh.L', [1.149999976158142, -0.05000019073486328, 0], None), ('foot.R', [0, -4.550000190734863, -0.10000000149011612], None), ('nozzle.calf.R', [0, -2.130966901779175, -1.6335101127624512], {'dir': [0.0, -0.8619, -0.507], 'radius': 0.3}), ('shin.R', [-0.05000007152557373, -4.450000286102295, 0], None), ('thigh.R', [-1.149999976158142, -0.05000019073486328, 0], None), ('nozzle.binder.L', [-0.05000007152557373, -0.7764787673950195, -0.5465035438537598], {'dir': [0.0, -0.8366, -0.5478], 'radius': 0.22}), ('binder.L', [1.100000023841858, 1.0500001907348633, -0.75], None), ('nozzle.binder.R', [0.05000007152557373, -0.7764787673950195, -0.5465035438537598], {'dir': [0.0, -0.8366, -0.5478], 'radius': 0.22}), ('binder.R', [-1.100000023841858, 1.0500001907348633, -0.75], None), ('nozzle.main.L', [0.41999998688697815, -1.3313779830932617, -0.8406887054443359], {'dir': [0.0, -0.8944, -0.4472], 'radius': 0.32}), ('nozzle.main.R', [-0.41999998688697815, -1.3313779830932617, -0.8406887054443359], {'dir': [0.0, -0.8944, -0.4472], 'radius': 0.32}), ('backpack', [0, 1.9000005722045898, -1.5], None), ('cockpit', [0, 1.8000001907348633, 0.75], None), ('head', [0, 0.5500001907348633, 0], None), ('neck', [0, 3.160000801086426, 0], None), ('grip.L', [-0.1400001049041748, -0.48000049591064453, 0.019999999552965164], None), ('hand.L', [0, -2.34999942779541, 0], None), ('forearm.L', [0.04999995231628418, -2.4499998092651367, 0], None), ('upperarm.L', [0.4500000476837158, -0.20000076293945312, 0], None), ('shoulder.L', [2, 2.700000762939453, 0], None), ('grip.R', [0.1400001049041748, -0.48000049591064453, 0.019999999552965164], None), ('hand.R', [0, -2.34999942779541, 0], None), ('forearm.R', [-0.04999995231628418, -2.4499998092651367, 0], None), ('upperarm.R', [-0.4500000476837158, -0.20000076293945312, 0], None), ('shoulder.R', [-2, 2.700000762939453, 0], None), ('torso', [0, 0.7999992370605469, 0], None), ('waist', [0, 0.5, 0], None), ('pelvis', [0, 10.600000381469727, 0], None), ('frame', None, {'frame': 'striker_a', 'height': 17.6})]\n\nship\nmaterials [('hull_dark', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('accent', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('hull', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('screen', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('light', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('trim', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('hazard', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('glow_thruster', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('frame', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('metal', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('deck', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('interior', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('lamp_red', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('lamp_green', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5})]\nnodes [('bay.1', [16, 0.20000000298023224, -10], {'classes': ['light', 'standard', 'heavy']}), ('bay.1.heavy', [16, 0.6000000238418579, -9.199999809265137], {'cls': 'heavy', 'platforms': [11.0, 21.0]}), ('bay.1.light.a', [19, 0.5, -10], {'cls': 'light', 'platforms': [4.4], 'board': 4.4}), ('bay.1.light.b', [13, 0.5, -10], {'cls': 'light', 'platforms': [4.4], 'board': 4.4}), ('bay.1.std', [16, 0.20000000298023224, -10], {'cls': 'standard', 'platforms': [8.0, 15.5]}), ('bay.2', [-16, 0.20000000298023224, -10], {'classes': ['light', 'standard', 'heavy']}), ('bay.2.heavy', [-16, 0.6000000238418579, -9.199999809265137], {'cls': 'heavy', 'platforms': [11.0, 21.0]}), ('bay.2.light.a', [-13, 0.5, -10], {'cls': 'light', 'platforms': [4.4], 'board': 4.4}), ('bay.2.light.b', [-19, 0.5, -10], {'cls': 'light', 'platforms': [4.4], 'board': 4.4}), ('bay.2.std', [-16, 0.20000000298023224, -10], {'cls': 'standard', 'platforms': [8.0, 15.5]}), ('door.L', [0, 0, 116], {'slide': [1.0, 0.0, -0.0]}), ('door.R', [0, 0, 116], {'slide': [-1.0, 0.0, -0.0]}), ('exit', [0, 13, 126], None), ('gantry.1.heavy', [16, 0, -10], {'cls': 'heavy', 'platforms': [11.0, 21.0]}), ('gantry.1.light', [16, 0, -10], {'cls': 'light', 'platforms': [4.4]}), ('gantry.1.std', [16, 0, -10], {'cls': 'standard', 'platforms': [8.0, 15.5]}), ('gantry.2.heavy', [-16, 0, -10], {'cls': 'heavy', 'platforms': [11.0, 21.0]}), ('gantry.2.light', [-16, 0, -10], {'cls': 'light', 'platforms': [4.4]}), ('gantry.2.std', [-16, 0, -10], {'cls': 'standard', 'platforms': [8.0, 15.5]}), ('launch.end', [0, 1.5, 112], None), ('launch.start', [0, 1.5, 22], None), ('launch.start.heavy', [0, 1.7000000476837158, 22], {'cls': 'heavy'}), ('launch.start.light', [0, 2.299999952316284, 22], {'cls': 'light'}), ('launch.start.std', [0, 1.5, 22], {'cls': 'standard'}), ('light.0', [0, 26, -6], {'color': [1.0, 0.96, 0.9], 'power': 1.0}), ('light.1', [14, 22, -10], {'color': [1.0, 0.96, 0.9], 'power': 0.7}), ('light.2', [-14, 22, -10], {'color': [1.0, 0.96, 0.9], 'power': 0.7}), ('light.3', [0, 22, 40], {'color': [0.85, 0.95, 1.0], 'power': 0.7}), ('light.4', [0, 22, 80], {'color': [0.85, 0.95, 1.0], 'power': 0.7}), ('nozzle.ship.0', [0, 22, -125.75], {'dir': [0.0, 0.0, -1.0], 'radius': 7.5}), ('nozzle.ship.1', [15, 12, -122.5], {'dir': [0.0, 0.0, -1.0], 'radius': 5.0}), ('nozzle.ship.2', [-15, 12, -122.5], {'dir': [0.0, 0.0, -1.0], 'radius': 5.0}), ('clamps.heavy', None, {'cls': 'heavy'}), ('clamps.light', None, {'cls': 'light'}), ('clamps.std', None, {'cls': 'standard'}), ('shuttle', [0, 0.550000011920929, 22], None), ('signal.green', [2.200000047683716, 23.799999237060547, 24], None), ('signal.red', [-2.200000047683716, 23.799999237060547, 24], None), ('ship', None, {'ship': 'merc_medium'})]\n\nlab_pilot\nmaterials [('accent', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('main', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('suit', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('trim', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('joint', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('visor', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('metal', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('frame', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5}), ('deck', {'baseColorFactor': [0.800000011920929, 0.800000011920929, 0.800000011920929, 1], 'metallicFactor': 0, 'roughnessFactor': 0.5})]\nnodes [('slot0', [-0.550000011920929, 0, 0], {'label': 'standing'}), ('slot1', [0.550000011920929, 0, 0], {'label': 'seated, bike'}), ('lab', None, None)]\n"}{"chunk_id":"5d3126","wall_time_seconds":0.00000413,"exit_code":0,"original_token_count":1883,"output":"\"\"\"A 1.75 m pilot in a flight suit, for scale in labs and lineups and to sit in the light cockpit.\n\nA fitted dark undersuit with armoured plates on the chest, shoulders, forearms, thighs and shins, a\nhigh collar, a life support pack, gloves and boots, and a sculpted helmet with a recessed dark visor,\near pods and a crest stripe. Plates are the body's own surface grown outward and cut by an outline,\nso they sit on the body like moulded armour and their edges read as real thickness.\n\nThe body is modelled once standing (rest pose: facing -Y, Z up, feet on z=0) and posed rigidly per\njoint, forward kinematics from the pelvis. Poses:\n  stand   standing at ease, arms a little out\n  bike    seated on a bike-style seat, leaning forward, hands forward on two grips (light cockpit)\n`points(pose)` gives the posed eye, grips, seat and foot pegs without building anything, so a\ncockpit can be laid out around the pilot.\n\nRoles: undersuit and gloves \"suit\", plates \"main\", secondary panels \"accent\", the crest stripe and\nsmall markings the `role` argument. \"hazard\" paints world-space stripes a metre and a half apart,\nwhich cut a person in half, so it falls back to \"trim\" here.\n\"\"\"\nimport math\n\nimport bmesh\nimport bpy\nfrom mathutils import Matrix, Vector\n\nfrom lib import boolean, halves, link, loft, merge, prism, solid, subd, transform\n\n# ---- the skeleton, rest pose -------------------------------------------------------------------------------\n# joint: (parent, pivot). Pivots for the left side (+X); the right side mirrors x.\nSKELETON = {\n    \"pelvis\": (None, (0, 0, .93)),\n    \"chest\": (\"pelvis\", (0, .01, 1.06)),\n    \"head\": (\"chest\", (0, .015, 1.5)),\n    \"upperarm\": (\"chest\", (.19, .01, 1.42)),\n    \"forearm\": (\"upperarm\", (.2, .02, 1.13)),\n    \"hand\": (\"forearm\", (.205, .01, .865)),\n    \"thigh\": (\"pelvis\", (.095, 0, .91)),\n    \"shin\": (\"thigh\", (.1, -.005, .5)),\n    \"foot\": (\"shin\", (.1, .02, .085)),\n}\nSIDED = {\"upperarm\", \"forearm\", \"hand\", \"thigh\", \"shin\", \"foot\"}\n\n# Joint rotations in degrees: (pitch about X, sideways about Y, twist about Z), applied in rest axes.\n# A positive pitch tips an upward bone forward (-Y) and a downward bone back. A positive sideways\n# value tips a downward left bone toward the centre line, mirrored on the right.\n# `fingers` curls the fingers (degrees per knuckle), `thumb` closes the thumb.\nPOSES = {\n    \"stand\": dict(lift=0.0, joints={\n        \"upperarm\": (-3, -7, 0), \"forearm\": (-12, 2, -20), \"hand\": (-4, 0, 0),\n        \"thigh\": (0, -1.5, 0), \"shin\": (2, 0, 0), \"foot\": (-2, 0, 0), \"head\": (-2, 0, 0)},\n        fingers=(22, 18), thumb=10),\n    \"bike\": dict(lift=0.0, joints={\n        \"pelvis\": (24, 0, 0), \"chest\": (18, 0, 0), \"head\": (-42, 0, 0),\n        \"upperarm\": (-124, -11, 0), \"forearm\": (-8, 4, -84), \"hand\": (8, 0, 6),\n        \"thigh\": (-86, -5, 0), \"shin\": (112, 3, 0), \"foot\": (-32, 0, 0)},\n        fingers=(78, 72), thumb=55),\n}\n\n# Points of interest in the rest pose, by joint: the eye (between the eyes, inside the helmet), the\n# grip in each hand, the seat contact under the pelvis, the ball of each foot.\nMARKS = {\"eye\": (\"head\", (0, -.085, 1.645)), \"grip\": (\"hand\", (.2, -.004, .79)), \"seat\": (\"pelvis\", (0, .0, .86)),\n         \"peg\": (\"foot\", (.1, -.07, .02))}\n\n\ndef _rot(p, r, t):\n    return Matrix.Rotation(math.radians(p), 4, \"X\") @ Matrix.Rotation(math.radians(r), 4, \"Y\") @ Matrix.Rotation(math.radians(t), 4, \"Z\")\n\n\ndef rig(pose=\"stand\"):\n    \"\"\"World matrices per joint (keys like \"thigh.L\") for a pose, feet-on-the-ground for stand.\"\"\"\n    P = POSES[pose]\n    M = {}\n    for name, (parent, piv) in SKELETON.items():\n        for s, sx in (((\"L\", 1), (\"R\", -1)) if name in SIDED else ((\"\", 1),)):\n            key = f\"{name}.{s}\" if s else name\n            pk = None if parent is None else (f\"{parent}.{s}\" if parent in SIDED else parent)\n            p, r, t = P[\"joints\"].get(name, (0, 0, 0))\n            c = Vector((piv[0] * sx, piv[1], piv[2]))\n            local = Matrix.Translation(c) @ _rot(p, r * sx, t * sx) @ Matrix.Translation(-c)\n            M[key] = (M[pk] if pk else Matrix.Translation((0, 0, P[\"lift\"]))) @ local\n    return M\n\n\ndef place(at=(0.0, 0.0), z=0.0, turn=0.0):\n    \"\"\"The placement of a built pilot: turned `turn` degrees about Z, then moved to (at, z).\"\"\"\n    return Matrix.Translation((at[0], at[1], z)) @ Matrix.Rotation(math.radians(turn), 4, \"Z\")\n\n\ndef points(pose=\"stand\", at=(0.0, 0.0), z=0.0, turn=0.0):\n    \"\"\"Posed marks in world space: eye, grip.L/R, seat, peg.L/R.\"\"\"\n    M = rig(pose)\n    off = place(at, z, turn)\n    out = {}\n    for mark, (joint, p) in MARKS.items():\n        if joint in SIDED:\n            for s, sx in ((\"L\", 1), (\"R\", -1)):\n                out[f\"{mark}.{s}\"] = off @ M[f\"{joint}.{s}\"] @ Vector((p[0] * sx, p[1], p[2]))\n        else:\n            out[mark] = off @ M[joint] @ Vector(p)\n    return out\n\n\n# ---- shape helpers -----------------------------------------------------------------------------------------\ndef S(z, w, d, x=0.0, y=0.0, p=2.3):\n    \"\"\"A cross-section: height z, width w (X), depth d (Y), centre (x, y), superellipse exponent p\n    (2 an ellipse, higher squarer).\"\"\"\n    return (z, w, d, x, y, p)\n\n\ndef ell(w, d, x=0.0, y=0.0, p=2.3, n=12):\n    out = []\n    for i in range(n):\n        t = 2 * math.pi * i / n\n        c, s = math.cos(t), math.sin(t)\n        out.append((x + w / 2 * math.copysign(abs(c) ** (2 / p), c), y + d / 2 * math.copysign(abs(s) ** (2 / p), s)))\n    return out\n38:def reset():\n46:def material(role):\n  /** One plume material per nozzle kind: a kind fires together. */\n  private plumeMats: Record<NozzleKind, THREE.ShaderMaterial>;\n  private exhaustColor: THREE.Color;\n  private targets = new Map<Joint, THREE.Quaternion>();\n\n  constructor(readonly root: THREE.Object3D) {\n    const map = nodes(root);\n    for (const j of JOINTS) {\n      const n = find(map, j);\n      if (n) this.joints.set(j, n);\n    }\n    this.cockpit = find(map, 'cockpit') ?? root;\n    this.grip = find(map, 'grip.R') ?? root;\n    const paint = PALETTES[(root.userData.palette as PaletteName | undefined) ?? 'merc'].glow_exhaust;\n    this.exhaustColor = new THREE.Color(paint.color);\n    this.plumeMats = {\n      main: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 0),\n      binder: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 17.3),\n      calf: plumeMaterial(this.exhaustColor, paint.glow ?? 1, 41.7),\n    };\n    root.traverse((o) => {\n      const dir = o.userData.dir as number[] | undefined;\n      if (!dir || !/^nozzle/.test(o.name)) return;\n      const kind: NozzleKind = /main/.test(o.name) ? 'main' : /binder/.test(o.name) ? 'binder' : 'calf';\n      const radius = (o.userData.radius as number) ?? 0.5;\n      // the plume's own space is in nozzle radii (render/plume.ts)\n      const plume = new THREE.Mesh(PLUME_HULL, this.plumeMats[kind]);\n      const d = new THREE.Vector3(...(dir as [number, number, number]));\n      plume.quaternion.setFromUnitVectors(new THREE.Vector3(0, 0, 1), d);\n      plume.scale.setScalar(radius);\n      plume.visible = false;\n      plume.renderOrder = 2;\n      o.add(plume);\n      this.nozzles.push({ node: o, dir: d, radius, kind, plume });\n    });\n  }\n\n  /** Any named node of the model (extras like harken.L), or null. */\n  node(name: string): THREE.Object3D | null {\n    return find(nodes(this.root), name) ?? null;\n  }\n\n  /** Snap to a pose. */\n  apply(pose: Pose) {\n    for (const [j, node] of this.joints) {\n      const r = pose[j] ?? [0, 0, 0];\n      node.quaternion.setFromEuler(tmpE.set(r[0] * D, r[1] * D, r[2] * D));\n    }\n"}
agent
+2:03I disagree with one part of the reflection: “plastic” is not enough evidence to make surface detail the first fix. Your earlier clarification was explicit about shape. I’d test form under fixed viewing conditions, then test finish separately.
For the visual, I’m staging the existing striker_a with the ship’s gantry and a pilot. It will test scale and presence, while keeping clear that better lighting does not settle the design.
apply_patch, exec_commandapply_patch (+1 more)
input
text(await tools.apply_patch("*** Begin Patch\n*** Add File: ~/work/sortie/tools/astra/render_study.py\n+\"\"\"One existing frame, staged in its existing hangar. No model files are changed.\n+\n+ ~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py -- --preview\n+ ~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py\n+\n+Preview and logs live in review/out/astra. The final PNG goes to ~/out.\n+\"\"\"\n+import argparse\n+import json\n+import math\n+from pathlib import Path\n+import sys\n+import time\n+\n+import bpy\n+from mathutils import Vector, Matrix\n+\n+START = time.monotonic()\n+ROOT = Path(__file__).resolve().parents[2]\n+parser = argparse.ArgumentParser()\n+parser.add_argument('--preview', action='store_true')\n+args = parser.parse_args(sys.argv[sys.argv.index('--') + 1:] if '--' in sys.argv else [])\n+SCRATCH = ROOT / 'review/out/astra'\n+SCRATCH.mkdir(parents=True, exist_ok=True)\n+OUT = Path.home() / 'out'\n+OUT.mkdir(exist_ok=True)\n+bpy.ops.object.select_all(action='SELECT')\n+bpy.ops.object.delete(use_global=False)\n+\n+\n+def load(name):\n+ before = set(bpy.data.objects)\n+ bpy.ops.import_scene.gltf(filepath=str(ROOT / 'public/assets' / f'{name}.glb'))\n+ objs = set(bpy.data.objects) - before\n+ return {o.name: o for o in objs}\n+\n+\n+def srgb(h):\n+ rgb = [int(h[i:i+2], 16) / 255 for i in (0, 2, 4)]\n+ return tuple(c / 12.92 if c <= .04045 else ((c + .055) / 1.055) ** 2.4 for c in rgb)\n+\n+\n+# Colours follow src/render/palette.ts, merc. Cycles finish is a study, not a port of look.ts.\n+PAINT = {\n+ 'main': ('d9dce1', .42, 0), 'accent': ('27527a', .42, 0),\n+ 'trim': ('c9452f', .4, 0), 'frame': ('5b6069', .48, .8),\n+ 'joint': ('33363c', .55, .9), 'metal': ('9aa0a8', .3, 1),\n+ 'visor': ('06080b', .22, .2), 'sensor': ('1d6b5c', .2, .3),\n+ 'hull': ('a9adb4', .55, 0), 'hull_dark': ('4a4f57', .6, .6),\n+ 'interior': ('5e6168', .7, .3), 'deck': ('3f434a', .7, .6),\n+ 'hazard': ('e3b62b', .6, 0), 'suit': ('1f2a4f', .6, 0),\n+}\n+EMIT = {\n+ 'glow_eye': ('7ef7e6', 3), 'glow_hot': ('eafffb', 3),\n+ 'glow_core': ('7ef7e6', 1), 'glow_thruster': ('9cc6ff', .3),\n+ 'light': ('fff3df', 3), 'screen': ('4fd8cc', 1.5),\n+ 'lamp_red': ('ff3a2e', 2), 'lamp_green': ('48ff6c', 2),\n+}\n+\n+\n+def recolor():\n+ for mat in bpy.data.materials:\n+ role = mat.name.split('.')[0]\n+ mat.use_nodes = True\n+ bsdf = mat.node_tree.nodes.get('Principled BSDF')\n+ if not bsdf:\n+ continue\n+ if role in PAINT:\n+ col, rough, metal = PAINT[role]\n+ bsdf.inputs['Base Color'].default_value = (*srgb(col), 1)\n+ bsdf.inputs['Roughness'].default_value = rough\n+ bsdf.inputs['Metallic'].default_value = metal\n+ if role in ('main', 'accent', 'trim'):\n+ bsdf.inputs['Coat Weight'].default_value = .16\n+ bsdf.inputs['Coat Roughness'].default_value = .32\n+ elif role in EMIT:\n+ col, strength = EMIT[role]\n+ bsdf.inputs['Base Color'].default_value = (*srgb(col), 1)\n+ bsdf.inputs['Emission Color'].default_value = (*srgb(col), 1)\n+ bsdf.inputs['Emission Strength'].default_value = strength\n+\n+\n+ship = load('ship')\n+for name, o in ship.items():\n+ if name.startswith(('gantry.1.light', 'gantry.1.heavy', 'gantry.2.light', 'gantry.2.heavy',\n+ 'clamps.light', 'clamps.heavy')):\n+ for part in [o, *o.children_recursive]:\n+ part.hide_render = True\n+\n+mech = load('striker_a')\n+root = mech['frame']\n+root.location = (16, 0, .2)\n+\n+# Resting arms with a small, deliberate asymmetry. Feet keep the authored stance.\n+# Imported GLB nodes recover Blender's original Z-up axes.\n+for name, angle in {'upperarm.L': (-3, -6, 0), 'upperarm.R': (0, 6, 0),\n+ 'forearm.L': (-16, 0, 0), 'forearm.R': (-9, 0, 0),\n+ 'head': (0, 0, -8)}.items():\n+ o = mech[name]\n+ o.rotation_mode = 'XYZ'\n+ o.rotation_euler = tuple(math.radians(v) for v in angle)\n+\n+pilot = load('lab_pilot')\n+for o in [pilot['slot1'], *pilot['slot1'].children_recursive]:\n+ o.hide_render = True\n+pilot['lab'].location = (8.5, -3, .2)\n+pilot['lab'].rotation_euler.z = math.radians(145)\n+recolor()\n+\n+\n+def light(name, at, target, color, power, size, shape='DISK', size_y=None):\n+ data = bpy.data.lights.new(name, 'AREA')\n+ data.energy = power\n+ data.color = srgb(color)\n+ data.shape = shape\n+ data.size = size\n+ if size_y is not None:\n+ data.size_y = size_y\n+ ob = bpy.data.objects.new(name, data)\n+ bpy.context.collection.objects.link(ob)\n+ ob.location = at\n+ ob.rotation_euler = (Vector(target) - ob.location).to_track_quat('-Z', 'Y').to_euler()\n+ return ob\n+\n+\n+light('front worklight', (7, -12, 21), (16, 0, 10), 'e3edff', 42000, 10)\n+light('bay warm rim', (22, 10, 23), (16, 0, 9), 'ffd6a0', 50000, 7)\n+light('port fill', (-7, 0, 15), (16, 0, 9), '91bfff', 16000, 12)\n+light('pilot pool', (7, -5, 7), (8, -3, 0), 'ffe4b5', 2200, 3)\n+light('rear wall wash', (12, 20, 20), (10, 32, 14), '8ebbd4', 18000, 10)\n+\n+scene = bpy.context.scene\n+scene.world.use_nodes = True\n+scene.world.node_tree.nodes['Background'].inputs[0].default_value = (*srgb('9ab3c9'), 1)\n+scene.world.node_tree.nodes['Background'].inputs[1].default_value = .15\n+\n+camdata = bpy.data.cameras.new('study camera')\n+cam = bpy.data.objects.new('study camera', camdata)\n+bpy.context.collection.objects.link(cam)\n+cam.location = (-1, -24, 3.2)\n+cam.rotation_euler = (Vector((13, 2, 9.0)) - cam.location).to_track_quat('-Z', 'Y').to_euler()\n+camdata.lens = 35\n+camdata.clip_end = 1000\n+scene.camera = cam\n+\n+scene.render.engine = 'CYCLES'\n+scene.cycles.device = 'CPU'\n+scene.cycles.samples = 24 if args.preview else 160\n+scene.cycles.use_denoising = True\n+scene.cycles.seed = 37\n+scene.cycles.max_bounces = 7\n+scene.cycles.diffuse_bounces = 4\n+scene.cycles.glossy_bounces = 4\n+scene.render.resolution_x = 1000 if args.preview else 2400\n+scene.render.resolution_y = 750 if args.preview else 1800\n+scene.render.resolution_percentage = 100\n+scene.render.image_settings.file_format = 'PNG'\n+scene.render.image_settings.color_mode = 'RGB'\n+scene.view_settings.view_transform = 'AgX'\n+scene.view_settings.look = 'AgX - Medium High Contrast'\n+scene.view_settings.exposure = .3\n+scene.render.filepath = str(SCRATCH / 'preview.png' if args.preview else OUT / 'sortie.png')\n+bpy.context.view_layer.update()\n+print('STUDY_BOUNDS', json.dumps({\n+ 'mech_root': list(root.matrix_world.translation),\n+ 'pilot_root': list(pilot['lab'].matrix_world.translation),\n+ 'camera': list(cam.location),\n+}))\n+bpy.ops.render.render(write_still=True)\n+elapsed = round(time.monotonic() - START, 2)\n+metadata = {'elapsed_seconds': elapsed, 'preview': args.preview,\n+ 'resolution': [scene.render.resolution_x, scene.render.resolution_y],\n+ 'samples': scene.cycles.samples, 'assets': ['striker_a.glb', 'ship.glb', 'lab_pilot.glb'],\n+ 'output': scene.render.filepath}\n+(SCRATCH / ('preview.json' if args.preview else 'render.json')).write_text(json.dumps(metadata, indent=2) + '\\n')\n+print('STUDY_RESULT', json.dumps(metadata))\n*** End Patch")); text(await tools.exec_command({cmd:"~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py -- --preview > review/out/astra-render-preview.log 2>&1","yield_time_ms":1000,"max_output_tokens":2000}));result, 4 lines
Script completed Wall time 0.1 seconds Output: {}{"chunk_id":"6854e5","wall_time_seconds":0.000005921,"exit_code":1,"original_token_count":21,"output":"/bin/bash: line 1: review/out/astra-render-preview.log: No such file or directory\n"}exec_commandmkdir -p review/out/astra && ~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py -- --preview > review/out/astra/preview.log 2>&1
command
mkdir -p review/out/astra && ~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py -- --preview > review/out/astra/preview.log 2>&1
result, 4 lines
Script completed Wall time 1.2 seconds Output: {"chunk_id":"4fb79c","wall_time_seconds":1.001995162,"session_id":74572,"original_token_count":0,"output":""}exec_commandtail -25 review/out/astra/preview.log && sed -n '1,180p' tools/outlines-lib.mjs && sed -n '1,140p' kit/block.py
command
tail -25 review/out/astra/preview.log && sed -n '1,180p' tools/outlines-lib.mjs && sed -n '1,140p' kit/block.py
result, 4 lines
Script completed Wall time 0.1 seconds Output: {"chunk_id":"c5fcf2","wall_time_seconds":0.00000565,"exit_code":0,"original_token_count":3034,"output":"03:16:07 | INFO: Blender create Mesh node pilot_shin_R_main.001\n03:16:07 | INFO: Blender create Mesh node pilot_shin_R_suit.001\n03:16:07 | INFO: Blender create Mesh node pilot_shin_R_trim.001\n03:16:07 | INFO: Blender create Mesh node pilot_thigh_L_main.001\n03:16:07 | INFO: Blender create Mesh node pilot_thigh_L_suit.001\n03:16:07 | INFO: Blender create Mesh node pilot_thigh_R_main.001\n03:16:07 | INFO: Blender create Mesh node pilot_thigh_R_suit.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_L_main.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_L_suit.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_L_trim.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_R_main.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_R_suit.001\n03:16:07 | INFO: Blender create Mesh node pilot_upperarm_R_trim.001\n03:16:07 | INFO: Blender create Mesh node plinth.001\n03:16:07 | INFO: glTF import finished in 0.64s\n~/work/sortie/tools/astra/render_study.py:64: DeprecationWarning: 'Material.use_nodes' is expected to be removed in Blender 6.0\n mat.use_nodes = True\n~/work/sortie/tools/astra/render_study.py:133: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n scene.world.use_nodes = True\n00:26.468 render | Saved: '~/work/sortie/review/out/astra/preview.png'\nSTUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.20000000298023224], \"pilot_root\": [8.5, -3.0, 0.20000000298023224], \"camera\": [-1.0, -24.0, 3.200000047683716]}\nSTUDY_RESULT {\"elapsed_seconds\": 25.88, \"preview\": true, \"resolution\": [1000, 750], \"samples\": 24, \"assets\": [\"striker_a.glb\", \"ship.glb\", \"lab_pilot.glb\"], \"output\": \"~/work/sortie/review/out/astra/preview.png\"}\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n// Outline sheets: rough black shapes at one scale, for reacting to in seconds (docs/handbook.md).\n// A spec is plain data, in metres, x across, z up, ground at z = 0, centre line at x = 0:\n// { \"title\": \"round 1\", \"outlines\": [ { \"note\": \"optional\", \"parts\": [\n// { \"pts\": [[x, z], ...], \"mirror\": true }, a polygon, and its mirror across x = 0\n// { \"circle\": [x, z, r], \"mirror\": true } ], a circle\n// \"side\": [ ... same parts ... ] } ] } optional side view, drawn beside the front\nconst PILOT_M = 1.75;\n\nfunction bounds(parts) {\n let x = 0, z = 0;\n for (const p of parts ?? []) {\n if (p.circle) {\n x = Math.max(x, Math.abs(p.circle[0]) + p.circle[2]);\n z = Math.max(z, p.circle[1] + p.circle[2]);\n } else for (const [px, pz] of p.pts) {\n x = Math.max(x, Math.abs(px));\n z = Math.max(z, pz);\n }\n }\n return { halfWidth: x, height: z };\n}\n\nfunction shape(p, tx, ty, s, flip) {\n const sign = flip ? -1 : 1;\n if (p.circle) {\n const [x, z, r] = p.circle;\n return `<circle cx=\"${(tx + sign * x * s).toFixed(1)}\" cy=\"${(ty - z * s).toFixed(1)}\" r=\"${(r * s).toFixed(1)}\"/>`;\n }\n const pts = p.pts.map(([x, z]) => `${(tx + sign * x * s).toFixed(1)},${(ty - z * s).toFixed(1)}`).join(' ');\n return `<polygon points=\"${pts}\"/>`;\n}\n\nfunction shapes(parts, tx, ty, s) {\n const out = [];\n for (const p of parts ?? []) {\n out.push(shape(p, tx, ty, s, false));\n if (p.mirror) out.push(shape(p, tx, ty, s, true));\n }\n return out.join('');\n}\n\n/** A person for scale: plain enough not to read as part of any design. */\nfunction person(x, ground, s) {\n const h = PILOT_M * s, w = Math.max(h * 0.28, 2);\n return `<g fill=\"#b03a2e\"><rect x=\"${(x - w / 2).toFixed(1)}\" y=\"${(ground - h * 0.82).toFixed(1)}\" width=\"${w.toFixed(1)}\" height=\"${(h * 0.82).toFixed(1)}\"/>` +\n `<circle cx=\"${x.toFixed(1)}\" cy=\"${(ground - h * 0.9).toFixed(1)}\" r=\"${(h * 0.1).toFixed(1)}\"/></g>`;\n}\n\n/** The sheet as an SVG string, with its pixel size. Every outline is drawn at the same scale. */\nexport function outlineSheet(spec, { cols = 6, tileHeight = 460 } = {}) {\n const list = spec.outlines ?? [];\n if (!list.length) throw new Error('outlines: the spec has no outlines');\n let tall = 0, front = 0, side = 0;\n for (const o of list) {\n const f = bounds(o.parts), b = bounds(o.side);\n tall = Math.max(tall, f.height, b.height);\n front = Math.max(front, f.halfWidth);\n side = Math.max(side, b.halfWidth);\n }\n if (tall <= 0 || front <= 0) throw new Error('outlines: nothing has any size');\n const margin = { top: 34, bottom: 18, gap: 16 };\n const s = (tileHeight - margin.top - margin.bottom) / tall;\n const frontW = front * 2 * s, sideW = side * 2 * s;\n const tileW = Math.ceil(frontW + (side ? sideW + margin.gap : 0) + margin.gap * 2 + 14);\n const rows = Math.ceil(list.length / cols);\n const head = spec.title ? 34 : 0;\n const W = Math.min(cols, list.length) * tileW, H = rows * tileHeight + head;\n const tiles = list.map((o, i) => {\n const x0 = (i % cols) * tileW, y0 = Math.floor(i / cols) * tileHeight + head;\n const ground = y0 + tileHeight - margin.bottom;\n const fx = x0 + margin.gap + frontW / 2;\n const sx = fx + frontW / 2 + margin.gap + sideW / 2;\n const px = x0 + tileW - 9;\n return `<rect x=\"${x0 + .5}\" y=\"${y0 + .5}\" width=\"${tileW - 1}\" height=\"${tileHeight - 1}\" fill=\"none\" stroke=\"#d6d6d2\"/>` +\n `<line x1=\"${x0 + 6}\" x2=\"${x0 + tileW - 6}\" y1=\"${ground}\" y2=\"${ground}\" stroke=\"#a9a9a4\"/>` +\n `<text x=\"${x0 + 8}\" y=\"${y0 + 22}\" class=\"n\">${i + 1}</text>` +\n (o.note ? `<text x=\"${x0 + 38}\" y=\"${y0 + 22}\" class=\"t\">${escapeXml(o.note)}</text>` : '') +\n `<g fill=\"#111\" stroke=\"#111\" stroke-width=\".8\">${shapes(o.parts, fx, ground, s)}${o.side ? shapes(o.side, sx, ground, s) : ''}</g>` +\n person(px, ground, s);\n }).join('');\n const title = spec.title ? `<text x=\"8\" y=\"23\" class=\"h\">${escapeXml(spec.title)}</text>` : '';\n const svg = `<svg xmlns=\"http://www.w3.org/2000/svg\" width=\"${W}\" height=\"${H}\" viewBox=\"0 0 ${W} ${H}\">` +\n `<style>text{font-family:system-ui,sans-serif;fill:#333}.n{font-size:18px;font-weight:700}.t{font-size:12px}.h{font-size:16px;font-weight:600}</style>` +\n `<rect width=\"${W}\" height=\"${H}\" fill=\"#f4f4f1\"/>${title}${tiles}</svg>`;\n return { svg, width: W, height: H, count: list.length, scale: s };\n}\n\nfunction escapeXml(t) {\n return String(t).replace(/[&<>\"]/g, (c) => ({ '&': '&', '<': '<', '>': '>', '\"': '"' })[c]);\n}\n\"\"\"Block models: plain boxes on the 22 joint rig, for judging mass and motion before any plate exists.\n\nA block model is one file, kit/blocks/<name>.py, with a build() that takes this module's Blocks class.\nIt builds in seconds, into a gitignored public/assets/block_<name>.glb:\n\n npm run kit -- block_dummy\n npm run clip -- block_dummy\n\nGeometry is authored in world rest pose coordinates in metres, models facing -Y, Z up, left is +X, as\nin the rest of the kit. Roles are the usual ones (main, accent, frame, joint). Nothing here is a design\nrule: no maker, frame or grade carries over unless a block file asks for it.\n\"\"\"\nimport importlib\n\nimport bpy\nfrom mathutils import Vector\n\nfrom lib import loft, merge, mirror_x, octo, solid\nfrom mech import joints as striker_joints, nozzle_pair, pair\n\nSIDED = {\"shoulder\", \"upperarm\", \"forearm\", \"hand\", \"grip\", \"thigh\", \"shin\", \"foot\", \"binder\"}\nBEVEL = .03\n\n\nclass Blocks:\n \"\"\"The rig plus block primitives. `joints` overrides rest positions: {\"thigh\": (1.1, 0, 9.5)} moves\n both thighs (give the left, +X, the right mirrors), {\"pelvis\": (0, 0, 9.8)} moves one node. Other\n joints stay where the striker has them, in world coordinates, so moving one moves nothing else.\"\"\"\n\n def __init__(self, joints=None, height=17.6):\n J = striker_joints()\n self.nodes = {o.name: o for o in J.values()}\n self.n = 0\n J[\"frame\"][\"frame\"] = \"block\"\n J[\"frame\"][\"height\"] = height\n place = {name: o.matrix_world.translation.copy() for name, o in self.nodes.items()}\n for key, at in (joints or {}).items():\n if key in SIDED:\n place[f\"{key}.L\"] = Vector(at)\n place[f\"{key}.R\"] = Vector((-at[0], at[1], at[2]))\n elif key in place:\n place[key] = Vector(at)\n else:\n raise KeyError(f\"block: no joint {key}\")\n for name, o in self.nodes.items(): # striker_joints() makes parents first\n if o.parent is not None:\n o.location = o.parent.matrix_world.inverted() @ place[name]\n bpy.context.view_layer.update()\n\n def at(self, name):\n return self.nodes[name].matrix_world.translation.copy()\n\n def _put(self, joint, bm, role, mirror):\n self.n += 1\n name = f\"block{self.n}_{joint}\"\n if joint in SIDED:\n pair(name, bm, role, self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"], bevel=BEVEL, panels=False)\n elif mirror:\n solid(name, merge(bm, mirror_x(bm)), role, self.nodes[joint], bevel=BEVEL, panels=False)\n else:\n solid(name, bm, role, self.nodes[joint], bevel=BEVEL, panels=False)\n\n def box(self, joint, x, y, z, role=\"main\", mirror=False):\n \"\"\"A box from x, y, z ranges (lo, hi). A sided joint (thigh, shin, ...) takes the left's numbers\n and mirrors to the right. `mirror` does the same for a box on a centre joint.\"\"\"\n r = [(x[0], y[0]), (x[1], y[0]), (x[1], y[1]), (x[0], y[1])]\n self._put(joint, loft([(z[0], r), (z[1], r)]), role, mirror)\n\n def taper(self, joint, rings, role=\"main\", mirror=False, chamfer=.15):\n \"\"\"A lofted block through rings (z, width, depth, x, y), bottom to top.\"\"\"\n self._put(joint, loft([(z, octo(w, d, chamfer, x=x, y=y)) for z, w, d, x, y in rings]), role, mirror)\n\n def bone(self, joint, a, b, w, d, role=\"main\", chamfer=.1):\n \"\"\"A block from joint a to joint b, both named for the left side: bone(\"thigh\", \"thigh.L\", \"shin.L\", 1, 1).\"\"\"\n pa, pb = self.at(a), self.at(b)\n lo, hi = (pa, pb) if pa.z < pb.z else (pb, pa)\n self.taper(joint, [(lo.z, w, d, lo.x, lo.y), (hi.z, w, d, hi.x, hi.y)], role, chamfer=chamfer)\n\n def nozzles(self, joint, at, direction, r=.45, length=.9, kind=\"main\"):\n \"\"\"A nozzle pair that fires plumes in the game. `kind`: main, binder or calf.\"\"\"\n if joint in SIDED:\n jl, jr = self.nodes[f\"{joint}.L\"], self.nodes[f\"{joint}.R\"]\n else:\n jl = jr = self.nodes[joint]\n nozzle_pair(kind, at, direction, r, length, jl, jr, housing=False)\n\n def mannequin(self):\n \"\"\"A neutral box on every bone, sized from the joints alone. For testing tools, not a design.\"\"\"\n for joint, a, b, w, d in ((\"thigh\", \"thigh.L\", \"shin.L\", 1.0, 1.0), (\"shin\", \"shin.L\", \"foot.L\", 1.0, 1.0),\n (\"upperarm\", \"upperarm.L\", \"forearm.L\", .7, .7), (\"forearm\", \"forearm.L\", \"hand.L\", .7, .7)):\n self.bone(joint, a, b, w, d)\n foot = self.at(\"foot.L\")\n self.box(\"foot\", (foot.x - .5, foot.x + .5), (foot.y - 1.2, foot.y + .6), (0, foot.z))\n hand = self.at(\"hand.L\")\n self.box(\"hand\", (hand.x - .3, hand.x + .3), (hand.y - .3, hand.y + .3), (hand.z - .8, hand.z))\n pelvis, torso, neck, head = self.at(\"pelvis\"), self.at(\"torso\"), self.at(\"neck\"), self.at(\"head\")\n self.box(\"pelvis\", (-1.3, 1.3), (-.8, .8), (pelvis.z - .8, pelvis.z + .4))\n self.box(\"waist\", (-.8, .8), (-.6, .6), (pelvis.z + .4, torso.z))\n shoulder = self.at(\"shoulder.L\")\n self.box(\"torso\", (-shoulder.x, shoulder.x), (-1, 1), (torso.z, neck.z))\n self.box(\"shoulder\", (shoulder.x, shoulder.x + .9), (-.6, .6), (shoulder.z - .6, shoulder.z + .4))\n self.box(\"neck\", (-.3, .3), (-.3, .3), (neck.z, head.z))\n self.box(\"head\", (-.5, .5), (-.6, .6), (head.z, head.z + 1.1))\n pack = self.at(\"backpack\")\n self.box(\"backpack\", (-.9, .9), (pack.y - .5, pack.y + .5), (pack.z - 1, pack.z + 1))\n\n\ndef build_block(name):\n \"\"\"block_<name> from kit/blocks/<name>.py.\"\"\"\n module = importlib.import_module(f\"blocks.{name.removeprefix('block_')}\")\n importlib.reload(module)\n module.build(Blocks)\n"}view_image~/work/sortie/review/out/astra/preview.png
input
image((await tools.view_image({path:"~/work/sortie/review/out/astra/preview.png"})).image_url);result, 4 lines
Script completed
Wall time 0.0 seconds
Output:
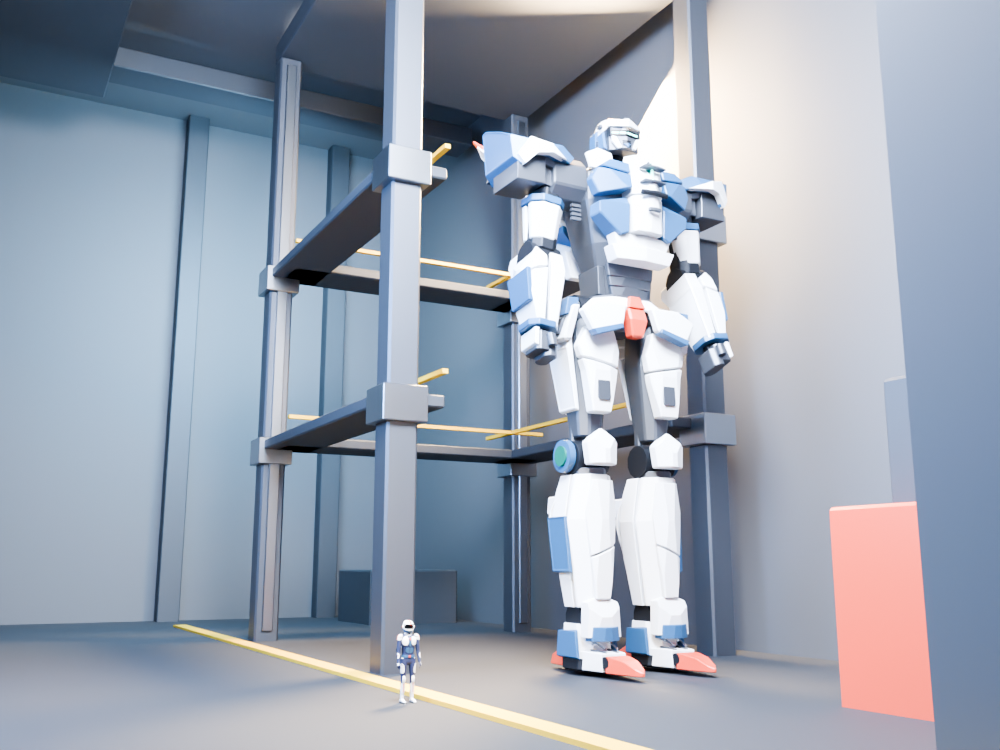
preview.png exec_commandpython - <<'PY' (+1 more)
command
python - <<'PY' import json,struct b=open('public/assets/ship.glb','rb').read();n=struct.unpack_from('<I',b,12)[0];j=json.loads(b[20:20+n]);print('\n'.join(v.get('name','') for v in j['nodes'] if 'mesh' in v)) PY rg --files node_modules/@fontsource/chakra-petch/files | head -10 && git status --shortresult, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"5cd139","wall_time_seconds":0.00000363,"exit_code":0,"original_token_count":352,"output":"back_wall_ribs\nband-34\nband-72\nbridge\nbridge_glass\nbridge_mast\nceiling_lights\ncrane\ncrate0\ncrate1\ncrate2\ncrate3\ncrate4\ncrate5\ndoor_edge.L\ndoor_panel.L\ndoor_edge.R\ndoor_panel.R\nengine0\nengine0.glow\nengine1\nengine1.glow\nengine2\nengine2.glow\ngantry_decks.1h\ngantry_jackets.1\ngantry_lifts.1h\ngantry_rails.1h\ncradle_frames.1\ncradle_hazard.1\ncradle_plates.1\ngantry_decks.1l\ngantry_lifts.1l\ngantry_rails.1l\ngantry_decks.1\ngantry_lifts.1\ngantry_rails.1\ngantry_decks.2h\ngantry_jackets.2\ngantry_lifts.2h\ngantry_rails.2h\ncradle_frames.2\ncradle_hazard.2\ncradle_plates.2\ngantry_decks.2l\ngantry_lifts.2l\ngantry_rails.2l\ngantry_decks.2\ngantry_lifts.2\ngantry_rails.2\ngantry_posts.1\ngantry_posts.2\ngantry_top.1\ngantry_top.2\nhangar_deck\nhangar_lane\nhull_lower\nhull_upper\nmouth_frame\nmouth_hazard\nnav.L\nnav.R\nradiator.L0\nradiator.L1\nradiator.L2\nradiator.R0\nradiator.R1\nradiator.R2\nheavy_clamp1\nheavy_clamp-1\nheavy_hazard\nheavy_heel1\nheavy_heel-1\nheavy_lip1\nheavy_lip-1\noutriggers\nsled_body\nsled_clamp1\nsled_clamp-1\nsled_hazard\nsled_heel_bar\nsled_legs\nsled_lip1\nsled_lip-1\nclamp1\nclamp-1\nclamp_lip1\nclamp_lip-1\nshuttle_body\nshuttle_hazard\nsignal_green\nsignal_red\nsignal_box\nspine\nsponson.L\nsponson.R\nstern\ntube_deck\ntube_edges\ntube_lights\ntube_rails\ntube_ribs\ntube_strips\nturret0\nturret1\nturret2\nturret_gun0-0.8\nturret_gun00.8\nturret_gun1-0.8\nturret_gun2-0.8\nturret_gun10.8\nturret_gun20.8\nturret_head0\nturret_head1\nturret_head2\n"}{"chunk_id":"20bc33","wall_time_seconds":0.00000354,"exit_code":0,"original_token_count":211,"output":"node_modules/@fontsource/chakra-petch/files/chakra-petch-latin-ext-300-italic.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-vietnamese-400-italic.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-thai-700-normal.woff\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-latin-ext-400-normal.woff\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-vietnamese-400-normal.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-vietnamese-500-normal.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-vietnamese-300-italic.woff\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-latin-600-italic.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-latin-ext-500-normal.woff2\nnode_modules/@fontsource/chakra-petch/files/chakra-petch-latin-400-italic.woff2\n?? tools/astra/\n"}
apply_patch, exec_commandapply_patch (+1 more)
input
text(await tools.apply_patch("*** Begin Patch\n*** Update File: ~/work/sortie/tools/astra/render_study.py\n@@\n pilot['lab'].location = (8.5, -3, .2)\n+pilot['lab'].rotation_mode = 'XYZ'\n pilot['lab'].rotation_euler.z = math.radians(145)\n recolor()\n+\n+# Lower the hangar's reflectance so the pale armour reads against it.\n+# These are local material copies created by the GLB importer.\n+ship_materials = {m for o in ship.values() if o.type == 'MESH' for m in o.data.materials}\n+for mat in ship_materials:\n+ role = mat.name.split('.')[0]\n+ bsdf = mat.node_tree.nodes.get('Principled BSDF')\n+ if role in ('hull', 'hull_dark', 'interior', 'frame', 'metal', 'deck'):\n+ col = bsdf.inputs['Base Color'].default_value\n+ bsdf.inputs['Base Color'].default_value = tuple(c * .22 for c in col[:3]) + (1,)\n+ bsdf.inputs['Roughness'].default_value = .56\n+ bsdf.inputs['Metallic'].default_value = .35\n+ if role == 'deck':\n+ noise = mat.node_tree.nodes.new('ShaderNodeTexNoise')\n+ noise.inputs['Scale'].default_value = 220\n+ noise.inputs['Roughness'].default_value = .7\n+ bump = mat.node_tree.nodes.new('ShaderNodeBump')\n+ bump.inputs['Strength'].default_value = .16\n+ bump.inputs['Distance'].default_value = .012\n+ mat.node_tree.links.new(noise.outputs['Fac'], bump.inputs['Height'])\n+ mat.node_tree.links.new(bump.outputs['Normal'], bsdf.inputs['Normal'])\n@@\n-light('front worklight', (7, -12, 21), (16, 0, 10), 'e3edff', 42000, 10)\n-light('bay warm rim', (22, 10, 23), (16, 0, 9), 'ffd6a0', 50000, 7)\n-light('port fill', (-7, 0, 15), (16, 0, 9), '91bfff', 16000, 12)\n-light('pilot pool', (7, -5, 7), (8, -3, 0), 'ffe4b5', 2200, 3)\n-light('rear wall wash', (12, 20, 20), (10, 32, 14), '8ebbd4', 18000, 10)\n+light('front worklight', (7, -8, 20), (16, 0, 10), 'd5e5ff', 14000, 7)\n+light('bay warm rim', (22, 10, 23), (16, 0, 9), 'ffd6a0', 22000, 5)\n+light('port fill', (-7, 0, 15), (16, 0, 9), '91bfff', 2600, 12)\n+light('pilot pool', (7, -5, 7), (8, -3, 0), 'ffe4b5', 1600, 2)\n+light('rear wall wash', (12, 20, 20), (10, 32, 14), '8ebbd4', 4500, 8)\n@@\n-scene.world.node_tree.nodes['Background'].inputs[1].default_value = .15\n+scene.world.node_tree.nodes['Background'].inputs[1].default_value = .06\n@@\n-cam.location = (-1, -24, 3.2)\n+cam.location = (-4, -17, 2.8)\n@@\n-camdata.lens = 35\n+camdata.lens = 32\n@@\n-scene.view_settings.exposure = .3\n+scene.view_settings.exposure = 0\n*** End Patch")); text(await tools.exec_command({cmd:"~/.local/bin/blender -b --factory-startup -t 8 -P tools/astra/render_study.py -- --preview > review/out/astra/preview.log 2>&1","yield_time_ms":1000,"max_output_tokens":1000}));result, 4 lines
Script completed
Wall time 1.2 seconds
Output:
{}{"chunk_id":"774ee7","wall_time_seconds":1.001237406,"session_id":86819,"original_token_count":0,"output":""}
exec_command, view_imagetail -8 review/out/astra/preview.log (+1 more)
input
text(await tools.exec_command({cmd:"tail -8 review/out/astra/preview.log","max_output_tokens":1000})); image((await tools.view_image({path:"~/work/sortie/review/out/astra/preview.png"})).image_url);result, 4 lines
Script completed
Wall time 0.1 seconds
Output:
{"chunk_id":"e005db","wall_time_seconds":0.00000354,"exit_code":0,"original_token_count":179,"output":"~/work/sortie/tools/astra/render_study.py:155: DeprecationWarning: 'World.use_nodes' is expected to be removed in Blender 6.0\n  scene.world.use_nodes = True\n00:24.115  render           | Saved: '~/work/sortie/review/out/astra/preview.png'\nSTUDY_BOUNDS {\"mech_root\": [16.0, 0.0, 0.20000000298023224], \"pilot_root\": [8.5, -3.0, 0.20000000298023224], \"camera\": [-4.0, -17.0, 2.799999952316284]}\nSTUDY_RESULT {\"elapsed_seconds\": 23.56, \"preview\": true, \"resolution\": [1000, 750], \"samples\": 24, \"assets\": [\"striker_a.glb\", \"ship.glb\", \"lab_pilot.glb\"], \"output\": \"~/work/sortie/review/out/astra/preview.png\"}\nBlender 5.2.3 LTS (hash e13b728c6880 built 2026-10-22 01:35:05)\n\nBlender quit\n"}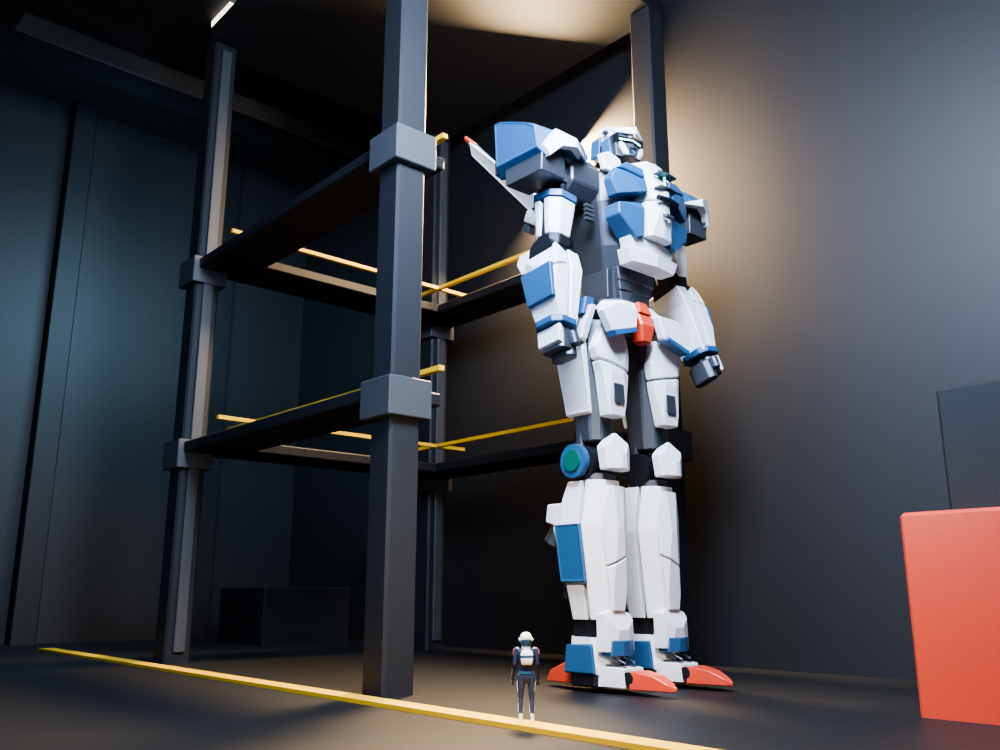
preview_2.png